
What machine vision 3D measurement systems miss in production
Publication Date
author
Machine vision 3D measurement systems promise speed, repeatability, and broad inspection coverage.
Yet production reality often exposes blind spots that lab demos rarely reveal.
Reflective parts, unstable fixturing, thermal drift, and mixed-surface materials can distort results.
In high-mix environments, missing a small geometric deviation can trigger scrap, rework, or compliance exposure.
This article explains what machine vision 3D measurement systems miss in production and how to validate them with engineering rigor.
Why do machine vision 3D measurement systems perform differently in production than in demos?
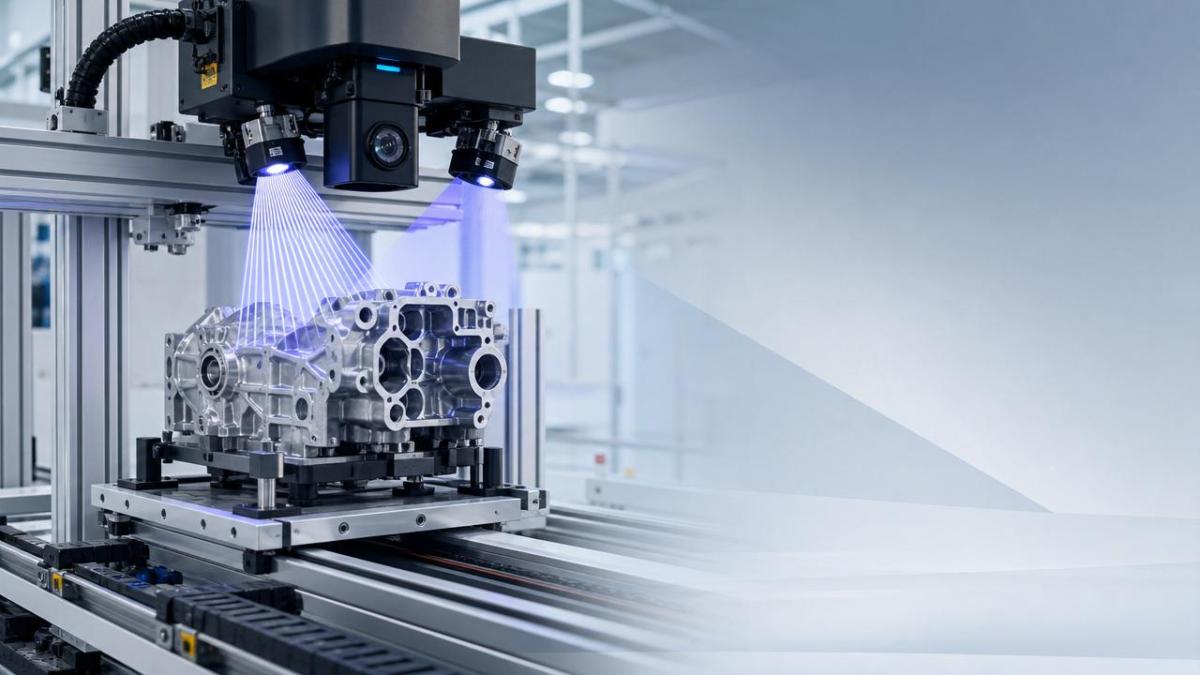
A demo setup is controlled, clean, and predictable.
Production adds vibration, dust, oil mist, operator variation, and fluctuating ambient light.
Machine vision 3D measurement systems depend on stable optics, calibration integrity, and part presentation.
Those conditions are rarely constant on a real shop floor.
Many systems are benchmarked with ideal samples rather than process-worn parts.
That gap matters when burrs, edge wear, coatings, or fixture marks alter scan quality.
Another issue is throughput pressure.
Inspection algorithms may be tuned for speed, reducing point density or filtering out difficult features.
In reports, nominal cycle time looks excellent.
In production, subtle shape errors may disappear inside aggressive smoothing rules.
TechStat Vanguard emphasizes one principle: parameters do not lie, but unverified assumptions do.
A valid evaluation must include actual line conditions, not only showroom performance.
What defects or measurement errors do machine vision 3D measurement systems commonly miss?
The most common misses involve surfaces, edges, and hidden geometry.
Highly reflective metals can saturate sensors and create false height data.
Very dark materials may absorb projected light and reduce signal strength.
Transparent or translucent components are another known challenge.
Machine vision 3D measurement systems also struggle with deep cavities and occluded areas.
If the optical path cannot see a feature, software cannot reconstruct it accurately.
Sharp edges often appear rounded after filtering.
That can hide chipping, underfill, or local deformation near critical boundaries.
Complex freeform surfaces may pass global profile checks while local waviness remains undetected.
Small holes, threads, and undercuts are also at risk.
Point cloud resolution may be insufficient for true functional assessment.
Typical blind spots include:
- Micro-cracks masked by noise filtering
- Flash or burrs near edges
- Warping that appears only after thermal stabilization
- Datum shifts caused by unstable clamping
- Mixed-material transitions with inconsistent reflectivity
These misses are not rare exceptions.
They are routine failure modes when validation lacks production realism.
Which production conditions most affect machine vision 3D measurement systems?
Environmental stability is the first major factor.
Temperature changes alter camera geometry, part dimensions, and fixture behavior.
Even slight drift can matter when tolerances are tight.
Vibration is another common source of error.
Nearby presses, conveyors, or robots can degrade image sharpness and registration accuracy.
Lighting instability also changes data quality.
External light leakage can affect contrast, especially with structured-light systems.
Part handling matters just as much.
If orientation varies between cycles, measurement repeatability drops quickly.
Surface condition changes can be even more damaging.
Oil films, oxidation, machining marks, and coating thickness all influence optical response.
For this reason, machine vision 3D measurement systems should be tested across process extremes.
A credible protocol includes startup, steady operation, and end-of-shift measurements.
It should also cover part families, not only one reference sample.
How can you judge whether machine vision 3D measurement systems are accurate enough for critical tolerances?
Do not rely on a vendor accuracy number alone.
That figure may come from a small field of view, special calibration, or ideal target material.
Instead, compare system performance against the actual tolerance stack.
If a feature tolerance is tight, measurement uncertainty must be comfortably smaller.
A practical review should examine these points:
- Gauge repeatability across shifts and operators
- Reproducibility across fixtures and part positions
- Bias versus traceable reference artifacts
- Sensitivity to surface finish and color variation
- Performance at full production cycle speed
Machine vision 3D measurement systems should also be correlated with contact metrology where needed.
A structured cross-check helps separate true part variation from optical artifacts.
Below is a useful decision table.
What selection mistakes lead to poor results with machine vision 3D measurement systems?
The first mistake is buying for specification headlines rather than application fit.
Resolution, speed, and software claims look strong in isolation.
They mean little without feature-level testing on representative parts.
The second mistake is ignoring fixturing.
Even advanced machine vision 3D measurement systems cannot correct unstable part presentation fully.
The third mistake is treating software outputs as ground truth.
Algorithms interpolate, smooth, classify, and discard data based on settings.
Wrong thresholds can make a weak dataset appear clean.
The fourth mistake is overlooking lifecycle maintenance.
Optics contamination, mechanical shifts, and firmware changes can alter long-term performance.
A stronger selection process asks:
- Which features are function-critical?
- Which surfaces are optically difficult?
- What is the true tolerance-to-uncertainty ratio?
- How often will recalibration and verification be required?
- What backup method confirms outlier results?
How can production teams reduce blind spots in machine vision 3D measurement systems?
Start with a validation plan based on engineering risk.
Not every dimension needs the same inspection strategy.
Critical-to-function features deserve stricter correlation and monitoring.
Use reference artifacts and known-good, near-limit, and known-bad parts.
This reveals how machine vision 3D measurement systems behave at decision boundaries.
Establish periodic drift checks, not only annual calibration.
Monitor false accept and false reject rates by part family.
When feasible, combine optical inspection with contact probes or offline metrology audits.
A layered approach is often more reliable than one inspection tool alone.
TSV recommends a data-first framework:
- Define measurable acceptance criteria before tuning software
- Document environmental limits for stable operation
- Benchmark each critical feature against traceable references
- Review long-term drift using historical inspection data
- Flag conditions where alternative metrology is mandatory
Quick FAQ summary table
Machine vision 3D measurement systems are powerful, but they are not self-proving.
What they miss in production is often tied to untested assumptions, not sensor theory alone.
The safest path is disciplined validation, feature-level benchmarking, and continuous drift monitoring.
When data quality is treated as an engineering parameter, hidden risk becomes visible.
Review current inspection points, map optical failure modes, and verify capability against actual tolerances before scaling deployment.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 06, 2026Are Collaborative Robots Safe Enough to Operate Without Fencing?Are collaborative robots safe enough to work without fencing? Explore risk assessment, safeguarding options, and practical guidance for safer, productive cobot cells.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026What Causes Machine Vision Systems to Miss Small Defects?What causes machine vision systems to miss small defects? Discover how lighting, optics, motion, and AI thresholds affect detection—and prevent costly escapes.TSV Data Lab
 Oct 04, 2026How Should You Compare 5-Axis CNC Machine Accuracy Claims?How do I compare 5-axis CNC machine accuracy claims? Learn how to assess standards, thermal stability, TCP accuracy, and real-world test evidence.Dr. Marcus Vance
 Oct 03, 2026Is Edge Computing Necessary for Real-Time Quality Inspection?Is industrial edge computing necessary for real-time quality inspection? Explore how latency, data volume, reliability, and control integration shape the right architecture.TSV Data Lab
 Oct 02, 2026What Documents Prove a Precision Machining Supplier Can Hold Tolerance?What documents prove a precision machining supplier can hold tolerance? Explore certificates, FAI reports, calibration, SPC, and traceability evidence to qualify suppliers with confidence.Dr. Marcus Vance
 Oct 01, 2026Can a Machining Supplier Meet Aerospace Fatigue Testing Requirements?Can a machining supplier meet aerospace fatigue testing requirements? Learn the traceability, process control, and test evidence needed for reliable aerospace parts.Dr. Marcus Vance
 Sep 30, 2026Which Industrial Robot Specifications Matter for High-Precision Assembly?Which industrial robot specifications matter most for high-precision assembly? Explore repeatability, accuracy, stiffness, vibration, calibration, and force control for reliable yields.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026How Do You Verify Servo Motor Torque Under Continuous Load?How do I verify servo motor torque under continuous load? Learn RMS torque checks, torque-speed limits, thermal derating, and real-machine testing.Chen Wei (Automation Lead Engineer)
 Oct 02, 2026ZD330 Software Configuration: Verifying Cut-List Import Before PurchaseZD330 software and machine configuration: verify cut-list imports, data mapping, labels, and workflow before purchase to reduce errors and choose with confidence.Victor Lin (Chief Software Architect)























