
UAV Fleet Management for Mapping: Key Features for Multi-Site Survey Planning
Publication Date
author
UAV Fleet Management for Mapping: Key Features for Multi-Site Survey Planning
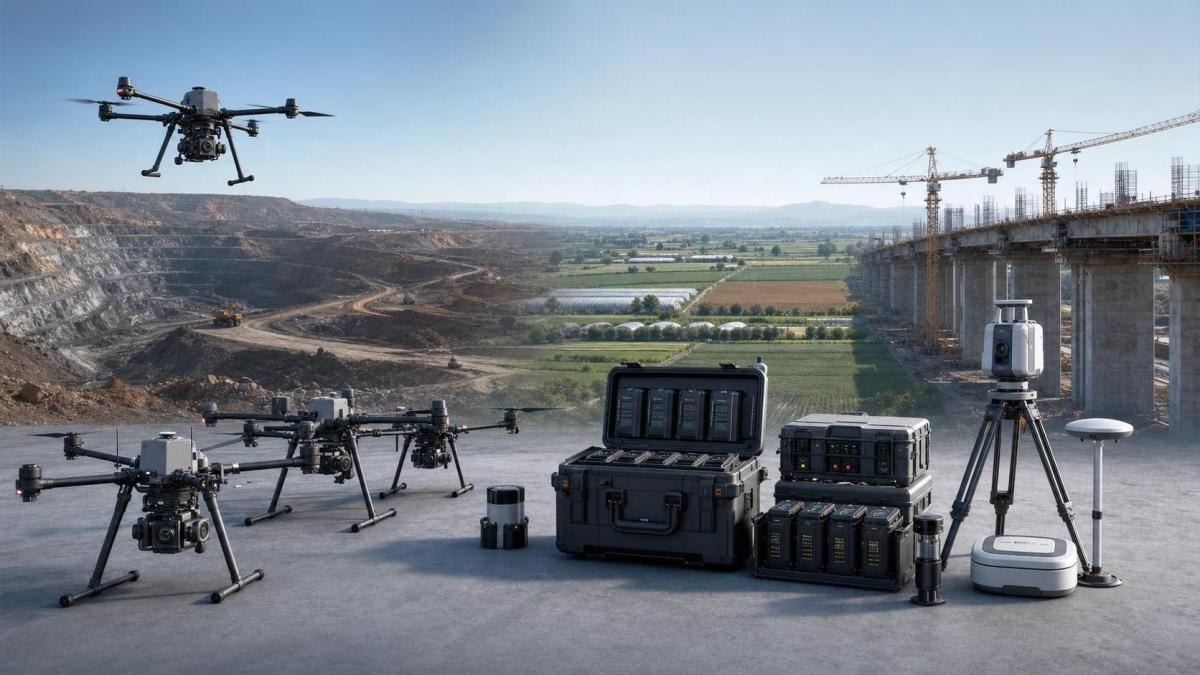
UAV fleet management for mapping is no longer just a flight scheduling task. It now sits at the center of survey quality, turnaround speed, and asset utilization.
When projects span several locations, small planning gaps become expensive fast. A missed battery cycle, uneven overlap rate, or weak terrain model can delay the whole program.
That is why UAV fleet management for mapping needs engineering discipline. It should control aircraft, crews, data standards, and site-specific constraints in one operational framework.
For organizations running corridor surveys, mines, construction sites, farmland, or infrastructure inspections, multi-site planning demands more than basic mission templates.
The most effective systems reduce field uncertainty before takeoff. They also make it easier to compare outputs across sites without reworking data later.
From a practical standpoint, the best approach is simple. Standardize what can be standardized, and adapt only where terrain, regulation, or deliverables require it.
Why Multi-Site Mapping Breaks Basic Flight Planning
Single-site workflows often hide operational weaknesses. Multi-site programs expose them immediately.
Each location may have different airspace rules, launch conditions, and elevation profiles. The same mission settings rarely deliver the same output quality everywhere.
Weather windows also shift by region. If the planning system cannot rebalance crews and aircraft quickly, utilization drops and deadlines start slipping.
More importantly, data inconsistency becomes a hidden cost. Orthomosaic accuracy, ground sampling distance, and point cloud density can drift between sites.
This is where UAV fleet management for mapping matters most. It gives planners a structured way to control repeatability across distributed operations.
Core Features That Matter Most
Not every feature in a fleet platform improves mapping results. For multi-site work, a smaller set of capabilities carries most of the operational value.
1. Centralized Mission Template Control
Mission templates should lock key survey parameters. That includes altitude, sidelap, frontlap, speed, camera angle, and trigger intervals.
With strong template control, teams can deploy consistent mapping logic across many sites. That reduces field interpretation and keeps outputs comparable.
2. Site-Aware Terrain and Airspace Planning
UAV fleet management for mapping should account for terrain variation before flights are assigned. Flat-ground assumptions fail in quarries, hills, and linear assets.
The platform should merge elevation data, no-fly zones, and local operating limits. That lets planners adjust altitude profiles without rebuilding every mission manually.
3. Aircraft, Payload, and Battery Matching
A mapping job is only as efficient as its equipment pairing. Large sites, dense vegetation, and required accuracy levels often need different sensors or aircraft classes.
Good fleet management software maps jobs to payload type, endurance profile, and battery health. This helps avoid underpowered deployments and unnecessary mobilization.
4. Resource Scheduling Across Crews and Sites
In real operations, conflicts usually come from people and logistics, not flight lines. Crews, chargers, transport windows, and spare units all compete for the same timeline.
The right UAV fleet management for mapping platform should expose these constraints early. That allows planners to sequence missions without creating downstream idle time.
Data Quality Controls That Protect Survey Value
Flight completion does not guarantee mapping success. The real benchmark is whether data meets processing and engineering requirements the first time.
This is where many field teams lose time. They complete missions, then discover coverage gaps or inconsistent image sets during stitching and modeling.
- Real-time overlap validation to detect weak capture zones before landing.
- Camera and sensor status checks to catch blur, angle drift, or trigger failures.
- Ground control point and checkpoint planning linked to each site specification.
- Automatic naming and metadata rules for traceable post-processing workflows.
- Pass-fail thresholds for image count, coverage percentage, and positional confidence.
These controls make UAV fleet management for mapping much more than dispatch software. They turn it into a quality gate for every site in the program.
What Good Multi-Site Planning Looks Like in Practice
A practical planning model usually follows a repeatable sequence. It balances standardization with local adjustment, which is exactly what complex survey programs need.
- Classify sites by terrain, deliverable type, risk level, and flight complexity.
- Assign approved mission templates to each site category.
- Match aircraft and payloads to expected accuracy and coverage demands.
- Sequence crews by travel efficiency, weather exposure, and battery turnaround.
- Review quality checkpoints before release to processing teams.
This structure keeps operations scalable. It also shortens the feedback loop between field teams, analysts, and project managers.
From recent industry changes, a clearer signal is emerging. Survey programs are being judged less by flight count and more by validated, usable output per deployment cycle.
Common Failure Points and How to Avoid Them
Even mature teams run into predictable issues when scaling UAV fleet management for mapping. The advantage is that most of them are preventable.
The pattern is consistent. Most failures start as planning blind spots, then show up later as data loss, downtime, or rework costs.
How to Evaluate a UAV Fleet Management for Mapping Solution
When comparing platforms, focus on measurable control points instead of broad feature claims. That aligns better with engineering-led procurement and field execution.
- Can it standardize missions across many sites without blocking local adjustments?
- Can it connect aircraft availability, battery health, and crew allocation in one schedule?
- Can it validate capture quality before the team leaves the field?
- Can it maintain traceable records for compliance, audits, and output comparison?
- Can it support scaling without creating manual coordination overhead?
A strong answer to these questions usually signals a mature UAV fleet management for mapping workflow. A weak answer often means more field friction later.
Final Takeaway
UAV fleet management for mapping works best when it connects planning, execution, and data acceptance as one system. That is the difference between flying missions and running a reliable survey operation.
For multi-site projects, the essential features are clear. Standardized templates, terrain-aware planning, resource visibility, and data quality checks should come first.
If the goal is faster delivery with fewer reflights, start by auditing where inconsistency enters the workflow. Then build UAV fleet management for mapping around those exact failure points.
That approach keeps operations practical, scalable, and far closer to engineering-grade truth than guesswork ever can.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 03, 2026Is Edge Computing Necessary for Real-Time Quality Inspection?Is industrial edge computing necessary for real-time quality inspection? Explore how latency, data volume, reliability, and control integration shape the right architecture.TSV Data Lab
 Oct 02, 2026What Documents Prove a Precision Machining Supplier Can Hold Tolerance?What documents prove a precision machining supplier can hold tolerance? Explore certificates, FAI reports, calibration, SPC, and traceability evidence to qualify suppliers with confidence.Dr. Marcus Vance
 Oct 01, 2026Can a Machining Supplier Meet Aerospace Fatigue Testing Requirements?Can a machining supplier meet aerospace fatigue testing requirements? Learn the traceability, process control, and test evidence needed for reliable aerospace parts.Dr. Marcus Vance
 Sep 30, 2026Which Industrial Robot Specifications Matter for High-Precision Assembly?Which industrial robot specifications matter most for high-precision assembly? Explore repeatability, accuracy, stiffness, vibration, calibration, and force control for reliable yields.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026How Do You Verify Servo Motor Torque Under Continuous Load?How do I verify servo motor torque under continuous load? Learn RMS torque checks, torque-speed limits, thermal derating, and real-machine testing.Chen Wei (Automation Lead Engineer)
 Oct 02, 2026ZD330 Software Configuration: Verifying Cut-List Import Before PurchaseZD330 software and machine configuration: verify cut-list imports, data mapping, labels, and workflow before purchase to reduce errors and choose with confidence.Victor Lin (Chief Software Architect)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab























