
How to Choose Material Handling Robot Solutions for Mixed SKU Warehouse Workflows
Publication Date
author
Mixed SKU warehouses rarely fail because automation is unavailable.
They fail when robot choices do not match slotting logic, order volatility, and data discipline.
That is why choosing material handling robot solutions now demands more than vendor demos or broad productivity claims.
The real decision sits at the intersection of workflow fit, software interoperability, payload realism, and operating resilience.
For operations handling diverse carton sizes, eaches, totes, returns, and replenishment moves, the wrong architecture creates friction everywhere.
The right one reduces touches, protects service levels, and keeps expansion options open.
Why mixed SKU environments change the selection logic
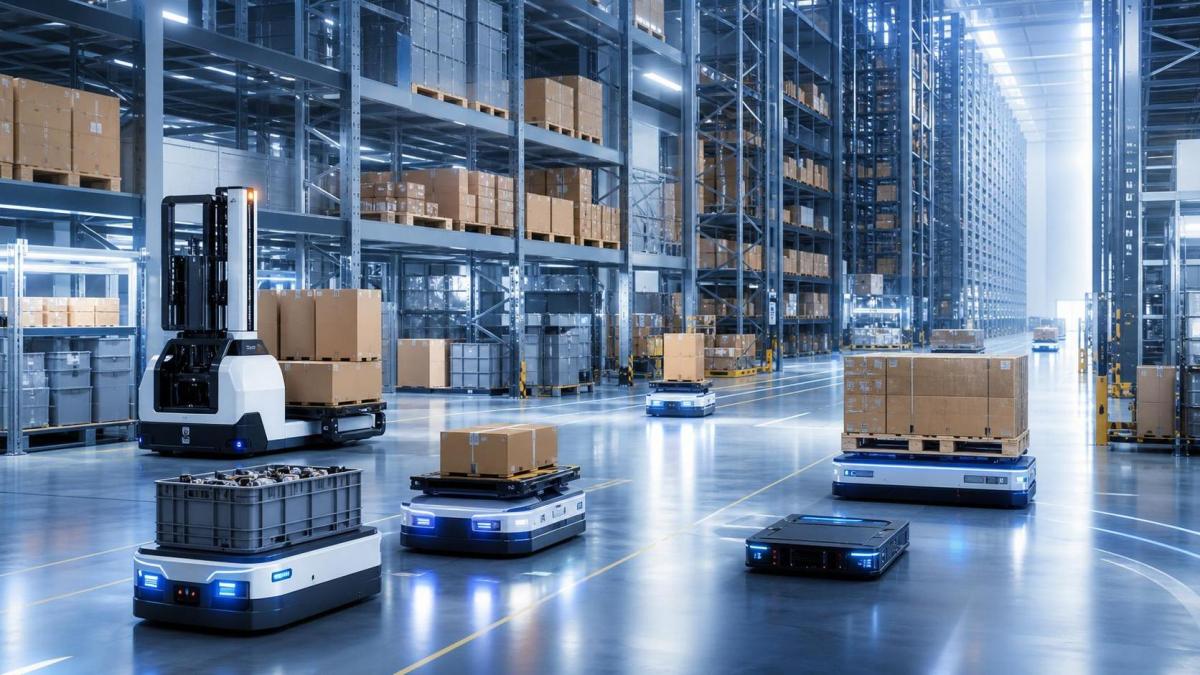
A high-mix warehouse behaves differently from a stable pallet-in, pallet-out facility.
Travel paths are less predictable.
Pick density shifts by hour, not by season alone.
Product dimensions also vary enough to expose weak assumptions in gripping, navigation, and queue logic.
In this context, material handling robot solutions must support changing order profiles without demanding constant re-engineering.
That includes exception handling, temporary congestion, damaged labels, and unplanned replenishment tasks.
From TechStat Vanguard’s perspective, this is where engineering truth matters.
Claims about flexibility mean little unless they are tied to measurable recovery rates, navigation fault tolerance, and sustained throughput under mixed loads.
Start with the workflow, not the robot category
Many projects begin by comparing AMRs, AGVs, robotic picking cells, shuttle links, or conveyor alternatives.
That is useful, but it is not the first filter.
The first filter is task structure.
A warehouse usually combines several movement types:
- inbound pallet transfer and decanting
- case movement between reserve and forward pick areas
- tote transport for goods-to-person workstations
- piece picking support for e-commerce or spare parts orders
- returns handling and re-slotting
Different tasks require different robot behaviors.
Some moves are repetitive and route-based.
Others need dynamic dispatching and frequent priority changes.
Effective material handling robot solutions often emerge as a workflow stack, not a single device decision.
That may mean AMRs for transport, robotic arms for induction or depalletizing, and software orchestration above both.
Questions that clarify workflow fit
- How many touches can be removed from each order line?
- Where do queues appear during peak release waves?
- Which exceptions still require manual intervention?
- What percentage of stock movement is predictable?
- How often do SKU dimensions change within a quarter?
The technical parameters that deserve real scrutiny
Marketing language usually compresses complex performance into a few polished metrics.
Mixed SKU operations need a more disciplined view.
At minimum, material handling robot solutions should be evaluated against actual operating thresholds, not nominal brochure values.
Navigation deserves special attention.
LiDAR-based autonomy, visual SLAM, magnetic guidance, and hybrid methods each have tradeoffs.
A clean pilot route is not enough.
The better test is how the system performs when pallets protrude, labels peel, or human traffic becomes dense.
Integration is often the decisive variable
Robot hardware usually gets the attention.
Software interoperability usually decides project success.
Material handling robot solutions must exchange reliable data with WMS, WES, ERP, and sometimes MES platforms.
Without that, robots only move uncertainty faster.
A practical integration review should cover order release logic, inventory synchronization, exception codes, API maturity, and latency during peak transactions.
It should also confirm who owns orchestration rules when priorities change mid-shift.
TSV’s hard-tech lens is useful here because vague software promises create the most expensive surprises.
Precise interface definitions, event timing, and fault escalation paths matter more than polished dashboard screenshots.
Signals of a mature integration stack
- documented APIs with clear event ownership
- standardized exception messaging
- version control for map and workflow changes
- sandbox testing before live deployment
- traceable performance logs for root-cause analysis
Choosing by scenario instead of headline capability
Not every warehouse needs the same mix of automation depth.
The stronger approach is to map material handling robot solutions to operating scenarios with measurable constraints.
This scenario view prevents a common error.
A robot can be technically impressive and still be operationally wrong.
Selection should reward fit under real warehouse variability, not feature volume.
What ROI really means in a mixed SKU warehouse
ROI should not be reduced to labor substitution.
That misses the broader economics of material handling robot solutions.
In high-mix operations, value also comes from shorter cycle times, lower mis-pick exposure, reduced training dependency, and better use of constrained floor space.
There is also strategic value in scalability.
A modular fleet that can absorb seasonal surges may outperform a rigid system with better nominal throughput.
The same logic applies to support models.
A solution with faster diagnostics, remote updates, and predictable spare access often delivers stronger lifecycle economics than a cheaper purchase price.
Useful ROI inputs
- order lines processed per labor hour before and after deployment
- exception rate per thousand moves
- fleet utilization during peak windows
- recovery time after stoppage or map disruption
- cost of change when new SKUs enter the network
A practical path to the next decision
A disciplined evaluation starts with a workflow baseline, not a brand shortlist.
Document current movement types, order profiles, congestion points, and exception frequencies.
Then translate those conditions into a measurable spec sheet.
That spec should define payload bands, navigation tolerance, software interfaces, uptime expectations, and fallback procedures.
From there, compare material handling robot solutions against the same operational test cases.
Ask for evidence under mixed SKU stress, not just ideal-path demonstrations.
In a market crowded by noise, TSV’s principle remains the most reliable filter: parameters do not lie.
When robot selection is grounded in measured workflow reality, automation becomes easier to scale, defend, and refine over time.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 03, 2026Is Edge Computing Necessary for Real-Time Quality Inspection?Is industrial edge computing necessary for real-time quality inspection? Explore how latency, data volume, reliability, and control integration shape the right architecture.TSV Data Lab
 Oct 02, 2026What Documents Prove a Precision Machining Supplier Can Hold Tolerance?What documents prove a precision machining supplier can hold tolerance? Explore certificates, FAI reports, calibration, SPC, and traceability evidence to qualify suppliers with confidence.Dr. Marcus Vance
 Oct 01, 2026Can a Machining Supplier Meet Aerospace Fatigue Testing Requirements?Can a machining supplier meet aerospace fatigue testing requirements? Learn the traceability, process control, and test evidence needed for reliable aerospace parts.Dr. Marcus Vance
 Sep 30, 2026Which Industrial Robot Specifications Matter for High-Precision Assembly?Which industrial robot specifications matter most for high-precision assembly? Explore repeatability, accuracy, stiffness, vibration, calibration, and force control for reliable yields.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026How Do You Verify Servo Motor Torque Under Continuous Load?How do I verify servo motor torque under continuous load? Learn RMS torque checks, torque-speed limits, thermal derating, and real-machine testing.Chen Wei (Automation Lead Engineer)
 Oct 02, 2026ZD330 Software Configuration: Verifying Cut-List Import Before PurchaseZD330 software and machine configuration: verify cut-list imports, data mapping, labels, and workflow before purchase to reduce errors and choose with confidence.Victor Lin (Chief Software Architect)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab























