Choosing an Edge AI Box for Robotics: Compute, Latency and I/O
Publication Date
author
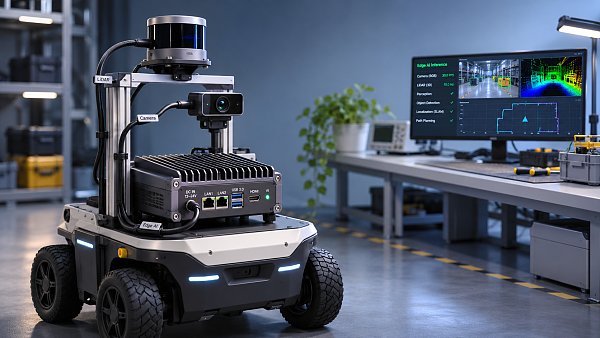
Select an edge AI box for robotics by testing the complete workload against the robot’s timing and interface requirements. A suitable box must sustain sensor ingestion, inference, data exchange and any local planning tasks while meeting the latency limit under the intended power and thermal conditions. A high advertised AI throughput figure is useful for narrowing candidates, but it cannot establish that a robot will react in time.
Start with the most demanding operating mode: identify the sensors active together, the models and other processes that run concurrently, and the maximum acceptable age of the information used by the controller. Compare candidates using the same input data, model precision and measurement boundaries. The resulting latency distribution, dropped-frame rate and sustained resource use provide a stronger basis for selection than peak throughput alone.
Define the workload before sizing compute
A robotics workload is a pipeline. Camera frames or point clouds arrive through physical interfaces, are decoded and transformed, pass through inference or other perception algorithms, and then become messages consumed by localization, planning or control software. CPU cores handle scheduling, middleware and preprocessing; an accelerator executes supported model operations; memory carries data between stages. Storage and networking can compete for the same internal bandwidth.
List each workload with its input rate, input size, model version and required output rate. Include concurrent services such as localization, mapping, recording and remote diagnostics. A detector that runs comfortably in isolation may miss its deadline when camera decoding and a mapping process share memory bandwidth or CPU time. Test the exact combination expected during the robot’s most demanding maneuver.
Separate average demand from bursts. A mobile robot might process a steady camera stream while receiving a larger point cloud, writing a diagnostic log and updating a map. Even when average utilization appears modest, simultaneous bursts can create queues. If the workload has distinct modes, measure each mode and the transition between them; startup or model loading can briefly compete with live perception.
Headroom should be based on observed variation and planned changes, such as an additional sensor or a larger model. Reserve enough capacity for those changes to remain within the measured deadline, then verify the reserve with the actual workload. An arbitrary utilization target on its own does not prove that critical tasks will remain responsive.
Read accelerator specifications in context
Advertised operations per second describe throughput under a specified calculation type and test condition. Figures based on different numerical precision, sparsity assumptions or batch sizes are not directly comparable. They also say little about preprocessing, unsupported operators or the time required to move tensors between memory and the accelerator.
For each candidate, establish whether the deployed model runs at its intended precision and input resolution, with the required accuracy. Quantization can improve speed and reduce memory use, but its effect must be measured on representative images and environmental conditions. A model that becomes faster while losing detection reliability for small or poorly lit objects has changed the system tradeoff.
Inspect the compiled execution graph as well as the headline inference time. If an unsupported operator falls back to the CPU, repeated transfers between CPU and accelerator can dominate latency. The same issue can appear when a model is divided across engines. A short accelerator-only benchmark will conceal that overhead.
Batching also changes the result. Large batches can improve aggregate throughput, but waiting for frames to fill a batch adds delay. For a single robot reacting to a live scene, measure the batch size and scheduling policy that will actually be deployed. For several cameras, record per-stream latency and fairness: a good combined frame rate can hide one delayed stream.
Measure latency from observation to usable output
Define the timing boundary before comparing boxes. Inference latency may begin after an image is already captured, transferred, decoded and resized. The robot acts on the total age of the observation when the output reaches the consuming process. For a motion-related decision, that age can include sensor exposure, transport, queuing, preprocessing, inference, postprocessing and message delivery.
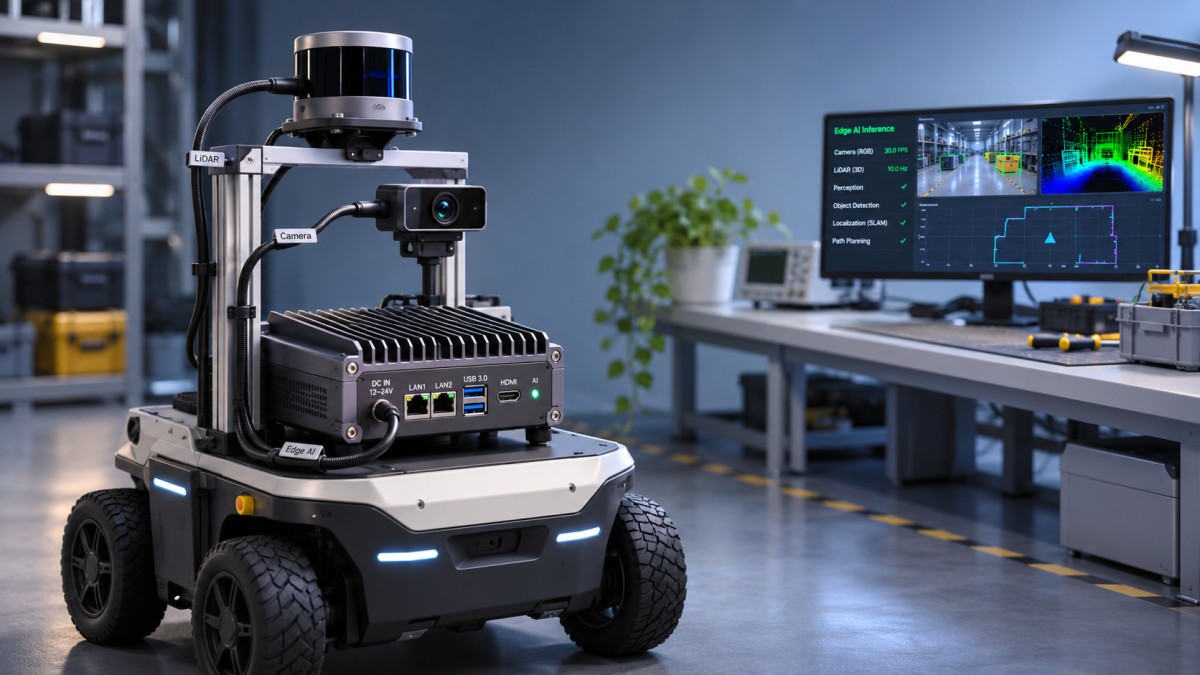
Timestamp at meaningful boundaries, starting as close to sensor acquisition as the hardware permits and ending where the result is consumed. Document whether timestamps represent the start or end of exposure, packet arrival or application delivery. When timestamps come from separate devices, synchronize their clocks or measure on a common clock; otherwise, clock offset and drift can be mistaken for processing delay.
Report a latency distribution and maximum observed value alongside the median. Tail latency matters when occasional late results are enough to interrupt a maneuver. Record the duration of the run, workload and number of observations so that the reported tail has context. An observed maximum is evidence from that test, not a guaranteed upper bound.
Also measure data age and dropped or replaced frames. A pipeline can report fast processing while consuming old frames from a growing queue. Conversely, a system configured to discard stale frames may keep latency bounded while reducing the number of observations. Choose the queue policy according to the task: live obstacle response often values fresh data, whereas a recording or inspection task may require every frame.
Keep hard real-time control requirements separate from ordinary application latency. A general-purpose operating system and an AI accelerator do not automatically provide deterministic timing. If a control loop has a strict deadline, establish its scheduling, communication path and failure behavior independently; a dedicated controller may be needed. The AI box’s role and the response to a missed perception update must be explicit.
Match I/O capacity to simultaneous sensor traffic
Count physical ports, but also map their internal connections. Multiple connectors can share a controller or an upstream link, and a network adapter, storage device and accelerator may compete for internal bandwidth. The interface name alone does not reveal how much capacity remains when all devices are active.
Estimate raw traffic before compression or protocol overhead. For example, an uncompressed image stream requires its width multiplied by height, bytes per pixel and frames per second. Multiply by the number of cameras, then account for line padding, metadata and transport overhead where applicable. Compression reduces link traffic at the cost of encoding, decoding or image changes; include those operations in the latency and compute measurements.
Synchronization deserves its own test. Multi-camera geometry and sensor fusion rely on knowing when observations were captured, not merely when packets reached the box. Establish whether the sensors and host support the required hardware trigger or clock synchronization arrangement, and measure alignment under load. Software timestamps at receipt can vary with network and operating-system scheduling.
Sustained performance inside the robot
A short benchmark on an open bench can select the wrong box. Installed performance depends on enclosure temperature, airflow, mounting orientation, heat transfer through the chassis and nearby heat sources. Run the full workload long enough for temperatures and clock rates to stabilize in the intended installation, including any protective enclosure and filters.
Record ambient temperature, processor and accelerator temperatures where available, clock behavior, power draw, latency and dropped frames over the same period. A gradual increase in latency accompanied by reduced clocks suggests a thermal or power limit; a latency spike without a clock change may instead point to scheduling, memory contention or I/O. Correlating these signals prevents treating every slowdown as insufficient accelerator capacity.
Evaluate power at the system boundary. Peak load, startup and attached peripherals matter as well as steady-state consumption. On a battery-powered robot, the compute box shares a finite energy budget with drives, sensors and communications. Confirm the permitted input-voltage range and behavior during the supply variations expected in the installation. A clean shutdown or recovery strategy matters where power can be interrupted.
Mechanical fit is part of the interface decision. Verify cable bend space, connector retention, access for service and the mounting method used for vibration isolation or heat transfer. A box that reaches its thermal limits only after installation is not equivalent to the same box on a bench.
Compare candidates with a repeatable acceptance run
Use a representative recorded dataset to compare model outputs and repeatable compute performance, then run live sensors to expose transport, synchronization and electrical issues that replay can miss. Keep model files, input resolution, software versions, power settings and background tasks consistent. Where hardware requires different implementations, document those differences and compare the resulting accuracy as well as speed.
A useful acceptance record states the operating mode, sensor configuration, test duration, ambient and enclosure conditions, latency boundaries, frame losses and resource use. Include both normal operation and relevant disturbances: network congestion, temporary sensor disconnects, storage saturation or a restart during workload activity. The required response to each disturbance should be defined before the test, so that a recovered connection is not mistaken for a valid recovery if the application continues using stale data.
Software support can determine whether a technically capable box remains deployable. Confirm compatibility among the operating system, accelerator runtime, sensor drivers and robotics middleware, including the specific versions used in the test. Verify that the model can be rebuilt and deployed after updates, and that monitoring exposes the temperatures, utilization and fault signals needed to diagnose field behavior.
Choose the candidate that meets the stated deadlines and accuracy requirements throughout the representative run, with enough measured reserve for the intended configuration. If none meets them, change a documented constraint—such as model resolution, sensor rate, task placement or cooling—and repeat the comparison using the revised workload.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Nov 19, 2026Choosing a Palletizing System for Bagged Food: Speed and Bag HandlingChoose the right palletizing system for bagged food. Compare throughput, bag handling, food safety, and robotic vs. conventional options.Chen Wei (Automation Lead Engineer)
 Nov 18, 2026Formnext 2026 Opens as Additive Manufacturing Advances Industrial ApplicationsFormnext 2026 highlights additive manufacturing innovations for industrial applications. Explore what they could mean for production, procurement and suppliers.Dr. Marcus Vance
 Nov 18, 2026Flexible Robotics Integration for High-Mix, Low-Volume ProductionFlexible robotics integration can make high-mix, low-volume production more adaptable. Explore practical ways to reduce changeover risk and plan a reliable robotic cell.Victor Lin (Chief Software Architect)
 Nov 17, 2026Formnext 2026: UK Additive Manufacturing Leads in Research but Faces Production BarriersUK additive manufacturing leads in research but faces barriers to production at scale. Explore the Formnext 2026 insights and what businesses should consider.Dr. Marcus Vance
 Nov 17, 2026Choosing Warehouse Automation Packaging Systems: Throughput and SpaceCompare warehouse automation packaging systems by throughput, footprint, and order mix. Discover how to choose a layout that meets peak demand.Victor Lin (Chief Software Architect)
 Nov 16, 2026China's October Industrial Robot Output Up 26%, 3D Printing Equipment Up 85.9%China's industrial robot output reportedly rose 26% in October, while 3D printing equipment grew 85.9%. Explore what the figures could mean for buyers.Chen Wei (Automation Lead Engineer)
 Nov 16, 2026Commercial Drones in North America: Choosing Payloads for Inspection and MappingCommercial drones North America: compare RGB, thermal and LiDAR payloads for inspection and mapping, and choose a system that delivers reliable data.Elena Rostova (UAV Systems Researcher)
 Nov 15, 2026Aerospace Materials in the UK: Choosing Metals and Composites for AircraftExplore aerospace materials UK teams use for aircraft. Compare metals and composites by weight, fatigue, manufacturing and approval needs to make informed choices.Dr. Marcus Vance
 Nov 14, 2026Ukraine Tests 3D-Printed Protective Structure Against M2 Heavy Machine-Gun FireUkraine’s 3D-printed protective structure reportedly resisted M2 heavy machine-gun fire. Explore the test’s limits and potential procurement implications.Dr. Marcus Vance
 Nov 14, 2026Rugged UAV Metrics: Assessing Wind Resistance, Endurance and IP RatingsCompare rugged UAV metrics for wind resistance, endurance and IP ratings. Learn what evidence to request and choose a platform fit for your mission.Chen Wei (Automation Lead Engineer)
 Nov 13, 2026Physical AI Gains Attention as Robot Investment Moves Beyond HardwarePhysical AI is reshaping robot investment beyond hardware. Explore what the shift toward perception and algorithms could mean for buyers and suppliers.Chen Wei (Automation Lead Engineer)
 Nov 13, 2026Precision Machining Benchmarks: A Guide to Tolerances and Surface FinishExplore this precision machining benchmarks guide to compare tolerances, surface finish, and inspection methods—and specify parts with confidence.Dr. Marcus Vance
 Nov 12, 2026Beijing Issues Three-Year Plan for Embodied AI Robotics IndustryBeijing’s embodied AI robotics plan targets leading humanoid robot makers by 2028. Explore its goals for supply chains, AI models and deployment.Chen Wei (Automation Lead Engineer)
 Nov 12, 2026Choosing an Edge AI Box for Robotics: Compute, Latency and I/OChoose the right edge AI box for robotics with practical guidance on compute, latency, sensor I/O and sustained performance. Explore the selection checklist.Chen Wei (Automation Lead Engineer)
 Nov 11, 2026Beijing Sets 200,000-Unit Annual Capacity Goal in Robotics PlanBeijing's robotics plan targets 200,000 units of annual capacity by 2027. Explore its technology goals, benchmark applications and adoption outlook.Chen Wei (Automation Lead Engineer)
 Nov 11, 2026Aero Engine Blade Machining: 5-Axis CNC Methods and ChallengesExplore aero engine blade machining, from 5-axis toolpaths to thin-wall challenges, surface integrity, and inspection. Learn what makes a process reliable.Dr. Marcus Vance
 Nov 10, 2026FAA Authorizes Skyways’ Long-Distance BVLOS Flights for Shell in Gulf of MexicoFAA authorizes Skyways’ long-distance BVLOS drone flights for Shell in the Gulf of Mexico. Discover what the decision means for offshore pipeline inspection.Elena Rostova (UAV Systems Researcher)