
UAV Thermal Inspection for Solar Panels With Fewer False Hotspots
Publication Date
author
UAV thermal inspection solar panels workflows often promise fast fault detection, yet real field conditions make accuracy harder than the marketing suggests. Reflections, changing irradiance, module mismatch, dust, camera angle, altitude, and poor emissivity assumptions can all create false hotspots that look urgent but are not true failures. In utility-scale and commercial solar operations, cleaner thermal evidence matters because every false callout can trigger extra site visits, unnecessary panel replacement, and distorted performance reporting. A more disciplined UAV thermal inspection solar panels process helps convert imagery into trustworthy maintenance actions, which is exactly the kind of engineering-first approach that data-focused operations now require.
When UAV Thermal Inspection Solar Panels Projects Need Different Rules
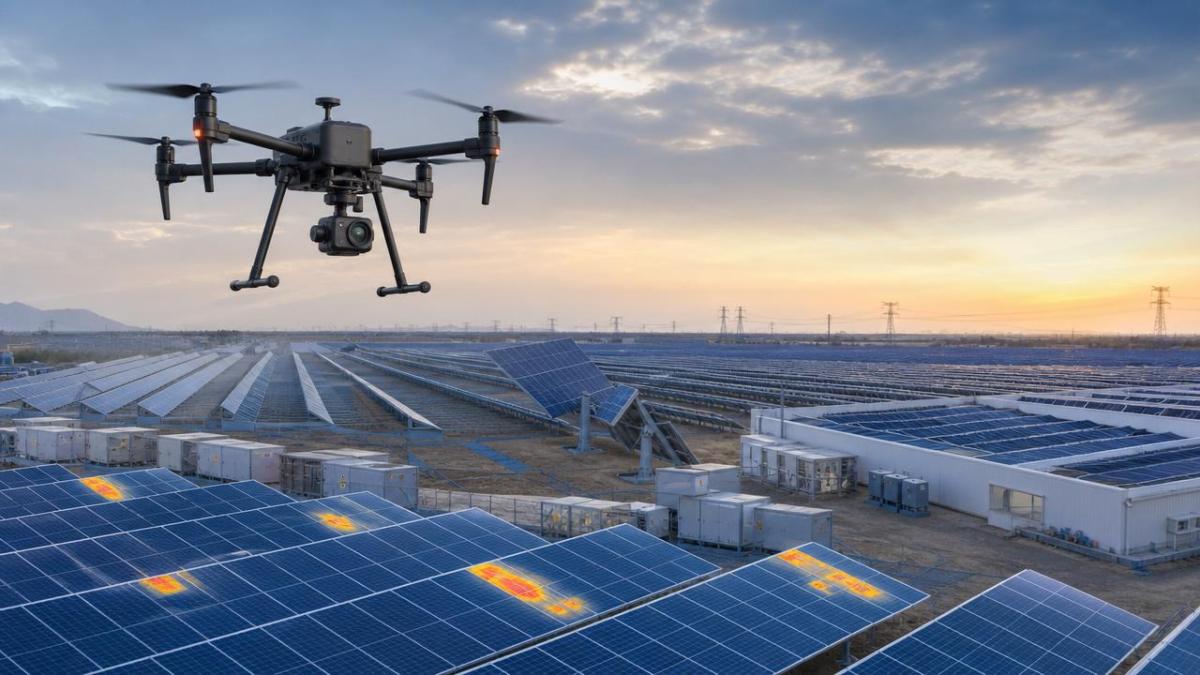
Not every site should be inspected the same way. A 5 MW ground-mount array in a dry inland climate behaves differently from a rooftop system near a coast, and a tracker-based plant introduces motion, angle variation, and reflection patterns that fixed-tilt systems do not. The value of UAV thermal inspection solar panels work increases when teams first identify the operating context: asset scale, module technology, environmental volatility, and the consequence of missing a defect versus over-reporting one.
This background step is more than planning. It changes flight timing, thermal camera settings, acceptable temperature delta thresholds, and the way anomalies are validated. In high-value energy portfolios, the goal is not to produce the most colorful thermographic map. The goal is to reduce uncertainty, isolate repeatable evidence, and separate thermal signatures caused by actual electrical or mechanical faults from signatures caused by surface artifacts or transient weather effects.
Scenario 1: Utility-Scale Solar Farms Where False Hotspots Multiply Fast
In large ground-mount assets, the biggest challenge in UAV thermal inspection solar panels workflows is scale. Thousands of modules may be scanned in one session, so even a small false-positive rate can generate a large maintenance burden. Here, core judgment points include stable irradiance during flight, consistent module loading, and enough thermal resolution to distinguish cell-level anomalies from broad warming caused by dirt, vegetation shading, or string imbalance.
For this scenario, repeatability matters more than visual drama. A hotspot that appears on one flight but disappears on a validation pass under similar irradiance is often a weak signal. Stronger evidence comes from anomalies that persist across sequential captures, correlate with electrical underperformance, or map to known failure modes such as bypass diode issues, cracked cells, connector heating, or localized soiling. In utility-scale UAV thermal inspection solar panels programs, reducing false hotspots often starts with stricter anomaly classification instead of lower sensitivity alone.
Key judgment points for large-field inspections
- Use narrow weather windows with stable irradiance and low cloud variability.
- Keep flight altitude low enough to preserve thermal detail but high enough for efficient coverage.
- Compare thermal anomalies with visible imagery to rule out mud, debris, and shadow edges.
- Apply consistent temperature delta criteria by module type and operating load.
- Flag only anomalies with repeatable geometry or electrical correlation for priority action.
Scenario 2: Commercial Rooftops Where Reflections Distort UAV Thermal Inspection Solar Panels Results
Rooftop solar introduces a different error profile. HVAC exhaust, parapet shadows, skylight reflections, varying roof membrane temperatures, and nearby metallic structures can all contaminate thermal readings. In this environment, UAV thermal inspection solar panels missions should focus on angle control, thermal context, and visible-light confirmation. What appears to be a hotspot may be a reflected heat source or a roof-level thermal plume rather than a defective module.
The best field practice is to avoid aggressive interpretation from a single perspective. Oblique imagery may reveal reflections that nadir views conceal, while a second pass at a slightly altered time or angle can expose whether the anomaly is fixed to the panel surface or drifting with environmental conditions. Rooftop UAV thermal inspection solar panels work benefits from slower flights, smaller mission blocks, and extra manual review because the background thermal complexity is higher than in open-field assets.
Scenario 3: Tracker-Based Plants Where Moving Geometry Changes Hotspot Interpretation
Single-axis tracker plants can improve generation but complicate thermal interpretation. Module angle changes throughout the day affect solar loading, reflection behavior, and apparent temperature patterns. If tracker position varies across rows due to control logic, maintenance mode, or temporary faults, UAV thermal inspection solar panels data can become inconsistent even within the same site.
In this scenario, inspections work best when tracker state is documented and, where possible, normalized. Consistent row orientation during the flight window reduces false contrasts between sections. It is also useful to record wind speed and gust behavior, since convective cooling can alter hotspot visibility. A reliable tracker-plant workflow links thermal anomalies to row position, tracker angle, and electrical segment data so that temperature differences are not interpreted in isolation.
How Scenario Demands Differ in UAV Thermal Inspection Solar Panels Programs
Practical Adaptation Steps That Reduce False Hotspots
Across sectors, better UAV thermal inspection solar panels accuracy usually comes from a small set of operational controls applied consistently. The first is flight timing. Thermal inspections are most useful when arrays are under meaningful load and irradiance is sufficiently stable. The second is camera discipline: calibrated sensors, verified focus, and capture settings matched to expected temperature ranges. The third is data fusion. Thermal images alone can suggest problems, but thermal plus RGB, site layout, inverter data, and maintenance history create a stronger diagnostic chain.
- Define acceptable weather windows before launch, including irradiance stability, wind limits, and cloud cover criteria.
- Standardize altitude, overlap, angle, and speed so results can be compared across inspections.
- Use anomaly categories such as likely fault, probable artifact, and monitor-on-next-pass.
- Validate high-severity findings with electrical tests or close-range confirmation before replacement.
- Track false-positive patterns by site, season, and module type to improve future thresholds.
This is where a data-centric methodology adds value. Teams that benchmark repeated thermal outcomes, compare defect classes against actual field repairs, and quantify how many alerts become confirmed failures can progressively improve the precision of UAV thermal inspection solar panels programs. The process becomes less subjective and more like engineering verification.
Common Misjudgments That Undermine UAV Thermal Inspection Solar Panels Accuracy
Several mistakes appear repeatedly. One is assuming every localized warm area is a defect. Another is using a single absolute temperature threshold across all module technologies and weather conditions. A third is overlooking the impact of emissivity assumptions, especially when panel surfaces are dirty, aged, or partly reflective. There is also a tendency to trust automated hotspot detection without reviewing context. Automation is useful, but if the model was trained on cleaner field conditions than the current site presents, false hotspots will rise.
Another ignored point is maintenance timing. If cleaning, vegetation control, or recent weather events changed site conditions, the thermal map may reflect short-term operational noise. UAV thermal inspection solar panels reports should state inspection conditions clearly: irradiance band, ambient temperature, wind, module orientation, and confidence level. Without this metadata, it is difficult to compare inspections or defend maintenance decisions later.
Next-Step Actions for Cleaner Thermal Decisions
A stronger UAV thermal inspection solar panels workflow begins with a site-specific inspection standard rather than a generic mission template. Define scenario-based thresholds, require RGB and thermal cross-checking, and separate preliminary anomaly detection from final maintenance recommendation. Build a review loop in which confirmed field outcomes are fed back into the inspection criteria. Over time, this reduces false hotspots, sharpens defect classification, and improves the economic value of every flight.
For organizations that prioritize engineering truth over surface-level reporting, the advantage is clear: fewer unnecessary interventions, better fault isolation, and a more credible performance picture across solar assets. In practice, the best UAV thermal inspection solar panels results do not come from seeing more heat. They come from understanding which heat signatures actually matter, under which scenario, and with what level of proof before action is taken.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026How Do You Verify Servo Motor Torque Under Continuous Load?How do I verify servo motor torque under continuous load? Learn RMS torque checks, torque-speed limits, thermal derating, and real-machine testing.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 29, 2026How MES and OEE work together to identify production lossesMES and OEE work together to uncover hidden production losses, connect downtime, speed, and quality data, and drive smarter shop-floor improvements.Victor Lin (Chief Software Architect)
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab























