
Defect Detection Systems Miss Good Parts Too—Here’s Why
Publication Date
author
Even advanced machine vision defect detection systems reject conforming parts. That problem is not minor noise. It affects yield, throughput, supplier alignment, and confidence in automated quality data.
False rejects often hide inside otherwise strong inspection programs. A line may appear controlled, while good parts are quietly diverted, reworked, or scrapped without a true defect.
For operations relying on machine vision defect detection systems, the real question is not only detection accuracy. It is whether the inspection logic matches process reality, part variation, and measurable engineering limits.
Why a structured review matters before adjusting inspection thresholds
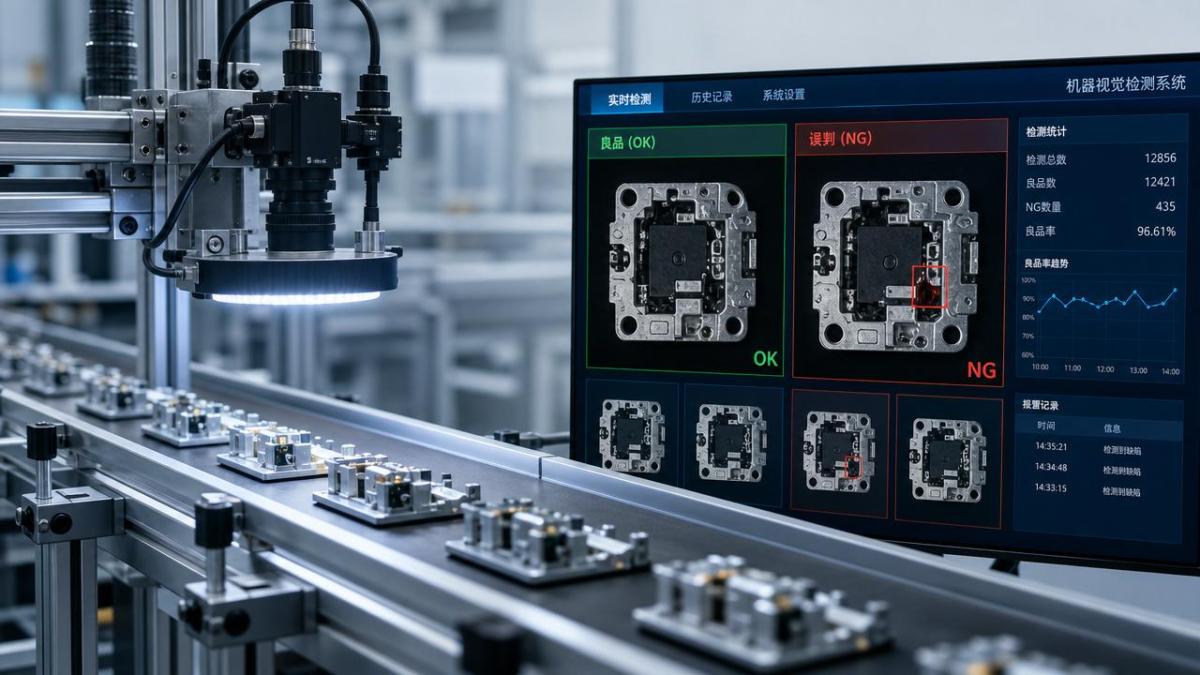
Many teams respond to false rejects by widening tolerances inside software. That can reduce nuisance alarms, but it may also increase escape risk and weaken traceable quality control.
A structured review helps separate optical noise from true product variation. It also reveals whether machine vision defect detection systems are failing because of setup, data, fixturing, or process drift.
This matters across sectors. Electronics, aerospace, machining, medical devices, packaging, and automotive lines all depend on stable inspection decisions tied to actual specifications.
Core checks for machine vision defect detection systems that reject good parts
Use the following checks in sequence. Each one addresses a common root cause behind false rejects in machine vision defect detection systems.
- Verify the golden sample set includes real acceptable variation, not only ideal parts made under unusually clean or tightly controlled conditions.
- Confirm lighting stability across shifts, because small changes in angle, intensity, glare, or color temperature can alter edge contrast and feature recognition.
- Check lens selection and focus depth against part geometry, especially where curved, reflective, textured, or low-contrast surfaces create inconsistent image data.
- Review fixture repeatability, since part tilt, rotation, vibration, or positional drift can trigger apparent defects that are actually presentation errors.
- Compare software thresholds with print tolerances and functional limits, ensuring pixel-based rules reflect engineering intent rather than arbitrary sensitivity settings.
- Audit annotation quality in training data, because mislabeled borderline samples teach AI-based inspection tools to confuse cosmetic variation with defects.
- Measure image timing relative to conveyor motion or robot handling, since motion blur and inconsistent triggering often mimic scratches, chips, or incomplete features.
- Validate environmental conditions, including dust, temperature, humidity, and vibration, which can gradually reduce optical clarity and system repeatability.
- Check whether upstream process changes altered surface finish, coatings, material lot appearance, or tool marks beyond what the vision model expects.
- Trend false reject patterns by cavity, tool, shift, supplier, and station to isolate whether the issue belongs to the system or the process.
1) Golden samples are often too perfect
Many machine vision defect detection systems are tuned against ideal reference parts. Real production contains normal texture, slight color shifts, and harmless edge variation.
If acceptable diversity is missing from the reference set, the system treats ordinary manufacturing signatures as anomalies. That pushes false rejects upward immediately.
2) Lighting changes create artificial defects
Lighting is not a background detail. It is one of the primary measurement conditions inside machine vision defect detection systems.
Slight lamp aging, contamination on covers, or a changed mounting angle can make a clean surface appear scratched, dented, or dimensionally inconsistent.
3) Pixel accuracy is not specification accuracy
Inspection software may detect extremely small deviations. That does not mean those deviations matter functionally or violate drawing intent.
The best machine vision defect detection systems are calibrated to engineering relevance. They should distinguish measurable variation from unacceptable failure modes.
How false rejects appear in different production environments
Precision machining and metal components
Tool wear, coolant residue, and directional surface finish often confuse machine vision defect detection systems. Reflective metals are especially sensitive to angle and illumination changes.
A useful check is to compare rejected parts against contact metrology or profilometry. That confirms whether the vision result matches a physical out-of-spec condition.
Electronics and PCB inspection
Board color variation, solder reflectivity, and component shadowing commonly produce unstable results. Fine-pitch features increase sensitivity to camera alignment and focus limits.
Here, machine vision defect detection systems should be reviewed alongside placement accuracy, reflow consistency, and board support stability during imaging.
Packaging, labels, and printed materials
Wrinkles, gloss changes, ink density shifts, and curved surfaces can trigger false alarms. Fast web speeds also increase the risk of motion-related image distortion.
For these applications, machine vision defect detection systems need robust trigger timing and acceptance logic that reflects branding and regulatory priorities separately.
Aerospace, medical, and other traceable sectors
False rejects are particularly expensive in high-traceability sectors. Every disputed result can trigger extra documentation, containment actions, and delayed release decisions.
In these environments, machine vision defect detection systems should be tied to validated acceptance criteria, revision control, and evidence-backed benchmarking.
Commonly missed risk factors
Algorithm drift is often overlooked. Software updates, retraining cycles, or parameter edits can change reject behavior without immediate visibility.
Mixed part families are another risk. Machine vision defect detection systems may inherit settings from similar products that differ in texture, tolerance, or geometry.
Teams also miss presentation effects from upstream automation. A robot gripper change or conveyor guide adjustment can alter imaging more than expected.
Finally, disputed rejects are not always fed back into model improvement. Without closed-loop review, the same good parts keep failing for the same reason.
Practical steps to reduce false rejects without increasing escapes
- Build a controlled sample library containing accepted variation, true defects, borderline cases, and verified metrology references.
- Run a false reject Pareto by defect code, product type, shift, and station before changing thresholds.
- Lock optical conditions where possible, including lighting angle, camera position, exposure, and fixture location.
- Tie inspection rules to drawings, functional criteria, and customer-approved acceptance standards.
- Use a secondary verification path for disputed parts until machine vision defect detection systems show stable repeatability.
- Revalidate after process changes, material substitutions, tooling updates, or software revisions.
This approach supports the TSV view that parameters matter more than marketing claims. Inspection credibility depends on traceable conditions, not broad promises of intelligence.
Conclusion and next actions
When machine vision defect detection systems miss good parts, the issue is rarely one setting alone. It is usually a chain of optical, mechanical, data, and specification factors.
A disciplined review can cut false rejects without weakening defect containment. Start with sample quality, lighting control, fixture repeatability, and threshold relevance.
Then compare inspection outcomes against engineering truth. That is how automated quality moves from noisy screening toward dependable, decision-grade manufacturing intelligence.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)
 Sep 19, 2026How to Scope Automation Integration Services for Multi-System Factory ProjectsAutomation integration services: learn how to scope multi-system factory projects with clear workflows, interface contracts, safety boundaries, and acceptance criteria.Victor Lin (Chief Software Architect)























