
How solid-state LiDAR handles glare on autonomous vehicles
Publication Date
author
For technical evaluators, glare is not a minor edge case—it is a decisive failure mode in perception reliability. This article examines how solid-state LiDAR for autonomous vehicles mitigates sunlight saturation, reflective interference, and false returns through sensor architecture, signal processing, and validation metrics, helping engineering teams assess real-world robustness with data rather than marketing claims.
Why glare resistance has moved from a feature claim to a market filter
The evaluation standard for perception hardware is changing. A few years ago, many autonomous driving programs focused on range, angular resolution, frame rate, and cost per unit. Those metrics still matter, but the conversation has shifted. As pilot deployments move from controlled demonstrations toward commercial operation, engineering teams are paying closer attention to failure behavior under harsh optical conditions. In practice, the most damaging perception failures often do not come from average scenes. They come from low sun angles, wet roads, reflective truck panels, tunnel exits, urban glass facades, and multipath reflections that trigger unstable detection confidence.
This is why solid-state LiDAR for autonomous vehicles is under sharper scrutiny. Buyers are no longer satisfied with lab-perfect point clouds. They want evidence that the sensor remains usable when sunlight directly enters the receiver, when the target has high reflectivity, or when environmental clutter produces competing optical energy. In other words, glare handling has become a selection criterion, not a secondary specification.
For firms like TechStat Vanguard, this shift reflects a broader industry correction: technical procurement is moving away from headline claims and back toward engineering fundamentals. The relevant question is no longer “Does the LiDAR look good in a demo?” but “How does the system degrade, recover, and maintain discrimination under optical stress?”
The trend signals behind stricter glare evaluation
Several signals explain why glare testing now receives more attention in autonomous vehicle programs. First, sensor stacks are being asked to support longer operating windows across geography and season. Morning and late afternoon driving produce challenging sun positions, while logistics fleets and robotaxis cannot simply avoid these periods. Second, vehicle design trends add complexity: larger glass areas, more polished surfaces, and dense urban operating domains increase reflective interference. Third, safety cases are becoming more evidence-based. Validation teams must prove robustness in corner cases, not just average performance.
These trends are especially important for technical evaluators because they change what counts as proof. A single “anti-sunlight” statement is weak evidence. A structured dataset showing detection probability, false positive rate, point cloud stability, and recovery time after direct glare exposure is much stronger. That difference is where many sourcing decisions are now made.
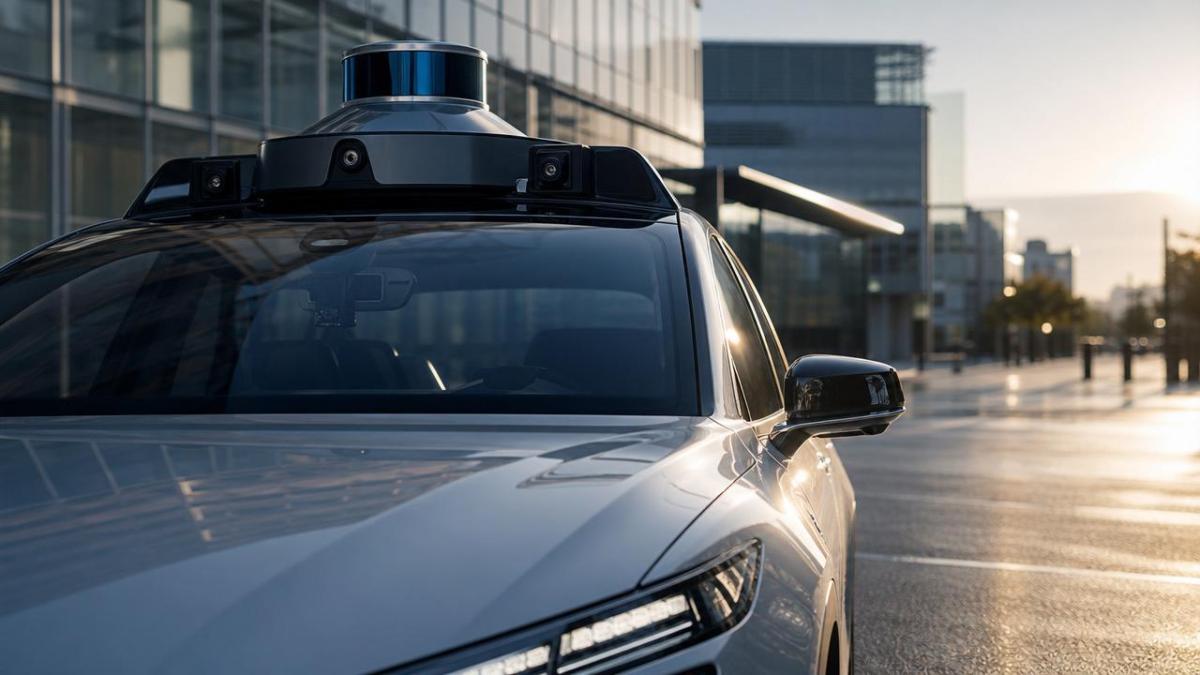
How solid-state LiDAR for autonomous vehicles handles glare at the architecture level
Not all glare mitigation begins in software. A large part of performance is determined by architecture. Solid-state LiDAR for autonomous vehicles typically improves glare robustness through tighter optical control, reduced moving-part dependency, and more disciplined signal acquisition paths. The exact implementation varies by technology family, whether MEMS-based, flash, or optical phased array, but the anti-glare logic follows similar engineering principles.
One key factor is field-of-view management. A receiver that limits unnecessary acceptance of off-axis light reduces the amount of solar energy and reflected noise entering the detection chain. Optical filters also matter. Narrowband filtering around the laser wavelength helps reject broad-spectrum sunlight before it overwhelms the photodetector. Detector dynamic range is another major lever. If the receiver saturates too easily, the system loses usable depth information and may generate unstable returns near high-intensity regions.
Laser pulse design contributes as well. Better timing precision, pulse coding strategies, and control over emitted energy allow the system to separate intended returns from background illumination. Some designs improve temporal discrimination so that random optical noise is less likely to be interpreted as a valid object echo. Others focus on reducing internal reflections inside the sensor package, because self-generated stray light can become a hidden source of glare-like artifacts.
For evaluators, the practical message is clear: glare resistance should be tied to measurable architectural choices. Ask which optical filtering method is used, what the receiver saturation threshold looks like, how the sensor behaves under direct sun incidence angles, and whether internal crosstalk has been characterized. If a vendor cannot connect performance claims to architecture, the claim is hard to trust.
Signal processing is becoming the second line of defense
Hardware alone does not solve glare. The more meaningful industry change is that signal processing pipelines are now expected to absorb part of the burden. This includes adaptive thresholding, background noise estimation, multi-return discrimination, confidence scoring, and temporal consistency checks across frames. In strong glare conditions, the challenge is not merely detecting fewer points. It is preventing contaminated points from entering downstream perception modules as if they were valid.
A robust pipeline will estimate the local optical noise floor and adjust detection thresholds dynamically rather than relying on static assumptions. It may compare intensity signatures, pulse width characteristics, or return timing distributions to reject improbable echoes. It may also suppress isolated returns that appear only under transient saturation but fail temporal persistence checks. These are not cosmetic refinements. They directly affect whether free-space estimation, object clustering, and tracking remain stable during optical stress.
This is a major reason why solid-state LiDAR for autonomous vehicles is increasingly judged as a system, not just a component. The sensor architecture, firmware, perception interface, and validation toolchain all influence glare behavior. In technical assessments, an impressive detector can still produce weak real-world outcomes if threshold logic, timestamp integrity, or confidence annotation is poorly designed.
Where reflective interference is becoming a bigger issue than direct sunlight alone
Many teams still treat glare as a direct-sun problem, but field experience suggests reflective interference is often just as important. Wet asphalt, painted metal, road signs, polished cargo surfaces, and glass-heavy urban corridors can all redirect energy into the receiver. These scenes may not fully blind the sensor, but they can create local blooming, ghost points, multipath behavior, or depth instability. Such effects are difficult because they may look plausible enough to survive naïve filtering.
The market implication is significant. Programs that validate only against open-sky sun exposure may overestimate robustness. Technical evaluators should push for scenario libraries that include low-angle sun plus reflective infrastructure, backlit vehicles, tunnel exit transitions, and mixed-material road environments. The trend in high-quality procurement is toward scene realism, not single-variable testing.
What different stakeholders should now measure
The impact of this shift is not limited to sensor engineers. It affects platform architects, validation teams, procurement leaders, and safety managers in different ways. A useful review process separates concerns instead of mixing them into one vague “performance” discussion.
This stakeholder view matters because it prevents a common evaluation error: accepting one favorable metric as proof of overall robustness. A sensor may maintain nominal range in sunlight yet still create unacceptable false returns on reflective surfaces. Another may suppress false points well but recover too slowly after temporary saturation. Only a role-based metric set reveals such trade-offs.
The next evaluation direction: from static specs to degradation curves
A notable industry direction is the move from static specifications toward degradation characterization. Instead of asking whether solid-state LiDAR for autonomous vehicles is “glare resistant,” advanced teams ask how performance changes as optical stress increases. This is a better framing because all sensors have limits. What matters is whether degradation is gradual, predictable, and manageable within the safety architecture.
Degradation curves can include point density loss versus incident light intensity, range reduction versus reflectivity contrast, false detection growth versus sun angle, and recovery time after abrupt exposure transitions. These curves help teams compare suppliers on engineering substance rather than rhetorical positioning. They also support stack-level decisions such as sensor placement, cleaning strategy, shielding design, and fusion weighting logic.
This trend aligns with a broader hard-tech procurement reality: mature buyers increasingly prefer bounded behavior over absolute promises. A vendor that clearly defines thresholds, test conditions, and failure modes may be more trustworthy than one offering larger headline numbers without boundary disclosure.
How technical evaluators can respond with a stronger decision framework
For organizations assessing solid-state LiDAR for autonomous vehicles, the strongest response is to formalize a glare evaluation framework before final supplier comparison begins. Start with scene design. Include direct sun, reflective urban corridors, low-angle backlighting, wet-surface multipath, and rapid bright-dark transitions. Then define measurable outputs: valid point retention, false return suppression, object detection continuity, latency shift, and post-saturation recovery behavior.
Next, require test traceability. The evaluation should document optical conditions, target materials, target distances, mounting geometry, ambient temperature, and software version. Without this, results are hard to compare across vendors or across program phases. Also separate raw sensor output review from downstream perception review. If the stack fails, teams must know whether the root cause was optical saturation, filtering logic, interface timing, or object-level misclassification.
Finally, look for consistency between vendor narrative and engineering evidence. If a supplier emphasizes anti-glare capability, the supporting package should include receiver design logic, filter characteristics, signal-processing strategy, and scenario-based performance limits. That level of detail is not excessive; it is the minimum required for high-confidence selection in a safety-critical domain.
Questions worth confirming before the next sourcing decision
The current direction of the market is clear: glare handling is becoming a decisive indicator of perception maturity. For technical evaluators, the most useful next step is not to ask for broader claims, but sharper evidence. When reviewing solid-state LiDAR for autonomous vehicles, confirm five points: what optical stress conditions were tested, how the sensor degrades under those conditions, how false returns are identified and suppressed, how quickly the system recovers, and whether the data is repeatable across software revisions and production units.
If enterprises want to judge how this trend affects their own roadmap, they should also confirm whether current validation plans overemphasize ideal lighting, whether procurement criteria still rely too heavily on peak range, and whether supplier comparison methods capture reflective interference as rigorously as direct sunlight. In a market increasingly shaped by real-world robustness, the winning decision framework will be the one that treats glare not as a brochure footnote, but as a measurable engineering boundary.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)























