
Where a 10kg Collaborative Robot Payload Becomes Unrealistic
Publication Date
author
A collaborative robot payload 10kg rating can look ideal on paper, but real-world conditions often tell a different story. Once reach, tool weight, acceleration, mounting angle, duty cycle, and safety margins are factored in, that nominal capacity may quickly become unrealistic. This article examines where the limits appear, why spec-sheet assumptions fail, and how engineering teams can benchmark payload claims with data instead of marketing language.
Why a collaborative robot payload 10kg often fails in real production
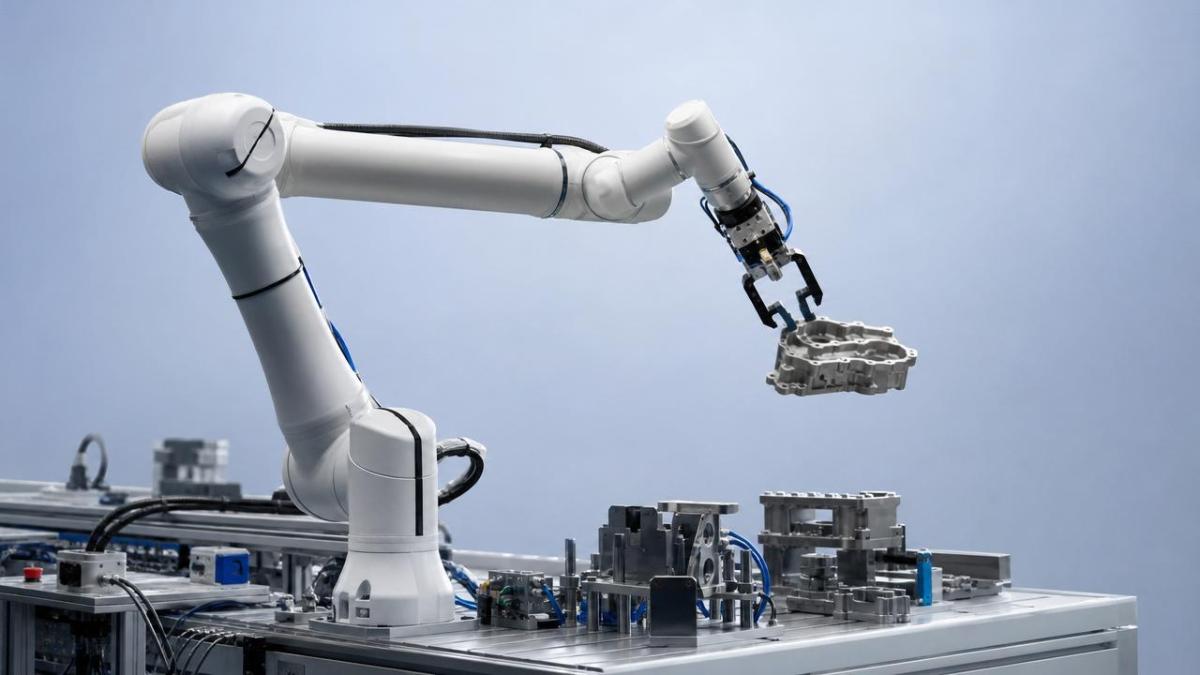
For information researchers comparing cobots across vendors, the phrase collaborative robot payload 10kg is often treated as a clean, single-number truth. It is not. In most cases, payload is a conditional rating measured under controlled assumptions: specific center of gravity, limited reach, moderate speed, defined mounting, and stable duty cycle. Change any one of those variables, and the effective usable payload drops.
This matters across the broader industrial landscape, from electronics assembly and CNC tending to packaging, inspection, and lab automation. A team that buys a 10kg cobot expecting a reliable 10kg process envelope may discover that the robot can technically lift the mass, yet cannot safely accelerate, maintain repeatability, or meet cycle time when the end effector and offset moment are included.
At TechStat Vanguard, the useful question is not “What payload is printed on the brochure?” It is “Under what engineering conditions does that payload remain repeatable, safe, and economically viable?” That distinction separates procurement confidence from expensive trial-and-error.
- Nominal payload may exclude the full gripper, cables, brackets, and sensor package.
- Long reach increases bending moment and reduces dynamic stability.
- High acceleration requirements can turn a static load into an unrealistic dynamic load.
- Mounting orientation and wrist posture can sharply change joint torque demand.
- Continuous duty can expose thermal limits that are invisible in short demonstrations.
Which engineering variables make a 10kg payload unrealistic?
The fastest way to misread a collaborative robot payload 10kg claim is to think only in kilograms. Cobot selection is a moment, inertia, and duty-cycle problem as much as a mass problem. A 7kg workpiece with a long tool and offset gripping geometry may be harder on the robot than a compact 10kg load held close to the flange.
The core variables procurement teams should check
The table below summarizes where a collaborative robot payload 10kg begins to lose realism in typical industrial evaluation. These are not universal failure points, but they are the variables most likely to invalidate brochure expectations.
The practical lesson is simple: a collaborative robot payload 10kg should never be approved without a flange-side mass breakdown and a motion-specific torque check. If the vendor cannot relate payload to center of gravity, inertia, acceleration, and thermal limits, the rating is incomplete for procurement purposes.
In which application scenarios does the 10kg rating break down first?
Not all applications stress a cobot the same way. Some processes operate close to the nominal payload with acceptable stability. Others make a collaborative robot payload 10kg unrealistic almost immediately. The gap usually appears in mixed conditions: long reach, tool complexity, short takt time, or multi-orientation handling.
Scenario-based risk assessment
The table below helps information researchers compare common use cases by payload realism rather than by headline rating alone.
For mixed manufacturing environments, the most vulnerable cases are not always the heaviest parts. They are the processes with awkward geometry, frequent acceleration changes, cable drag, and compliance requirements. That is why TSV encourages scenario-specific benchmarking instead of relying on broad product-category assumptions.
- If the application needs fast transfer between stations, dynamic derating should be treated as a core design input.
- If the process involves reach near the robot’s maximum span, check torque and repeatability at the farthest working point.
- If the end effector uses pneumatic or vacuum systems, include hoses, brackets, manifolds, and future tooling changes in the payload budget.
How to evaluate payload claims without relying on vendor language
The safest way to evaluate a collaborative robot payload 10kg is to turn the purchase question into a verification workflow. This is especially important for global sourcing teams and engineers who must compare multiple suppliers with different testing conventions and documentation quality.
A practical due-diligence checklist
- Define the full payload stack: workpiece, gripper, adapter, quick changer, sensors, cable package, and safety margin.
- Map center of gravity relative to the flange in the actual gripping orientation, not only the neutral design position.
- Request target cycle time validation with acceleration limits, path data, and worst-case reach conditions.
- Check whether the rating changes for wall mount, ceiling mount, or angled installation.
- Ask how repeatability behaves near rated payload and after extended operation.
- Review safety functions and collaborative speed limits, because safe operation may reduce usable throughput.
This method aligns with TSV’s broader philosophy: parameters do not lie, but incomplete parameters mislead. For hard-tech sourcing, the goal is not to reject vendor data. The goal is to convert fragmented data into a decision-ready engineering picture.
What procurement teams should compare beyond the 10kg number
A collaborative robot payload 10kg may be acceptable from one supplier and risky from another, even when the headline payload matches. Procurement teams should compare the structure around the rating, not just the rating itself. That means comparing usable envelope, integration burden, thermal behavior, safety implications, and support transparency.
Selection criteria that improve decision quality
The table below is useful for cross-vendor evaluation when the application is payload-sensitive and the cost of a wrong decision is high.
When these dimensions are visible, buyers can distinguish between a cobot that only reaches 10kg in a narrow demo window and one that can support a stable production process. That difference influences not just robot selection, but tooling design, line balancing, and maintenance planning.
Common misconceptions about collaborative robot payload 10kg
“If the part weighs 8kg, a 10kg cobot is enough”
Usually not by default. The part is only one part of the load case. Add a gripper, bracket, connector hardware, cable management, and a prudent operating margin, and the system can exceed what is comfortable for repeatable, high-speed collaboration.
“Payload is the same as real process capacity”
Payload is a rated limit. Real process capacity is the load the robot can move at the required speed, reach, accuracy, and duty cycle while staying inside safe and stable operating conditions. Those are not the same value.
“A slower speed solves everything”
Reducing speed can help, but it may destroy takt-time economics. A robot that handles the load only when slowed far below target throughput may meet the mechanical requirement while failing the business case.
“All 10kg cobots are comparable”
They are not. Differences in arm geometry, joint sizing, controller behavior, software limits, safety configuration, and test disclosure can make one collaborative robot payload 10kg far more usable than another in the same factory.
FAQ: how should researchers judge a 10kg cobot claim?
How much safety margin should be reserved below a collaborative robot payload 10kg?
There is no universal percentage because margin depends on reach, tool geometry, acceleration, and duty cycle. In practice, teams should avoid planning around the exact nominal limit unless the process is compact, slow, and fully validated. A better approach is to model the complete load case and ask whether the application still performs under worst-case motion and thermal conditions.
What data should a supplier provide for payload validation?
Useful data includes payload versus center of gravity, inertia limits, reach-related load restrictions, repeatability under load, mounting condition notes, and any duty-cycle or thermal derating behavior. If those items are missing, the 10kg claim is harder to trust in production planning.
Which industries are most affected by unrealistic payload assumptions?
Machine tending, palletizing, automotive subassembly, metalworking, and packaging lines are frequent examples because they combine substantial tooling mass with aggressive cycle requirements. Electronics inspection is usually less payload-sensitive, but cable routing and precision demands still matter.
Should buyers choose a larger robot instead of a 10kg cobot?
Sometimes yes, but not automatically. A larger robot may add cost, footprint, guarding complexity, or integration constraints. The correct choice depends on whether the current application truly exceeds the realistic envelope of the collaborative robot payload 10kg once tooling and motion are included.
Why data-led benchmarking matters before supplier shortlisting
In a hard-tech sourcing environment flooded with vague adjectives, payload claims need engineering context. That is where TechStat Vanguard adds value. TSV focuses on technical benchmarking, tolerance-driven interpretation, and traceable comparison logic so engineering teams can filter out low-resolution marketing language before it reaches the approval stage.
For a collaborative robot payload 10kg evaluation, that means translating nominal specifications into a decision framework based on use case, moment load, duty cycle, compliance expectations, and integration risk. The result is not just better content comprehension. It is shorter qualification cycles, fewer redesign loops, and more credible supplier conversations.
- Benchmark vendors using identical load-case assumptions instead of brochure summaries.
- Screen for hidden risk in tooling mass, flange offset, and process acceleration.
- Reduce rework by aligning robot selection with actual takt time and compliance needs.
Why choose us for collaborative robot payload evaluation
TechStat Vanguard supports information researchers, engineering teams, and procurement leaders who need more than a headline collaborative robot payload 10kg number. We help convert unclear vendor claims into structured technical comparison points that can be used for spec drafting, supplier screening, and internal decision review.
You can contact us to discuss payload parameter confirmation, application-specific cobot selection, realistic cycle-time benchmarking, tooling mass assessment, delivery and qualification considerations, customization boundaries, and documentation gaps that may affect RFQ quality. If your team is comparing multiple suppliers, TSV can also help organize the questions that expose whether a 10kg payload is genuinely usable or only nominally advertised.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026How Do You Verify Servo Motor Torque Under Continuous Load?How do I verify servo motor torque under continuous load? Learn RMS torque checks, torque-speed limits, thermal derating, and real-machine testing.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 29, 2026How MES and OEE work together to identify production lossesMES and OEE work together to uncover hidden production losses, connect downtime, speed, and quality data, and drive smarter shop-floor improvements.Victor Lin (Chief Software Architect)
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab























