
Industrial Robots for Palletizing Applications: Speed or Flexibility
Publication Date
author
When evaluating industrial robots for palletizing applications, the real question is not simply speed or flexibility, but fit. Throughput, SKU variation, payload, reach, and integration demands all shape the right answer.
A fast robot can underperform in mixed-product lines. A flexible robot can become inefficient in stable, high-volume operations. The better decision comes from measurable engineering requirements, not broad vendor claims.
For operations across food, logistics, chemicals, consumer goods, and industrial components, industrial robots for palletizing applications should be compared using cycle time, repeatability, tooling adaptability, uptime, and total system constraints.
Why a structured evaluation matters
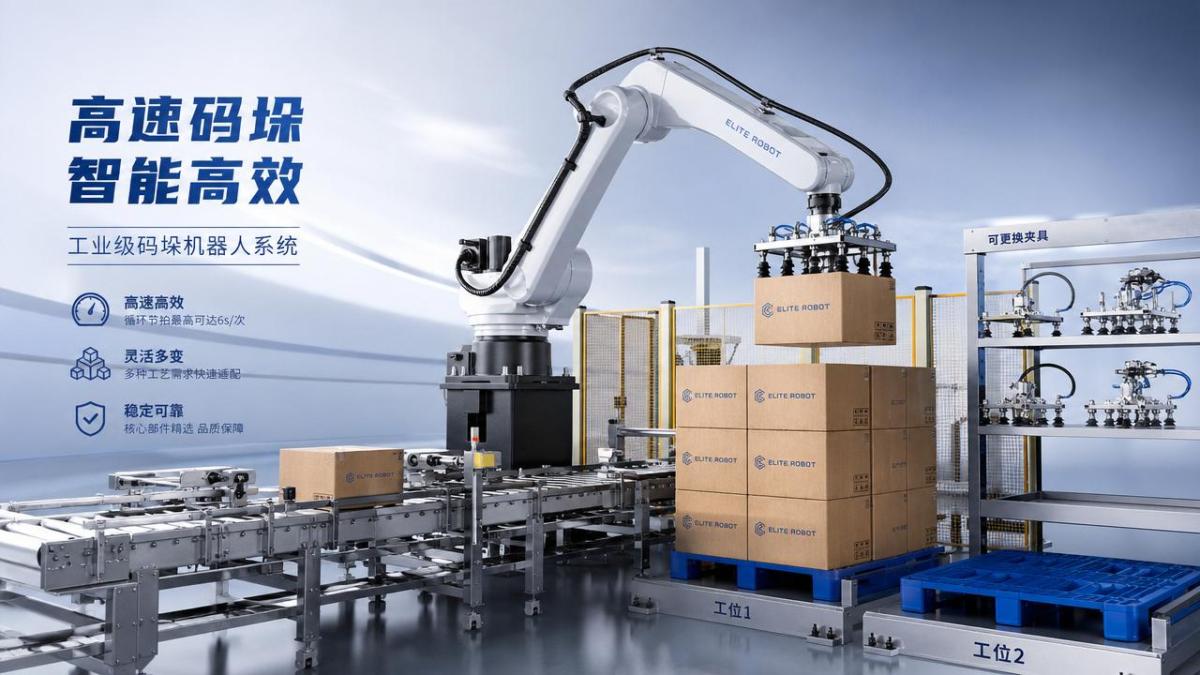
Palletizing projects often fail at the requirement stage, not at robot performance. Teams may compare arm speed, yet ignore infeed spacing, case stability, layer patterns, or pallet change interruptions.
A structured review reduces selection errors. It also helps align robot specs with conveyor timing, end-of-arm tooling, safety architecture, and long-term product change needs.
This matters because industrial robots for palletizing applications are rarely standalone assets. They sit inside broader material handling systems where one mismatch can reduce the entire cell’s effective output.
Core points to verify before choosing speed or flexibility
- Confirm actual cases per minute at full payload, including pick, rotation, placement, pallet indexing, and slip-sheet handling, instead of relying on empty-cycle robot speed.
- Check payload with tooling weight included, then add a safety margin for vacuum grippers, clamps, multi-pick heads, and future package changes.
- Measure required reach from infeed pickup to top pallet layer, including extended stack height, dual-pallet zones, and guarding clearance limitations.
- Review repeatability under real motion profiles, because stable box placement depends on deceleration control, product rigidity, and gripper consistency, not catalog precision alone.
- Evaluate SKU variation, layer recipes, and pallet pattern frequency to determine whether flexible programming creates more value than peak mechanical speed.
- Verify infeed product orientation quality, because poor spacing or skewed cartons often reduce cell throughput more than robot arm limitations.
- Assess end-of-arm tooling change time, especially where one cell handles bags, trays, cartons, and shrink-wrapped bundles in the same shift.
- Map line uptime targets against robot MTBF, spare parts availability, and service response, since nominal speed loses value during repeated downtime events.
- Check software integration with PLCs, vision systems, pallet dispensers, and warehouse execution systems before selecting advanced flexible palletizing logic.
- Model total cost per pallet, including energy, footprint, safety fencing, engineering hours, and reconfiguration time over the expected equipment lifecycle.
How speed-first systems make sense
High-volume, low-mix environments usually benefit from speed-first palletizing. Typical examples include beverage cases, corrugated shipping cartons, and standardized packaged goods with stable dimensions.
In these settings, industrial robots for palletizing applications should prioritize repeatable high cycle rates, rigid tooling, and minimal recipe changes. Mechanical simplicity often supports better uptime and easier maintenance.
Best-fit indicators
- Fewer than five routine SKUs, stable carton geometry, and limited pallet pattern changes across weekly production schedules.
- Consistent upstream conveyor flow with low product skew, allowing the robot to sustain deterministic motion paths.
- Downtime costs that quickly outweigh the value of broad recipe flexibility.
When flexibility should outweigh raw speed
Mixed-product operations often gain more from flexible automation than from maximum arm speed. This applies to contract packaging, third-party logistics, e-commerce fulfillment, and plants with frequent format changes.
Here, industrial robots for palletizing applications must handle recipe switching, variable box dimensions, different pallet sizes, and changing stack rules with limited engineering intervention.
Best-fit indicators
- Frequent SKU turnover, mixed-case loads, or seasonal packaging changes that make fixed mechanical systems inefficient.
- Demand for quick software-based pallet recipe updates rather than hardware-intensive changeovers.
- Need to support future line extensions, additional product families, or warehouse automation interfaces.
Application notes across common operating environments
Food and beverage
Speed often dominates, but washdown needs, package fragility, and sanitation-compatible tooling are equally important. Bagged products and lightweight cartons may require gentler acceleration profiles.
For these lines, industrial robots for palletizing applications should be checked for hygienic design compatibility, stable vacuum performance, and reliable pallet layer compression control.
Warehouse and logistics
Flexibility usually ranks higher because shipment profiles change constantly. Mixed dimensions, variable label orientation, and dynamic order composition increase software and sensing demands.
Key checks include vision support, fast recipe changes, and error recovery logic. Throughput should be tested under realistic parcel diversity, not idealized carton streams.
Chemicals and building materials
Heavy loads, dusty conditions, and bag deformation can challenge standard robotic cells. Payload margin and gripper force control become more important than top headline speed.
In these environments, industrial robots for palletizing applications should be validated for abrasive exposure, product instability, and long vertical reach at full load.
Precision industrial goods
Boxes may be standardized, but handling constraints can be stricter. Sensitive components, documentation requirements, and traceability links often make integration quality a deciding factor.
Software handshake reliability with labeling, scanning, and MES layers should be reviewed before prioritizing faster robot motion profiles.
Frequently overlooked factors that change the decision
Upstream instability
Robot speed cannot compensate for poor carton spacing, inconsistent case squareness, or conveyor accumulation problems. Many palletizing bottlenecks start before the robot pick point.
Tooling inertia
Large multifunction grippers improve flexibility, yet added mass can reduce acceleration and extend cycle time. The end-of-arm design often decides whether speed claims remain achievable.
Pallet quality variation
Warped or inconsistent pallets can disrupt layer accuracy and increase drop risk. This is especially relevant for tall loads near maximum reach limits.
Expansion risk
A speed-optimized cell may become restrictive if the site later adds mixed SKUs or dual-line feeding. Designing only for current throughput can create future retrofit costs.
Practical execution steps before final selection
- Document real product mix, peak hourly output, pallet patterns, and changeover frequency from live operating data.
- Request simulation or FAT evidence using true payload, true tooling, and realistic infeed assumptions.
- Compare at least three operating states: steady volume, mixed SKU mode, and recovery after upstream interruptions.
- Score options using throughput, flexibility, integration risk, maintainability, and lifecycle cost rather than purchase price alone.
- Reserve engineering margin for product evolution, not just present-day line conditions.
Final direction
The best industrial robots for palletizing applications are not always the fastest, nor the most flexible on paper. They are the systems that sustain target output under real packaging, layout, and uptime constraints.
A disciplined comparison should start with actual line data, then move to payload, reach, tooling, software, and expansion risk. This approach reflects TSV’s view that engineering truth lives in measurable system performance.
Use the points above as a working decision baseline. If speed drives economics, optimize for deterministic cycle time. If change dominates operations, prioritize flexible control, tooling adaptability, and integration resilience.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)
 Sep 19, 2026How to Scope Automation Integration Services for Multi-System Factory ProjectsAutomation integration services: learn how to scope multi-system factory projects with clear workflows, interface contracts, safety boundaries, and acceptance criteria.Victor Lin (Chief Software Architect)























