
How precise should a robotic arm be for electronics assembly
Publication Date
author
For robotic arm for electronics assembly, precision is not a marketing claim but a measurable engineering threshold that directly affects yield, solder joint integrity, and micro-component placement. This article examines how repeatability, vision calibration, payload stability, and process tolerance define real-world performance for engineers, operators, procurement teams, and decision-makers seeking data-driven benchmarks.
What precision actually means in electronics assembly
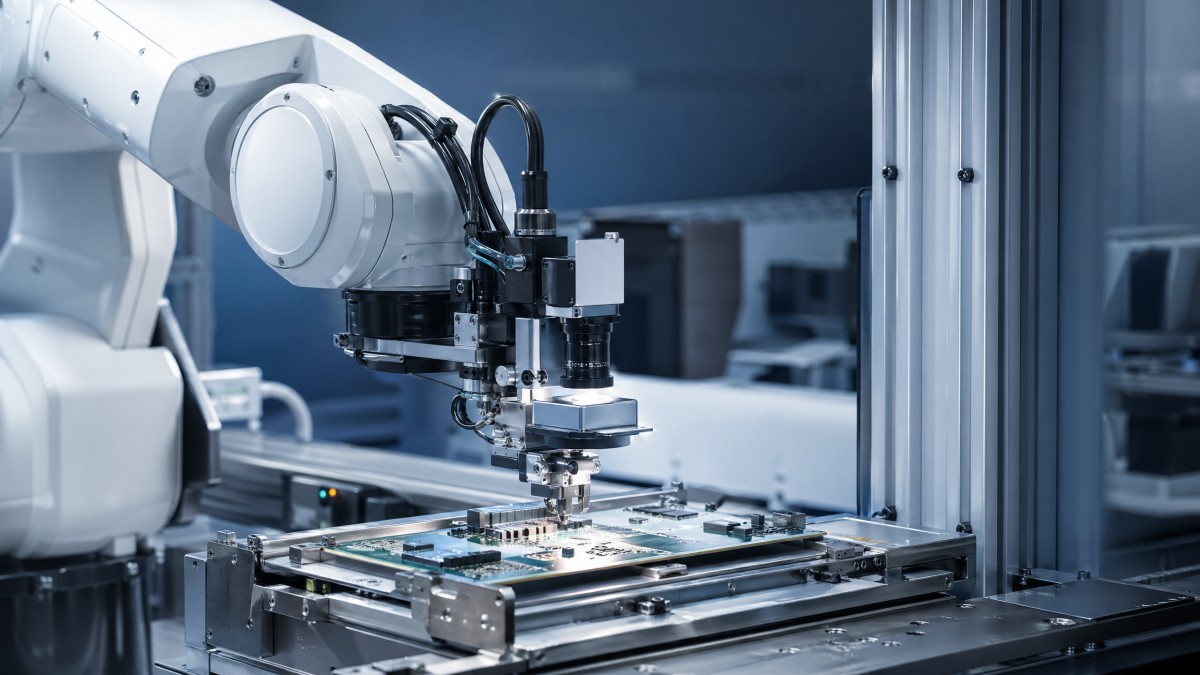
When buyers ask how precise a robotic arm should be for electronics assembly, they often receive broad claims such as “high accuracy” or “micron-level capability.” Those phrases are not enough. In production, precision must be broken into at least 4 measurable layers: repeatability, absolute positioning, vision-guided correction, and end-of-arm process stability. Each layer influences different tasks, from PCB loading to connector insertion and fine adhesive dispensing.
For most electronics assembly environments, repeatability matters more than raw advertised accuracy. A robot may have acceptable absolute positioning after calibration, but if its repeatability drifts under changing payloads, acceleration, or ambient temperature, placement quality will degrade. In common industrial practice, robotic arm repeatability for electronics assembly is often evaluated in ranges such as ±0.02 mm, ±0.03 mm, ±0.05 mm, or ±0.1 mm, depending on the process and fixture design.
A critical distinction is that the robot is only one part of the tolerance chain. Electronics assembly precision also depends on feeder consistency, PCB fixturing, end-effector compliance, camera resolution, calibration interval, and conveyor stop accuracy. A robotic arm with ±0.02 mm repeatability cannot guarantee ±0.02 mm part placement if the vision system, tooling, and mechanical stack-up add another ±0.05 mm of variation.
This is where TechStat Vanguard’s engineering-first view becomes useful. Instead of treating robotic arm precision as an isolated specification, TSV frames it as a system benchmark. That approach helps information researchers compare like with like, helps operators identify process drift, helps procurement teams write sharper RFQs, and helps executives avoid paying for precision levels that the rest of the production cell cannot actually use.
Why repeatability usually matters more than brochure accuracy
In electronics assembly, the robot normally performs repeated motions inside a defined work envelope. That means the ability to return to the same point over 10,000 cycles or over a 2-shift production day is often more valuable than its one-time ability to reach a theoretical coordinate in an empty test setup. Repeatability directly affects pad alignment, insertion force consistency, and cycle-to-cycle quality stability.
Absolute accuracy becomes more important when the robotic arm must interact with multiple stations, changing fixtures, or mobile platforms. However, in a fixed electronics cell with regular recalibration, repeatability plus good vision compensation can outperform a more expensive robot chosen only for a stronger headline specification. This is one of the most common sourcing mistakes in high-mix and mid-volume lines.
Operators also care about how precision behaves over time. A system that holds alignment for 8 to 12 hours before recalibration may be acceptable in some factories, while high-yield micro-assembly lines may require verification every 2 to 4 hours. Those intervals should be defined during FAT and SAT, not discovered after installation.
Key terms teams should separate during evaluation
- Repeatability: the robot’s ability to return to the same programmed point under the same conditions, usually the most relevant metric for repetitive electronics assembly.
- Absolute accuracy: how close the arm reaches a true coordinate in space, often improved with calibration and external vision correction.
- Resolution and control granularity: the smallest commandable motion increment, which does not automatically equal real process precision.
- System placement accuracy: the total result after robot, end-effector, fixture, camera, and part presentation errors are combined.
How precise should the robotic arm be for different electronics tasks?
The right precision threshold depends on the task, not on marketing pressure. A robotic arm for tray handling, PCB transfer, and screwdriving does not need the same repeatability as a system placing miniature connectors, shielding cans, or fragile optical components. In practice, electronics assembly buyers should classify applications into 3 groups: general handling, precision assembly, and micro-assembly or vision-critical operations.
General handling tasks such as loading carriers, moving PCBs between stations, or presenting parts to testers often tolerate robotic arm repeatability around ±0.05 mm to ±0.1 mm when the fixtures are forgiving. Precision assembly tasks such as connector mating, label placement, or controlled dispensing usually benefit from ±0.02 mm to ±0.05 mm. Micro-assembly tasks, especially those involving miniature components or narrow alignment windows, may demand sub-±0.02 mm system-level control with rigid tooling and high-quality vision integration.
The table below summarizes typical evaluation logic. These are not universal guarantees, because part geometry, process force, and fixture tolerance can shift the practical requirement. Still, this framework helps engineers and procurement teams translate a vague question into a usable specification sheet.
The key takeaway is simple: a robotic arm should be precise enough to stay inside the full process tolerance window, not just to satisfy a standalone catalog value. If the product tolerance stack leaves only a narrow margin of 0.04 mm to 0.08 mm, then selecting an arm with loose repeatability creates immediate yield risk. If the process window is wider, overspending on ultra-fine precision may not improve results.
This task-based view also supports better budget allocation. Instead of buying the highest precision arm for the entire line, many factories use a mixed architecture: one high-precision station for critical assembly and one or two standard arms for loading, unloading, and non-critical movement. That can reduce capital inefficiency while preserving process performance where it matters.
When process tolerance is tighter than robot tolerance
If the required placement window is tighter than the robotic arm’s proven repeatability, the process is already under stress before production starts. Teams may try to compensate with slower speeds, softer grippers, or frequent recalibration, but those are often temporary fixes. The more sustainable approach is to redesign the tolerance chain: improve fixturing, upgrade vision, shorten cantilever length, or choose a more suitable arm.
A useful engineering rule is to maintain enough margin so that robotic motion error consumes only a portion of the total allowable process variation. The exact ratio depends on the application, but the principle is consistent: do not let the robot use up nearly the entire tolerance budget on its own.
Which technical parameters matter beyond the precision spec?
A robotic arm for electronics assembly should never be selected on repeatability alone. In many lines, unstable vision calibration, unsuitable payload sizing, or vibration under acceleration causes more defects than the nominal precision value. For this reason, TSV-style benchmarking looks at a parameter set, not a single line item. At minimum, teams should review 5 technical dimensions before comparing quotations.
First is payload utilization. A robotic arm carrying an end-effector that consumes 60% to 80% of its payload rating may still operate, but dynamic stiffness can change during fast motion. Second is reach and posture. The same arm can behave differently near the center of its work envelope versus near the edge. Third is cycle-time acceleration. Higher speed is useful only if it does not introduce oscillation at the tool center point.
Fourth is vision integration quality, including calibration method, camera placement, and recalibration interval. Fifth is environmental stability. Electronics factories are cleaner than heavy machining shops, but temperature shifts, ESD controls, and fine cable routing still affect motion consistency. In delicate assembly, even a small variation over a 6-hour run can change insertion force or placement offset.
The following table provides a practical review framework for engineers, operators, and sourcing teams evaluating a robotic arm for electronics assembly. It is especially useful when two suppliers appear similar on headline precision but differ in real system behavior.
For operators, these factors explain why a robot can pass initial setup yet drift later in production. For procurement teams, they show why a quotation with identical reach and payload may still create very different process outcomes. For executives, they support a more disciplined capital decision: buy the precision level the process can exploit, and verify the surrounding subsystems with the same rigor.
A practical 5-point validation checklist
- Test repeatability with the actual gripper, cable routing, and part load, not with an empty flange.
- Measure placement quality after 1 hour, 4 hours, and 8 hours to detect thermal or mechanical drift.
- Verify precision at the real working posture, especially if the task is near the edge of the reach envelope.
- Check how quickly the system can be recalibrated during a shift without disrupting throughput.
- Confirm whether the quoted precision refers to the arm alone or to the complete integrated workstation.
How should procurement teams compare robotic arm options?
Procurement rarely fails because teams ignore price. It fails because teams compare incomplete technical definitions. In electronics assembly, two robotic arm proposals may look similar on reach, payload, and repeatability, yet differ significantly in controller response, vision compatibility, support for clean routing, or ease of preventive maintenance. A good sourcing process converts technical risk into a structured comparison before PO release.
A useful method is to divide evaluation into 3 decision layers: process fit, integration fit, and lifecycle fit. Process fit answers whether the robotic arm can achieve the required precision for the specific electronics assembly task. Integration fit checks communication, space, vision, ESD, and tooling compatibility. Lifecycle fit examines spare parts access, calibration support, operator training, and expected maintenance intervals over 12 to 36 months.
This approach is especially important for companies that operate across multiple geographies or contract manufacturing sites. A robotic arm that performs well in one demonstration cell may be difficult to standardize if software support, documentation depth, or local service response does not match the plant network. Data-driven procurement reduces these hidden adoption costs.
Questions procurement should put into the RFQ
To avoid ambiguous offers, procurement documents should ask suppliers to state whether precision values are measured under no-load, nominal-load, or full working-load conditions. The RFQ should also request recommended recalibration intervals, acceptable ambient temperature range, expected maintenance checkpoints, and the integration method for machine vision and force control if used in connector insertion or delicate assembly.
Another important step is to define acceptance criteria in advance. For example, teams may require a robotic arm for electronics assembly to maintain placement performance over a fixed sample run, such as 500 cycles, 2,000 cycles, or a full shift simulation, depending on process criticality. The exact threshold depends on the product, but predefining the test avoids subjective handover decisions later.
A 4-step sourcing workflow
- Define the task tolerance chain, including part tolerance, fixture tolerance, vision contribution, and robotic arm precision allowance.
- Shortlist 2 to 4 robotic arm candidates that match reach, payload, speed, and environmental requirements.
- Run a proof-of-process test using real parts, real tooling, and realistic cycle profiles rather than a simplified demo.
- Score lifecycle factors such as support responsiveness, spare parts availability, training, and calibration workflow before final selection.
For decision-makers, the best procurement outcome is not simply the lowest purchase price or the highest published precision. It is the lowest total process risk at the required throughput and quality target. In many cases, a slightly more expensive robotic arm with stronger integration discipline and support transparency delivers a lower cost per acceptable unit over time.
Common mistakes, compliance considerations, and practical FAQ
Many electronics manufacturers underestimate how quickly a precision discussion becomes a compliance and validation discussion. If the production line serves regulated sectors such as medical electronics, aerospace electronics, or automotive electronics, teams may need stronger traceability, documented calibration, and clearer acceptance protocols. While the exact standard depends on the application, the principle remains the same: the robotic arm must fit into a controlled manufacturing system, not just a fast one.
A second mistake is assuming that cobot safety and ease of deployment automatically equal suitability for high-precision electronics assembly. Collaborative robots can be a good fit for certain loading, inspection, or light assembly tasks. However, if the process demands very tight placement, high speed, or rigid insertion control, a traditional industrial robotic arm or a specialized precision platform may be more appropriate.
A third mistake is focusing on initial acceptance and ignoring long-run stability. Electronics assembly lines may run single shifts, double shifts, or 24/7 schedules. Precision that looks acceptable over 50 cycles may not hold over 5,000 cycles without robust calibration and maintenance planning. That is why benchmarking over time is more valuable than snapshot testing.
FAQ: How precise should a robotic arm be for electronics assembly?
Is ±0.1 mm precise enough for electronics assembly?
It can be enough for basic handling, tray movement, or loading operations with generous fixture tolerance. It is often not enough for tighter connector insertion, fine dispensing, or miniature component alignment. The answer depends on the full process window, not on the robotic arm alone.
Should I prioritize a vision system or a higher precision robotic arm?
If the incoming part position varies, vision may create more value than buying a much tighter robotic arm. If the task already has stable presentation but a very narrow tolerance window, higher robot repeatability and mechanical stiffness may matter more. In many advanced cells, the best answer is balanced investment in both.
How often should calibration be checked?
There is no universal interval. Some lines verify once per shift, some every 2 to 4 hours, and some only after tooling changes. The right interval depends on thermal stability, task criticality, cycle speed, and defect sensitivity. During pilot runs, teams should establish a realistic verification schedule based on measured drift rather than guesswork.
Can a collaborative robot handle precision electronics assembly?
Sometimes yes, especially for light assembly, loading, or vision-assisted handling. But not every cobot is ideal for tightly constrained insertion or micro-placement. Buyers should compare stiffness, settle time, and real working repeatability, not just safety features and ease of programming.
Why data-led evaluation matters now
In a market filled with broad performance claims, the most effective way to select a robotic arm for electronics assembly is to benchmark process reality: repeatability under load, vision drift, tool rigidity, acceptance cycles, and maintenance intervals. That is exactly the gap TSV addresses. By filtering out inflated language and focusing on measurable engineering thresholds, TSV helps teams shorten supplier qualification cycles and reduce expensive trial-and-error in automation investments.
If your team is comparing robotic arm precision for electronics assembly, TSV can support parameter confirmation, application-based benchmarking, RFQ structure review, tolerance-chain analysis, delivery-cycle discussion, and fit-for-process evaluation. That is valuable whether you are an engineer defining a station, an operator diagnosing drift, a buyer comparing vendors, or an executive reviewing capital allocation for a new manufacturing line.
Why work with TSV for robotic arm benchmarking and sourcing decisions
TechStat Vanguard is built for hard-tech teams that need engineering clarity rather than promotional language. In robotics and automation, that means translating ambiguous claims into usable procurement criteria: repeatability ranges, tolerance-chain logic, calibration expectations, integration constraints, and realistic application fit. We do not treat precision as a slogan. We treat it as a decision variable tied to yield, risk, and lifecycle cost.
If you are preparing a robotic arm for electronics assembly project, the most useful next step is not a generic inquiry. It is a structured technical discussion. Share the assembly task, part size range, target cycle time, required placement window, payload with end-effector, vision setup, and expected validation method. With those 6 inputs, conversations become faster, supplier comparisons become cleaner, and sourcing mistakes become easier to prevent.
You can contact TSV to discuss parameter confirmation, robotic arm selection logic, process-specific precision thresholds, integration risks, sample evaluation criteria, common delivery timelines, and documentation requirements for regulated or high-reliability applications. For global teams dealing with information noise, this kind of data-led support can materially reduce qualification friction and improve sourcing confidence.
When tolerances dictate success, decisions should start with evidence. That is the standard TSV brings to robotics, sensors, precision manufacturing, and broader hard-tech supply chains.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 26, 2026AMAXiMAL Releases Open-Source TopMod 3D v3 With Claude AIExplore AMAXiMAL’s free, open-source TopMod 3D v3 with Claude AI assistance, topology-based modeling and plywood fabrication tools that connect complex designs to physical builds.Dr. Marcus Vance
 Oct 26, 2026Choosing a SCADA System Integrator Company: PLC Compatibility and Long-Term SupportChoose a scada system integrator company with proven PLC compatibility and reliable long-term support. Discover what to test, compare, and require before investing.Victor Lin (Chief Software Architect)
 Oct 25, 2026Hesai Leads Global ADAS Main Lidar Shipments in Yole’s 2026 ReportHesai led global ADAS main lidar shipments with a 43% share in 2025, according to Yole’s 2026 report. Explore what this ranking reveals about its automotive market position.TSV Data Lab
 Oct 25, 2026Choosing an Aerospace Materials Manufacturer: Quality and Traceability ChecksChoosing an aerospace materials manufacturer? Learn how to verify certifications, test reports, and lot traceability to qualify suppliers confidently and reduce costly sourcing risks.Dr. Marcus Vance
 Oct 24, 2026Guotai Haitong: Global Entry-Level 3D Printer Shipments Rose 39% in Q1 2026Entry-level 3D printer shipments rose 39% in Q1 2026, Guotai Haitong reports. Explore how AI, multicolor printing and print farms are shaping market growth.Dr. Marcus Vance
 Oct 24, 2026Choosing an Industrial Vision Inspection Supplier: Acceptance Tests That MatterChoose an industrial vision inspection supplier with confidence. Discover acceptance tests for defect detection, false rejects, production speed, and reliable part rejection before you buy.TSV Data Lab
 Oct 23, 2026US Navy Raises Gecko Robotics Contract Ceiling to $300M for Robotic Fleet MaintenanceUS Navy raises Gecko Robotics’ contract ceiling to $300M for Pacific Fleet robotic inspections. Explore potential opportunities for maintenance suppliers and key procurement considerations.Chen Wei (Automation Lead Engineer)
 Oct 23, 2026Choosing Industrial Sensing Systems for Global Plants: Protocol CompatibilityCompare industrial sensing systems international buyers can trust. Explore protocol compatibility, reduce integration risks, and select proven configurations for reliable global plant deployments.TSV Data Lab
 Oct 22, 2026KUKA Showcases Physical AI and iiQKA.AI Vision at NVIDIA GTC BerlinExplore KUKA’s Physical AI showcase at NVIDIA GTC Berlin and discover how iiQKA.AI Vision aims to simplify robotic vision integration and improve 2D and 3D scene recognition.TSV Data Lab
 Oct 22, 2026Robotic Machining of Advanced Composites: What Tolerances Are Achievable?Explore advanced materials machining robotics: discover what drives achievable composite tolerances and how to validate accuracy before investing in your next machining system.Dr. Marcus Vance
 Oct 21, 2026China’s Industrial Robot Exports Near RMB 10 Billion in First Nine Months of 2026China’s industrial robot exports neared RMB 10 billion in January–September 2026, with value rising faster than volume. Explore the data and what it could mean for suppliers.Chen Wei (Automation Lead Engineer)
 Oct 21, 2026Low-Latency Industrial Data Processing: Pricing and Key Cost DriversExplore industrial data latency price drivers, from edge hardware to integration and support. Learn how to compare quotes, verify performance, and avoid unnecessary costs.TSV Data Lab
 Oct 20, 2026KUKA Launches iiQKA.AI Vision to Simplify Industrial Image ProcessingKUKA iiQKA.AI Vision simplifies industrial image processing with controller-based 2D and 3D vision. Explore drag-and-drop setup for vision-guided automation.TSV Data Lab
 Oct 20, 2026Smart Industrial Edge Devices: Key Criteria for Legacy PLC IntegrationChoose smart industrial edge devices for legacy PLC integration. Discover key criteria for compatibility, data quality, security, and reliable collection without disrupting control.TSV Data Lab
 Oct 19, 2026Choosing a Radar Sensor by Application: Range, Resolution, and Field of ViewSimplify radar sensor application based product selection. Compare range, resolution, and field of view to avoid blind spots and choose with confidence. Explore the guide.TSV Data Lab
 Oct 18, 2026Comparing Material Options for Procurement: Specs, Costs, and Supply RisksExplore procurement oriented technical content on material options, specs, costs, and supply risks. Compare alternatives to cut hidden expenses and make confident sourcing decisions.Dr. Marcus Vance
 Oct 17, 20265-Axis CNC Positioning Accuracy: How to Interpret ISO 230-2 Test ResultsAssess 5 axis CNC machining positioning accuracy with ISO 230-2. Learn to interpret repeatability, reversal error, and test conditions to compare suppliers and make confident acceptance decisions.Dr. Marcus Vance























