
Why warehouse AGV AMR projects miss expected throughput
Publication Date
author
Many AGV/AMR programs promise fast ROI, yet warehouse teams still miss expected throughput after launch. For financial approvers evaluating AGV AMR for warehouse automation, the real issue is rarely the robot count alone—it is the gap between modeled flow and operational reality. This article examines where capacity assumptions fail, which technical constraints get overlooked, and how data-driven validation protects both budget efficiency and long-term performance.
Why throughput misses are usually a modeling problem, not a robot problem
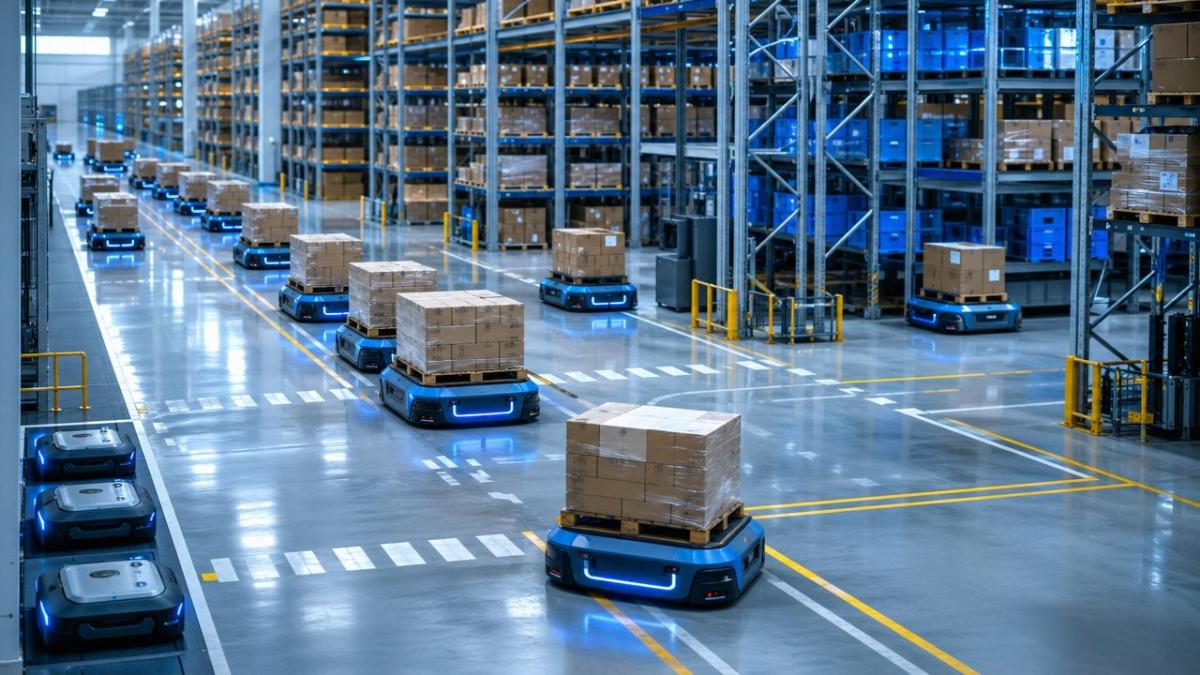
When an AGV or AMR warehouse project underperforms, the first explanation is often too simple: not enough robots, weak software, or poor vendor execution. In practice, expected throughput is missed because the original business case assumed a cleaner operating environment than the warehouse actually provides. For finance leaders, this matters because the project may still be technically functional while economically underdelivering.
Most AGV AMR for warehouse automation proposals are built on average travel times, average pick density, average congestion levels, and ideal battery availability. Those assumptions can look reasonable in a sales presentation, but warehouse performance is decided by variability, not averages. Traffic spikes, exception handling, cross-aisle interference, manual forklift interaction, charging queues, and order-wave surges create compounding losses that erode the modeled capacity.
This is why some sites achieve robot uptime targets yet still fail to hit line dispatch rates, dock turn speed, or order completion windows. The automation layer may be operating as designed, but the overall flow system is not. For a financial approver, the correct question is not “Will the robots run?” but “Will the entire process sustain the required throughput under realistic peak conditions?”
The highest-value financial insight is straightforward: throughput risk is often hidden upstream in layout, control logic, replenishment timing, and exception processes. If those factors are not validated with data before approval, the capital request may underestimate both ramp-up cost and payback period.
Where AGV/AMR business cases typically overestimate capacity
One of the most common issues is that vendors model robot movement as if transport demand is evenly distributed. Real warehouses do not behave that way. Demand clusters around popular SKUs, shift changes, replenishment windows, picking cutoffs, and outbound wave releases. This creates temporary bottlenecks at intersections, workstations, elevators, buffer lanes, and pack-out zones. A fleet that looks adequate in average-hour analysis may be undersized during the two or three hours that determine daily output.
Another common overestimate comes from assuming that each robot spends most of its time on productive motion. In reality, productive travel can be only one part of the cycle. Queueing, waiting for aisle clearance, docking alignment, pallet pickup verification, safety slowdowns near pedestrians, and software dispatch latency all consume time. Even a few lost seconds per mission become a major throughput penalty across thousands of moves per day.
Battery strategy is another frequent blind spot. Financial models often treat charging as a background activity with limited operational consequence. But in many systems, charging policy directly affects capacity. If too many units seek charging during the same window, available fleet size drops when demand is high. If charging opportunities are too sparse, robots may enter low-power protection states that disrupt workflow. This is not just an engineering question; it changes the cost of required fleet size and spare infrastructure.
There is also a widespread assumption that warehouse management system integration will smoothly synchronize with robot task orchestration. Yet interface delays, poor task prioritization, and incomplete exception messaging can create invisible throughput loss. A robot can be technically available but not optimally dispatched. For decision-makers approving budget, that means software architecture deserves the same scrutiny as hardware specifications.
What financial approvers should examine before trusting a throughput claim
Financial approvers do not need to become robotics engineers, but they do need a disciplined review framework. The first checkpoint is whether projected throughput is based on average conditions or peak operational windows. A proposal should clearly show required performance during the busiest hour, busiest shift, and busiest season—not just daily averages.
The second checkpoint is the mission-cycle breakdown. Ask for the full time budget of a representative move: dispatch delay, travel time, dwell time, load handling, waiting time, congestion time, and charging impact. If the vendor cannot decompose cycle time at this level, the throughput estimate may be too abstract to support investment-grade forecasting.
The third checkpoint is exception-rate treatment. Warehouses do not run on perfect flows. Labels fail to scan, pallets are mispositioned, aisles are partially blocked, inventory is misplaced, and manual traffic interrupts routes. Strong proposals quantify how often exceptions occur and how much capacity they consume. Weak proposals mention exceptions only in implementation notes, even though they materially affect ROI.
The fourth checkpoint is buffer design. Throughput is not generated by robots alone; it depends on how well upstream and downstream stations absorb variability. Without enough accumulation space, queue discipline, and handoff logic, mobile robots simply move congestion from one part of the building to another. Financially, this can create a misleading outcome where capex is spent but labor inefficiency remains.
The fifth checkpoint is ramp-up realism. If the business case assumes near-nameplate throughput shortly after go-live, it may understate the learning curve. Sites often need tuning cycles for routing rules, battery thresholds, traffic zoning, replenishment timing, and workstation balancing. Finance teams should ask how long it typically takes comparable sites to achieve stable throughput and what temporary productivity penalties should be expected.
Why warehouse constraints matter more than headline robot specifications
In AGV AMR for warehouse automation discussions, buyers can become overly focused on navigation methods, top speed, or fleet size. Those metrics are relevant, but they do not by themselves determine output. A robot capable of higher speed does not create value if the operating environment forces frequent deceleration, stop-and-wait behavior, or low-speed coexistence with people and forklifts.
Layout geometry is often more important than brochure specifications. Narrow turning zones, insufficient overtaking opportunities, constrained merge points, elevator dependencies, and poor workstation placement can cap throughput no matter how advanced the fleet is. If two dozen robots must pass through a limited number of conflict points, the practical system capacity may be far below the theoretical robot capacity.
Safety policy also has a measurable impact. Shared environments require obstacle detection, reduced speed zones, human-robot separation logic, and compliance with site-specific operating rules. These are necessary controls, but they lower effective throughput when not incorporated into the planning model. Financial approvers should insist that safety constraints are reflected in the actual throughput simulation rather than treated as a later commissioning detail.
Payload assumptions must also be tested against actual load diversity. Different pallet dimensions, unstable cartons, floor quality variation, and docking tolerances can all affect cycle time and reliability. A system that performs well in a narrow test case may lose efficiency when confronted with the full mix of warehouse reality. The financial implication is simple: throughput claims should be tied to the full operational profile, not only to idealized loads.
How to distinguish credible ROI from optimistic automation storytelling
Credible ROI starts with measurable baseline pain. If the current warehouse does not have a clear throughput bottleneck, labor instability problem, safety risk, or service-level penalty, automation economics may be overstated. AGV/AMR systems create the strongest financial case when they remove identifiable and recurring flow constraints rather than when they are introduced mainly to modernize perception.
Next, look for scenario-based sensitivity analysis. A robust business case should show what happens if order volume rises 20%, if congestion is worse than expected, if battery utilization drops, or if a critical interface experiences delay. Finance teams should prefer proposals that reveal downside ranges instead of presenting only a single ROI figure. A narrow, highly confident payback estimate is often less credible than a transparent range supported by assumptions.
Labor savings should also be audited carefully. Some projects assume direct labor removal while ignoring the added need for traffic management, exception handling, software support, battery maintenance, and process supervision. The better question is not simply how many operators can be eliminated, but how labor is reallocated and whether the end-to-end process actually improves cost per completed order or cost per pallet move.
Another warning sign is when savings are calculated from continuous high utilization without accounting for underused periods. Many warehouses have demand peaks and troughs. If the fleet is financially justified only under sustained high activity, the utilization profile may be fragile. Capital efficiency improves when the automation design matches real demand distribution and can be phased rather than oversized from day one.
What data-driven validation should exist before capital approval
Before budget approval, there should be more than a conceptual layout and vendor promise. At minimum, decision-makers should expect timestamped flow data from the current operation, including move frequency by zone, peak-hour demand, travel paths, queue durations, replenishment timing, and exception frequency. Without this operational baseline, it is difficult to test whether the future-state model is credible.
A serious evaluation should also include simulation under stress conditions. This means testing not only steady-state performance but also peak demand, partial route blockage, charger unavailability, workstation slowdown, and mixed manual-automated traffic. The purpose is not to eliminate all risk, but to identify where throughput collapses first and what mitigation cost is required.
Pilot design matters as well. A useful pilot is not a showroom demonstration; it targets the most failure-prone part of the workflow. If congestion at a cross-aisle, sequencing at pack-out, or replenishment timing into goods-to-person stations is the likely bottleneck, the pilot should replicate that challenge. Financially, a focused pilot reduces the risk of scaling a system that performs well only in low-complexity conditions.
Approvers should also require acceptance metrics that tie technical performance to business outcomes. Instead of approving against generic goals such as “improved automation efficiency,” define measurable thresholds: moves per hour during peak windows, queue limits at critical stations, order completion rate, labor hours per unit shipped, and recovery time after exceptions. These are the metrics that protect budget integrity.
Questions finance leaders should ask vendors and internal teams
A practical review can begin with a short list of disciplined questions. What percentage of throughput depends on the busiest operational hour? What are the top three physical bottlenecks in the proposed layout? How much cycle time is lost to waiting, congestion, and exception handling? What fleet availability is assumed after charging and maintenance effects? How is performance affected when one critical route or station degrades?
Ask internal teams whether the current process itself is stable enough for automation. If inventory accuracy, slotting discipline, pallet quality, or workstation responsiveness are already inconsistent, mobile automation may amplify those weaknesses instead of solving them. Robots can reduce manual transport effort, but they do not correct poor process control for free.
Also ask whether the implementation plan includes enough time and budget for tuning after go-live. In many cases, value is unlocked not by the initial install but by the first three to six months of parameter optimization. If no structured tuning phase exists, the forecast may be assuming performance that the organization has not funded or operationally prepared to achieve.
A more reliable way to approve AGV/AMR investments
For financial approvers, the best way to evaluate AGV AMR for warehouse automation is to treat throughput as a system outcome rather than a robot attribute. The critical question is whether the project has modeled operational variability honestly and translated that into realistic economics. Strong projects do not just promise automation; they quantify how the warehouse will perform under pressure.
That means approving projects with clear baseline data, peak-condition analysis, stress-tested simulation, explicit exception assumptions, and business-linked acceptance criteria. It also means being cautious when a proposal emphasizes robot features more than flow logic, software dispatching, layout constraints, and ramp-up strategy. In warehouse automation, throughput misses are usually born long before go-live—inside the assumptions used to justify the investment.
The takeaway is not that AGV/AMR projects are inherently risky or overhyped. Many deliver strong returns. But the winning projects are typically the ones that respect engineering detail, operational variability, and financial discipline at the same time. When approval is grounded in measured flow data rather than optimistic averages, companies are far more likely to achieve the throughput they paid for—and the ROI they were promised.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)
 Sep 19, 2026How to Scope Automation Integration Services for Multi-System Factory ProjectsAutomation integration services: learn how to scope multi-system factory projects with clear workflows, interface contracts, safety boundaries, and acceptance criteria.Victor Lin (Chief Software Architect)























