
AGV AMR path planning algorithms and the tradeoff with traffic flow
Publication Date
author
For technical evaluators, AGV AMR path planning algorithms are never just a software choice—they directly shape throughput, congestion risk, and fleet stability. In modern automated facilities, the real challenge is balancing route optimality with overall traffic flow under variable loads, mixed-priority tasks, and dynamic obstacles. This article examines that tradeoff through an engineering lens, helping decision-makers compare algorithm logic against measurable operational outcomes.
Why the evaluation standard is changing now
A few years ago, many buyers assessed AGV AMR path planning algorithms mainly by asking whether a vehicle could reach a target safely and with acceptable accuracy. That baseline is no longer enough. Warehouses, electronics plants, aerospace component workshops, and mixed-model assembly environments now expect mobile robots to operate in denser fleets, tighter aisles, and more variable task conditions. As a result, the industry is shifting from single-robot navigation performance to fleet-level traffic performance.
This change matters because the fastest local route is not always the best operational route. An algorithm that minimizes travel distance for one AMR can increase queueing at intersections, amplify deadlock probability, and reduce effective throughput across the whole system. In practical deployment, technical evaluators are therefore moving toward a broader question: how do AGV AMR path planning algorithms behave when many robots compete for the same space at the same time?
For organizations following an engineering-first procurement model, this is a decisive shift. It aligns with a wider hard-tech trend: claims about “smart routing” are losing value unless they are tied to measurable congestion recovery time, mission completion stability, and predictable traffic flow under stress.
The key trend signal: route optimality is being redefined by system behavior
The most important trend is not that algorithms have become more advanced in theory, but that evaluation criteria have become more operational. In live facilities, route optimality now includes travel time variance, intersection blocking, detour resilience, charging coordination, and priority handling for urgent tasks. This means AGV AMR path planning algorithms are increasingly judged by how well they preserve traffic flow instead of how elegantly they solve a shortest-path problem.
Three signals support this shift. First, fleets are getting larger, making interaction effects more visible. Second, facilities are running more mixed workflows, where human workers, forklifts, tow tractors, and AMRs share space. Third, uptime expectations are rising, so temporary inefficiencies that were once tolerated now become material losses. In these conditions, path planning becomes a traffic management discipline as much as a navigation discipline.
What is driving the rise of traffic-aware AGV AMR path planning algorithms
Several forces are pushing the market toward more traffic-aware logic. One is layout compression. Facilities want to increase storage density and production flexibility, but that usually reduces open maneuvering space. Another is labor and asset utilization pressure. If a fleet is purchased to raise productivity, hidden waiting time at crossings or pickup points quickly undermines the business case.
A third driver is the rising use of hybrid environments. In many deployments, automated vehicles are no longer isolated from people and manual equipment. That makes purely deterministic routing less effective, because traffic disturbances become frequent and hard to model in advance. Finally, software expectations are changing. Buyers increasingly expect orchestration platforms to connect mission allocation, battery strategy, and path planning into one coordinated system rather than treating routing as a stand-alone module.
This is why technical evaluation is moving beyond labels such as A*, Dijkstra, conflict-based search, or reinforcement learning. Those methods matter, but the larger engineering question is how they are implemented in a real fleet architecture: centralized or distributed control, reservation granularity, refresh frequency, safety fallback behavior, and latency tolerance.
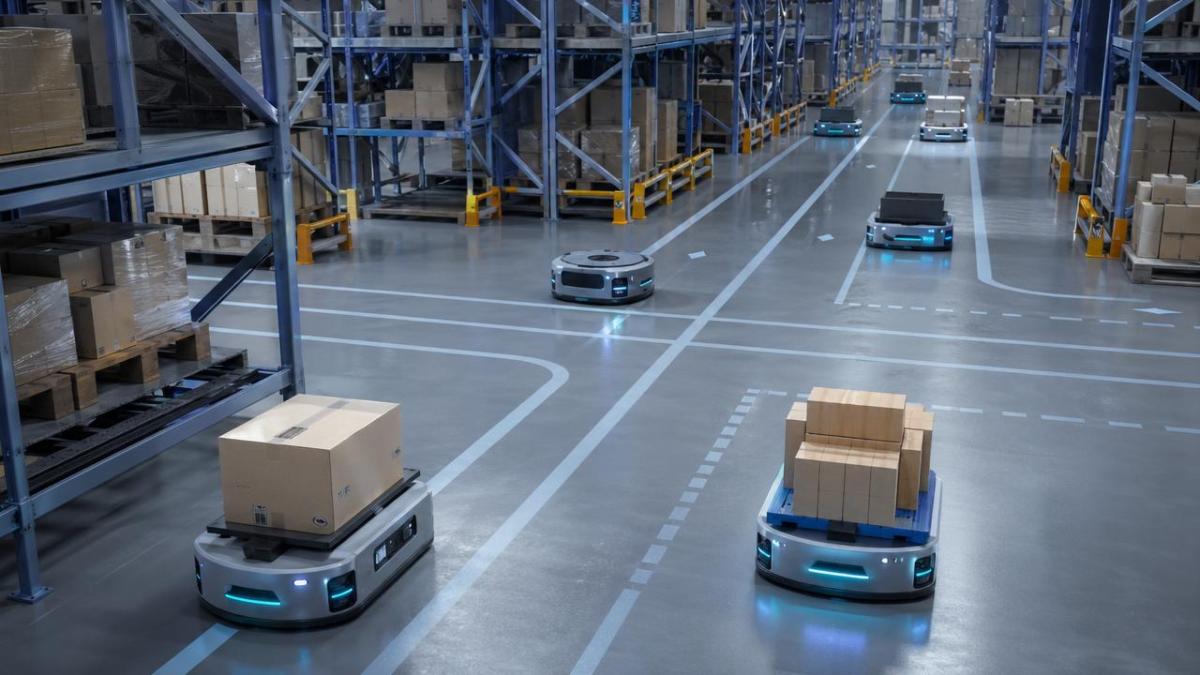
The central tradeoff: local efficiency versus network-wide flow
The tradeoff at the center of AGV AMR path planning algorithms can be stated simply: if the system aggressively optimizes each robot’s immediate route, it may create unstable traffic patterns; if it over-prioritizes traffic smoothing, some individual trips become longer. Neither extreme is ideal. The right balance depends on fleet density, mission urgency, and the cost of delay in specific zones.
For example, shortest-path logic often works well at low utilization. But as utilization rises, repeated use of the same corridor can create a bottleneck. A traffic-aware algorithm may intentionally send some vehicles on longer routes to reduce intersection load and preserve overall throughput. From a single-mission perspective, that can look inefficient. From a system perspective, it is often the more rational decision.
This is where many evaluations fail. Teams compare algorithms on path length or average travel time in lightly loaded simulations, then discover different behavior after deployment. The real comparison should include queue formation, tail latency for urgent missions, deadlock escape time, and the percentage of time robots spend blocked rather than moving.
Common decision tension points
- Shortest path versus balanced corridor utilization
- Strict task priority versus fairness across the fleet
- Fast replanning versus computational stability
- High reservation certainty versus reduced flexibility
- Local collision avoidance versus global traffic predictability
How the impact differs across stakeholders and operating stages
The consequences of algorithm choice are not distributed evenly. A CTO may care about architecture scalability, while a plant engineering team feels the immediate pain of congestion. Procurement may focus on vendor claims, but operations will live with the actual throughput limits. This is why AGV AMR path planning algorithms should be assessed through the lens of each decision owner.
The stage of deployment also changes the evaluation logic. In pilot projects, many algorithms appear acceptable because route density is low. During expansion, interaction complexity rises sharply. In mature deployments, the biggest risks often come from exception handling rather than nominal routing. A technically strong system is one that degrades gracefully as complexity increases.
What technical evaluators should watch beyond algorithm names
One of the most misleading habits in the market is to compare AGV AMR path planning algorithms by name alone. Two vendors may both claim to use A* variants or multi-agent planning, yet show very different real-world performance because the surrounding control strategy is different. Evaluation should focus on system behavior, parameter visibility, and edge-case handling.
First, examine whether the planner is static, periodic, or event-driven. Event-driven replanning usually improves responsiveness, but it can also create route oscillation if not stabilized. Second, inspect traffic reservation policy. Segment reservation, node reservation, and time-window reservation produce different tradeoffs between safety margin and lane utilization. Third, check how priorities are enforced. If every urgent task receives unconditional precedence, lower-priority work may starve and create downstream imbalances.
It is also important to ask how the system measures itself. Vendors should be able to expose blocked time, average queue length by zone, detour ratio, path recomputation frequency, and mission lateness distribution. Without those indicators, it is difficult to validate whether traffic flow is truly optimized or merely appears acceptable during demonstrations.
Emerging direction: from path planning to flow orchestration
A notable market direction is the shift from isolated path planning toward full flow orchestration. In this model, AGV AMR path planning algorithms are integrated with task allocation, charging control, workstation readiness, and zone access policies. The planner no longer reacts only to map obstacles; it proactively shapes where robots should go, when they should wait, and which missions should be delayed to avoid system-wide instability.
This trend is especially relevant in facilities where task priority is uneven and buffer space is limited. Instead of asking only how to find a path, more advanced systems ask whether the mission should enter a congested zone at all. That logic can reduce visible movement efficiency on some routes while improving plant-level output. For evaluators, this means future-proof selection will increasingly depend on orchestration maturity rather than on navigation features alone.
A practical evaluation framework for current buying decisions
Given current market conditions, a practical framework should test AGV AMR path planning algorithms at three levels. At the route level, verify obstacle handling, travel consistency, and map adaptability. At the interaction level, verify crossing conflicts, merge behavior, and queue spillback. At the fleet level, verify throughput retention during peak demand and after disturbances such as blocked aisles or battery-driven vehicle withdrawals.
Scenario design matters as much as the algorithm itself. Benchmarking should include mixed-priority missions, repeated calls to the same hotspot, temporary lane loss, and manual traffic intrusion. A vendor that performs well only in balanced and predictable traffic may not be suitable for facilities with real variability. Evaluators should also request evidence of parameter tuning boundaries, because some systems perform well only after heavy custom adjustment that is hard to maintain.
What to do next if you are assessing a deployment
The next step is not to search for a universally best algorithm. It is to identify the operating pattern your site actually has. If your environment is low-density and highly predictable, simpler AGV AMR path planning algorithms may be sufficient and easier to maintain. If your environment has bursty demand, narrow shared corridors, or frequent human interaction, traffic-aware and orchestration-oriented logic will usually deserve stronger weighting in the decision model.
For technical evaluators, the most useful questions are concrete. Where do queues form today? What delay is operationally acceptable by task class? How often does the layout change? Which zones are safety-constrained? How much blocked time can the business tolerate before ROI assumptions fail? Those answers will do more to guide selection than any generic claim about intelligence or optimization.
In the current market, the strongest signal is clear: AGV AMR path planning algorithms are no longer judged only by whether they can find a path, but by whether they can sustain orderly traffic flow as automation scales. Organizations that evaluate this tradeoff early will make more resilient fleet decisions, shorten validation cycles, and reduce the risk of discovering congestion limits only after deployment.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)
 Sep 19, 2026How to Scope Automation Integration Services for Multi-System Factory ProjectsAutomation integration services: learn how to scope multi-system factory projects with clear workflows, interface contracts, safety boundaries, and acceptance criteria.Victor Lin (Chief Software Architect)























