
Why path planning algorithms matter more in mixed AGV AMR fleets
Publication Date
author
In mixed AGV and AMR deployments, navigation is no longer just a software feature—it is a core operational risk and performance lever. AGV AMR path planning algorithms determine how safely, efficiently, and predictably fleets move through shared, dynamic environments. For project managers balancing throughput, integration complexity, and long-term scalability, understanding these algorithms is essential to avoiding costly bottlenecks and making data-driven automation decisions.
The core search intent behind “AGV AMR path planning algorithms” is practical, not academic. Readers are typically trying to answer a decision question: why do these algorithms matter in real operations, especially when both guided vehicles and autonomous mobile robots must share the same facility? They want to understand whether path planning affects throughput, safety, congestion, system integration, and future expansion enough to influence vendor selection or project design.
For project managers and engineering leads, the biggest concern is rarely the mathematical elegance of the algorithm itself. The real concern is operational consequence. Will the fleet slow down at peak hours? Will mixed traffic create deadlocks at intersections? Can the system adapt when aisles change, stations move, or manual forklifts enter the area? Most importantly, can the chosen architecture support growth without triggering expensive rework?
The short answer is yes: path planning matters more in mixed fleets because AGVs and AMRs operate with different assumptions, different control models, and different tolerance for uncertainty. When those differences are not handled by strong fleet-level planning logic, the result is usually congestion, underused assets, unstable cycle times, and hidden safety risk. In other words, poor path planning does not just reduce efficiency; it can undermine the business case for automation.
Why mixed AGV and AMR fleets create a harder planning problem
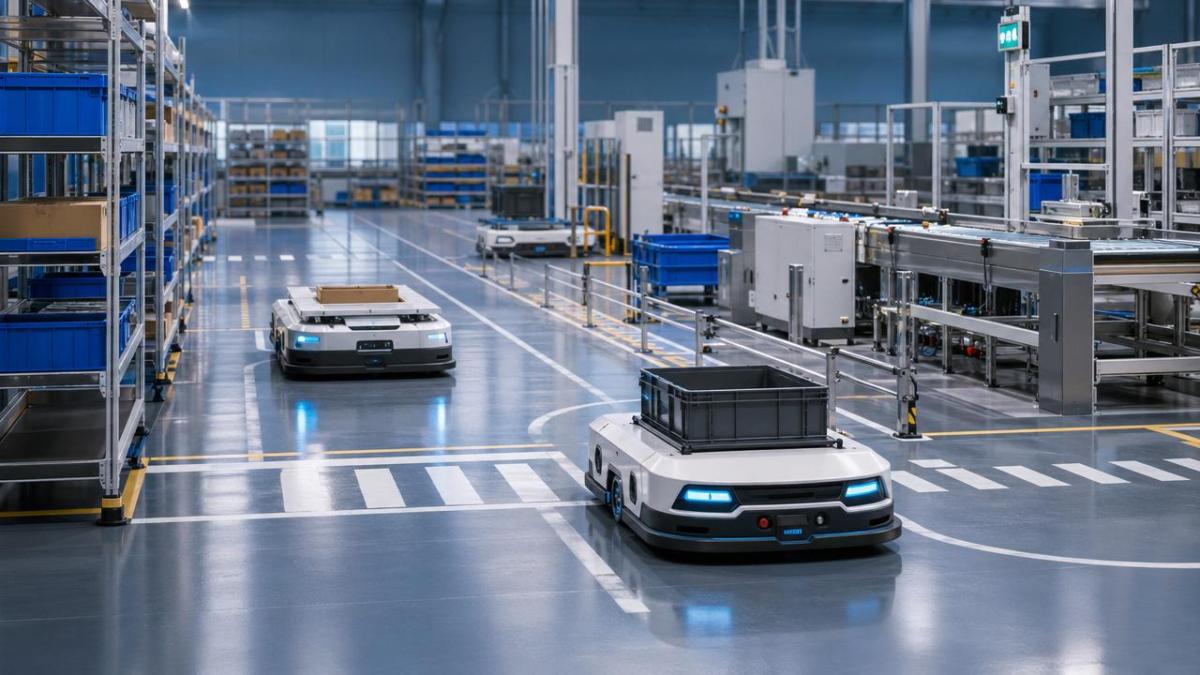
In single-technology fleets, navigation logic is relatively easier to standardize. Traditional AGVs often follow predefined routes, markers, magnetic tape, QR codes, or highly structured guidance paths. Their strengths are predictability, repeatability, and straightforward validation in stable workflows. AMRs, by contrast, are designed for dynamic navigation. They can reroute around obstacles, adjust speed based on local conditions, and react to changing environments with more autonomy.
When both systems coexist, the facility is no longer governed by one movement philosophy. Some vehicles depend on fixed traffic logic, while others continuously compute movement decisions in real time. That mismatch changes the planning burden. The fleet management layer must coordinate fixed-path discipline with dynamic autonomy, while also accounting for human workers, forklifts, variable load priorities, and physical bottlenecks such as narrow aisles, crossings, elevators, and work cells.
This is why AGV AMR path planning algorithms become more important in mixed fleets than in pure AGV or pure AMR deployments. The algorithm is no longer choosing only the shortest route. It must balance route availability, vehicle priority, collision avoidance, task urgency, battery status, station occupancy, and traffic rules across machines with different mobility behavior. That complexity directly affects whether the system behaves like a synchronized production asset or a collection of robots competing for space.
What project managers should care about most: business outcomes, not algorithm labels
Vendors often describe navigation with terms such as A*, Dijkstra, SLAM, multi-agent planning, traffic control, or hybrid orchestration. These terms matter technically, but they do not help much unless they are tied to measurable outcomes. Project managers should focus on what the path planning system enables at the operational level.
First, look at throughput stability. A weak path planning design may perform well in demonstrations but degrade sharply when vehicle count rises or when multiple missions compete for the same area. What matters is not peak speed on an empty floor, but sustained flow under production conditions. If cycle times become unpredictable during shift change, replenishment peaks, or dispatch surges, the project will struggle to deliver reliable ROI.
Second, assess congestion handling. In mixed fleets, congestion is not just a routing issue. It is a systems issue involving dispatch logic, intersection control, waiting zone design, and task prioritization. Good algorithms reduce localized traffic waves before they propagate across the plant. Poor ones allow small delays to cascade into queue buildup, idle equipment, and station starvation.
Third, examine recovery behavior. Real factories are not static. Pallets may be misplaced, temporary barriers appear, operators may stop in travel lanes, and process changes may alter the map. Strong path planning does not just optimize normal operation; it recovers gracefully from abnormal conditions. That recovery capability often separates scalable systems from brittle ones.
Why shortest path is often the wrong goal in real facilities
One of the most common misunderstandings in automation planning is assuming that the best algorithm is the one that finds the shortest route. In actual mixed AGV and AMR environments, the shortest path can be operationally inferior. A route that is shortest in distance may pass through the busiest crossing, conflict with manual logistics, or block a high-priority AGV lane.
The more relevant objective is usually system-level efficiency rather than local route optimality. That means the algorithm should minimize total delay, avoid contention, and maintain predictable task completion times across the fleet. Sometimes a slightly longer path is the better decision if it reduces interference with critical traffic or keeps high-value processes supplied on time.
For project leaders, this distinction is important during proof-of-concept reviews. A demo that highlights agile rerouting may look impressive, but if the broader coordination layer is weak, the system can still underperform at scale. Ask whether the planning engine optimizes individual robot movement or overall fleet productivity. The difference has direct budget and capacity implications.
How path planning affects safety, compliance, and operational trust
Safety in mixed fleets is not defined only by onboard sensors and emergency stops. It is also shaped by planning quality. If routes repeatedly force vehicles into contested spaces, blind corners, or heavy pedestrian areas, even technically compliant robots may create an unsafe operating pattern. The safest fleet is not merely one that can stop in time; it is one that avoids generating frequent conflict situations in the first place.
This matters especially where AGVs and AMRs share corridors with operators or forklifts. AGVs may behave in highly predictable ways, while AMRs may slow, yield, or reroute more dynamically. Without a coherent planning framework, human workers may struggle to form reliable expectations about robot behavior. That reduces operational trust and often leads to workarounds, blocked lanes, or manual intervention.
From a project management perspective, this creates hidden cost. Every time supervisors must step in to resolve traffic confusion, the automation system loses part of its labor-saving value. Strong AGV AMR path planning algorithms help standardize movement behavior across mixed fleets, improving not only safety outcomes but also workforce acceptance and daily manageability.
Where mixed-fleet projects typically fail
Most mixed-fleet problems do not begin with robot hardware. They begin with underestimating coordination complexity. One common failure is deploying AGVs and AMRs under separate software layers with weak interoperability. Each fleet may work reasonably well on its own, but once they share physical space, route conflicts and dispatch inefficiencies become difficult to manage.
Another common issue is validating only low-density scenarios. A pilot may succeed with three vehicles and stable routes, then fail in production with fifteen vehicles, seasonal layout changes, and priority exceptions. Path planning must be stress-tested for queue formation, deadlock risk, blocked stations, charging contention, and mission reprioritization.
A third failure point is ignoring facility design. No algorithm can fully compensate for poor traffic geometry. If buffer zones are undersized, crossings are too tight, charging stations are badly placed, or one aisle becomes a mandatory chokepoint, the planning software will be forced into constant compromise. Project managers should treat layout and algorithm design as one system, not two separate workstreams.
Questions to ask vendors before selecting a fleet solution
If you are evaluating a mixed AGV and AMR deployment, ask vendors questions that reveal operational substance rather than presentation polish. Start with multi-robot coordination. Can the system plan globally across the full fleet, or is each robot mostly making local decisions with limited central control? Hybrid models can work, but the division of responsibility must be clear.
Ask how the platform handles traffic priority. Can you assign rule-based precedence to line-feeding AGVs, urgent replenishment AMRs, or vehicles carrying sensitive payloads? In real operations, not all missions are equal. The path planning algorithm should support business priorities, not just geometric navigation.
Ask about deadlock prevention and congestion prediction. Does the system simply react when a lane becomes blocked, or can it anticipate contention and reroute before queues form? Preventive logic usually becomes more valuable as fleet density rises.
Also request evidence from comparable environments. Metrics should include mission completion time variance, intersection delay, throughput under peak load, recovery time after obstruction, and performance after layout changes. For TSV-style technical due diligence, these data points are far more meaningful than generic claims about “smart navigation.”
What good implementation looks like in practice
A strong mixed-fleet deployment usually starts with traffic segmentation. Not every area should be equally dynamic. High-predictability corridors may be reserved for structured AGV movement, while AMRs handle more variable routes in less constrained zones. This does not reduce flexibility; it creates controllable flexibility.
Second, successful teams define operational rules early. These include intersection behavior, pedestrian zones, one-way lanes, waiting areas, charging strategy, and priority logic by task type. Path planning algorithms perform better when the environment includes intentional traffic policy rather than uncontrolled freedom.
Third, mature deployments rely on simulation before commissioning. Simulation should not only test route feasibility but also mission mix, congestion peaks, and exception handling. For project managers, simulation results can provide a clearer basis for capacity planning, capital justification, and phased rollout decisions.
Finally, good implementations plan for change. Product mix evolves, station locations move, and throughput targets increase. The path planning system should be maintainable by the operating organization without excessive vendor dependence. If every map update or rule adjustment requires specialist intervention, long-term scalability becomes expensive.
How to evaluate ROI beyond robot count and labor savings
Many business cases for automation focus on headcount reduction or simple transport replacement. In mixed AGV and AMR fleets, ROI is often driven more by flow reliability than by direct labor substitution. Better path planning can reduce line stoppage risk, lower WIP accumulation, improve schedule adherence, and increase the usable capacity of the same number of vehicles.
That means two deployments with identical hardware can produce very different financial outcomes depending on the quality of their planning logic. A fleet that avoids congestion and maintains stable cycle times may need fewer robots, less floor intervention, and less supervisory effort. A poorly planned fleet may require additional vehicles just to compensate for inefficiency, which increases capital cost without solving the root cause.
For decision-makers, this is the key strategic takeaway: AGV AMR path planning algorithms are not a hidden technical detail. They are a determinant of asset utilization, safety performance, operational resilience, and expansion cost. In mixed fleets, the navigation layer directly shapes whether automation remains an isolated pilot or matures into a plant-wide logistics platform.
Conclusion: path planning is the control point that determines whether mixed fleets scale
Mixed AGV and AMR fleets promise flexibility and productivity, but they also introduce coordination challenges that many projects underestimate. Path planning matters more in these environments because the fleet must reconcile fixed guidance, autonomous rerouting, shared space, and changing operational priorities in real time.
For project managers, the right evaluation approach is straightforward: focus less on algorithm branding and more on measurable fleet behavior. Look for evidence of stable throughput, low congestion, safe conflict avoidance, graceful recovery, and scalable rule management. Those are the indicators that the planning layer is mature enough to support real industrial performance.
In practical terms, the quality of AGV AMR path planning algorithms often determines whether a mixed fleet becomes a reliable production system or a permanent source of exceptions. If the goal is long-term automation value rather than short-term deployment optics, path planning deserves a central place in technical selection, layout design, and project governance.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)























