
Fleet software limits that show up after AMR expansion
Publication Date
author
As AMR deployments scale from pilot zones to full-site operations, hidden bottlenecks in AGV AMR fleet management software often surface fast—slowing coordination, weakening traffic control, and exposing integration gaps with WMS, MES, and ERP systems. For project managers and engineering leaders, recognizing these limits early is critical to avoiding downtime, cost overruns, and control failures during expansion.
Why software limits matter more after expansion
A pilot AMR project usually runs in a controlled zone, with limited routes, stable task priorities, and a small number of vehicle interactions. Under those conditions, AGV AMR fleet management software can appear highly capable because the operational complexity is still low. Once the same site adds more robots, more pickup points, mixed traffic, and tighter production timing, the real ceiling of the software becomes visible. What worked for 5 robots may struggle with 25. What looked smooth in one workshop may fail when connected across warehousing, production, and outbound logistics.
For project leaders, this is not only a technical issue. It is a business risk issue. Expansion changes the decision criteria from “Can the system run?” to “Can the system coordinate reliably under load?” In integrated facilities, the answer depends on scheduling logic, map management, traffic conflict handling, task orchestration, API maturity, alarm visibility, and the ability of AGV AMR fleet management software to support future process changes without major redevelopment.
Where these limits usually appear in real operating scenarios
The same software does not fail in the same way everywhere. Limits emerge according to business scenario, layout density, and system coupling. For this reason, project teams should evaluate AGV AMR fleet management software by use case rather than by brochure claims.
Scenario 1: Warehouse replenishment with predictable routes
In a straightforward warehouse replenishment environment, route patterns are often repetitive and traffic rules are easier to standardize. Here, fleet software limits usually show up in task batching, charging strategy, and queue management at high-demand stations. If too many AMRs are sent to the same aisle or loading point, local congestion spreads quickly. A weak scheduling engine may keep assigning tasks without understanding that throughput is falling.
Scenario 2: Production feeding with strict takt time
In line-side feeding, the challenge is not just movement but timing precision. A delayed parts delivery can stop a machine or disrupt assembly balancing. In this setting, AGV AMR fleet management software must coordinate with MES events, material call triggers, and exception handling. Software that performs well in warehouse missions may struggle here if it cannot prioritize urgent jobs dynamically or re-route around blocked zones without human intervention.
Scenario 3: Mixed manual and autonomous traffic
Many factories expand AMR fleets into areas shared with forklifts, carts, and pedestrians. This is where traffic logic becomes a major differentiator. Basic fleet platforms often rely on simple right-of-way rules, but mixed traffic requires smarter zone policies, intersection reservation, speed adaptation, and operational visibility for supervisors. If the AGV AMR fleet management software cannot model these realities, safety buffers grow, average speed drops, and the expected labor savings fade.
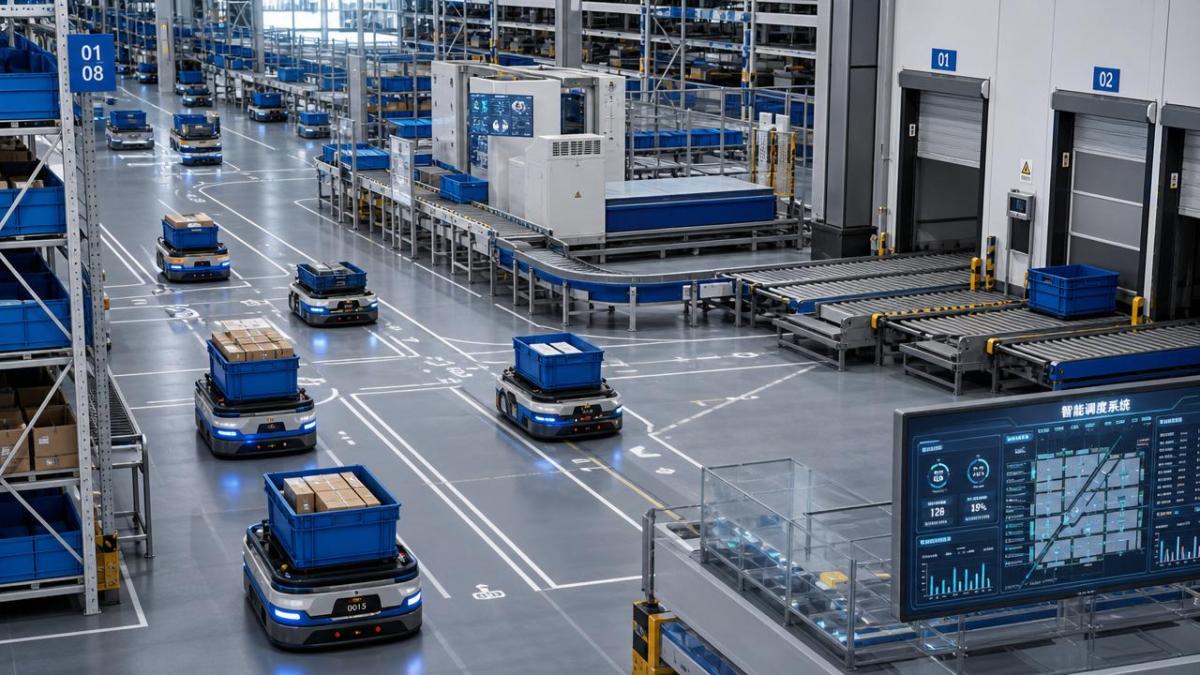
Scenario 4: Multi-workshop or multi-floor expansion
A pilot often stays in one area. Expansion usually does not. Once AMRs move across workshops, elevators, fire doors, or separate operational cells, map governance becomes far more complex. Software limits appear in map version control, localization transitions, permissions, and fallback logic when one subsystem becomes unavailable. If one map change affects another zone unexpectedly, rollout speed slows and trust in the platform declines.
Scenario 5: High-variability operations with frequent process change
Electronics, contract manufacturing, and project-based production environments often change flows rapidly. In these cases, the problem is not only scale but adaptability. AGV AMR fleet management software may become the bottleneck if route creation, task templates, and system rules require vendor intervention for every process update. A platform that lacks configurable workflow logic can turn agile operations into a maintenance-heavy program.
Scenario comparison: what project managers should evaluate first
The most common software limits hidden during pilot success
The biggest mistake in expansion planning is assuming pilot performance represents full-scale readiness. In practice, several limits remain invisible until fleet density rises.
1. Scheduling that works only at low robot counts
Many systems dispatch adequately when vehicle interaction is simple. After expansion, the AGV AMR fleet management software may over-prioritize nearest-task assignment while ignoring downstream congestion, battery state, or station wait time. The result is apparent utilization but poor flow efficiency.
2. Traffic control without true conflict intelligence
Deadlocks and stop-and-go patterns often appear not because AMRs cannot navigate, but because the fleet layer cannot govern shared movement well enough. In larger deployments, simplistic zone locking becomes a throughput penalty.
3. Weak integration with enterprise systems
Expansion typically increases dependencies on WMS, MES, ERP, and sometimes SCADA or quality systems. If the AGV AMR fleet management software has shallow APIs, unstable connectors, or unclear data ownership, task latency and information mismatches become recurring operational issues.
4. Limited observability for supervisors
When only a few robots operate, supervisors can compensate manually. At scale, the software must expose cause-level visibility: why a task was delayed, where queue pressure is building, and which rules triggered re-prioritization. Without this, teams react to symptoms instead of root causes.
5. Change management that depends too much on the vendor
A scalable platform should allow trained site teams to update operational parameters safely. If every workflow change requires external engineering support, expansion becomes expensive and slow, especially across multiple factories.
How needs differ by stakeholder and site maturity
Project managers, automation engineers, plant operations leaders, and procurement teams often look at the same AGV AMR fleet management software from different angles. Aligning these viewpoints early reduces rework later.
Practical fit guidance by application scenario
If your site has stable routes and low process change, prioritize robust dispatching, congestion handling, and charging optimization. If your site depends on just-in-time production delivery, prioritize event-driven integration and guaranteed response logic. If your operation spans many zones, demand strong map governance and subsystem resilience. If your business changes workflows often, insist on configurable rules and open interfaces rather than custom-coded dependence.
A useful buying principle is this: match the software to the most difficult operating hour, not the average hour. That is when the true value of AGV AMR fleet management software is tested. Peak shift changes, urgent material calls, blocked routes, and partial system failures reveal whether the platform supports scale or simply survives it.
Common misjudgments during AMR expansion
One common misjudgment is evaluating only robot hardware while treating fleet software as a standard layer. In reality, the software often determines usable throughput more than nominal robot specifications do. Another mistake is assuming integration can be postponed until after deployment. For many sites, WMS and MES connectivity is not an upgrade; it is core operating infrastructure.
Teams also underestimate the impact of exception scenarios. Most vendors can demonstrate ideal flows. Fewer can prove how their AGV AMR fleet management software handles blocked aisles, missing pallets, stalled lifts, or overlapping urgent missions. Finally, some organizations overlook internal governance. If no one owns data definitions, rule changes, and operational KPIs, even good software will underperform.
FAQ for project managers evaluating AGV AMR fleet management software
How many robots are enough to expose software limits?
There is no universal threshold. Limits often appear when interaction density rises, not simply when robot count rises. A site with 12 AMRs in narrow shared zones may stress the software more than a site with 30 AMRs in open routes.
Should small factories care about these issues?
Yes, especially if the factory plans phased expansion. Choosing AGV AMR fleet management software that cannot grow with process complexity creates costly migration pressure later.
What is the fastest way to test scalability before purchase?
Ask for a scenario-based simulation or reference validation using your expected traffic conflicts, integration points, task peaks, and failure cases. Do not rely only on average-cycle demos.
Final takeaway for expansion planning
For engineering-led organizations, the right question is not whether AMRs can be added, but whether the control layer can absorb operational complexity without losing visibility, timing, or reliability. High-quality AGV AMR fleet management software should fit the scenario, support enterprise integration, and remain configurable as the site evolves. If you are preparing for expansion, build your evaluation around actual application scenarios, stress conditions, and recovery logic. That is how project teams reduce trial-and-error cost and select a platform ready for real industrial scale.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)
 Sep 19, 2026How to Scope Automation Integration Services for Multi-System Factory ProjectsAutomation integration services: learn how to scope multi-system factory projects with clear workflows, interface contracts, safety boundaries, and acceptance criteria.Victor Lin (Chief Software Architect)























