Mapping Drone Waypoint Control: How to Improve Coverage Accuracy on Complex Survey Sites
Publication Date
author
Why does mapping drone waypoint control become critical on complex survey sites?
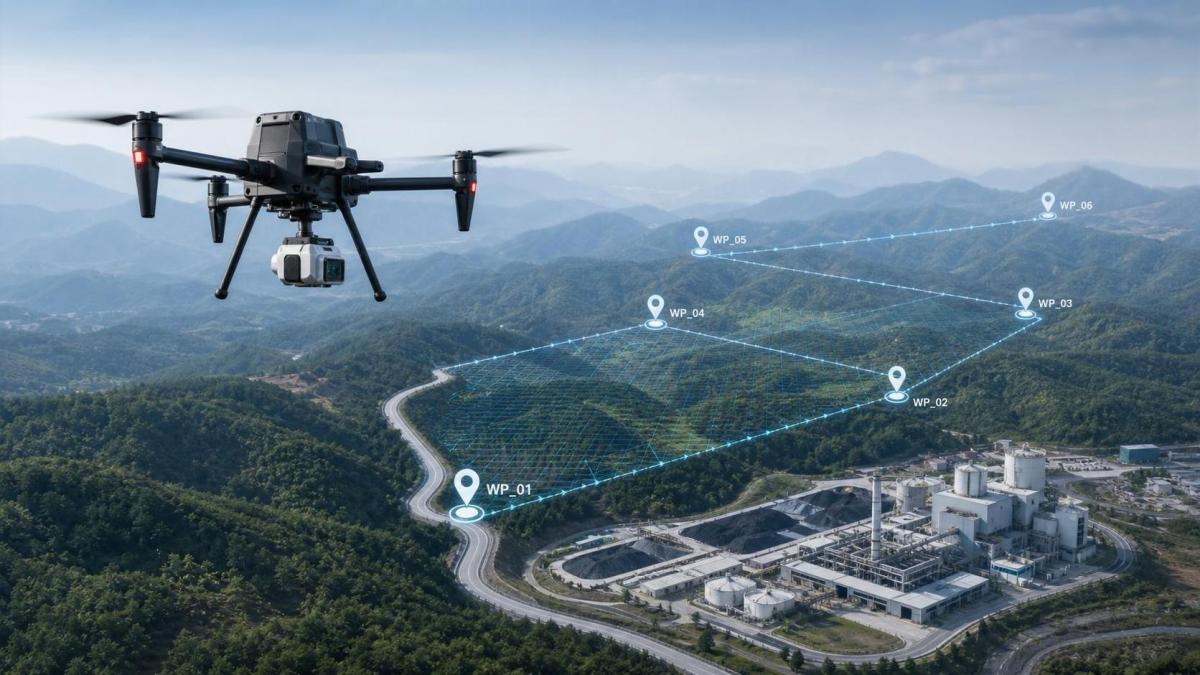
On simple open ground, flight planning errors often stay hidden. Complex sites expose them quickly through uneven terrain, obstacles, magnetic disturbance, and weak positioning consistency.
That is why mapping drone waypoint control matters far beyond route convenience. It directly affects overlap quality, edge completeness, image geometry, and how much rework follows.
In practical mapping, the drone is not just following points on a screen. It is negotiating slope changes, wind shifts, signal variation, and camera timing under moving field conditions.
A waypoint plan that looks tidy in software can still fail in the air. Common symptoms include missed corners, drift near structures, inconsistent sidelap, and unstable altitude above ground.
The more irregular the site, the more waypoint control should be treated as a measurement problem, not a navigation checkbox. That data-first mindset aligns with TSV’s engineering view.
TechStat Vanguard regularly emphasizes that parameters matter more than slogans. For UAV mapping, that means looking at measurable flight behavior instead of trusting generic automation claims.
A reliable mission usually comes from disciplined waypoint spacing, terrain-aware altitude control, and realistic turn handling. Coverage accuracy improves when those details are tuned together.
What does good waypoint control actually look like in a mapping mission?
Good mapping drone waypoint control is not simply tighter waypoint density. It is a balanced setup where flight path, speed, trigger interval, and altitude support the same coverage target.
The first sign of healthy control is predictable overlap. Frontlap and sidelap should remain stable even when the aircraft crosses ridges, pits, haul roads, towers, or fragmented parcel edges.
The second sign is smooth path execution. If the drone brakes sharply at every turn, yaw changes aggressively, or climbs late over terrain, the route is technically planned but poorly controlled.
A third sign is data continuity. Image sets should show consistent scale and limited motion blur. Point cloud reconstruction should not reveal unexpected voids between adjacent flight lines.
In real projects, the most effective waypoint strategy usually includes these checks:
- Use terrain following when elevation changes can distort ground sampling distance.
- Increase buffer distance beyond site boundaries to protect edges and corners.
- Reduce speed before complex turns or narrow corridor segments.
- Match image trigger timing to actual ground speed, not nominal cruise speed.
- Break one large mission into smaller blocks when obstacle density is high.
Simple route automation works on clean rectangles. More demanding sites need waypoint control that reflects the site’s geometry instead of forcing the site into a generic grid.
Which site conditions usually cause coverage errors first?
Operators often blame the drone too early. More often, the site itself is stressing the mission in ways the original plan did not account for.
The table below helps identify where mapping drone waypoint control needs adjustment before the next flight.
What matters here is pattern recognition. If one symptom repeats, the mission likely needs waypoint redesign, not just another flight attempt with the same settings.
TSV’s engineering logic applies well here: remove the marketing layer, isolate the parameter, then test the variable that actually influences coverage accuracy.
How should waypoint spacing, speed, and overlap be adjusted together?
This is where many mapping errors begin. Settings are often changed one at a time, even though they affect each other immediately.
If speed increases but trigger timing stays fixed, front overlap drops. If waypoint spacing is too wide near bends, the aircraft may smooth the path and cut geometry.
A better approach is to treat mapping drone waypoint control as a linked system. Start with the required ground sampling distance, then confirm altitude, trigger interval, and line spacing.
After that, verify whether the drone can physically hold those values in wind and turning segments. Software values mean little if the aircraft cannot execute them consistently.
In actual field work, these adjustments usually produce cleaner coverage:
- Add overlap margin on uneven ground instead of aiming for the minimum acceptable percentage.
- Reduce cruise speed when using a heavier payload or longer exposure time.
- Place extra waypoints before and after sharp turns to stabilize heading.
- Use separate missions for open areas and congested sections.
The point is not to make the route more complicated. It is to make each parameter believable under site conditions.
What mistakes cause rework even when the mission looks correct on screen?
The most common mistake is trusting default automation too much. Default turn radius, default overlap, and default terrain assumptions are built for average sites.
Complex sites are rarely average. Quarries, industrial yards, solar fields, and mixed urban edges all create different demands on mapping drone waypoint control.
Another mistake is designing from a two-dimensional base map only. A route can appear complete from above while still failing against slope, elevation breaks, or overhead obstruction.
There is also a persistent habit of using one mission for everything. Large mixed sites usually benefit from segmented planning, with separate blocks for terrain, corridor, and obstacle-rich zones.
Need-to-watch errors include:
- No overshoot beyond site edges, causing weak reconstruction at boundaries.
- High speed carried into turns, reducing heading stability.
- Insufficient preflight validation of GNSS quality or local interference.
- Ignoring wind direction when assigning flight line orientation.
- Using the same altitude logic for both flat pads and broken relief.
When these issues appear, rework costs usually come from field return time, extra battery cycles, and delayed processing rather than from one obvious flight failure.
How can you verify that waypoint control is good enough before committing to full capture?
A short validation flight is often more valuable than a long planning session. It reveals whether the route behaves as intended under actual wind, terrain, and signal conditions.
The quickest check is to inspect edge coverage, turn smoothness, and trigger consistency on a small representative section. That sample should include the hardest geometry on site.
If the sample shows uneven overlap or unstable heading, revise the mission immediately. Full-site capture with known defects usually wastes more time than resetting the waypoint structure.
A practical verification routine can stay simple:
- Check terrain model quality before flight planning.
- Fly a short block across the most difficult area.
- Review overlap, motion blur, and path adherence.
- Adjust speed, waypoint density, or altitude logic.
- Repeat only until the route performs consistently.
This verification style reflects the broader TSV principle that engineering confidence should come from measurable evidence, not from interface claims or brand language.
For complex survey sites, better mapping drone waypoint control usually comes from small preflight corrections made early. Review the terrain, test the hardest segment, compare execution against planned parameters, and build the final mission around what the aircraft can repeat reliably.
That next step is usually enough to reduce blind spots, improve coverage accuracy, and keep mapping results consistent when the site stops behaving like a simple grid.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 02, 2026What Documents Prove a Precision Machining Supplier Can Hold Tolerance?What documents prove a precision machining supplier can hold tolerance? Explore certificates, FAI reports, calibration, SPC, and traceability evidence to qualify suppliers with confidence.Dr. Marcus Vance
 Oct 01, 2026Can a Machining Supplier Meet Aerospace Fatigue Testing Requirements?Can a machining supplier meet aerospace fatigue testing requirements? Learn the traceability, process control, and test evidence needed for reliable aerospace parts.Dr. Marcus Vance
 Sep 30, 2026Which Industrial Robot Specifications Matter for High-Precision Assembly?Which industrial robot specifications matter most for high-precision assembly? Explore repeatability, accuracy, stiffness, vibration, calibration, and force control for reliable yields.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026How Do You Verify Servo Motor Torque Under Continuous Load?How do I verify servo motor torque under continuous load? Learn RMS torque checks, torque-speed limits, thermal derating, and real-machine testing.Chen Wei (Automation Lead Engineer)
 Oct 02, 2026ZD330 Software Configuration: Verifying Cut-List Import Before PurchaseZD330 software and machine configuration: verify cut-list imports, data mapping, labels, and workflow before purchase to reduce errors and choose with confidence.Victor Lin (Chief Software Architect)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Oct 02, 2026What affects the cost of a pick and place robot cell?Pick and place robot cost depends on throughput, tooling, vision, safety, and integration. Compare quotes confidently and avoid hidden automation costs.Chen Wei (Automation Lead Engineer)
 Oct 01, 2026What is included in a robotic system integration project cost?Robotic system integration project cost explained: compare equipment, engineering, safety, testing, installation, and lifecycle factors for smarter automation investments.Chen Wei (Automation Lead Engineer)