
Commercial drone payload capacity benchmark by mission type
Publication Date
author
A reliable commercial drone payload capacity benchmark by mission type is essential for technical evaluators comparing platforms for mapping, inspection, delivery, and agricultural operations. Rather than relying on broad vendor claims, this analysis focuses on payload-to-endurance tradeoffs, structural limits, mission realism, and system-level constraints to help engineering and procurement teams make defensible, data-driven UAV decisions.
For most technical evaluation teams, the core question is not “Which drone has the highest payload?” It is “Which drone can carry the required payload for the actual mission profile, with acceptable endurance, stability, safety margin, and integration risk?” That distinction matters because payload numbers published in brochures are often measured under ideal conditions, with reduced battery reserve, simplified flight paths, and limited environmental stress.
The practical conclusion is straightforward: the best commercial drone payload capacity benchmark must be mission-specific. A mapping UAV optimized for long endurance with a lightweight LiDAR payload should not be judged by the same benchmark as a heavy-lift spraying platform or a last-mile delivery drone. Technical evaluators need to compare usable payload, not theoretical payload, and always in relation to endurance, power draw, center-of-gravity tolerance, wind performance, and regulatory constraints.
What technical evaluators are really trying to verify
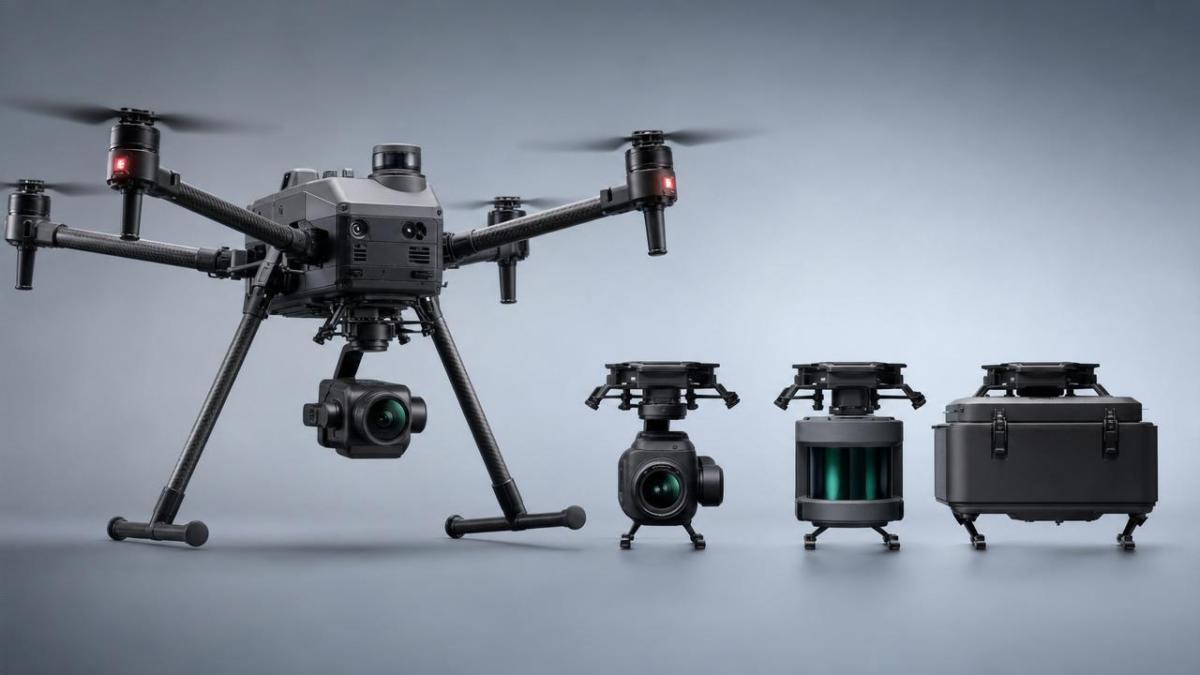
When users search for a commercial drone payload capacity benchmark, they are usually looking for a framework that supports platform selection, vendor screening, or specification drafting. The real intent is comparative evaluation. They want to know how payload capacity changes by mission type, what “good” performance looks like, and how to detect inflated claims before procurement or field testing begins.
For engineering and sourcing teams, the most important issues are consistent. First, they need to verify whether the aircraft can lift the payload safely with mission reserves intact. Second, they need to understand how much endurance is lost when a payload is added. Third, they need to assess whether the airframe, motors, propulsion system, landing gear, and flight controller remain within safe operating limits when the payload is integrated.
They are also concerned with hidden system dependencies. A drone may support the weight of a payload but fail the mission because of excessive vibration, electromagnetic interference, insufficient mounting rigidity, poor thermal management, or unstable flight behavior after the center of gravity shifts. In technical evaluation, payload capacity is never just about kilograms. It is about total mission viability.
Why a single payload number is a poor benchmark
A vendor’s headline payload figure can be useful as an initial screen, but it is a weak decision metric on its own. In practice, commercial drone payload capacity is constrained by battery chemistry, propulsion efficiency, aerodynamic drag, environmental conditions, flight speed, takeoff altitude, and legal operating envelope. Two drones with the same claimed payload may perform very differently once real mission conditions are applied.
For example, one platform may lift 10 kilograms only for a short hover demonstration at sea level with minimal battery reserve. Another may carry 8 kilograms while maintaining a 25-minute mission, stable waypoint tracking, and acceptable redundancy margins. For technical evaluators, the second platform is often more valuable because its payload figure is operationally usable.
This is why benchmarking should center on payload-to-endurance tradeoff curves rather than a single maximum value. A credible benchmark asks: what endurance remains at 25%, 50%, 75%, and 100% of rated payload? At what payload level does flight stability degrade? How much additional current draw is created by powered sensors, gimbals, pumps, winches, or onboard compute modules? These data points reveal whether the platform is suitable for field deployment rather than showroom comparison.
A mission-type benchmark framework for commercial drone payload capacity
The most effective benchmark groups UAVs by mission, because mission architecture determines what payload performance actually matters. A useful commercial drone payload capacity benchmark should separate at least four major mission classes: mapping and surveying, industrial inspection, delivery and logistics, and agricultural operations. Each has different payload expectations, endurance thresholds, and tolerance for instability.
For mapping and surveying, payloads are usually moderate in mass but sensitive in performance. A high-resolution RGB camera, multispectral sensor, LiDAR unit, gimbal, RTK module, and onboard storage may not create a heavy-lift problem in absolute kilograms, but they place strict demands on vibration control, power stability, and flight endurance. In this category, benchmark value comes from payload efficiency: how much sensing capability can be carried without collapsing area coverage per flight.
For industrial inspection, the payload may include zoom EO/IR systems, gas sensors, corona detection tools, laser rangefinders, or custom edge AI modules. Here, the benchmark must account for hover stability, close-proximity maneuvering, obstacle-rich operation, and the impact of payload geometry. A compact 2-kilogram payload may perform better than a bulkier 1.5-kilogram payload if drag and balance are more favorable.
For delivery and logistics, payload benchmarking should emphasize repeatable point-to-point transport with reserve energy for rerouting, holding, or return-to-home. In this mission type, the key comparison is not simply mass lifted. It is delivered mass over distance under regulated operating conditions, with packaging volume, loading method, and release mechanism included.
For agricultural spraying and spreading, the benchmark must focus on productive payload. Tank volume, liquid density, spray system weight, pump power draw, and flight profile all shape true field output. A spraying drone’s effective payload changes continuously during the mission as fluid mass drops, which means endurance and handling evolve dynamically. Benchmarking should therefore consider hectares per hour, refill frequency, and application uniformity rather than only initial takeoff mass.
Benchmark ranges by mission type: what “good” usually looks like
Although exact numbers vary by platform class, there are useful directional ranges that help evaluators classify options. Lightweight mapping drones often carry sensor payloads in the sub-1-kilogram to roughly 3-kilogram range, depending on whether they are fixed-wing, VTOL, or multirotor. In this category, endurance is often more valuable than maximum payload, because area coverage and data consistency drive mission economics.
Industrial inspection multirotors commonly operate with payloads from around 1 to 5 kilograms, especially when carrying stabilized optical systems, thermal cameras, and specialized sensors. What separates average from strong performance is not just lift capability, but stable hover under wind load, low vibration transfer, and sufficient battery reserve after repeated repositioning.
Delivery drones vary widely. Smaller urban or campus logistics systems may target payloads around 2 to 10 kilograms, while specialized heavy-lift platforms can exceed that range. However, technical evaluators should be cautious with outlier claims. As payload increases, airframe complexity, battery depletion rate, safety requirements, and operational risk all rise sharply. High nominal payload is meaningful only if route distance, turnaround time, and redundancy remain acceptable.
Agricultural spraying drones often represent the most visible heavy-payload commercial segment. Payload systems may range from roughly 10 to 50 liters or more, depending on aircraft class and regulations. Yet the meaningful benchmark is not tank size alone. The stronger platform is the one that sustains predictable spray swath, droplet consistency, obstacle response, and safe thermal performance while maintaining field productivity.
The most important tradeoff: payload versus endurance
If one metric dominates a commercial drone payload capacity benchmark, it is the payload-endurance curve. Every additional kilogram reduces available flight time, but not always linearly. In some designs, endurance drops gradually at lower payload fractions and then collapses once propulsion efficiency moves beyond an optimal zone. This nonlinear behavior is exactly what evaluators need to identify during technical review.
A robust benchmark should capture flight endurance at realistic mission speeds, not only hover time. It should include a battery reserve threshold, such as a mandatory 20% remaining charge at landing, and should define environmental assumptions such as wind speed, ambient temperature, and altitude. Without these controls, payload comparisons become misleading.
Evaluators should also distinguish between useful airborne time and total airborne time. If a mission requires transit, station-keeping, and return, only part of the endurance budget is available for productive work. For example, a drone that carries a payload for 28 minutes in total may provide only 12 to 15 minutes of effective inspection time after transit and safety reserve are deducted. That gap directly affects deployment economics.
Structural and integration limits often matter more than motor thrust
Many procurement teams initially focus on thrust-to-weight ratio, but platform suitability often fails at the integration layer. Payload mounting stiffness, connector reliability, power rail stability, electromagnetic compatibility, cable routing, and vibration isolation can limit usable payload long before the propulsion system reaches its theoretical maximum.
This is especially true for sensor-heavy missions. A LiDAR payload, for example, may fit within the weight budget but exceed acceptable vibration or power noise thresholds, degrading point cloud quality. A thermal inspection module may create thermal hotspots in enclosed housings. A delivery box may shift the center of gravity during acceleration or descent. These issues do not always appear in specification sheets, but they strongly influence real mission success.
Technical evaluators should therefore ask vendors for integration-specific evidence: maximum payload at specified center-of-gravity offsets, validated payload mounting load cases, vibration test results, ESC and motor temperature margins, power output specifications for auxiliary devices, and performance impacts when payloads require onboard computing or active stabilization.
How to build a defensible evaluation methodology
For teams developing an internal benchmark, the most reliable approach is to use a repeatable test matrix. Start with mission decomposition: payload mass, payload power draw, payload dimensions, center-of-gravity location, flight distance, hover requirement, speed, altitude, wind, and reserve margin. Then define pass-fail criteria based on the mission, not generic flight capability.
A practical test sequence includes unloaded baseline flights, incremental payload loading, environmental variation, and mission-profile replication. Measure takeoff current, climb performance, steady-flight consumption, hover stability, return energy margin, landing stability, and thermal behavior. If the payload includes sensors, data quality should be measured alongside flight metrics, because payload viability includes output integrity.
It is also useful to normalize performance across platforms. Instead of comparing only absolute payload, compare payload fraction relative to maximum takeoff weight, endurance retention at target payload, delivered mission time per kilogram, and operational productivity per battery cycle. These normalized metrics are more useful for cross-platform sourcing decisions.
Common mistakes when comparing commercial drone payload claims
The first common mistake is comparing different mission categories as if they were directly equivalent. A long-endurance mapping VTOL and a spraying multirotor solve different problems and should not be forced into the same benchmark logic. The second mistake is treating rated payload as continuous operational payload without accounting for reserve energy and environmental derating.
Another frequent error is ignoring payload volume and geometry. Two payloads with identical weight can create very different aerodynamic effects. This matters in crosswind operation, forward flight efficiency, and close-structure inspection. Evaluators also often overlook powered payload demand. A payload that consumes substantial electrical power reduces effective endurance even if its mass remains constant.
Finally, many teams underestimate maintainability and lifecycle effects. Repeated heavy-payload operation accelerates wear on motors, ESCs, props, arms, landing gear, and battery packs. A platform that looks acceptable in first-flight benchmarking may become expensive or unreliable at fleet scale if payload-related stress drives maintenance frequency upward.
What to ask vendors before shortlisting a platform
To turn a benchmark into a procurement tool, evaluators should request several specific data sets. These include payload-endurance curves, maximum takeoff weight definition, test conditions used for published payload ratings, battery reserve assumptions, center-of-gravity limits, auxiliary power output capability, and validated wind resistance at target payload.
They should also ask for evidence of mission-specific performance. For mapping, request area coverage and data quality metrics at the intended sensor weight. For inspection, request hover precision and vibration performance with the selected gimbal and sensor package. For delivery, request route endurance with packaging included. For agriculture, request field productivity, refill interval, and application consistency data.
Strong vendors will provide not just marketing numbers, but engineering context: test methodology, boundary conditions, and known derating factors. That level of transparency is often the clearest sign that a platform’s commercial drone payload capacity claims can be trusted in a real evaluation pipeline.
Conclusion: benchmark payload by mission reality, not brochure maximum
The most useful commercial drone payload capacity benchmark is not a ranking of who can lift the most. It is a mission-specific framework that connects payload to endurance, stability, integration risk, and operational output. For technical evaluators, the right benchmark answers a harder but more valuable question: which platform can complete the intended mission with defensible safety margin and repeatable performance?
In practical terms, mapping platforms should be judged by sensing efficiency and endurance retention, inspection drones by stability and integration quality, delivery drones by delivered mass over distance, and agricultural drones by productive application rate under field conditions. Across all categories, usable payload matters more than headline payload.
That is the standard worth applying in technical assessment and sourcing. When payload claims are translated into mission realism, procurement teams can reduce trial-and-error cost, shorten qualification cycles, and select UAV systems based on engineering truth rather than optimistic specification sheet marketing.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)























