Which vision camera for PCB inspection reduces false rejects
Publication Date
author
Selecting the right vision camera for PCB inspection can significantly reduce false rejects, shorten verification cycles, and improve yield stability across high-mix production lines. The key issue is not headline resolution alone. Reliable inspection depends on how the camera, lens, lighting, software, and motion system perform together under real production conditions.
In electronics manufacturing and broader industrial quality control, false rejects create hidden cost. They consume engineering time, interrupt throughput, trigger unnecessary rework, and distort process capability data. A data-driven evaluation method helps identify which vision camera for PCB inspection delivers repeatable defect detection without overreacting to normal variation.
Core definition and performance baseline
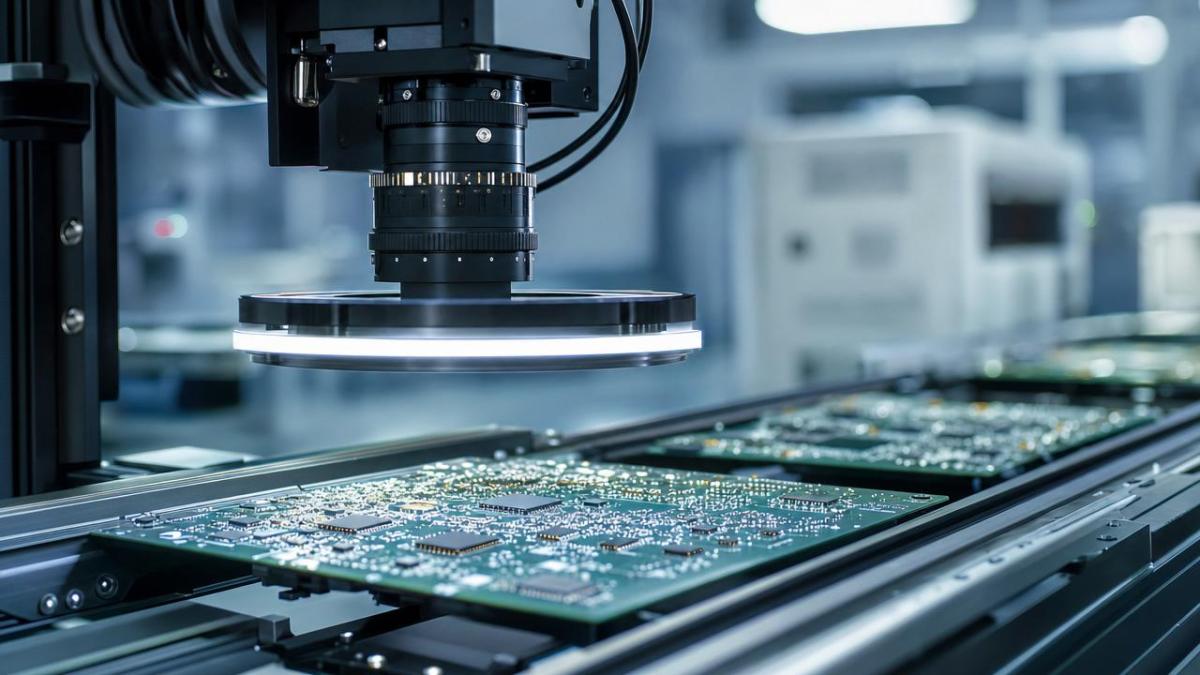
A vision camera for PCB inspection captures board images for automated optical inspection, component verification, solder assessment, code reading, and traceability tasks. In practice, the camera is only one part of an imaging chain. Inspection stability depends on sensor quality, optics, illumination, triggering, calibration, and algorithm design.
False rejects happen when acceptable boards are flagged as defective. This usually results from unstable contrast, insufficient dynamic range, poor depth coverage, vibration sensitivity, inconsistent focus, or weak model tuning. Therefore, the best vision camera for PCB inspection is the one that preserves defect visibility while tolerating normal process variation.
A useful baseline includes five measurable dimensions:
- Spatial resolution at the target field of view
- Signal-to-noise performance under production lighting
- Dynamic range for reflective pads and dark substrates
- Acquisition stability at line speed
- Integration reliability with inspection software and PLC control
When these factors are balanced, defect classification improves and nuisance alarms decline. This is why evaluating a vision camera for PCB inspection requires production data, not brochure claims.
Current industry signals shaping camera selection
PCB inspection has become more demanding as assemblies shrink, board variants increase, and traceability expectations rise. Standard 2D imaging still works for many tasks, but tolerance windows are narrower and cosmetic variation can confuse poorly tuned systems.
Several signals now influence camera choice across electronics and mixed industrial assembly environments:
These shifts explain why the search for a vision camera for PCB inspection increasingly focuses on false reject reduction rather than simple megapixel counts. Better images support better models, and better models support more stable yield decisions.
What actually reduces false rejects
The strongest false reject improvements usually come from system matching, not one isolated specification. A camera can be technically advanced yet still perform poorly if paired with the wrong lens or lighting geometry.
1. Resolution matched to defect size
Use the smallest critical defect as the starting point. Pads, bridges, missing components, polarity marks, and hairline scratches require different pixel coverage. Oversizing resolution increases data load and may amplify noise without improving classification.
2. High dynamic range and low noise
A capable vision camera for PCB inspection should separate bright solder reflections from darker substrate details. Good dynamic range reduces blown highlights and crushed shadows. Low sensor noise also helps algorithms distinguish real defects from texture variation.
3. Stable color and grayscale response
Many false rejects come from inconsistent contrast. If conformal coating, solder mask color, or ambient light changes affect image response, thresholds drift. Stable grayscale or calibrated color response supports more repeatable defect classification.
4. Global shutter for moving targets
At conveyor speed, motion blur can distort lead edges and component outlines. A global shutter vision camera for PCB inspection is often better than a rolling shutter where motion must be frozen precisely.
5. Lighting tolerance and optical repeatability
Camera selection should always be tested with dome, coaxial, bar, and low-angle lighting options where relevant. The best imaging result often comes from reducing glare before software tuning begins.
Business value across production and quality workflows
A well-chosen vision camera for PCB inspection does more than improve image quality. It changes how quickly a line reaches stable operation and how confidently quality data can be used across engineering, maintenance, and traceability systems.
- Lower false reject rates reduce manual review workload
- Fewer unnecessary stops improve cycle consistency
- Clearer defect images strengthen root cause analysis
- Better recipe stability shortens new product introduction validation
- Consistent image archives improve audit and traceability confidence
This value extends beyond electronics. Similar imaging principles are now used in medical devices, automotive modules, aerospace electronics, and industrial controls, where acceptable variation must be separated from critical defect conditions.
Typical camera categories and fit by inspection task
No single vision camera for PCB inspection fits every board and every defect mode. Selection should reflect field of view, takt time, board topology, and defect risk.
For many lines, a hybrid approach works best. A 2D vision camera for PCB inspection handles most checks efficiently, while 3D stations focus on height-critical risks that commonly trigger ambiguous 2D results.
Practical evaluation method before final selection
A disciplined trial prevents expensive mistakes. Instead of comparing generic camera datasheets, evaluate candidate systems against actual boards, actual defects, and actual throughput limits.
- Define the top defect classes causing escapes or false rejects.
- Measure required pixel density for the smallest critical feature.
- Test multiple lighting geometries with the same camera.
- Run golden boards and borderline boards through repeated cycles.
- Track false reject rate, miss rate, and review burden separately.
- Verify trigger timing, data transfer, and software compatibility.
- Check long-shift thermal stability and focus retention.
This method reveals whether a vision camera for PCB inspection performs consistently in real production, not just in controlled demonstrations. It also exposes hidden integration risks early.
Implementation cautions and next-step direction
Common selection mistakes include buying excessive resolution, ignoring lens quality, skipping calibration routines, and evaluating cameras without representative defect samples. Another frequent error is tuning thresholds around ideal boards only, which inflates false rejects once process variation returns.
The strongest path forward is to build a comparative scorecard. Include measurable image contrast, defect capture consistency, false reject rate, cycle impact, maintenance effort, and software interoperability. That scorecard should guide the final vision camera for PCB inspection decision.
For teams seeking engineering truth rather than marketing language, the question is simple: which system produces the most stable inspection decision under realistic variation? Start with defect physics, verify with line trials, and choose the vision camera for PCB inspection that reduces noise in both images and decisions.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 04, 2026How Should You Compare 5-Axis CNC Machine Accuracy Claims?How do I compare 5-axis CNC machine accuracy claims? Learn how to assess standards, thermal stability, TCP accuracy, and real-world test evidence.Dr. Marcus Vance
 Oct 03, 2026Is Edge Computing Necessary for Real-Time Quality Inspection?Is industrial edge computing necessary for real-time quality inspection? Explore how latency, data volume, reliability, and control integration shape the right architecture.TSV Data Lab
 Oct 02, 2026What Documents Prove a Precision Machining Supplier Can Hold Tolerance?What documents prove a precision machining supplier can hold tolerance? Explore certificates, FAI reports, calibration, SPC, and traceability evidence to qualify suppliers with confidence.Dr. Marcus Vance
 Oct 01, 2026Can a Machining Supplier Meet Aerospace Fatigue Testing Requirements?Can a machining supplier meet aerospace fatigue testing requirements? Learn the traceability, process control, and test evidence needed for reliable aerospace parts.Dr. Marcus Vance
 Sep 30, 2026Which Industrial Robot Specifications Matter for High-Precision Assembly?Which industrial robot specifications matter most for high-precision assembly? Explore repeatability, accuracy, stiffness, vibration, calibration, and force control for reliable yields.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026How Do You Verify Servo Motor Torque Under Continuous Load?How do I verify servo motor torque under continuous load? Learn RMS torque checks, torque-speed limits, thermal derating, and real-machine testing.Chen Wei (Automation Lead Engineer)
 Oct 02, 2026ZD330 Software Configuration: Verifying Cut-List Import Before PurchaseZD330 software and machine configuration: verify cut-list imports, data mapping, labels, and workflow before purchase to reduce errors and choose with confidence.Victor Lin (Chief Software Architect)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)