
When Sub-Pixel Vision Accuracy Stops Matching Production Results
Publication Date
author
When machine vision sub-pixel recognition accuracy looks perfect in lab validation but fails to match production results, quality and safety risks rise fast. For QC teams and safety managers, the real question is not headline precision, but how optics, vibration, lighting, calibration, and throughput affect repeatable inspection performance on the factory floor.
What machine vision sub-pixel recognition accuracy really means
In industrial inspection, machine vision sub-pixel recognition accuracy refers to the ability of an imaging and algorithm stack to estimate an edge, center point, gap, angle, or position with finer granularity than a single sensor pixel. In theory, that sounds like a breakthrough. If one pixel equals 20 microns, a sub-pixel method may report location changes of a few microns. For engineering teams, however, that number only matters when it remains stable across shifts, parts, operators, temperatures, and line speeds.
This is where confusion often starts. Sub-pixel measurement is not the same as system accuracy, process capability, or production-grade repeatability. A lab setup may produce a very clean image, controlled exposure, fixed part positioning, and little vibration. Under those conditions, machine vision software can model edges with impressive mathematical precision. Once deployed in production, the same system must deal with dust, reflective surfaces, moving conveyors, changing ambient light, lens drift, thermal expansion, and part variation. The algorithm may still calculate a result to three decimal places, but the result may no longer represent the physical truth.
For quality control teams, this distinction matters because false confidence in machine vision sub-pixel recognition accuracy can lead to escaped defects, unnecessary rejects, and unstable statistical process control. For safety managers, the stakes can be even higher when vision is used for presence verification, alignment before robotic motion, battery cell inspection, or aerospace component validation. Precision claims without production validation create hidden risk.
Why the topic matters more in modern production environments
Across advanced manufacturing, inspection tasks are becoming tighter while production lines are becoming faster. Edge AI cameras, smart sensors, robotic cells, and automated sorting systems now operate in environments where a small measurement error can trigger a larger process failure. Industries such as aerospace, electronics, medical devices, battery manufacturing, precision machining, packaging, and UAV component assembly all depend on reliable visual measurement, not just attractive benchmark claims.
TechStat Vanguard’s engineering viewpoint is simple: parameters do not lie, but isolated parameters do not tell the whole story either. A sub-pixel claim should never be evaluated alone. It must be interpreted alongside optical resolution, depth of field, illumination stability, sensor noise, calibration method, target geometry, and line dynamics. In other words, machine vision sub-pixel recognition accuracy is meaningful only inside the full measurement chain.
This broader perspective is essential because production decisions are often made using supplier datasheets, short demos, or controlled proof-of-concept trials. Those inputs can be useful, but they rarely expose the degradation mechanisms that appear during 24/7 operation. A system that measures a gauge block beautifully may struggle with oily stamped metal, semi-transparent film, textured composites, or vibrating fixtures. The gap between validation and production is rarely caused by one dramatic failure. More often, it comes from multiple small deviations that add up.
The main reasons lab results stop matching factory-floor results
The first cause is optical mismatch. Lens distortion, insufficient magnification, poor telecentricity, and inconsistent focus all change the shape of the edge that the software is trying to estimate. If the edge profile changes, the sub-pixel model changes too. The system may still return a value, but its repeatability drifts.
The second cause is lighting instability. Sub-pixel algorithms depend heavily on edge contrast and grayscale transition. Small changes in backlight intensity, LED aging, glare, shadow, or surface reflectivity can shift the estimated edge position. This is especially common with polished metal, solder joints, films, glass, and curved plastic parts.
The third cause is mechanical motion. Conveyor vibration, fixture play, robot approach variation, and part bounce introduce blur and position inconsistency. A mathematically sophisticated algorithm cannot recover information that was never captured cleanly by the sensor.
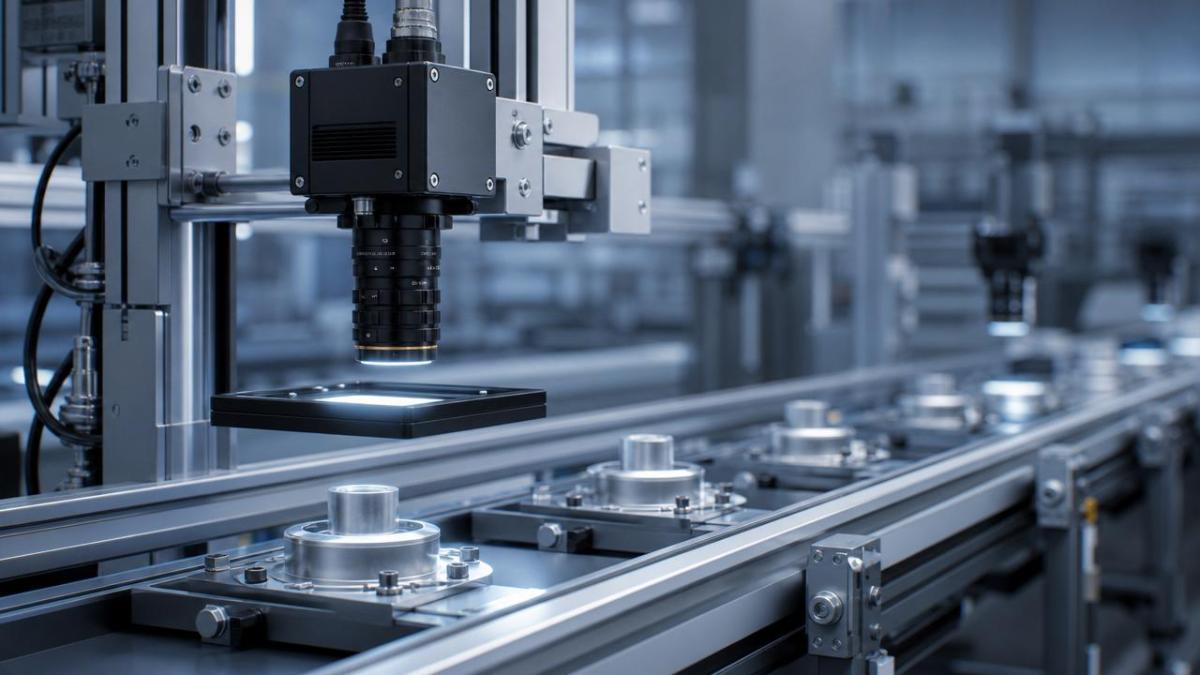
The fourth cause is calibration drift. A camera that was calibrated during installation may slowly deviate due to impact, maintenance changes, thermal cycles, or mount movement. Even a minor shift in camera angle or working distance can alter dimensional conversion from pixels to real units. The fifth cause is throughput pressure. At higher line speeds, exposure time shortens, lighting demand rises, and image noise becomes more visible. Production often forces a compromise between cycle time and measurement certainty.
The sixth cause is part variation itself. Laboratory samples are often clean and representative, but real production includes burrs, rough edges, mixed finishes, slight warpage, contamination, and upstream process variation. If the algorithm was tuned on ideal samples only, it may overfit the lab and underperform in reality.
A practical industry overview for QC and safety teams
For decision-makers, the most useful way to judge machine vision sub-pixel recognition accuracy is to connect it with the inspection objective and the failure mode. The table below shows how the issue commonly appears in production settings.
Where machine vision sub-pixel recognition accuracy brings real value
Used correctly, machine vision sub-pixel recognition accuracy remains highly valuable. It enables more precise gauging than pixel counting alone, supports tighter alignment control in robotic assembly, improves trend detection for gradual tool wear, and helps reduce subjectivity in manual inspection. It can also strengthen traceability when measurement results are linked to part IDs, process windows, and nonconformance records.
For QC personnel, the value is strongest when sub-pixel measurement is treated as one element within a capability-based inspection strategy. That means checking repeatability and reproducibility, confirming gauge correlation against reference instruments, and separating algorithm precision from total measurement uncertainty. For safety managers, the value comes from reducing the chance that a visually accepted part creates downstream operational risk. In safety-critical environments, a robust vision system can support containment, verification, and preventive action, but only if its performance limits are clearly understood.
How to evaluate performance beyond the headline number
A better evaluation framework starts with five questions. First, what is the real feature size and tolerance band? Second, how many pixels actually cover that feature under production optics? Third, how stable is the grayscale edge across time and part variation? Fourth, what is the total system uncertainty after calibration, fixturing, motion, and environment are included? Fifth, does the measurement remain capable at full line speed rather than reduced demo speed?
These questions help teams avoid a common mistake: accepting a sub-pixel claim as if it were equivalent to guaranteed dimensional accuracy. A more reliable method is to require production-like validation. Use real parts from multiple lots, include shift variation, run tests at operating throughput, and monitor drift over time. Compare machine outputs against a trusted reference such as a calibrated microscope, CMM workflow, gauge block standard, or metrology-grade comparator, depending on the application.
It is also wise to examine failure behavior, not only average performance. Ask what happens when the surface becomes brighter, the part tilts slightly, or contamination appears. Systems that fail gracefully and trigger alarms are safer than systems that continue reporting overconfident numbers under degraded conditions.
Implementation guidance for stable production results
The most effective path is cross-functional. Quality, safety, manufacturing engineering, automation teams, and suppliers should agree on acceptance criteria before deployment. Those criteria should include not just nominal accuracy, but repeatability, false reject rate, missed defect rate, calibration interval, maintenance triggers, and environmental limits.
In practice, several actions usually improve results. Use optics selected for the actual field of view and tolerance requirement rather than a generic camera package. Stabilize illumination with controlled geometry and documented intensity checks. Reduce mechanical vibration at the mount and fixture level. Validate exposure settings at real cycle time. Build recalibration checkpoints into preventive maintenance. Most importantly, test on the ugliest acceptable parts, not just the best samples.
For plants with multiple lines or global sites, standardization matters. A machine vision sub-pixel recognition accuracy target that works in one cell may not transfer cleanly to another if lighting hardware, mounting stiffness, firmware revision, or operator procedures differ. Version control, benchmark datasets, and traceable parameter management are essential for consistent replication.
A measured path forward for quality and safety leaders
The core lesson is straightforward: machine vision sub-pixel recognition accuracy is a useful engineering capability, but it is not a free pass to production certainty. Lab precision can be real and still be incomplete. What matters on the factory floor is the repeatable conversion of image information into trustworthy decisions under real operating stress.
For quality control teams, the priority is to connect sub-pixel measurement with process capability, containment strategy, and traceable validation. For safety managers, the priority is to understand where visual measurement errors can escalate into operational or product risk. Organizations that evaluate the full chain—from optics and lighting to calibration and throughput—will make better decisions than those guided by marketing adjectives or isolated benchmark claims.
At TechStat Vanguard, the engineering standard remains clear: do not ask whether a system can report sub-pixel values; ask whether those values stay credible when production reality pushes back. That is the difference between impressive demos and dependable industrial truth.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)
 Sep 19, 2026How to Scope Automation Integration Services for Multi-System Factory ProjectsAutomation integration services: learn how to scope multi-system factory projects with clear workflows, interface contracts, safety boundaries, and acceptance criteria.Victor Lin (Chief Software Architect)























