
Machine vision for quality inspection: why defects still get missed
Publication Date
author
Machine vision for quality inspection promises speed, consistency, and scalable defect detection, yet critical flaws still slip through in real production environments. For quality and safety leaders, the issue is rarely the camera alone—it is the gap between laboratory assumptions and factory-floor variability. This article examines why missed defects persist and what engineering teams must verify to improve inspection accuracy.
In high-mix manufacturing, safety-critical assembly, and precision machining environments, a missed defect is not a minor software issue. It can become a warranty event, a line stoppage, a supplier dispute, or a compliance risk. For teams evaluating machine vision for quality inspection, the most important question is not whether a demo detects defects under ideal lighting, but whether the full inspection cell can maintain repeatable performance across 3 shifts, changing operators, variable parts, dust, vibration, and upstream process drift.
That distinction matters to procurement leaders and quality managers alike. A system specified only by camera resolution or AI branding often underperforms once cycle times tighten below 2 seconds, cosmetic variation increases, or tolerances shrink into the ±0.05 mm to ±0.20 mm range. Engineering truth begins with measurable conditions: contrast, depth of field, part presentation, defect classes, false reject rates, and traceable acceptance criteria.
Why machine vision for quality inspection still misses real defects
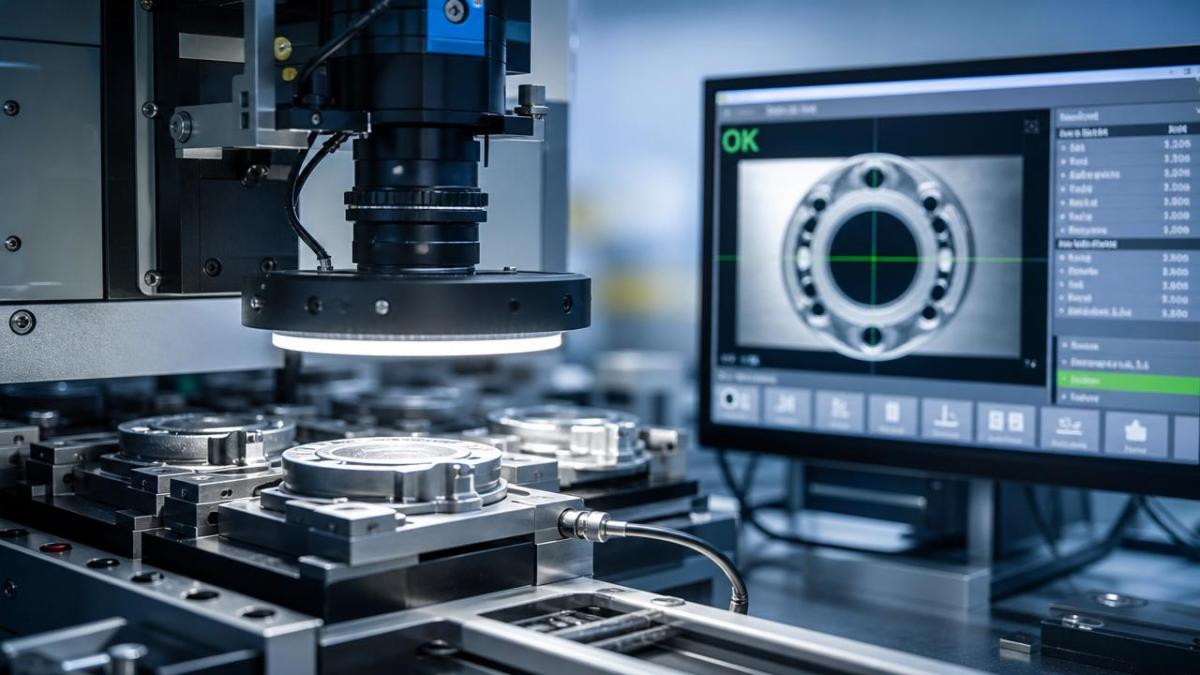
The phrase machine vision for quality inspection often suggests automated certainty, but production inspection is a chain of dependencies. A missed defect can originate from optics, lighting geometry, trigger timing, fixture instability, contamination, labeling error, or an incomplete defect library. In most plants, failures are systemic rather than singular.
Quality and safety teams should think of inspection performance as a stack with at least 6 layers: part handling, imaging hardware, illumination, software logic, acceptance thresholds, and process control feedback. If one layer drifts by even 5% to 10%, overall defect capture can degrade sharply, especially for low-contrast scratches, shallow dents, burrs under 0.10 mm, or intermittent assembly errors.
1. Lab images do not represent factory-floor variability
Many systems are validated using clean sample sets of 50 to 200 parts, stable lighting, and ideal orientation. Real production may involve thousands of parts per shift, multiple suppliers, surface finish variation, oil residue, and thermal drift across 8 to 12 operating hours. A model that performs well on curated samples may fail when the part angle changes by 2 degrees or when ambient light leaks into the enclosure.
This is especially common in reflective metals, molded plastics with gloss variation, and assemblies with mixed materials. The camera may still capture a sharp image, yet the defect signal becomes buried in normal appearance variation. For quality inspection, image quality is not equal to defect separability.
2. Defect definitions are often incomplete or inconsistent
A machine vision system cannot reliably detect what the organization has not clearly defined. Teams frequently use broad labels such as scratch, crack, contamination, or misalignment, but production reality requires finer classification. Is a 0.3 mm surface mark cosmetic or rejectable? Does a burr become critical at 0.05 mm, 0.10 mm, or only when it appears on a sealing edge? Without defect taxonomy and severity rules, the system will alternate between over-rejecting and under-detecting.
For safety-related products, the defect library should be separated into at least 3 levels: critical, major, and minor. Each level needs measurable criteria tied to dimensions, location, frequency, and downstream risk. This is where many deployments break down, not because of AI limitations, but because engineering acceptance criteria were never formalized in machine-readable terms.
3. Throughput pressure reduces inspection robustness
Inspection performance often declines when line speed increases from pilot conditions to actual takt time. At 6 parts per minute, a station may allow multiple exposures, image stacking, or mechanical settling. At 30 or 60 parts per minute, those margins disappear. Trigger jitter of a few milliseconds, motion blur, or inconsistent standoff distance can be enough to miss edge defects and dimensional anomalies.
In B2B procurement reviews, cycle time claims should always be paired with detection conditions. A supplier should specify whether the stated performance was achieved at 1 image, 2 images, or 4 images per part; under static or moving inspection; and with what reject confidence threshold. Without those details, quoted throughput has limited decision value.
The table below shows common root causes behind missed defects and the engineering checks that matter more than headline specifications.
The key pattern is that defect misses are usually linked to variation tolerance, not brochure performance. The stronger the link between inspection design and real process capability, the lower the probability of hidden failures moving downstream.
What quality and safety teams must verify before approving a system
A robust machine vision for quality inspection project should be approved only after engineering verification, not after a polished demonstration. For procurement, this means comparing systems by measurable acceptance logic, maintenance burden, and integration discipline. For safety managers, it means identifying where missed defects create containment exposure or operator risk.
Define the inspection target in engineering terms
Before evaluating vendors, document 4 baseline items: defect type, minimum detectable size, allowable false reject rate, and required cycle time. For example, detecting a 0.2 mm nick on a matte polymer is different from detecting a 0.2 mm dent on polished aluminum. The same pixel count does not guarantee equal performance.
- Set defect thresholds by dimension and location, such as burrs above 0.08 mm on sealing surfaces.
- Specify throughput as inspected parts per minute under full line conditions, not bench conditions.
- Separate cosmetic concerns from safety-critical defects to avoid unstable reject logic.
- Require pass/fail evidence storage for traceability, ideally by batch, timestamp, and station ID.
Verify the imaging chain, not just the camera
In many sourcing discussions, the camera becomes the center of attention. In practice, lens selection, lighting angle, enclosure design, distance control, and fixturing often determine more than 60% of final detection reliability. A 12 MP camera can still miss defects if the optical setup compresses contrast or if vibration shifts the working distance outside the calibrated range.
Critical checks for the imaging stack
- Confirm repeatable part positioning within the defined tolerance window, often ±0.2 mm to ±1.0 mm depending on the feature.
- Test lighting against reflective, dark, translucent, and contaminated surfaces, not only ideal samples.
- Measure exposure and processing latency at actual line speed, especially when cycle time is below 1.5 seconds.
- Assess enclosure resistance to dust, coolant mist, and temperature swings across a full shift.
The next table summarizes practical procurement criteria for machine vision for quality inspection in demanding production settings.
For buyers, these questions filter out vague claims. For quality teams, they create a repeatable acceptance framework that can be applied across multiple plants, part families, or suppliers.
Common implementation gaps after commissioning
Even a well-designed system can lose effectiveness 30 to 90 days after launch if governance is weak. Commissioning often focuses on getting the station running, while long-term defect capture depends on maintenance discipline, retraining triggers, and ownership across quality, production, and automation teams.
Drift in fixtures, optics, and cleaning routines
A vision cell that passes FAT or SAT can degrade quietly when operators clean the lens inconsistently, fixtures loosen, or replacement lighting differs from the validated setup. Small changes accumulate. A standoff shift of 1 mm, reduced diffuser performance, or smudging on a protective window may not stop the line, but it can lower sensitivity enough to miss subtle defects.
Preventive checks should be scheduled by operating hours or lot count. In many applications, a weekly verification with golden samples and a monthly review of false accept or false reject events is a practical starting point. The exact interval depends on contamination load, line speed, and product criticality.
No closed-loop response to recurring defects
Machine vision for quality inspection should not operate as a passive sorting device alone. If the system repeatedly finds burrs, seal misalignment, missing fasteners, or print defects, that data should drive corrective action upstream. Otherwise, the plant simply automates rejection without reducing defect generation.
A practical 5-step control loop
- Capture defect images and timestamps for each reject.
- Group events by defect family, tool, cavity, supplier lot, or shift.
- Set escalation thresholds, such as 3 critical defects in 1 hour or 2 consecutive batch failures.
- Launch containment and process review before defect density increases further.
- Update the inspection rule set after verified process change, not by operator preference alone.
AI models are updated without controlled validation
In AI-assisted inspection, retraining can improve performance, but unmanaged updates can also introduce new blind spots. A model retrained on recent defects may overfit one supplier lot and become less reliable on another. Quality managers should require version control, rollback procedures, and side-by-side validation before deployment.
A disciplined approach is to validate any major model revision against a representative sample covering at least normal parts, known defect classes, marginal cases, and recent production variability. That review should include both false accept and false reject behavior, since aggressive sensitivity can disrupt output just as much as weak detection can endanger quality.
How to improve inspection accuracy without overbuying equipment
When defects are being missed, the default reaction is often to request a higher-resolution camera or a more advanced AI package. Sometimes that is justified, but many plants can improve capture performance more cost-effectively by fixing presentation, illumination, and inspection logic first. Better engineering usually delivers more value than simply buying more pixels.
Prioritize defect contrast before model complexity
If a defect is visually indistinguishable from background variation, additional software sophistication will have limited impact. Reworking the lighting geometry, adding polarizers, separating stations by defect type, or slowing the part momentarily for a stable capture often improves performance faster than changing algorithms. In many industrial use cases, one targeted mechanical improvement can outperform a full software retraining cycle.
Segment the inspection task
Trying to inspect dimensions, presence, surface quality, and print verification in one all-purpose station can reduce reliability. A better approach is to split tasks into dedicated checks: for example, one station for assembly presence, one for code reading, and one for cosmetic surfaces. This reduces compromise in optics and shortens root-cause analysis when defects escape.
Use acceptance windows tied to business risk
Not every defect deserves the same sensitivity. Safety-critical errors such as missing components, crack propagation, seal damage, or out-of-position fasteners should be inspected with tighter thresholds and stronger containment logic. Cosmetic variation with low downstream impact can use more tolerant limits to avoid unnecessary scrap or manual review load.
That risk-based structure helps balance two competing goals: catching dangerous escapes and keeping line efficiency stable. It also creates clearer communication between engineering, operations, and procurement when future upgrades are evaluated.
What procurement and quality leaders should request from suppliers
When sourcing machine vision for quality inspection, teams should request evidence that reflects operational truth rather than marketing language. The most useful proposals explain what was tested, under which constraints, how accuracy was measured, and what maintenance or retraining is required over time.
- A defect matrix showing detectable defect types, minimum size range, and excluded conditions.
- A test protocol performed on production-like parts, preferably across multiple lots or shifts.
- A maintenance plan covering cleaning, calibration checks, spare parts, and verification frequency.
- A change-control process for new SKUs, revised tolerances, and AI model updates.
- Data export and traceability options for audits, CAPA workflows, and supplier quality reviews.
For organizations operating across advanced manufacturing, aerospace supply chains, robotics, sensors, or precision machining, those details are not optional. They reduce trial-and-error cost, shorten supplier qualification cycles, and expose the gap between nominal capability and verified performance.
Missed defects in machine vision for quality inspection usually point to unresolved variability, incomplete specification, or weak validation discipline rather than a single hardware limitation. The strongest systems are built around measurable thresholds, production-realistic testing, controlled maintenance, and closed-loop feedback into the process. If your team is reviewing inspection architecture, benchmark criteria, or supplier capability for safety-sensitive production, now is the right time to evaluate the engineering details behind the claims. Contact TSV to discuss a data-driven assessment, request a tailored evaluation framework, or explore practical inspection benchmarks for your manufacturing environment.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)























