
Industrial 3D Vision Camera Supplier and Accuracy at Depth
Publication Date
author
Selecting an industrial 3d vision camera supplier is no longer about broad claims—it is about measurable depth accuracy, calibration stability, latency, and repeatable performance in real production environments. In advanced manufacturing, robotics, logistics, electronics, and precision inspection, 3D vision performance directly affects grasping success, metrology confidence, and automation uptime. This article examines how depth accuracy changes across working distance, which specifications matter most during evaluation, and how a data-driven sourcing process can reduce qualification risk while improving long-term system reliability.
Depth Accuracy as the Core Benchmark
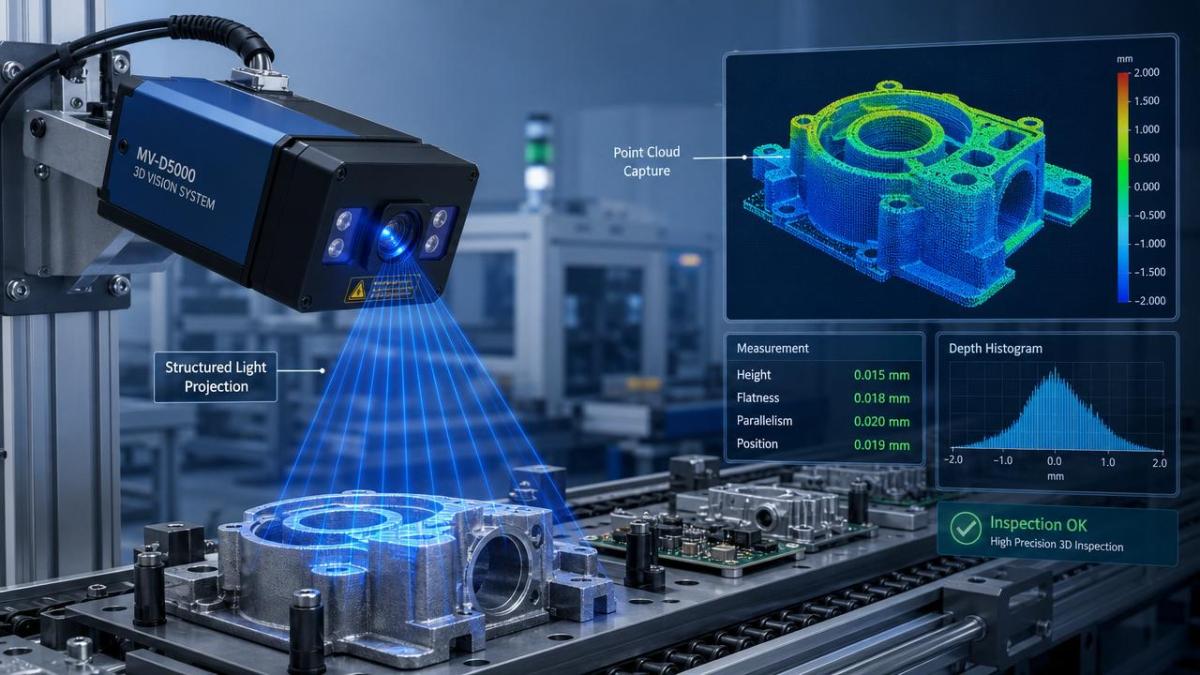
When comparing an industrial 3d vision camera supplier, the first technical question should be simple: how accurate is the camera at the actual operating depth, not just at an ideal test point? Many systems perform well in a narrow laboratory range but show rapid degradation when the target surface moves farther away, changes reflectivity, or enters a high-vibration production line. In industrial settings, depth performance must be validated across the complete usable volume.
Depth accuracy generally describes how closely measured Z-axis data matches the real-world position of an object. However, that single concept includes several layers: absolute accuracy, repeatability, point cloud density, edge reconstruction quality, and thermal drift over time. A capable industrial 3d vision camera supplier should present these metrics with explicit test conditions, including ambient light, target material, exposure settings, and mounting geometry.
For practical evaluation, “accuracy at depth” should not be read as a static brochure number. It should be interpreted as a performance curve. As distance increases, structured light contrast may weaken, stereo matching may become less stable, and time-of-flight noise may increase. The supplier that matters most is the one able to quantify this performance decay and explain the operational threshold where measurement results remain trustworthy.
What an Industrial 3D Vision Camera Supplier Should Specify Clearly
A reliable industrial 3d vision camera supplier should provide technical data that supports engineering decisions rather than marketing interpretation. Several specifications are especially important when evaluating 3D vision systems for production use.
- Working distance range: The effective near-to-far operating zone where stable 3D data can be collected.
- Z accuracy and Z repeatability: Absolute depth error and consistency under repeated measurements.
- X-Y resolution: Spatial detail captured on the target plane, affecting edge detection and small-feature inspection.
- Frame rate and latency: Critical for robotic picking, tracking, and closed-loop motion.
- Calibration stability: Resistance to drift caused by temperature variation, shock, or long operating hours.
- Surface compatibility: Performance on dark, reflective, transparent, textured, or low-contrast materials.
- Ingress and industrial robustness: Protection against dust, oil mist, vibration, and electromagnetic interference.
- Interface and software ecosystem: Support for GigE, USB3, Ethernet/IP, PROFINET, SDK maturity, and third-party integration.
These specifications should be tied to real testing methods. If an industrial 3d vision camera supplier only offers a headline resolution number without test geometry, target type, or exposure assumptions, the specification has limited sourcing value. In contrast, engineering-grade documentation reveals whether the camera will remain useful after installation, recalibration cycles, and environmental stress.
Current Industry Signals Shaping Evaluation Criteria
Across the broader industrial landscape, expectations for 3D vision have changed. Users now need not just image capture, but quantified spatial reliability. This is especially relevant as automation expands from fixed, repeatable cells to mixed-model production, mobile robotics, and adaptive inspection lines.
Under these conditions, the role of an industrial 3d vision camera supplier extends beyond hardware delivery. The supplier becomes part of the technical validation chain, supporting benchmark design, environmental testing, and interface proof. This is where a data-driven evaluation model aligns with the TSV principle that parameters, tolerances, and repeatability matter more than generalized performance claims.
Business Value of Reliable Accuracy at Depth
The right industrial 3d vision camera supplier can influence far more than imaging quality. Reliable depth accuracy improves first-pass yield, stabilizes robot motion planning, reduces false rejects in inspection, and lowers unplanned maintenance caused by vision-related downtime. In many systems, a minor depth error can cascade into gripper collision, misalignment, or dimensional escape.
From a cost perspective, weak depth performance often creates hidden expenses. These include frequent recalibration, custom fixtures added to compensate for poor vision tolerance, software tuning hours, reduced line speed, and increased engineering labor during troubleshooting. A qualified industrial 3d vision camera supplier helps avoid these costs by delivering stable data at the actual required distance and by documenting where performance limits begin.
This is particularly valuable in cross-border sourcing or multi-site deployments. When a vision platform is rolled out across several plants, consistency matters as much as peak capability. The best supplier profile is not the one with the most aggressive brochure numbers, but the one with repeatable field performance, clear tolerances, and a transparent validation history.
Typical Application Categories and Depth Priorities
Different production tasks place different demands on a camera system. An industrial 3d vision camera supplier should be evaluated according to the dominant error mode in the intended use case rather than a generic technical ranking.
This application-based approach prevents overbuying and under-specifying at the same time. It also makes comparison among industrial 3D vision options more objective, because each platform is judged against the depth risks that matter most in service.
Practical Evaluation Methods Before Final Selection
Before confirming an industrial 3d vision camera supplier, a structured verification plan should be established. The most useful evaluations simulate production reality rather than ideal demo conditions.
- Test at minimum, nominal, and maximum working distances, then compare Z error across the entire range.
- Include representative materials such as matte metal, polished metal, black polymer, cartons, and mixed textures.
- Measure repeatability after warm-up, after a long production cycle, and after environmental temperature change.
- Validate latency from capture to actionable output, not camera frame rate alone.
- Check mounting sensitivity by introducing slight vibration or fixture shift to assess calibration robustness.
- Review SDK documentation, error handling behavior, and support for PLC or robot ecosystem integration.
A disciplined benchmark can reveal whether a quoted specification is sustainable in real operation. This is also where a credible industrial 3d vision camera supplier stands out: transparent suppliers accept comparative testing, define pass-fail criteria in advance, and provide engineering support grounded in data rather than sales positioning.
A Data-Driven Next Step for Sourcing and Qualification
For organizations building a shortlist, the most effective next step is to create a specification sheet centered on depth performance, calibration durability, environmental tolerance, and integration requirements. Instead of asking who is the “best” industrial 3d vision camera supplier, define the acceptable Z error at each working distance, the permitted drift over time, the target cycle latency, and the material conditions that must be supported.
This approach reflects the wider engineering philosophy advanced by TechStat Vanguard: truth in hard-tech sourcing comes from measurable parameters, controlled comparisons, and transparent performance boundaries. In 3D vision, accuracy at depth is not a secondary detail; it is the operating foundation for reliable automation. Build supplier evaluation around evidence, and the result is a shorter qualification cycle, lower implementation risk, and a more dependable production system.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)























