
Solid-state LiDAR for autonomous vehicles: where reliability still fails
Publication Date
author
Solid-state LiDAR for autonomous vehicles promises compact packaging, lower maintenance, and scalable production, yet reliability gaps still surface in harsh vibration, thermal cycling, optical contamination, and long-duration field deployment. For technical evaluators, the real question is not whether the technology works in demos, but where performance drifts, failure modes emerge, and engineering data still falls short of procurement-grade confidence.
For procurement teams, validation engineers, and platform architects, the reliability debate around solid-state LiDAR for autonomous vehicles is no longer theoretical. It affects sensor fusion confidence, safety case documentation, spare parts strategy, and supplier qualification timelines that often run 8 to 24 weeks before any production nomination. In TSV’s hard-tech evaluation framework, the central issue is simple: marketing claims may describe peak performance, but sourcing decisions require degradation data, environmental limits, and clearly bounded failure behavior.
Compared with legacy mechanical spinning systems, solid-state architectures reduce moving parts and can improve packaging flexibility. However, “solid-state” does not mean failure-proof. MEMS mirrors, flash illumination modules, optical windows, ASICs, thermal interfaces, adhesives, and sealing materials all introduce different stress points. In autonomous driving stacks operating across -40°C to 85°C, under continuous vibration and high road contamination, even a 10% to 20% drop in effective detection consistency can materially change system-level risk.
Why reliability still breaks after the demo stage
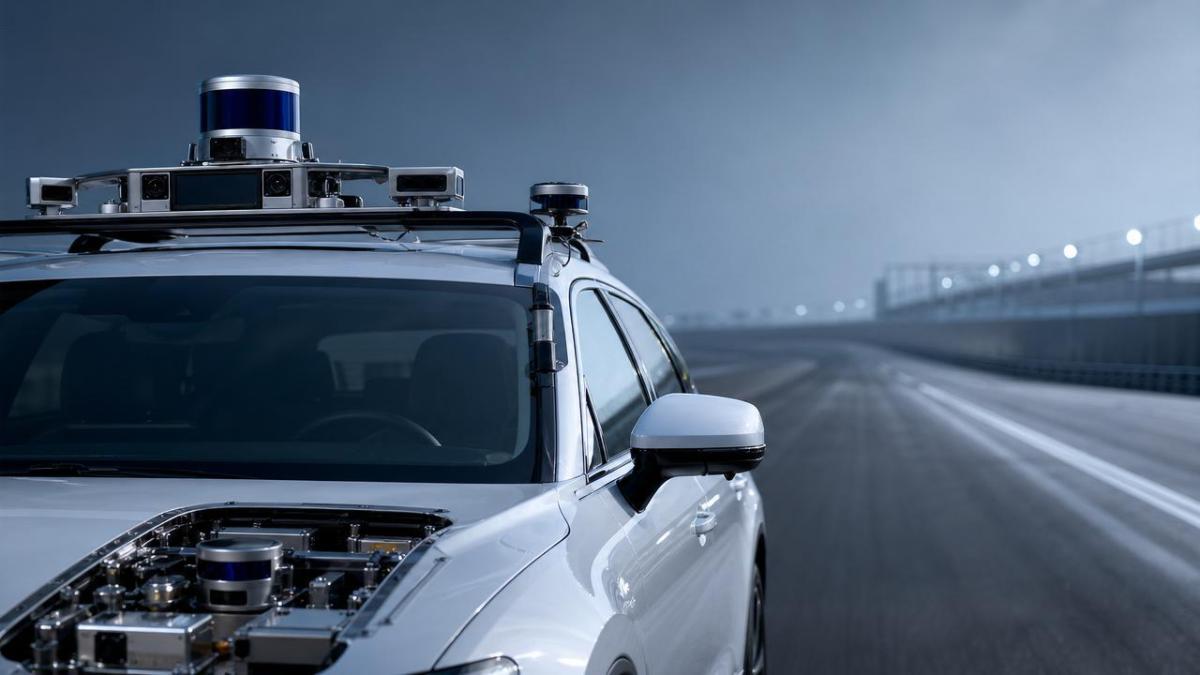
The gap between laboratory success and fleet reliability is where solid-state LiDAR for autonomous vehicles is most often misjudged. Bench demonstrations typically emphasize clean targets, stable power, fixed ambient temperature, and short-duration runs of a few hours. Real vehicle deployment introduces thousands of kilometers of vibration exposure, repeated thermal shock, airborne particulates, car wash chemistry, and software update cycles that can alter signal processing behavior.
Four recurring engineering failure zones
Technical evaluators generally see reliability problems emerge in four zones: opto-mechanical stability, thermal drift, contamination management, and long-duration calibration retention. These issues do not always create immediate hard failures. More often, they generate soft failure patterns such as range reduction at low reflectivity, higher false returns in rain spray, angular bias drift, or intermittent frame dropout under power fluctuations.
- Vibration and shock can alter optical alignment, solder integrity, or MEMS scan stability after 50 to 200 hours of road-profile testing.
- Thermal cycling from cold soak to peak enclosure temperature can shift timing calibration, beam uniformity, and receiver sensitivity.
- Dust, mud film, salt residue, and washer fluid can reduce optical transmission and raise noise floors within days in harsh road use.
- Long-duration operation may reveal drift that is invisible in 1-day demos but measurable over 500 to 1,000 operating hours.
Failure is often gradual, not binary
One major sourcing mistake is to evaluate only pass/fail status. In practice, solid-state LiDAR for autonomous vehicles often degrades along a curve. A sensor may remain “functional” while its effective point cloud quality declines at 120 meters, its edge-object recall weakens at 10% reflectivity, or its frame-to-frame consistency worsens under 15 Hz to 200 Hz vibration input. These shifts matter because perception software is tuned to statistical confidence, not only sensor uptime.
The table below summarizes where reliability claims most often diverge from procurement-grade evaluation criteria.
The key takeaway is that autonomous vehicle buyers should treat nominal performance and reliability as separate qualification tracks. A sensor that performs well on day 1 may still fail system requirements by day 90 if contamination sensitivity, internal thermal stress, or calibration drift are not quantified.
Architecture matters, but test design matters more
Different solid-state approaches carry different reliability profiles. MEMS-based LiDAR may face scan element fatigue or resonance sensitivity. Flash LiDAR may avoid beam steering components but can face thermal loading and detector saturation constraints. Optical phased array concepts promise fewer mechanical concerns, yet manufacturability and field robustness still depend on packaging precision and thermal control. For technical evaluators, the architecture label alone is insufficient unless supported by mission-profile testing.
The failure modes technical evaluators should measure first
In practical sourcing programs, the first 6 to 8 tests should not chase every possible metric. They should target the most financially consequential failure modes. For solid-state LiDAR for autonomous vehicles, those are the modes that distort perception confidence without immediately triggering a diagnostic fault. This is where engineering teams lose time: the sensor appears alive, but system-level trust erodes.
Vibration-induced optical and electronic instability
Vehicle mounting introduces random vibration, resonance peaks, and road shock that can shift optical alignment or degrade connector integrity. Even when the enclosure survives, internal changes may alter beam placement and timing. Evaluators should request test evidence across at least 3 axes, with sweep ranges such as 10 Hz to 2,000 Hz and dwell conditions aligned with actual vehicle mounting positions. A single-axis lab plot is rarely enough.
Thermal cycling and temperature-driven calibration drift
Autonomous vehicle sensors must survive cold mornings, midday solar loading, and repeated startup cycles. Reliability gaps often appear not at absolute temperature extremes, but during transitions. For example, repeated cycling between -30°C and 70°C over 100 to 300 cycles can reveal adhesive creep, lens stress, timing offset variation, or ASIC throttling behavior. The question is not only whether the LiDAR powers on, but whether its ranging and angular accuracy remain within usable limits.
Optical contamination and signal integrity loss
Road grime is one of the least glamorous and most decisive reliability variables. Thin dust layers, dried water spots, insect residue, and salt film can cut transmission enough to reduce low-reflectivity object detection. For a vehicle running in mixed urban and highway conditions, the contamination burden over 7 to 14 days may be more informative than a single IP-rated enclosure test. A reliable evaluation plan should measure point cloud degradation at multiple contamination levels, not just post-clean performance.
A practical screening matrix
The matrix below helps technical evaluators prioritize early-stage validation for solid-state LiDAR procurement.
This matrix supports a more disciplined qualification workflow. Instead of accepting broad language such as “automotive grade,” buyers can request measurable drift windows, test durations, and pre/post-test deltas that make supplier comparison possible.
How to qualify solid-state LiDAR for autonomous vehicle procurement
A reliable sourcing process should combine specification review, controlled validation, and field correlation. Many teams overinvest in feature comparison before verifying whether the test plan reflects actual duty cycles. A stronger approach is to move through 4 stages: requirements mapping, stress testing, software behavior analysis, and supply-chain readiness review.
Stage 1: Define operational limits in engineering terms
Before supplier shortlisting, evaluators should define at least 6 core limits: required detection range, reflectivity targets, environmental temperature range, acceptable false return rate, cleaning interval target, and diagnostic response behavior. If a platform requires dependable detection of dark objects at 100 meters in winter spray, that condition must appear in the specification, not remain an informal expectation.
Stage 2: Demand degradation data, not only nominal specs
For solid-state LiDAR for autonomous vehicles, procurement teams should ask for pre-stress and post-stress performance deltas. Useful requests include range reduction percentage after contamination, point cloud uniformity after vibration, and accuracy drift after thermal cycling. A supplier that can provide 3 to 5 controlled degradation plots is usually more transparent than one offering only a polished spec sheet.
Stage 3: Link sensor behavior to perception stack impact
A 5% shift in range may be manageable in one software stack and unacceptable in another. That is why sensor evaluation should include replay tests or controlled scenario comparisons at the perception layer. Technical teams should examine how point loss, timing jitter, or angular inconsistency influence obstacle classification, tracking persistence, and emergency fallback logic over 20 to 50 representative scenarios.
Stage 4: Audit supply continuity and serviceability
Reliability is not only a device property. It also depends on service response, firmware traceability, replacement logistics, and process control. Buyers should assess lead times for engineering samples and replacement units, software release documentation, change-notification practices, and field return analysis capability. A sensor with excellent performance but poor revision control can still become a program risk within 12 months.
Common procurement mistakes
- Using peak range as the primary selection metric while underweighting drift after contamination.
- Accepting short demo runs instead of requesting 500-hour or cycle-based durability evidence.
- Reviewing enclosure robustness without evaluating optical window cleaning and residue recovery.
- Ignoring how firmware updates may alter filtering behavior and effective point cloud output.
- Comparing sensors without normalizing test conditions, reflectivity, and ambient light load.
What stronger engineering evidence should look like
For decision-makers operating under TSV-style engineering scrutiny, better evidence is specific, bounded, and reproducible. The most useful supplier materials are not adjective-heavy brochures but controlled test protocols, environmental condition definitions, degradation charts, and change-management records. Reliable qualification depends on seeing how performance moves under stress, not merely how impressive it looks in ideal conditions.
Data packages worth requesting
- Environmental test matrix with temperatures, cycle counts, dwell times, and pass criteria.
- Pre/post-contamination comparison using at least 3 contamination types and recovery cleaning steps.
- Frame stability and range repeatability under representative vehicle vibration profiles.
- Long-duration drift records over 500 to 1,000 hours with periodic calibration checkpoints.
- Firmware revision history tied to point cloud output changes and diagnostic behavior.
A realistic view of adoption
Solid-state LiDAR for autonomous vehicles remains strategically important because it supports compact integration, lower mechanical complexity, and volume manufacturing potential. Yet technical evaluators should resist the false choice between optimism and rejection. The correct position is conditional adoption: proceed where the sensor’s failure envelope is well characterized, maintenance assumptions are realistic, and system-level mitigation is validated. Reliability maturity is not a slogan; it is a measured envelope of acceptable drift.
For engineering teams, CTO offices, and procurement leaders, the path forward is to benchmark sensors against application-specific stress profiles rather than generic claims. If you are comparing solid-state LiDAR platforms, refining a qualification matrix, or drafting sourcing specifications with tighter reliability thresholds, now is the time to turn broad promises into measurable acceptance criteria. Contact TSV to discuss a custom evaluation framework, review procurement-grade test checkpoints, or explore deeper hard-tech benchmarking support for your autonomous sensing program.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)























