
Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and Integration
Publication Date
author
Selecting an automotive radar sensor module for ADAS should begin with the driving function, not the maximum range shown in a datasheet. A long-range forward sensor, a short-range parking sensor, and a corner radar may all use similar radar principles, yet they need different field of view, angular discrimination, update behavior, mounting positions, and software outputs.
The practical question is not “Which radar sees farthest?” It is: which module produces stable, usable object information for the vehicle function under the conditions where that function must work? A module that detects a vehicle at long distance but cannot separate it from an adjacent-lane target may be unsuitable for adaptive cruise control. A wide-angle sensor with modest long-distance performance may be the better choice for rear cross-traffic alert or low-speed maneuvering.
For a defensible evaluation, translate each ADAS requirement into measurable sensing, tracking, integration, and validation criteria before comparing suppliers.
Start with the ADAS Function and Its Failure Boundaries
Radar selection changes materially depending on whether the intended function is forward collision warning, adaptive cruise control, automatic emergency braking support, blind-spot detection, lane-change assistance, rear cross-traffic alert, or parking assistance. These functions differ in the objects they must detect, the directions from which those objects appear, and the consequences of delayed or ambiguous detection.
A forward-driving function usually needs dependable performance along the vehicle’s travel direction, with enough range to provide useful reaction time at the intended operating speeds. It also needs to distinguish a relevant lead vehicle from roadside structures, overhead signs, guardrails, and vehicles in neighboring lanes. In this setting, range alone has limited value without strong range separation, velocity measurement, and angular resolution.
Corner applications impose a different demand. Blind-spot and cross-traffic functions need a broad lateral coverage area and consistent tracking of objects entering from oblique angles. A narrow-beam long-range radar may produce excellent forward coverage while leaving the actual risk zone poorly observed. Parking systems place more emphasis on nearby object coverage and close-range behavior; a sensor optimized for highway tracking can be unnecessarily costly and poorly matched to that task.
Define the operational design conditions before reviewing modules: vehicle speed bands, detection zones, object types, road geometry, mounting location, weather exposure, and expected sensor fusion architecture. This converts a generic request for an automotive radar sensor module into a testable engineering requirement.
Range Is a Scenario Requirement, Not a Marketing Number
Detection range should be evaluated by target type and use case. Large metallic vehicles, motorcycles, pedestrians, roadside barriers, and low-reflectivity objects do not produce the same radar return. A supplier’s quoted maximum detection distance may describe a favorable target, orientation, and environment. It does not automatically describe the distance at which the ADAS stack can classify, track, and act on a relevant object.
For forward applications, separate three questions:
- At what distance can the sensor report a possible object?
- At what distance can the perception system maintain a stable track with sufficient confidence?
- At what distance does the vehicle still have enough time to make the intended decision or intervention?
Those distances are not interchangeable. Early detection is useful only when it remains reliable enough to support downstream logic. Conversely, a shorter-range module may be fully adequate when the function is limited to lower speeds or is supported by camera, lidar, or another radar view.
Ask suppliers to describe range performance by target category, relative velocity, azimuth angle, and environmental condition. Also examine the minimum range. A forward radar mounted behind a bumper may have a near-field gap that matters during cut-in events or slow traffic. A corner sensor with a weak close-range zone may miss the part of a maneuver where the driver expects assistance most.
Resolution Determines Whether the Radar Can Make Useful Distinctions
Radar resolution is often discussed as a single specification, but technical evaluators should separate range resolution, velocity resolution, and angular resolution. Each affects a different ADAS decision.
Range resolution affects the ability to distinguish objects located at similar distances. It matters in dense traffic, where a vehicle, guardrail, and stationary object may occupy closely spaced positions along the driving direction. Velocity resolution affects how precisely the radar measures relative motion, which is fundamental for estimating closing speed and maintaining stable tracking. Angular resolution determines how well the sensor can separate objects that are at similar range but different lateral positions.
Angular resolution is especially important for forward ADAS functions. A radar that cannot consistently distinguish the current lane from an adjacent lane may create false targets, unstable target handoff, or unnecessary braking requests. The issue is not only the nominal beamwidth. Evaluators should understand how the module produces angle estimates, how performance changes at the edge of the field of view, and whether multipath reflections or dense traffic degrade object separation.
Do not treat point-cloud density as a universal measure of quality. A denser output can be helpful for higher-level perception and sensor fusion, but its value depends on how points are filtered, associated, and exposed through the interface. For a function built around radar-provided tracked objects, track stability, object attributes, confidence behavior, and latency may be more useful than raw point count.
Field of View Must Match the Zone of Responsibility
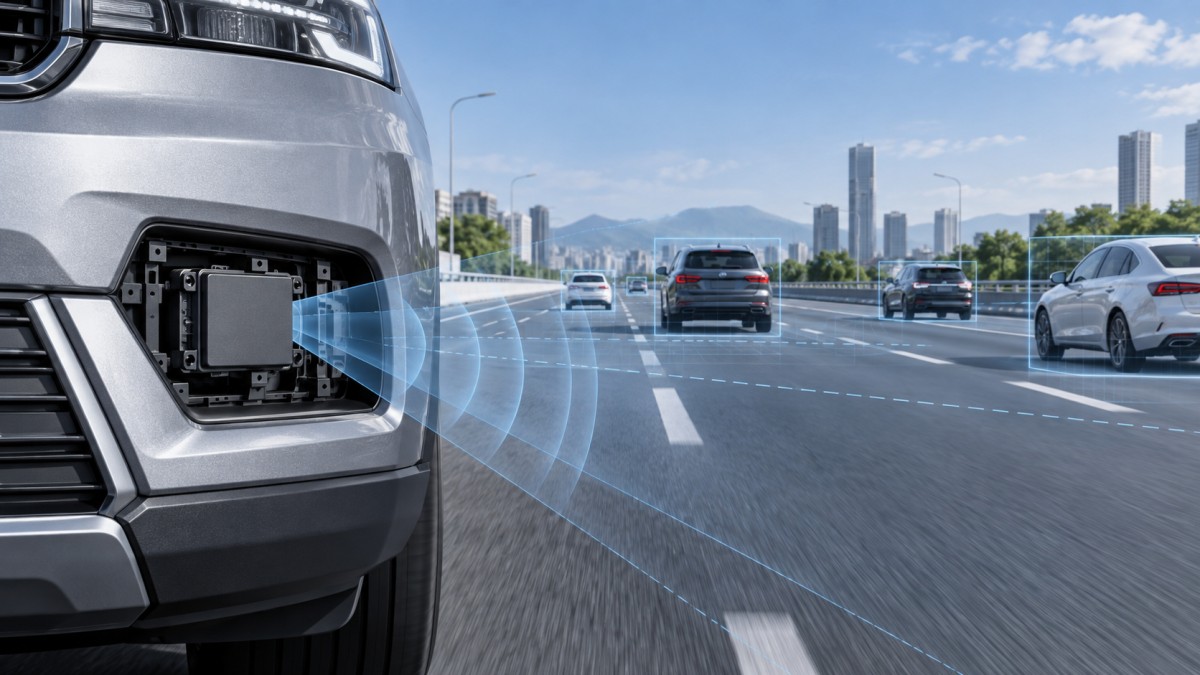
Every radar placement represents a coverage trade-off. A narrower field of view generally concentrates sensing capability in a smaller region, while a wider view provides broader lateral awareness but may reduce discrimination at distance or create more complex clutter conditions. The right choice is determined by the zone the ADAS function owns, including transition areas where targets enter or exit that zone.
Coverage drawings should be treated as a starting point, not proof. Vehicle body geometry, bumper shape, paint layers, badging, brackets, fascia material, and sensor height can alter the usable sensing area. A proposed module should therefore be assessed in its intended installation geometry rather than on a free-space diagram alone.
Update Rate and Latency Affect Control Quality
Radar modules produce data on a cycle, then pass that data through processing, communication, fusion, decision logic, and potentially an actuation path. The result is a timing chain, not merely a sensor update rate. A fast radar output is valuable, but only if timestamps are consistent and downstream systems can process the data without introducing unpredictable delay.
For functions involving moving objects, assess the age of data at the point where it is consumed. Track latency can affect cut-in recognition, braking decisions, and object association with camera detections. Timing behavior also matters when several sensors are fused: poorly synchronized inputs can make a moving target appear to shift location, creating false disagreement between sensors.
Ask whether the module provides timestamps, how measurement time is represented, and what operating modes affect cycle timing. It is also useful to identify how the sensor signals reduced performance, temporary unavailability, or degraded tracking. A system cannot manage a sensor limitation it cannot observe.
Interference, Multipath, and Clutter Need Design-Level Attention
Automotive radar operates in an environment containing reflective vehicle surfaces, barriers, road infrastructure, water, and other radar-equipped vehicles. The module must manage more than direct target echoes. Multipath can make objects appear at misleading positions; reflections from guardrails and large vehicles can raise clutter; nearby radars can add interference pressure in dense traffic.
There is no single specification that proves real-world robustness. Review the supplier’s interference mitigation approach, output behavior in congested radar environments, filtering options, and diagnostic reporting. Then validate representative scenarios that challenge the intended application: passing large vehicles, curved roads with barriers, urban intersections, wet surfaces, dense traffic queues, and sensor views partially affected by vehicle geometry.
Filtering must be considered carefully. Aggressive suppression can reduce nuisance outputs, but it can also remove weak yet relevant targets. The correct balance depends on the system-level hazard strategy and the other sensors available for confirmation. A camera-radar fusion system may accept a different radar output profile than a radar-led safety function.
Integration Often Decides Whether a Good Module Becomes a Good System
An automotive radar sensor module is not a self-contained ADAS feature. Integration includes mechanical installation, electrical design, thermal behavior, electromagnetic compatibility, communication interfaces, diagnostics, calibration, cybersecurity expectations, and software ownership.
Mechanical integration deserves early attention. Determine the allowed radar-facing material, bumper thickness variation, surface treatments, sensor orientation tolerance, bracket stiffness, and service replacement process. Small alignment errors can shift the coverage zone and reduce angular accuracy. A module may also require controlled mounting conditions to preserve the performance claimed in its specification.
On the electrical and software side, clarify the interface format, bandwidth, message structure, configuration workflow, diagnostic coverage, and boot behavior. Some modules provide higher-level object tracks, while others expose more detailed detections for a central perception stack. Neither model is inherently better. A tracked-object output can simplify an implementation and shorten processing work; lower-level data can offer more control when the vehicle program has the expertise and compute budget to build its own perception pipeline.
Do not leave ownership unclear. The evaluation should establish which party is responsible for radar configuration, bumper compensation, calibration, sensor health handling, target classification, fusion tuning, and field updates. Integration risk increases sharply when those responsibilities are divided without explicit interfaces.
A Practical Evaluation Sequence
Shortlisting becomes more efficient when teams avoid comparing every datasheet line at once. Use a staged process that removes mismatched candidates early and reserves detailed testing for modules that fit the vehicle architecture.
- Write function-specific sensing requirements. Define the relevant zone, target classes, relative speeds, required decision distance, and unacceptable failure modes.
- Map those requirements to radar behavior. Specify needed range bands, minimum range, field of view, angular separation, velocity performance, update behavior, and output type.
- Check installation compatibility. Review bumper stack-up, placement, packaging volume, harness routing, thermal environment, alignment control, and service constraints.
- Assess interface and software fit. Confirm whether the module’s detections, tracks, timestamps, diagnostics, and configuration tools match the ECU and fusion architecture.
- Test representative edge conditions. Evaluate not only normal detection but target separation, clutter behavior, false tracks, boundary-zone coverage, and degradation reporting.
- Review lifecycle support. Consider configuration control, traceability, update mechanisms, replacement calibration, and the evidence available for supplier qualification.
This process also makes supplier comparisons more transparent. Rather than accepting broad claims about “high performance,” the team can compare candidates against the same scenarios, interfaces, and installation constraints. That discipline aligns with the data-first approach promoted by TechStat Vanguard: parameters are useful when their test context and system consequence are made explicit.
Common Selection Errors
The most frequent error is selecting the longest-range device before confirming what the ADAS function needs to resolve. Another is assuming a field-of-view drawing represents installed coverage. Both shortcuts can lead to expensive redesign work after bumper integration or vehicle testing begins.
A third error is treating radar as an isolated sensor. Radar strengths include direct measurement of relative range and velocity and resilience in conditions that challenge optical sensing. Yet radar perception also has ambiguity around object shape, reflectivity, and multipath. The module should be selected together with the intended fusion strategy, not as a substitute for system architecture.
Finally, avoid evaluating only nominal performance. The module must remain understandable when performance is imperfect. Clear diagnostics, predictable degraded modes, well-documented output semantics, and stable configuration management can be more valuable to a vehicle program than a marginal headline advantage that is difficult to integrate or validate.
The strongest procurement decision is therefore a requirements-to-evidence decision: choose the radar whose installed, timed, and interpretable outputs support the ADAS function’s real operating conditions. That is a more demanding standard than comparing range figures, but it is the one that reduces late-stage integration surprises.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 03, 2026Is Edge Computing Necessary for Real-Time Quality Inspection?Is industrial edge computing necessary for real-time quality inspection? Explore how latency, data volume, reliability, and control integration shape the right architecture.TSV Data Lab
 Oct 02, 2026What Documents Prove a Precision Machining Supplier Can Hold Tolerance?What documents prove a precision machining supplier can hold tolerance? Explore certificates, FAI reports, calibration, SPC, and traceability evidence to qualify suppliers with confidence.Dr. Marcus Vance
 Oct 01, 2026Can a Machining Supplier Meet Aerospace Fatigue Testing Requirements?Can a machining supplier meet aerospace fatigue testing requirements? Learn the traceability, process control, and test evidence needed for reliable aerospace parts.Dr. Marcus Vance
 Sep 30, 2026Which Industrial Robot Specifications Matter for High-Precision Assembly?Which industrial robot specifications matter most for high-precision assembly? Explore repeatability, accuracy, stiffness, vibration, calibration, and force control for reliable yields.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026How Do You Verify Servo Motor Torque Under Continuous Load?How do I verify servo motor torque under continuous load? Learn RMS torque checks, torque-speed limits, thermal derating, and real-machine testing.Chen Wei (Automation Lead Engineer)
 Oct 02, 2026ZD330 Software Configuration: Verifying Cut-List Import Before PurchaseZD330 software and machine configuration: verify cut-list imports, data mapping, labels, and workflow before purchase to reduce errors and choose with confidence.Victor Lin (Chief Software Architect)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab























