Is radar sensor for traffic monitoring accurate in bad weather
Publication Date
author
For technical evaluators, the key question is not whether a radar sensor for traffic monitoring works in ideal conditions, but how reliably it performs in rain, fog, snow, and road spray. This article examines weather-related accuracy limits, signal stability, false detection risks, and the engineering metrics that matter when assessing radar-based traffic monitoring systems for real-world deployment.
Why bad-weather accuracy matters in real traffic monitoring scenarios
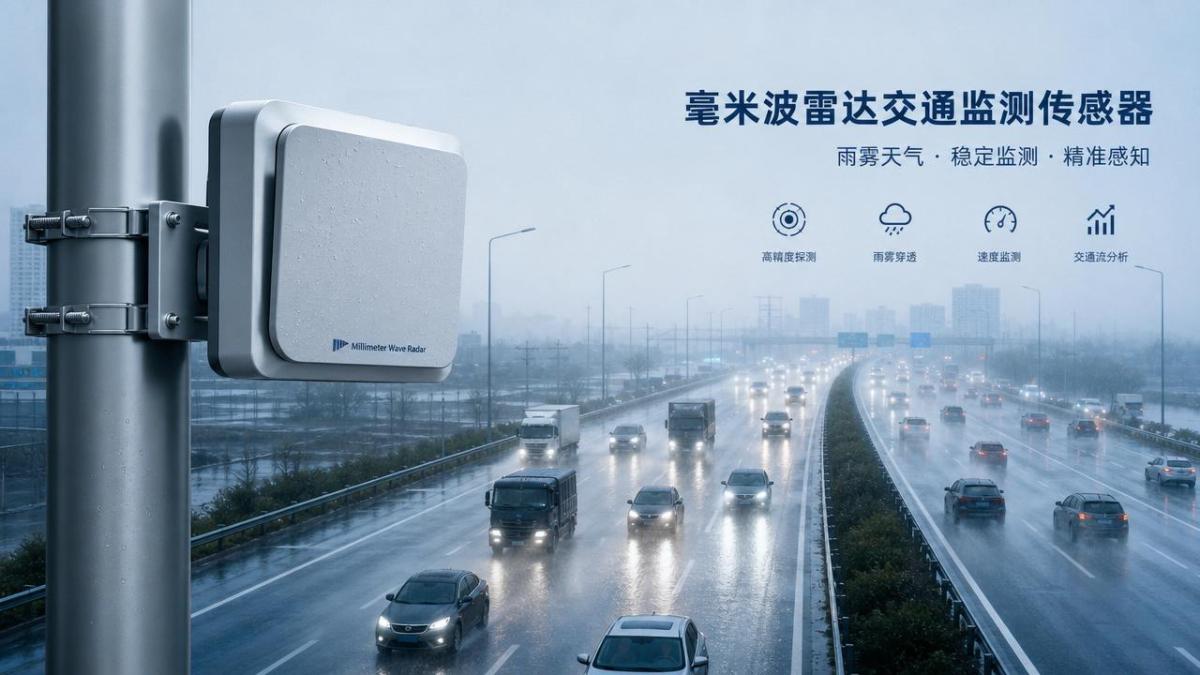
A radar sensor for traffic monitoring is often selected for outdoor durability, but weather resilience is not a binary feature. Accuracy changes by scenario, installation height, beam design, and target mix.
Urban intersections, expressways, tunnels, bridges, and toll approaches all stress the sensor differently. Rain clutter, roadside reflections, vehicle splash, and wet pavement can shift detection confidence.
This matters because traffic data supports signal timing, violation analytics, adaptive control, queue estimation, and safety monitoring. Small errors can compound into poor decisions.
At TechStat Vanguard, the engineering view is simple: a useful radar sensor for traffic monitoring must be judged by measurable stability under degraded conditions, not by marketing claims.
Scenario background: different roads create different weather failure modes
Bad weather does not affect every deployment equally. The same radar platform may perform well on an open highway but struggle at a dense urban junction.
On high-speed roads, long-range tracking and speed accuracy dominate. In cities, the key issues are object separation, stopped vehicle recognition, and suppression of multipath reflections.
Snow introduces another layer. It can reduce contrast between moving targets and background clutter, while slush and spray may create intermittent ghost objects near the road edge.
Fog usually hurts camera systems more than radar, yet dense moisture still matters. It can lower signal-to-noise ratio and challenge weaker sensors with narrow power margins.
Core weather variables to examine
- Rain rate and droplet density
- Fog thickness and sustained humidity
- Snowfall type, dry or wet
- Road spray from heavy vehicles
- Wet asphalt reflectivity and guardrail multipath
- Wind-driven vibration on poles and gantries
Where a radar sensor for traffic monitoring stays accurate in rain and fog
In moderate rain and normal fog, a radar sensor for traffic monitoring usually remains highly usable. Millimeter-wave radar is less sensitive than optical systems to visibility loss.
Vehicle presence detection is typically robust. Speed measurement also remains stable when the sensor has sufficient Doppler resolution and clean target tracking logic.
This is why radar is widely used for lane occupancy, queue length estimation, wrong-way alerts, and approach detection in adverse weather corridors.
Best-fit applications in degraded visibility
Expressway mainline monitoring benefits most. Targets are larger, trajectories are cleaner, and there are fewer complex roadside objects than at city intersections.
Ramp metering is another strong fit. The radar sensor for traffic monitoring can track approach speed and headway even during spray events.
Bridge decks and open corridors also suit radar well, especially where fog routinely limits camera effectiveness.
Where accuracy drops: snow, spray, dense clutter, and multi-target intersections
Accuracy declines when weather combines with scene complexity. The issue is rarely pure signal loss alone. More often, classification and tracking stability are affected.
Wet snow can be especially difficult. It changes background scattering and may partially mask smaller objects, such as bicycles, scooters, or pedestrians near lane boundaries.
Road spray from trucks can create short-lived clutter plumes. These may not break vehicle detection, but they can increase false alarms in poorly tuned systems.
At dense intersections, a radar sensor for traffic monitoring must separate vehicles waiting side by side, turning, or partially occluded. Bad weather makes this harder.
Typical weak points
- Small object detection near large trucks
- Precise lane-level assignment on curved roads
- Stopped-object confirmation in mixed reflections
- Classification accuracy during slush and heavy splash
Engineering metrics that reveal true bad-weather performance
To judge whether a radar sensor for traffic monitoring is accurate in bad weather, focus on testable metrics rather than generic claims of all-weather reliability.
Most useful evaluation metrics
Request weather-binned data where possible. A credible report separates light rain, heavy rain, fog, dry snow, and wet snow instead of reporting one blended average.
How scenario needs differ across roads, cities, and smart infrastructure projects
Not every deployment values the same metric. A radar sensor for traffic monitoring should match the operational objective of the site.
Practical fit recommendations before selecting a radar sensor for traffic monitoring
The best selection process starts with scenario validation. Do not treat all-weather operation as a universal pass condition.
Recommended evaluation steps
- Define targets clearly: vehicle only, or mixed road users.
- Map local weather patterns, including rain intensity and snow type.
- Review installation geometry, pole vibration, and road curvature.
- Request bad-weather field data, not only lab demonstrations.
- Check software filtering logic and update frequency.
- Verify integration with cameras or loop alternatives if redundancy is needed.
A radar sensor for traffic monitoring is strongest when deployment geometry is stable and expected targets are well defined. Performance drops when requirements are vague.
Common misjudgments that distort bad-weather radar evaluations
One common mistake is equating radar immunity to weather immunity. Radar is resistant, not unaffected. Severe precipitation and clutter still change performance envelopes.
Another mistake is reviewing only overall accuracy. A 95% average may hide unacceptable errors for bicycles, stopped vehicles, or lane-level detection during snow.
Some evaluations ignore mounting quality. Poor alignment, unstable poles, and blocked fields of view can hurt a radar sensor for traffic monitoring more than weather itself.
A final oversight is relying on dry-weather calibration. Thresholds that work in clear conditions may over-trigger when road spray and reflections increase.
Action path: how to verify whether the system is accurate enough for deployment
Start with a site-specific test matrix. Include rain, fog, snow, nighttime operation, and mixed traffic density. Compare radar outputs against trusted ground truth.
Use scenario-based acceptance criteria. For example, highway speed monitoring may prioritize velocity stability, while intersections may prioritize lane assignment and stop-line accuracy.
If data transparency is limited, request segmented results and failure cases. Engineering confidence comes from visible edge conditions, not from polished summaries.
In conclusion, a radar sensor for traffic monitoring is generally accurate in bad weather, especially compared with optical-only systems. But true suitability depends on scenario, clutter environment, and measurable bad-weather validation.
For infrastructure decisions shaped by hard data, use TSV’s engineering-first method: compare parameters, test weather-specific metrics, and validate real deployment conditions before final selection.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 04, 2026How Should You Compare 5-Axis CNC Machine Accuracy Claims?How do I compare 5-axis CNC machine accuracy claims? Learn how to assess standards, thermal stability, TCP accuracy, and real-world test evidence.Dr. Marcus Vance
 Oct 03, 2026Is Edge Computing Necessary for Real-Time Quality Inspection?Is industrial edge computing necessary for real-time quality inspection? Explore how latency, data volume, reliability, and control integration shape the right architecture.TSV Data Lab
 Oct 02, 2026What Documents Prove a Precision Machining Supplier Can Hold Tolerance?What documents prove a precision machining supplier can hold tolerance? Explore certificates, FAI reports, calibration, SPC, and traceability evidence to qualify suppliers with confidence.Dr. Marcus Vance
 Oct 01, 2026Can a Machining Supplier Meet Aerospace Fatigue Testing Requirements?Can a machining supplier meet aerospace fatigue testing requirements? Learn the traceability, process control, and test evidence needed for reliable aerospace parts.Dr. Marcus Vance
 Sep 30, 2026Which Industrial Robot Specifications Matter for High-Precision Assembly?Which industrial robot specifications matter most for high-precision assembly? Explore repeatability, accuracy, stiffness, vibration, calibration, and force control for reliable yields.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026How Do You Verify Servo Motor Torque Under Continuous Load?How do I verify servo motor torque under continuous load? Learn RMS torque checks, torque-speed limits, thermal derating, and real-machine testing.Chen Wei (Automation Lead Engineer)
 Oct 02, 2026ZD330 Software Configuration: Verifying Cut-List Import Before PurchaseZD330 software and machine configuration: verify cut-list imports, data mapping, labels, and workflow before purchase to reduce errors and choose with confidence.Victor Lin (Chief Software Architect)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)