
Where automotive assembly robots still create bottlenecks
Publication Date
author
Despite decades of automation, industrial robots for automotive assembly still leave critical bottlenecks in cycle time, line balancing, changeovers, and quality validation. For project managers and engineering leads, the real issue is not robot adoption alone, but where integration limits throughput and raises hidden costs. This article examines the overlooked constraints behind modern vehicle production and highlights where data-driven engineering decisions matter most.
Why do industrial robots for automotive assembly still create bottlenecks?
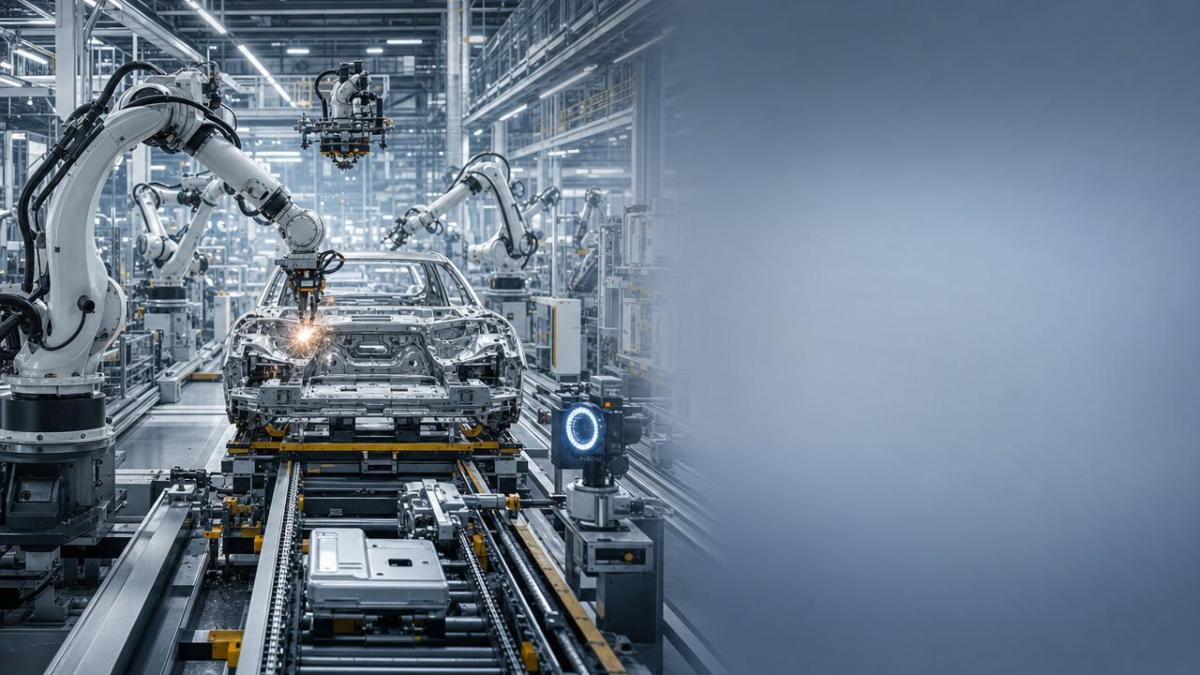
Automotive plants are often described as highly automated, yet bottlenecks persist because the robot itself is rarely the whole system. A welding robot may have sufficient speed on paper, but its actual output depends on fixturing stability, part presentation, clamp timing, vision confirmation, downstream buffer capacity, and rework loops. For project leaders, the bottleneck is usually found in interfaces, not in the robot brochure.
This matters when evaluating industrial robots for automotive assembly. Rated payload, reach, and repeatability are necessary parameters, but they do not reveal whether a station will recover from micro-stops, support model mix changes, or maintain takt time under variable upstream conditions. In a real body shop or final assembly line, a robot that is theoretically fast can still become the slowest asset in the chain.
- Cycle time is constrained by the total station sequence, including tool changes, sensing delays, part settling time, and safety gate logic.
- Line balancing breaks down when one robotic cell cannot absorb product variation or recover quickly after faults.
- Quality validation often sits outside the robot motion path, creating inspection queues and delayed defect detection.
- Changeovers introduce hidden downtime when grippers, fixtures, software recipes, and traceability records are not synchronized.
TSV’s engineering perspective is useful here because it filters out promotional language and focuses on measurable limits: repeatability under load, end-effector wear rates, sensor false-positive rates, fault recovery logic, and throughput stability over time. For a project manager under launch pressure, those are the data points that determine whether industrial robots for automotive assembly reduce risk or simply relocate it.
Where are the most common bottlenecks in automotive robot cells?
The main bottlenecks appear in predictable zones. They are not limited to one process, and they often span body-in-white, paint support handling, powertrain subassembly, battery pack integration, and final assembly material transfer. The table below summarizes where industrial robots for automotive assembly most often underperform relative to line expectations.
The pattern is clear: bottlenecks emerge when motion control, sensing, tooling, and process validation are treated as separate procurement items rather than one engineered production system. Many industrial robots for automotive assembly perform well in isolated factory acceptance tests, but line performance falls once tolerance variation and mixed-model complexity are introduced.
The hidden bottleneck: recovery time after minor faults
A cell that stops five times per shift for 90 seconds may look acceptable in a demo environment. On a high-volume automotive line, those micro-stops can erase the theoretical benefit of higher robot speed. Project teams should not only ask how fast the robot moves, but how quickly the cell returns to stable production after sensor loss, tool wear alarms, or part misloads.
The second hidden bottleneck: upstream and downstream mismatch
Even advanced industrial robots for automotive assembly fail to raise throughput when conveyors, AGVs, fixtures, or manual assist stations cannot match the same pace. In many launch programs, local optimization of a robot cell creates global imbalance. TSV typically advises engineering teams to benchmark cell utilization against line starvation and blockage data, not only robot cycle counters.
Which technical metrics should project managers track before buying?
Procurement decisions often lean too heavily on catalog specifications. For industrial robots for automotive assembly, project managers need a wider parameter set that reflects production risk. The right metrics should connect directly to throughput, quality, maintainability, and changeover performance.
The following table is a practical pre-purchase checklist for evaluating industrial robots for automotive assembly beyond headline figures.
For project management teams, this approach prevents a common failure mode: selecting industrial robots for automotive assembly based on peak specification, then discovering that integration friction wipes out ROI. A robot is not “faster” if its recipe switch or quality confirmation path introduces hidden queue time.
A practical procurement checklist
- Request loaded-cycle data, not only unloaded motion specs.
- Compare actual recovery procedures for the top five expected fault types.
- Validate traceability compatibility with your plant MES, quality database, and maintenance logs.
- Map spare part lead times against launch ramp-up and critical path milestones.
- Simulate mixed-model demand, not just a single reference vehicle.
Why line balancing and changeovers remain harder than robot motion
In mature vehicle plants, the bottleneck is often no longer basic motion execution. It is scheduling flexibility. Industrial robots for automotive assembly may handle a single model efficiently, but automotive production now demands higher variant counts, battery-electric platform shifts, regional customization, and shorter launch cycles. Every added variant increases the load on tooling logic, part identification, and validation software.
Line balancing suffers when robotic cells have narrow operating windows. A station optimized for one body style may struggle when panel tolerances shift, adhesive paths change, or fastener access becomes tighter. Project managers should view changeover capability as a throughput parameter, not a maintenance afterthought.
- Tooling standardization reduces setup confusion, but only if software naming, recipes, and interlocks are standardized too.
- Offline programming saves launch time, yet it must be validated against actual fixture drift and part springback.
- Buffer sizing can protect takt time, but excessive buffering masks root causes and inflates floor space demand.
When faster robots do not solve the problem
Buying a higher-speed robot may help only if the constraint is truly axis motion. In many industrial robots for automotive assembly programs, the actual delay comes from adhesive cure windows, weld confirmation timing, inter-station handshakes, or operator-assisted exceptions. TSV’s data-first philosophy is especially relevant here: measure bottleneck propagation through the entire line before spending budget on extra robot speed.
How should teams compare automation options, cell redesign, and partial alternatives?
Not every bottleneck should be solved by adding another robot. Sometimes the better answer is fixture redesign, a different sensor architecture, improved conveyor logic, or a semi-automated assist process. This comparison matters for budget control and delivery schedules, especially when launch deadlines leave little room for late-stage redesign.
The table below helps compare typical response paths when industrial robots for automotive assembly are causing production constraints.
The takeaway is simple: more automation is not always better automation. For industrial robots for automotive assembly, the right decision depends on the bottleneck source, its recurrence pattern, and the cost of delay. A well-documented engineering review often saves more than a rushed equipment expansion.
What standards, validation steps, and implementation risks should be reviewed?
Project managers in automotive programs must also consider compliance and launch governance. While exact requirements vary by plant and geography, industrial robots for automotive assembly usually sit within a broader framework of machine safety, electrical integration, process capability, and traceability discipline. Standards alone do not remove bottlenecks, but poor compliance planning often creates them.
Key validation areas
- Functional safety review for guarding, interlocks, emergency stop logic, and collaborative zones where applicable.
- Process capability checks for welding, sealing, fastening, or material handling repeatability under production conditions.
- Data traceability validation so torque records, weld logs, alarms, and quality events align with unit-level production history.
- Maintenance readiness review covering spare parts, preventive intervals, diagnostic tools, and technician training.
Teams should also challenge a common misconception: passing acceptance tests means the bottleneck is solved. Factory acceptance tests and site acceptance tests prove baseline functionality, but they may not expose endurance-related issues, cable fatigue, sensor contamination, or queue instability during full-shift mixed production. That is why TSV emphasizes engineering benchmarking and operating-envelope verification instead of trusting generic marketing claims.
FAQ: practical questions about industrial robots for automotive assembly
How do I know whether the robot is the real bottleneck?
Start with station-level time decomposition. Separate robot motion time from clamp time, sensor confirmation, tool exchange, manual intervention, and downstream release delays. If motion is only a small share of the total cycle, replacing the robot may not improve throughput. For industrial robots for automotive assembly, bottlenecks are frequently systemic rather than isolated.
What should I prioritize: speed, repeatability, or maintainability?
Prioritize the parameter that constrains line performance. In welding or dispensing, loaded repeatability may matter more than peak speed. In mixed-model assembly, changeover stability and maintainability can have higher financial impact than raw motion performance. The best industrial robots for automotive assembly are the ones that protect takt time across the full operating window.
Are collaborative robots a replacement for traditional automotive robot cells?
Usually not as a direct substitute for high-throughput body shop or heavy payload tasks. Cobots can fit inspection, light assembly assistance, or flexible low-volume operations, but they may not meet the speed, stiffness, or environmental robustness needed in many core automotive processes. Selection should be based on process demands, not trend appeal.
How early should procurement involve integration and quality teams?
As early as the specification stage. Delayed involvement often leads to mismatched interfaces, traceability gaps, and retrofit costs. For industrial robots for automotive assembly, early cross-functional review reduces supplier qualification cycles and prevents late-stage changes to fixtures, software, and inspection logic.
Why choose us when evaluating automotive automation bottlenecks?
TechStat Vanguard supports engineering teams that need more than vendor claims. Our role is to help decision-makers assess industrial robots for automotive assembly through measurable parameters, benchmarking logic, and supply-chain clarity. We focus on the details that affect project outcomes: repeatability under load, validation scope, fault recovery patterns, traceability readiness, and the trade-off between capex and throughput stability.
If your team is planning a new line, upgrading an existing robotic cell, or investigating why a highly automated station still limits output, you can consult us on specific topics such as:
- parameter confirmation for industrial robots for automotive assembly, including payload, reach, repeatability, and loaded process behavior;
- cell comparison for welding, sealing, transfer, fastening, and vision-assisted operations;
- delivery cycle and spare-part risk review for launch-critical programs;
- customized evaluation frameworks for mixed-model production and changeover-intensive lines;
- certification and compliance checkpoints related to safety, traceability, and process validation;
- quotation discussions built around engineering requirements instead of generic feature lists.
In high-value manufacturing, parameters do not lie and tolerances decide outcomes. If you need a clearer basis for robot selection, integration review, or supplier benchmarking, TechStat Vanguard can help your team replace information noise with engineering truth.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)























