
How Much Payload Margin Does a Collaborative Robot Need?
Publication Date
author
Selecting the right cobot is not just about rated load—it is about real-world safety, cycle stability, and future process flexibility. When evaluating collaborative robots payload capacity, technical teams must account for end-of-arm tooling, part variation, acceleration, and payload margin under dynamic conditions. This article explains how much margin a collaborative robot truly needs to reduce risk, avoid underspecification, and support data-driven procurement decisions.
For technical evaluators, payload is rarely a single number. A cobot that can lift 10 kg on paper may struggle once grippers, adapters, cable dress packs, off-center loads, and higher-speed motion are added. In procurement reviews, that gap between nominal rating and usable capacity is where cycle instability, safety trips, and early redesign costs often appear.
At TSV, the practical question is not whether a collaborative robot can pick a part once in a lab. The real question is whether its collaborative robots payload capacity remains stable across 8-hour shifts, 2-shift production schedules, and changing SKUs without forcing operators or process engineers into constant compromise.
Why Payload Margin Matters More Than Rated Payload
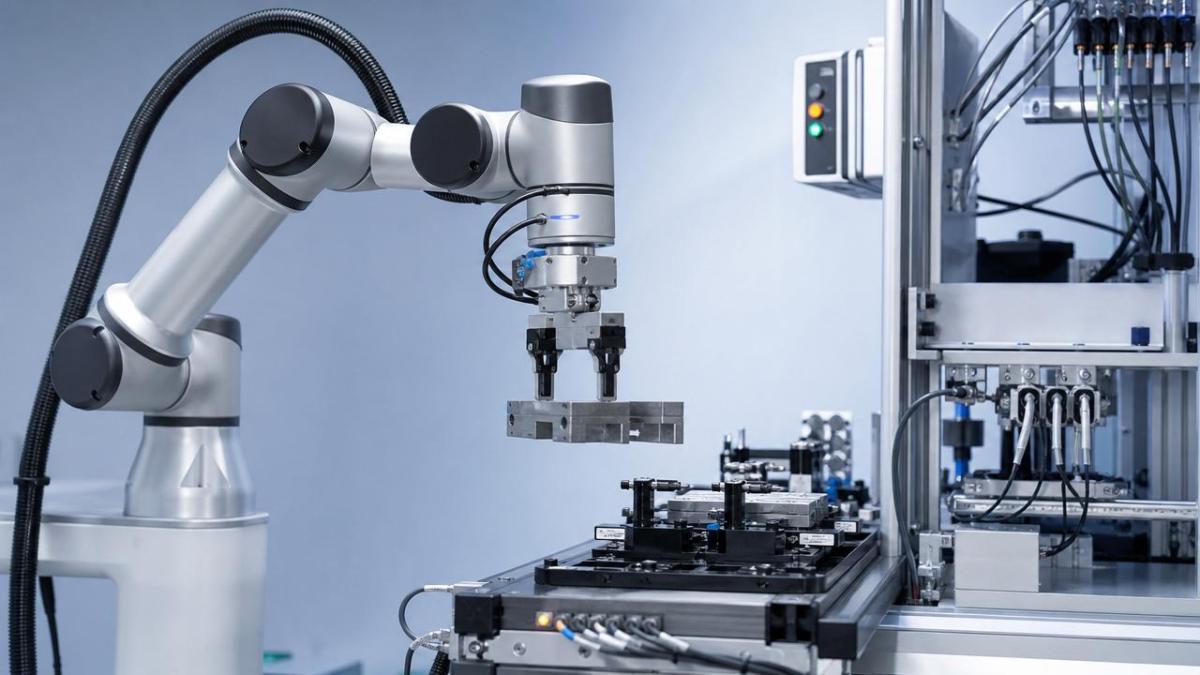
A manufacturer’s rated payload typically reflects a controlled condition: defined wrist orientation, limited moment load, standard acceleration, and a specific center of gravity. In actual deployment, even a modest end-of-arm tooling package can consume 15% to 40% of the available capacity before the workpiece is added. That is why payload margin is a design variable, not a purchasing afterthought.
For most technical teams, a practical starting point is to avoid sizing a cobot at more than 70% to 80% of its rated payload during normal cycles. If the application includes longer reach, rapid acceleration, or offset gripping, the preferred operating zone may fall closer to 60% to 70%. This leaves room for dynamic peaks, part variation, and future process changes.
Static load is not the same as dynamic load
A box weighing 8 kg is a static figure. But once the robot accelerates, decelerates, changes direction, or extends farther from the base, the effective demand on joints and gearboxes rises. In palletizing, machine tending, and screwdriving cells, dynamic forces may increase equivalent load by 10% to 30%, depending on motion profile and reach.
Key factors that reduce usable payload
- End-of-arm tooling mass, often 1 kg to 6 kg for vacuum tools, grippers, sensors, and brackets
- Workpiece center-of-gravity offset, which increases wrist moment even when mass stays unchanged
- Acceleration and deceleration settings, especially in cycle-time-driven cells
- Cable drag, hose routing, and auxiliary devices mounted near the flange
- Part inconsistency across batches, which may add 5% to 15% weight variation
The table below shows a simplified way to distinguish rated payload from usable process payload during technical evaluation. It is not a vendor specification substitute, but it helps procurement and engineering teams compare options on a like-for-like basis.
The main conclusion is straightforward: collaborative robots payload capacity must be judged under process conditions, not brochure conditions. A low margin may still work in a proof-of-concept, but it often creates hidden constraints in production, especially when takt time or part mix increases later.
How Much Payload Margin Does a Collaborative Robot Usually Need?
There is no universal percentage that fits every cell, yet most applications can be grouped into clear decision bands. A light-duty bench-top assembly task with low acceleration may work safely with a 20% margin. A machine tending cell with steel parts, longer reach, and moderate throughput may need 30% to 40%. High-mix operations usually benefit from even more headroom.
A practical margin framework for technical evaluators
Instead of asking, “What is the robot’s rated payload?” ask three layered questions: What is the maximum all-in moving mass? What happens at the worst-case center of gravity? What margin remains at the target cycle speed? Those three checks often reveal whether the selected payload class is robust or merely adequate.
- Calculate total moving mass: tooling + adapter + sensors + cables + workpiece.
- Test the heaviest SKU, not the average SKU.
- Review wrist moment and center-of-gravity limits alongside payload.
- Apply the actual acceleration profile needed for production takt time.
- Reserve extra margin for future gripper changes or part redesigns.
The following table provides a practical rule-of-thumb matrix for collaborative robots payload capacity planning. These ranges reflect common industrial evaluation logic rather than a single mandatory standard.
In short, if a production cell requires moving a 7 kg workpiece with a 2 kg gripper, the total apparent load is already 9 kg before dynamic effects. If the chosen cobot is rated at 10 kg, the design is usually too tight. A 12 kg to 16 kg class may be more realistic depending on reach and motion profile.
When less margin may still be acceptable
Lower margin can still be defensible in highly controlled tasks. Examples include slow-speed lab automation, seated operator assistance, or repetitive fixture loading with stable parts under 3 kg. Even then, technical teams should validate thermal behavior, fault frequency, and stopping performance over at least 500 to 1,000 continuous cycles before approval.
The Hidden Variables Behind Collaborative Robots Payload Capacity
Payload capacity is often discussed as if mass were the only issue. In practice, moment load, reach, duty cycle, and safety mode settings can be equally decisive. Two cobots with the same nominal payload may perform very differently if one has stricter wrist torque limits or reduced speed under collaborative operation.
Center of gravity and wrist moment
A compact 8 kg component held close to the flange is easier to manage than a 6 kg part extending 250 mm outward. That extra offset increases moment on the wrist and elbow joints. For technical evaluation, a robot’s flange load chart and center-of-gravity envelope should be checked with the same attention as the payload number itself.
Questions engineers should ask suppliers
- Is the rated payload valid at full reach or only at reduced extension?
- What is the allowable center-of-gravity distance in millimeters?
- How does payload change under collaborative speed and force limits?
- Are there duty-cycle derating recommendations for 16-hour or 24-hour operation?
- What overload or protective-stop behavior appears near the upper limit?
Cycle speed and throughput pressure
A payload choice that works at 8 cycles per minute may fail at 14 cycles per minute. Higher acceleration shortens takt time but increases inertial demand. This is especially relevant in packaging, electronics handling, and CNC tending where procurement teams are often asked to hit both compact footprint and short cycle targets with one platform.
For this reason, collaborative robots payload capacity should be validated against the target throughput window, not the current demonstration setting. If the business case assumes a 12-month production ramp or 15% output increase, that expected growth belongs in the payload model from day one.
A Procurement Method for Right-Sizing Payload Without Overspending
Oversizing a cobot can raise purchase cost, footprint, and integration complexity. Undersizing creates a more expensive problem later: lost throughput, higher troubleshooting time, and possible cell redesign. The goal is not maximum payload. The goal is sufficient engineering margin with the lowest process risk.
A five-step review process
- Document all moving masses, including grippers, couplers, vision brackets, and cable support.
- Define worst-case part weight and geometry across every planned SKU.
- Map reach, orientation, and center-of-gravity distance at pick and place points.
- Simulate or test target cycle time with real acceleration values, not reduced demo speed.
- Set a margin threshold, typically 20% to 50% based on risk, flexibility, and duty cycle.
This method is especially useful for cross-functional reviews involving automation engineers, safety personnel, and sourcing teams. It converts the selection process from a catalog comparison into an engineering decision supported by measurable constraints.
Common sourcing mistakes
- Using net part weight instead of total moving mass
- Ignoring future tooling upgrades or dual-gripper designs
- Comparing robots only by payload, not by reach and moment envelope
- Accepting proof-of-concept data from low-speed test routines
- Leaving no reserve for wear, recalibration, or batch variation
For technical assessment teams, these mistakes can delay acceptance by 2 to 6 weeks and trigger additional fixture or programming work. In capital equipment procurement, that delay often costs more than selecting the correct payload class at the start.
Where Payload Margin Delivers Long-Term Value
Payload margin is not only a safety buffer. It also supports smoother commissioning, broader SKU compatibility, and easier redeployment. A cobot with realistic spare capacity is better positioned to accept a new gripper, a vision module, or a heavier part family without a full automation reset.
Operational benefits over 12 to 36 months
In many facilities, the original application changes within 12 to 24 months. Packaging dimensions evolve, fixtures are upgraded, or operators request a different end effector. If the robot was selected with only 5% to 10% residual capacity, those normal changes can force a replacement. With a healthier margin, the same asset remains useful across more than one process generation.
That flexibility matters in sectors where sourcing cycles are long and validation resources are limited. Engineering teams do not want to restart layout, safety review, and tool qualification simply because the first cobot was sized too close to the edge.
TSV perspective for hard-tech buyers
From a data-driven procurement standpoint, collaborative robots payload capacity should be treated as a compound metric: rated mass, real moving mass, moment tolerance, cycle-speed demand, and future adaptation room. Buyers who use that framework usually produce tighter spec sheets, shorter evaluation loops, and fewer redesign surprises.
For technical evaluators, the most defensible answer is rarely the smallest robot that can “just lift” the part. It is the robot that can lift the entire process requirement repeatedly, safely, and economically with adequate margin left for variation and change.
If your team is comparing models, rewriting a spec sheet, or validating collaborative robots payload capacity for a new automation project, TSV can help structure the decision around measurable engineering parameters rather than marketing claims. Contact us to discuss a tailored evaluation framework, request a benchmark-oriented review, or explore more hard-tech procurement guidance.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)
 Sep 19, 2026How to Scope Automation Integration Services for Multi-System Factory ProjectsAutomation integration services: learn how to scope multi-system factory projects with clear workflows, interface contracts, safety boundaries, and acceptance criteria.Victor Lin (Chief Software Architect)























