
Custom robotic end effectors for fragile product handling
Publication Date
author
For operators handling delicate items, custom robotic end effectors can mean the difference between product loss and repeatable precision. In today’s automation landscape, fragile product handling demands more than generic grippers—it requires data-driven design, force control, and application-specific engineering. This article explores how custom robotic end effectors help improve safety, consistency, and throughput while reducing damage across demanding production environments.
In packaging, food processing, electronics assembly, medical device production, and precision component transfer, the operator’s challenge is rarely just “pick and place.” The real issue is maintaining stable handling when products vary in geometry, surface friction, shell strength, fill level, or temperature. A cracked blister pack, deformed pastry, scratched lens, or dropped vial can erase the productivity gains of automation in a single shift.
That is why custom robotic end effectors have become a practical engineering topic rather than a niche upgrade. For users and operators on the line, the value is measurable: lower scrap rates, fewer jams, more predictable cycle times, and safer robot interaction. For technical decision-makers, the right end-of-arm tooling supports repeatability targets, process validation, and faster changeovers across mixed-product environments.
Why Fragile Product Handling Needs Custom Robotic End Effectors
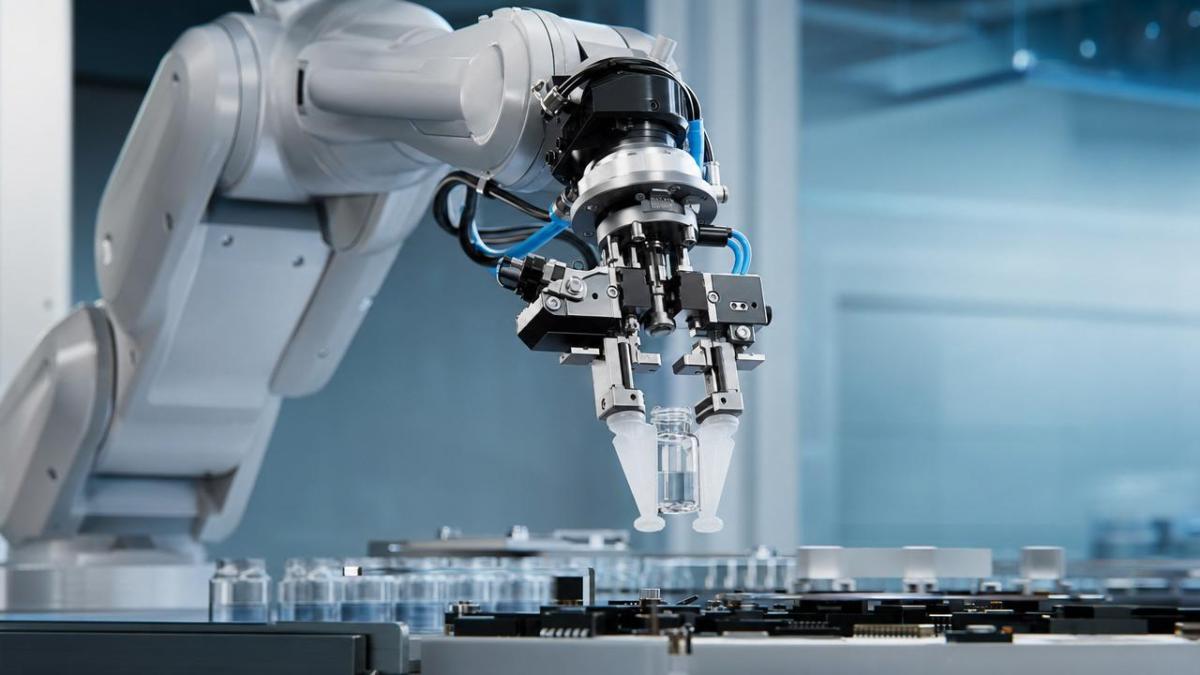
Generic grippers are typically designed around broad payload categories such as 0.5 kg, 2 kg, or 5 kg. Fragile handling requires a much narrower engineering window. Operators often need a gripping force low enough to avoid damage, yet stable enough to maintain positional control during acceleration, deceleration, and rotation. In many lines, the acceptable force band may be as tight as 5 N to 20 N, with repeatability targets of ±0.2 mm to ±0.5 mm.
A custom robotic end effector is engineered around the actual product and motion profile. That means vacuum cup material, finger contour, contact area, compliance travel, sensor feedback, and release timing are matched to the workpiece. This is especially important when the robot must handle items that are thin-walled, glossy, porous, flexible, or inconsistently oriented on the infeed side.
Typical Failure Modes in Delicate Automation Tasks
Operators usually notice failure through visible breakage, but handling errors often begin earlier. A gripper may apply uneven pressure, create micro-abrasion, fail to compensate for part tolerance, or lose suction during a 0.5-second acceleration spike. Even a 1% drop in pick reliability can become significant in a line running 20 to 60 cycles per minute across 2 or 3 shifts.
- Surface marking on cosmetic or polished products
- Compression damage on thin plastic, paperboard, or baked goods
- Product slip during high-speed transfer or orientation change
- Mis-picks caused by inconsistent spacing or part presentation
- Vacuum loss due to porous, textured, or irregular surfaces
Where Customization Delivers Measurable Gains
The strongest gains usually come from 4 areas: controlled contact force, adaptive compliance, sensor-assisted confirmation, and application-specific geometry. A well-designed custom robotic end effector can reduce product damage, cut manual intervention, and support shorter setup windows, often from 30–45 minutes down to 10–20 minutes in repeat changeover scenarios.
The table below outlines common fragile handling scenarios and the types of end-effector features operators should evaluate before deployment.
For operators, the key lesson is simple: fragile handling problems are often tooling problems before they become robot problems. When product quality losses appear sporadic, the source may be contact mechanics, vacuum stability, or release behavior rather than arm repeatability alone.
Core Design Elements Operators Should Understand
A custom robotic end effector is not a single part but a controlled interface between robot and product. Operators do not need to design every component themselves, but they should understand the variables that shape performance on the line. In most projects, 5 engineering factors determine whether the system remains stable after the first 2 weeks of production.
1. Contact Method: Vacuum, Mechanical, or Hybrid
Vacuum tools work well for flat or slightly curved surfaces, but they depend on seal quality, airflow, and product porosity. Mechanical grippers provide stronger retention for irregular shapes, though they can introduce local stress. Hybrid systems combine low-force gripping with suction support, often useful when handling products between 50 g and 1.5 kg that require both orientation control and gentle placement.
When each method fits best
- Vacuum: smooth trays, sealed cartons, blister packs, flat pouches
- Mechanical: molded parts, capped containers, uneven geometries
- Hybrid: delicate assemblies with mixed surfaces or variable center of gravity
2. Force Control and Compliance
A rigid tool can cause damage even at low programmed force if the incoming part height varies by 2 mm to 4 mm. Compliance mechanisms absorb small positional differences and reduce shock at first contact. In practical terms, 3 mm to 10 mm of passive compliance can make a major difference in fragile lines, especially when conveyors, trays, or nests are not perfectly level.
Force control becomes even more important in collaborative cells where lower speed does not automatically mean lower risk to the product. A slower robot can still crush a thin shell if the gripping profile is wrong. The end effector should therefore be matched to product crush limit, friction coefficient, and acceleration envelope.
3. Sensor Feedback and Pick Confirmation
Operators benefit from tooling that confirms whether a product is actually secured before transfer. This can be done through vacuum pressure sensing, finger position monitoring, or part presence detection. A basic confirmation step can prevent empty picks, double picks, and dropped parts, reducing rework events across long production runs.
In higher-mix environments, sensor feedback can also support recipe switching. If the line handles 6 to 12 SKUs, parameter sets for suction level, grip timing, and release dwell can be stored and changed in seconds rather than manually retuned during every shift.
4. Tool Material and Surface Interface
The contact material matters as much as the gripping mechanism. Silicone, polyurethane, nitrile, and other contact surfaces behave differently under temperature, oil exposure, washdown, and repeated compression. In fragile handling, non-marring performance is often more important than raw grip strength. Tool wear should be checked at defined intervals such as every 250,000 to 500,000 cycles, depending on material and environment.
How to Select the Right Custom Robotic End Effector
Selection should begin with process data, not catalog preference. Before choosing a tool, operators and engineers should define the product envelope, acceptable damage threshold, cycle rate, orientation needs, and cleaning or regulatory constraints. In many projects, 6 inputs are enough to narrow the concept significantly and avoid unnecessary redesign loops.
Essential Evaluation Criteria
- Product dimensions, mass, and center-of-gravity variation
- Surface condition: smooth, porous, textured, wet, oily, or dusty
- Maximum allowable contact force or deformation limit
- Required cycle time, often 15–60 picks per minute
- Changeover frequency, such as once per week or multiple times per shift
- Maintenance access and expected service interval
The table below helps operators compare common selection priorities in real production conditions.
A tool that looks impressive in a demonstration may fail on a real line if maintenance access is poor or if small product variations were ignored. Operators should always ask for trial data under realistic speed, orientation, and environmental conditions rather than relying on static bench picks alone.
Questions to Ask Before Procurement
Before committing to a custom robotic end effector, users should request technical clarity on several points. These questions reduce risk during sourcing and support better coordination between production, maintenance, and automation teams.
- What product tolerance range was used for the tool design?
- What happens if part height changes by ±3 mm or more?
- What is the expected wear life of cups, pads, or fingers?
- Can the tool support at least 2 future SKUs with minor adjustment?
- What sensors are included for pick confirmation and fault detection?
- How long is the typical build and validation cycle: 2 weeks, 4 weeks, or longer?
Implementation, Testing, and Operator Readiness
Even the best custom robotic end effectors can underperform if commissioning is rushed. Successful implementation usually follows 3 stages: application review, prototype validation, and production tuning. For fragile product handling, test conditions should reflect actual line behavior, including conveyor vibration, variable part spacing, full shift heat buildup, and routine cleaning procedures.
A Practical 5-Step Rollout
- Capture product data, defect history, and handling goals
- Develop a tooling concept based on contact method and force limits
- Run prototype tests over at least 100–500 cycles per SKU
- Fine-tune speeds, approach path, grip timing, and release timing
- Train operators on inspection points, cleaning, and fault recovery
Validation should not stop at “it worked once.” A more useful acceptance target is stable handling across representative conditions. For example, many teams use checks such as less than 0.5% drop events, no visible marking after 300 cycles, and repeatable pickup after a standard restart sequence. The exact threshold depends on product value and process criticality, but measurable criteria are essential.
Operator Training Priorities
Operators should know more than start and stop commands. They should be able to identify early wear, recognize abnormal suction behavior, and respond to mis-picks without damaging parts or forcing a jammed sequence. In many facilities, 60 to 90 minutes of focused tool-specific training is enough to improve first-line troubleshooting significantly.
Daily checks that matter
- Inspect contact surfaces for wear, contamination, or hardening
- Verify vacuum level or finger travel against normal values
- Check alignment after any collision or maintenance intervention
- Review reject patterns at the end of each shift
Common Mistakes and How to Avoid Them
A frequent mistake is specifying payload without specifying fragility. A robot may safely carry 3 kg, yet the product may tolerate only a narrow contact load at one edge. Another common issue is testing the end effector on perfect samples only. Real production includes warped trays, surface dust, fill-level variation, and occasional positioning error. A robust design must absorb those realities.
Users also underestimate release behavior. Picking is only half the cycle. If release height, air blast, or gripper opening speed is not controlled, products may bounce, rotate, or land outside acceptable orientation windows. In delicate packaging and assembly tasks, a release mismatch of just a few milliseconds can affect downstream placement accuracy.
Risk Reduction Guidelines
- Use product samples from normal production, not only ideal lab samples
- Validate at operating speed, not just reduced-speed debug mode
- Measure defect type separately: crush, slip, mark, miss, and drop
- Keep spare wear parts available for at least one maintenance cycle
- Review tooling performance after the first 1, 7, and 30 days of use
For fragile handling, custom robotic end effectors should be treated as a controlled process tool, not an accessory. That mindset helps teams align engineering, procurement, maintenance, and operator expectations around measurable handling quality rather than broad marketing claims.
Custom robotic end effectors create real value when they are built around the product’s physical limits, the operator’s daily workflow, and the line’s actual performance targets. For facilities handling delicate goods, the payoff is not abstract: fewer damaged units, more stable uptime, cleaner changeovers, and stronger process confidence. If you are evaluating automation for fragile product handling, now is the right time to review your tooling assumptions, request application-specific data, and get a tailored solution that matches your operating conditions. Contact us to discuss your process, compare end-effector options, and explore a practical custom robotic end effector strategy for your production line.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)
 Sep 19, 2026How to Scope Automation Integration Services for Multi-System Factory ProjectsAutomation integration services: learn how to scope multi-system factory projects with clear workflows, interface contracts, safety boundaries, and acceptance criteria.Victor Lin (Chief Software Architect)























