
Collaborative robots for electronics assembly need cleaner logic
Publication Date
author
In high-mix, precision-driven production, collaborative robots for electronics assembly must do more than move fast—they need cleaner logic, tighter process control, and verifiable performance data. For operators on the line, even small decision errors can affect yield, traceability, and rework rates. This article examines how data-grounded automation standards help teams reduce noise, improve consistency, and make smarter deployment choices.
Why do collaborative robots for electronics assembly need cleaner logic?
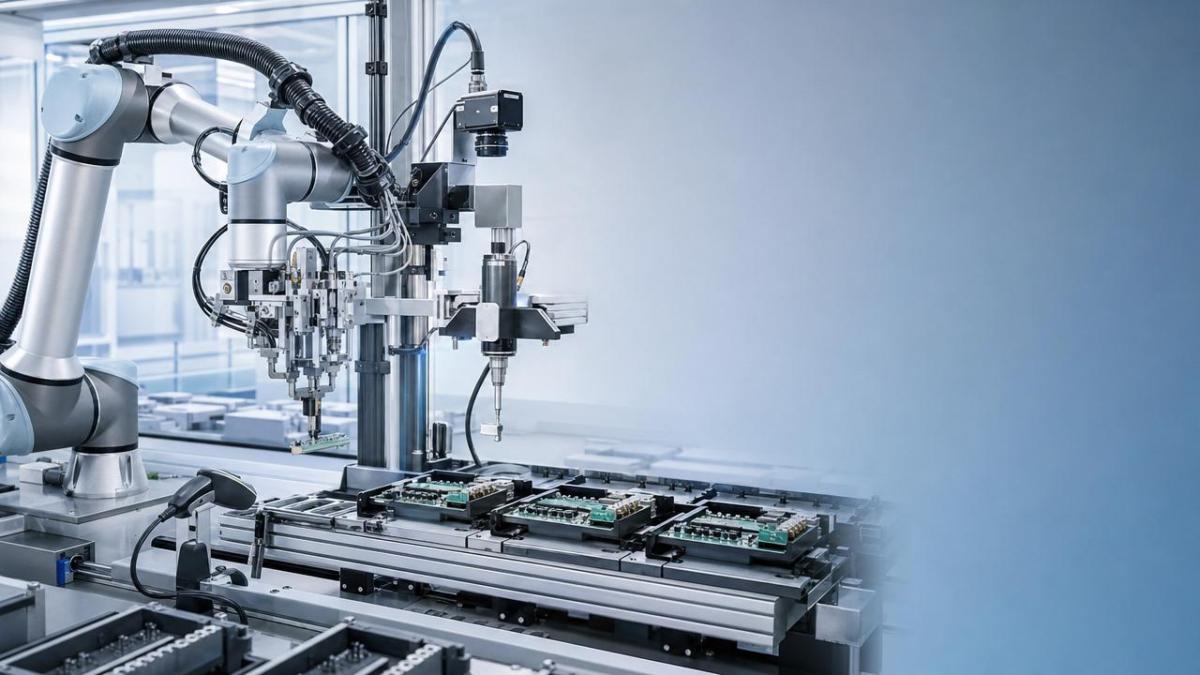
In electronics production, a cobot is rarely judged only by speed. Operators care about whether the arm places a connector within tolerance, whether screwdriving torque stays inside the approved process window, and whether recipe switching introduces hidden errors. Cleaner logic means the robot system makes fewer ambiguous decisions during motion, sensing, part identification, and exception handling.
This matters more in electronics than in many heavier industrial environments because assemblies are smaller, tolerances are tighter, and product changeovers happen more often. A robot that performs well in a general demo may still create line instability if vision alignment drifts, if handoff timing conflicts with conveyors, or if false positives from sensors trigger unnecessary stops.
For line users and operators, poor logic is not an abstract software problem. It appears as repeated resets, extra touch-ups, more manual intervention, uncertain defect causes, and higher stress during shift changes. In a data-driven manufacturing environment, collaborative robots for electronics assembly should be evaluated as decision systems, not just mechanical arms.
- Motion logic affects placement consistency, especially in PCB handling, micro-fastening, and tray-to-fixture transfers.
- Sensor logic determines whether the robot reacts correctly to misfeeds, missing parts, reflective surfaces, and fixture offsets.
- Process logic controls traceability, lot switching, recipe management, and alarm escalation paths that operators actually use on the floor.
What line operators actually need from cobot automation
Many automation projects are specified from the top down, but successful deployment depends on operator experience at the station. Collaborative robots for electronics assembly must support the people who load components, verify first articles, recover from faults, and maintain cycle stability across long shifts.
The real pain points on the line
- Frequent product changeovers create confusion when program versions, gripper settings, and vision parameters are not tightly linked.
- Tiny components and reflective materials make sensing difficult, especially when low-cost cameras are used without robust error-checking logic.
- Alarm messages are often too generic. “Pick failed” is not enough when the actual cause may be feeder jam, vacuum loss, part orientation error, or coordinate mismatch.
- Traceability breaks when torque values, barcode reads, and operator confirmations are not linked to the same production record.
TSV’s data-first viewpoint is useful here because it shifts selection away from marketing language and toward measurable control behavior. Instead of asking whether a cobot is “smart,” users should ask whether its repeatability, recovery logic, latency, and process data output are stable enough for the intended station.
Which electronics assembly scenarios benefit most?
Not every electronics task needs the same robot architecture. Some applications demand very fine motion with low payload. Others need flexible handling and safe collaboration. The best collaborative robots for electronics assembly are chosen by task profile, not by brochure claims.
The table below compares common electronics assembly scenarios and the control characteristics operators should pay attention to before deployment.
This comparison shows why application-specific logic matters. A cobot cell for screwdriving may look similar to one used for labeling, yet the process windows, failure modes, and traceability requirements are very different. Operators benefit when the system logic is built around these differences from day one.
What technical parameters should users verify before approval?
When reviewing collaborative robots for electronics assembly, the safest approach is to validate the parameters that directly affect yield and downtime. TSV’s engineering mindset is especially relevant because it rejects vague claims and prioritizes values that influence station stability in real production.
Parameters that matter more than marketing adjectives
- Repeatability: Important for repeated placement, fastening, and insertion. Users should relate repeatability claims to actual tool center point conditions, payload, and cycle profile.
- Control latency: Relevant for vision-guided correction, force-limited insertion, and conveyor synchronization. Lower latency generally improves response quality, but system integration quality matters as much as the robot controller.
- Payload versus end-effector mass: A robot may have enough nominal payload, but actual process stability can degrade if the gripper, screwdriver, cable routing, and compliance tools consume too much of the available dynamic margin.
- MTBF-related evidence: Users should not accept broad reliability language without understanding service intervals, component wear points, and expected uptime under multi-shift duty.
- Data output capability: For modern lines, the robot should support process records, event logs, and integration with factory software used for traceability and root-cause analysis.
The next table gives a practical screening framework for collaborative robots for electronics assembly. It is not a brand ranking. It is a user-oriented checklist for acceptance discussions with integrators and suppliers.
A useful lesson for buyers and operators alike is that no single parameter predicts success. Repeatability without clean recovery logic still creates line chaos. Fast cycle time without process data still makes troubleshooting slow. Better selection comes from combining kinematic, sensing, and information-layer evidence.
How should buyers compare collaborative robots for electronics assembly?
Buying decisions often fail because teams compare robot arms in isolation. In practice, the operational result depends on the arm, end-effector, controller behavior, safety setup, vision stack, data interface, and maintenance burden. For electronics assembly, a lower upfront robot price can become more expensive if changeovers are slow or alarm handling is weak.
A practical comparison method
- Define the task in measurable terms: placement tolerance, cycle target, reject criteria, operator interaction points, and required records.
- Map failure modes: feeder empty, barcode unreadable, connector skew, screw cross-thread risk, vision glare, or fixture wear.
- Check integration depth: PLC compatibility, MES communication, screwdriver data capture, and machine vision calibration workflow.
- Evaluate usability: operator screen clarity, reset procedures, recipe authorization, maintenance access, and spare parts availability.
- Run a pilot with representative product variants rather than a single ideal sample.
This structured comparison is consistent with TSV’s role as a commercial filter. The aim is not to amplify product claims but to isolate variables that affect production truth: tolerance holding, data integrity, failure behavior, and recovery time.
What implementation mistakes create hidden cost?
The visible cost of collaborative robots for electronics assembly is only part of the story. Hidden cost often comes from logic gaps that increase scrap, training load, or line stoppages. These costs are frequently missed during procurement because they are not obvious on the quotation sheet.
Common hidden-cost drivers
- Overreliance on manual adjustments after each changeover, which consumes operator time and weakens repeatability.
- Insufficient alarm granularity, causing long fault isolation times and unnecessary technician escalation.
- Weak traceability design, forcing quality teams to reconstruct events manually during audits or customer complaints.
- Inadequate validation of cable routing, vacuum tubing, or end-effector wear, leading to unstable behavior after initial acceptance.
In some stations, a dedicated industrial robot or semi-automatic fixture may still be a better choice than a cobot. If the process requires very high throughput with minimal human interaction, collaboration benefits may be limited. If the process demands frequent human loading, variant handling, and safe shared access, collaborative robots for electronics assembly often become more attractive.
Which standards and compliance points should not be ignored?
Electronics assembly projects sit at the intersection of automation safety, product quality, and traceability expectations. Even when a line is not in a heavily regulated niche, users should still ask how the robot cell aligns with common industrial safety practices and quality management needs.
- Risk assessment should cover human-robot interaction, pinch points, tool hazards, restart behavior, and material handling conditions.
- Electrical and control integration should be reviewed for safe stop functions, interlocks, and fault response logic.
- ESD control may be relevant depending on the product and station design, especially for sensitive assemblies and component exposure stages.
- Quality systems may require controlled process records for torque, identification, configuration, or operator acknowledgment.
A data-centric review helps here. Instead of only asking whether a station is “compliant,” operators and buyers should ask what evidence the station can produce: event logs, process confirmations, revision control records, and validation documents that support audits and supplier qualification.
FAQ: practical questions about collaborative robots for electronics assembly
How do I know whether a cobot is precise enough for my electronics task?
Start with the actual process window, not the catalog value. Compare required placement tolerance, insertion force sensitivity, and fixture variation against demonstrated performance under the real end-effector load and cycle pattern. If possible, test multiple product variants and include restart scenarios after a fault, not just nominal cycles.
Are collaborative robots for electronics assembly always better than manual work?
No. They are stronger when the task is repetitive, traceability matters, and variation can be controlled with sensing or guided logic. Manual work may remain more suitable for low volume, highly delicate rework, or stations where frequent engineering judgment is needed. The right decision depends on error cost, takt time, and operator burden.
What should operators ask for during acceptance?
Ask for clear alarm definitions, guided recovery instructions, recipe control rules, maintenance intervals, backup procedures, and traceability output examples. Also ask to observe a controlled fault recovery test. A robot that recovers cleanly in front of operators is often more valuable than one that only looks fast during a sales demo.
How important is data integration for small assembly cells?
It is increasingly important, even for small cells. Basic process data such as timestamps, pass-fail status, torque results, barcode reads, and alarm history can dramatically reduce troubleshooting time. As TSV emphasizes, engineering truth depends on records that can be checked, not on assumptions made after a defect escapes.
Why data-driven evaluation is becoming the safer path
As electronics manufacturing becomes more distributed, high-mix, and quality-sensitive, collaborative robots for electronics assembly will be judged less by marketing language and more by measurable operating behavior. Users need proof of repeatability, transparent control logic, stable recovery, and usable production data. That is the difference between automation that looks modern and automation that actually improves outcomes.
TSV’s perspective is especially relevant for teams navigating supplier noise. By focusing on parameters, tolerances, integration evidence, and traceability readiness, decision-makers can reduce trial-and-error cost and shorten qualification cycles. In practical terms, cleaner logic means fewer surprises on the line and better confidence during scale-up.
Why choose us for evaluation support and next-step consultation
If your team is reviewing collaborative robots for electronics assembly, TechStat Vanguard can help you turn broad vendor claims into engineering questions that operators, engineers, and procurement teams can actually use. Our value is not in adding more noise. It is in filtering it through hard-tech benchmarking logic and measurable decision criteria.
- Request support for parameter confirmation, including repeatability context, payload margin, sensing assumptions, and process data output needs.
- Discuss product selection logic for specific stations such as screwdriving, PCB handling, connector insertion, labeling, or vision-guided pick-and-place.
- Review delivery and implementation questions, including line integration dependencies, operator training points, and likely qualification bottlenecks.
- Clarify certification and compliance expectations, traceability requirements, sample validation scope, and quotation comparison structure.
If you are preparing a spec sheet, screening suppliers, or validating a new cobot cell, contact us with your task profile, expected cycle, quality checkpoints, and integration requirements. We can help you frame the right questions before budget is committed and before line-side complexity turns into rework.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)
 Sep 19, 2026How to Scope Automation Integration Services for Multi-System Factory ProjectsAutomation integration services: learn how to scope multi-system factory projects with clear workflows, interface contracts, safety boundaries, and acceptance criteria.Victor Lin (Chief Software Architect)























