Wholesale LiDAR Sensors for Autonomous Vehicles: Key Specs That Matter
Publication Date
author
Choosing wholesale LiDAR sensors for autonomous vehicles is not about marketing claims—it is about measurable performance under real operating conditions. For technical evaluators, the specs that truly matter include point cloud density, detection range, angular resolution, latency, interference resistance, and long-term reliability. This guide breaks down the engineering parameters that directly affect perception accuracy, system safety, and procurement decisions.
For most technical evaluation teams, the core search intent behind this topic is practical and immediate: how to compare LiDAR products at the specification level, how to separate useful engineering data from inflated vendor language, and how to identify which parameters actually influence autonomous driving performance. In other words, readers are not looking for a basic definition of LiDAR. They want a procurement-grade framework for technical screening.
The main concerns are usually consistent across advanced mobility projects. Evaluators want to know which specifications are safety-critical, which metrics are often presented in misleading ways, how environmental conditions change real-world performance, and what hidden integration risks can raise validation costs later. They also want to understand the tradeoff between sensor cost and usable perception value in fleet-scale or platform-scale purchasing.
That means the most helpful article is not a generic overview of LiDAR categories. It should focus on the engineering metrics that affect object detection, tracking stability, system latency, and long-term field reliability. It should also weakly emphasize abstract trend talk and strongly emphasize measurable parameters, test conditions, interface requirements, and supplier qualification checkpoints. For technical assessors, useful content is content that shortens the path from shortlist to validated source.
What technical evaluators should prioritize first when sourcing wholesale LiDAR sensors
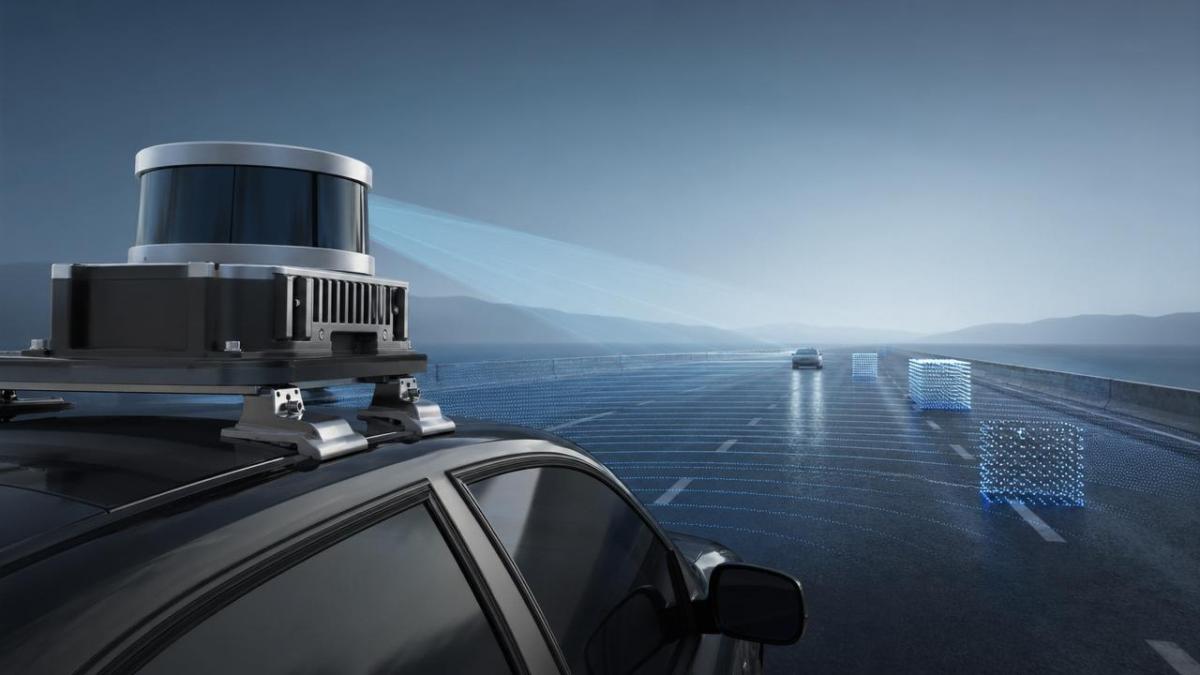
The first priority is to define the sensor’s role inside the perception stack before comparing product sheets. A LiDAR used for low-speed robotic shuttles, highway pilot functions, mining vehicles, and urban delivery platforms will not share the same specification thresholds. Teams that compare only by maximum range or channel count often make poor sourcing decisions because those metrics do not, by themselves, describe usable perception quality.
In wholesale procurement, the right question is not “Which LiDAR has the biggest number?” but “Which LiDAR provides stable, machine-usable data under our operational design domain?” Technical evaluators should start by mapping sensor requirements to vehicle speed, stopping distance, object classes, environmental exposure, field of view requirements, and compute architecture. Once those system-level constraints are clear, individual specs become much easier to interpret.
This is especially important when reviewing wholesale LiDAR sensors for autonomous vehicles from multiple manufacturers. Different suppliers may present similar headline numbers while measuring them under very different assumptions. One vendor may state range at a high reflectivity target under controlled lab conditions, while another reports range at lower reflectivity or in stronger ambient light. Without normalized conditions, a direct comparison is not technically valid.
For engineering teams, an effective first-pass filter usually includes six categories: effective detection range by target reflectivity, point cloud density at relevant distance bands, horizontal and vertical angular resolution, end-to-end latency, resistance to environmental and electromagnetic interference, and field reliability under temperature, vibration, and contamination stress. These are the parameters most closely tied to operational perception quality and long-term deployment cost.
Detection range is only meaningful when reflectivity and scenario assumptions are clear
Detection range is often the most advertised specification, but it is also one of the most misunderstood. A LiDAR that claims 200 meters of range may only achieve that figure against a high-reflectivity target under ideal atmospheric conditions. For autonomous vehicles, evaluators need to ask a much narrower question: what is the reliable detection distance for low-reflectivity objects that matter to planning and braking?
Relevant targets typically include dark vehicles, tires, road debris, pedestrians in varied clothing, and lane-adjacent obstacles. A range specification should be tied to reflectivity percentage, target size, ambient illumination, and confidence threshold. For example, range at 10% reflectivity is usually far more useful for procurement evaluation than range at 80% or 90% reflectivity, because low-reflectivity performance better represents real road complexity.
Distance also must be interpreted in relation to vehicle speed and perception refresh requirements. A sensor with adequate raw range but poor point density at distance may not provide enough shape detail for classification or trajectory estimation. At highway speeds, it is not enough to detect “something” far ahead; the perception stack needs sufficient data quality to distinguish drivable space, static clutter, and vulnerable road users in time for a safe decision.
Technical evaluators should therefore request test data instead of relying only on brochure claims. Useful vendor evidence includes detection curves by reflectivity, probability of detection at distance, false alarm rate, and performance degradation in rain, fog, dust, or strong sunlight. These measurements reveal whether a LiDAR’s stated range translates into operational value or remains a marketing number with limited system relevance.
Point cloud density and angular resolution determine whether the vehicle sees enough detail
For perception teams, point cloud density often matters more than channel count alone. Two sensors may both advertise high channel numbers, yet generate very different spatial detail across the same scene. What matters is how many points land on an object at the distances that matter to your use case, and how consistently those points support detection, segmentation, and tracking across motion and environmental noise.
Angular resolution plays a central role here. Horizontal and vertical resolution determine how finely the scene is sampled and how well small or distant objects can be separated from the background. Better angular resolution generally improves object edge definition, lane-side geometry interpretation, and obstacle differentiation, but it also interacts with frame rate, scanning architecture, and processing burden. The best sensor is not always the one with the smallest angular increment if the rest of the pipeline cannot use that added detail efficiently.
For technical evaluation, one practical method is to estimate points-on-target at representative ranges. If a pedestrian, tire fragment, or traffic cone receives too few returns at 80 to 120 meters, detection confidence may become unstable even if the raw range specification looks strong. Likewise, if road boundary features are too sparsely sampled, localization and free-space estimation can become fragile in cluttered urban environments.
Another key issue is point cloud uniformity. Some LiDAR architectures produce dense central coverage but weaker edge sampling, while others vary significantly across the field of view. Evaluators should look beyond total points per second and ask how points are distributed spatially. Perception algorithms are sensitive not just to quantity, but to consistency. Uniform, repeatable sampling often supports more robust model behavior than impressive peak density numbers alone.
Latency, frame rate, and synchronization affect safety more than many buyers expect
Latency is one of the most operationally important but underweighted specifications in autonomous sensing. In a moving vehicle, every millisecond matters because sensor data is consumed inside a larger chain that includes timestamping, fusion, perception inference, planning, and actuation. A LiDAR with acceptable static accuracy can still create system-level risk if data arrives too late or with inconsistent timing relative to cameras, radar, and inertial sensors.
Technical evaluators should distinguish between internal sensor latency, interface transmission delay, and effective end-to-end latency as consumed by the perception stack. Suppliers may state one timing value while omitting the rest. For integration planning, what matters is whether the output data can be tightly synchronized with other sensors and whether timestamps remain stable across thermal drift, compute load changes, and vehicle power-state transitions.
Frame rate must also be interpreted carefully. Higher frame rates can improve temporal responsiveness, but only if point cloud quality remains sufficient and the downstream compute stack can process the data without backlog. Some platforms benefit more from stable moderate frame rates with precise synchronization than from nominally faster output that introduces jitter or variable data quality. Consistency often matters more than peak headline performance.
For procurement validation, ask for timing diagrams, synchronization protocol support, and evidence of interoperability with common automotive or robotic middleware. IEEE 1588 support, hardware timestamping behavior, deterministic Ethernet compatibility, and known integration references can all reduce engineering uncertainty. A sensor that looks attractive in isolation may become costly if synchronization errors force extensive custom compensation in software.
Interference resistance and environmental robustness separate lab performance from deployable performance
As autonomous vehicle deployments scale, LiDAR-to-LiDAR interference is becoming a more serious concern. In fleet environments, urban roads, logistics hubs, and industrial zones, multiple active optical sensors may operate in overlapping spaces. Technical teams should verify not only whether a LiDAR meets baseline detection performance, but how gracefully it handles mutual interference, external light sources, reflective clutter, and adverse weather.
Interference can manifest as ghost points, missing returns, unstable distance estimates, or reduced confidence in regions where other sensors are active. These effects can be intermittent, making them difficult to catch during narrow pilot tests. Evaluators should request evidence from multi-sensor stress testing, including scenarios with several nearby LiDAR units, direct sunlight angles, highly reflective metal surfaces, and night operations with mixed artificial lighting.
Environmental robustness goes beyond IP rating alone. Sealing is important, but it does not fully describe performance under thermal cycling, shock, vibration, dust loading, mud splash, and optical window contamination. Autonomous vehicles often operate in conditions that degrade lens clarity and reduce return strength long before the sensor technically fails. A robust design must maintain usable data quality, not merely survive exposure on paper.
For this reason, qualification should include de-rated performance data across temperature and weather conditions, heater or cleaning strategy details where relevant, and failure mode behavior under partial obstruction. A sensor that loses a moderate amount of range but remains stable may be easier to manage than one that suffers abrupt data corruption under contamination. Reliability in the real world is about graceful degradation, not just pass-fail durability.
Reliability, MTBF, and lifecycle support matter in wholesale purchasing decisions
When sourcing wholesale LiDAR sensors for autonomous vehicles, unit performance is only part of the evaluation. Technical assessors also need confidence in production consistency, field reliability, and lifecycle support. In pilot programs, a high-performing sample can look excellent. In volume deployment, however, variation between batches, firmware instability, or supplier support gaps can turn a promising component into a scaling risk.
Mean Time Between Failures, warranty structure, return data analysis, and field serviceability are therefore relevant engineering topics, not just commercial details. Buyers should ask whether MTBF estimates come from modeled assumptions or actual accelerated life testing, and whether optical, mechanical, and electronic subsystems have been validated under vehicle-grade vibration and thermal loads. Test methodology matters as much as the resulting number.
Firmware maturity is another underappreciated factor. Many LiDAR systems improve over time through calibration updates, filtering changes, and diagnostic enhancements. That can be positive, but it also introduces version control risk. Procurement teams should clarify how firmware is managed, how backward compatibility is handled, and whether any updates affect data format, timing, or calibration behavior. Even small changes can disrupt validated perception pipelines.
Lifecycle support includes supply continuity, obsolescence planning, functional safety documentation where applicable, and responsiveness during root-cause investigations. A technically strong sensor from a weak support organization can create significant downstream cost. For enterprise deployments, the best suppliers are usually those that combine solid sensor metrics with traceable quality systems, stable manufacturing, and transparent engineering communication.
How to build a practical evaluation framework for supplier comparison
For technical teams, the most efficient approach is to convert broad interest into a weighted scorecard tied to the intended vehicle platform. Start with mission requirements: speed envelope, expected object classes, operating hours, weather conditions, mounting position, compute budget, and redundancy architecture. Then assign evaluation weights to the metrics that directly support those requirements rather than using a generic industry checklist.
A useful comparison framework often includes four layers. First is raw performance: range by reflectivity, point density, angular resolution, frame rate, and field of view. Second is operational robustness: interference resistance, weather stability, thermal behavior, and contamination tolerance. Third is integration readiness: interface compatibility, synchronization, diagnostics, software tools, and calibration workflow. Fourth is supplier maturity: quality systems, volume capability, support response, and lifecycle transparency.
It is also important to test against the scenarios most likely to create perception failure, not only against the easiest benchmark cases. That means including low-reflectivity targets, partial occlusions, mixed urban clutter, roadside metal structures, rain or dust exposure, and multi-sensor coexistence. Field testing should be supplemented by bench characterization so that anomalies can be traced to measurable causes rather than anecdotal impressions.
Finally, procurement decisions should consider total engineering cost, not just sensor price. A lower-cost unit that demands extensive algorithm re-tuning, custom synchronization work, or frequent cleaning interventions may be more expensive over the platform lifecycle. The best-value LiDAR is the one that reduces validation burden, behaves predictably across conditions, and supports scalable deployment without hidden integration penalties.
Common mistakes when comparing wholesale LiDAR sensors for autonomous vehicles
One common mistake is overvaluing a single headline metric, especially maximum range. Range matters, but without context on reflectivity, angular resolution, and latency, it does not tell you whether the sensor supports safe motion planning. Technical evaluators should treat standalone superlatives with caution and insist on multi-variable interpretation.
Another mistake is ignoring the relationship between sensor output and perception software capability. A LiDAR with very high data volume may look superior on paper, but if the compute platform cannot process the stream reliably, practical performance may suffer. Sensor selection should always be tied to the full stack, including fusion methods, bandwidth limits, storage, and timing architecture.
Teams also sometimes under-test environmental and interference edge cases because pilot timelines are compressed. This can create a dangerous gap between demo success and deployment readiness. Robust evaluation means exposing the sensor to the conditions most likely to undermine confidence, including dirty optics, thermal extremes, nearby active sensors, and low-contrast objects at critical distances.
The final major mistake is treating supplier transparency as optional. In advanced sensing, incomplete answers are often a warning sign. If a vendor cannot clearly explain test conditions, calibration method, failure diagnostics, or firmware revision impact, technical risk remains high regardless of the brochure. For serious sourcing decisions, engineering clarity is part of the product.
Conclusion: the best LiDAR spec is the one that remains meaningful in real operating conditions
For technical evaluators, choosing wholesale LiDAR sensors for autonomous vehicles should begin with one principle: only measurable, scenario-specific performance matters. The most important specifications are not the most dramatic marketing claims, but the ones that determine whether the vehicle can perceive objects reliably enough to support safe decisions. Detection range, point cloud density, angular resolution, latency, interference resistance, and reliability all need to be judged in operational context.
That is why effective LiDAR evaluation requires more than reading a datasheet. It requires asking how the numbers were measured, what assumptions are hidden behind them, and how they interact with the rest of the autonomous stack. A technically strong procurement process links every important spec to a real driving requirement, then validates it through disciplined testing and supplier scrutiny.
In the end, the right sensor is rarely the one with the loudest positioning. It is the one that provides stable, machine-usable perception across the actual conditions your vehicle will face, while minimizing integration risk and lifecycle uncertainty. For engineering-led sourcing, that is the standard that matters—and it is the standard that turns wholesale selection into a sound autonomous vehicle decision.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 28, 2026IDC: Global Quadruped Robot Shipments Rise 92.5% in H1 2026 as Volume and Value DivergeGlobal quadruped robot shipments rose 92.5% in H1 2026, according to IDC. Explore what diverging volume and value trends mean for industrial buyers and manufacturers.Chen Wei (Automation Lead Engineer)
 Oct 28, 2026Interpreting Industrial IoT Latency Data for Monitoring and Real-Time ControlInterpret industrial category latency data to assess jitter, deadline misses, and real-time readiness. Learn how to benchmark IIoT systems and choose monitoring and control solutions.TSV Data Lab
 Oct 27, 2026GXO and Agility Robotics Expand Partnership to Accelerate US Humanoid Robot DeploymentGXO and Agility Robotics plan to expand US humanoid robot deployment with Digit 4 in early 2027. Explore warehouse automation plans, service terms and future Digit 5 upgrades.Chen Wei (Automation Lead Engineer)
 Oct 27, 2026Robotic Automation Costs: Budgeting for Equipment, Integration, and MaintenancePlan your robotics automation cost with confidence. Explore equipment, integration, and maintenance expenses, compare quotes, and build a realistic budget for better ROI.Chen Wei (Automation Lead Engineer)
 Oct 26, 2026AMAXiMAL Releases Open-Source TopMod 3D v3 With Claude AIExplore AMAXiMAL’s free, open-source TopMod 3D v3 with Claude AI assistance, topology-based modeling and plywood fabrication tools that connect complex designs to physical builds.Dr. Marcus Vance
 Oct 26, 2026Choosing a SCADA System Integrator Company: PLC Compatibility and Long-Term SupportChoose a scada system integrator company with proven PLC compatibility and reliable long-term support. Discover what to test, compare, and require before investing.Victor Lin (Chief Software Architect)
 Oct 25, 2026Hesai Leads Global ADAS Main Lidar Shipments in Yole’s 2026 ReportHesai led global ADAS main lidar shipments with a 43% share in 2025, according to Yole’s 2026 report. Explore what this ranking reveals about its automotive market position.TSV Data Lab
 Oct 25, 2026Choosing an Aerospace Materials Manufacturer: Quality and Traceability ChecksChoosing an aerospace materials manufacturer? Learn how to verify certifications, test reports, and lot traceability to qualify suppliers confidently and reduce costly sourcing risks.Dr. Marcus Vance
 Oct 24, 2026Guotai Haitong: Global Entry-Level 3D Printer Shipments Rose 39% in Q1 2026Entry-level 3D printer shipments rose 39% in Q1 2026, Guotai Haitong reports. Explore how AI, multicolor printing and print farms are shaping market growth.Dr. Marcus Vance
 Oct 24, 2026Choosing an Industrial Vision Inspection Supplier: Acceptance Tests That MatterChoose an industrial vision inspection supplier with confidence. Discover acceptance tests for defect detection, false rejects, production speed, and reliable part rejection before you buy.TSV Data Lab
 Oct 23, 2026US Navy Raises Gecko Robotics Contract Ceiling to $300M for Robotic Fleet MaintenanceUS Navy raises Gecko Robotics’ contract ceiling to $300M for Pacific Fleet robotic inspections. Explore potential opportunities for maintenance suppliers and key procurement considerations.Chen Wei (Automation Lead Engineer)
 Oct 23, 2026Choosing Industrial Sensing Systems for Global Plants: Protocol CompatibilityCompare industrial sensing systems international buyers can trust. Explore protocol compatibility, reduce integration risks, and select proven configurations for reliable global plant deployments.TSV Data Lab
 Oct 22, 2026KUKA Showcases Physical AI and iiQKA.AI Vision at NVIDIA GTC BerlinExplore KUKA’s Physical AI showcase at NVIDIA GTC Berlin and discover how iiQKA.AI Vision aims to simplify robotic vision integration and improve 2D and 3D scene recognition.TSV Data Lab
 Oct 22, 2026Robotic Machining of Advanced Composites: What Tolerances Are Achievable?Explore advanced materials machining robotics: discover what drives achievable composite tolerances and how to validate accuracy before investing in your next machining system.Dr. Marcus Vance
 Oct 21, 2026China’s Industrial Robot Exports Near RMB 10 Billion in First Nine Months of 2026China’s industrial robot exports neared RMB 10 billion in January–September 2026, with value rising faster than volume. Explore the data and what it could mean for suppliers.Chen Wei (Automation Lead Engineer)
 Oct 21, 2026Low-Latency Industrial Data Processing: Pricing and Key Cost DriversExplore industrial data latency price drivers, from edge hardware to integration and support. Learn how to compare quotes, verify performance, and avoid unnecessary costs.TSV Data Lab
 Oct 20, 2026KUKA Launches iiQKA.AI Vision to Simplify Industrial Image ProcessingKUKA iiQKA.AI Vision simplifies industrial image processing with controller-based 2D and 3D vision. Explore drag-and-drop setup for vision-guided automation.TSV Data Lab