
Solid-state LiDAR anti-interference parameters that matter outdoors
Publication Date
author
For technical evaluators comparing perception hardware in real outdoor deployments, solid-state LiDAR anti-interference parameters are not a secondary spec—they determine usable data integrity under sunlight, dust, glare, and multi-sensor cross-talk. This article cuts past generic performance claims to examine which interference metrics actually matter when validating reliability, signal stability, and procurement readiness in demanding field environments.
Why a checklist-first approach is the right way to assess outdoor LiDAR
Technical evaluators often receive glossy data sheets showing range, resolution, field of view, and frame rate. Those figures are useful, but they rarely reveal whether the sensor will keep delivering stable point clouds at noon sun, near reflective metal, in dusty logistics yards, or beside other active optical systems. That is why a checklist is more valuable than a broad product overview when reviewing solid-state LiDAR anti-interference parameters.
In outdoor use, interference is not a single failure mode. It is a stack of interacting conditions: ambient solar radiation, low-reflectivity targets, rain backscatter, glass reflections, multi-path effects, vibration, thermal drift, and cross-talk from neighboring sensors. A sensor can look excellent in controlled demonstrations yet degrade sharply when these factors combine. The right evaluation method is therefore not “What is the maximum range?” but “Under what interference conditions does data quality remain decision-grade?”
For procurement, validation, and supplier qualification, the most important principle is simple: review measurable anti-interference parameters that map to field risk, not just marketing language. If the supplier cannot define the test condition, the number should not influence the final decision.
Core checklist: the solid-state LiDAR anti-interference parameters that matter most
Use the following checklist as the primary review framework. These are the solid-state LiDAR anti-interference parameters that most directly affect outdoor robustness, comparison fairness, and deployment confidence.
- Ambient light immunity: Ask for the maximum sunlight level under which the sensor still meets stated detection performance. Lux values alone are not enough; request the linked range and reflectivity condition.
- False point rate under strong illumination: A low false detection rate matters as much as raw range. Evaluators should confirm how often phantom returns appear near high-glare surfaces or direct solar angles.
- Signal-to-noise ratio stability: Stable SNR across changing light conditions indicates whether filtering and receiver design are robust rather than artificially tuned for lab scenes.
- Cross-talk resistance: In multi-vehicle or multi-sensor environments, confirm whether neighboring LiDAR units reduce effective range, create ghost objects, or increase packet-level dropouts.
- Dynamic range of reflectivity handling: Outdoor scenes mix black rubber, asphalt, foliage, retroreflective tape, and polished metal. The sensor must handle both weak and intense returns without severe saturation or loss.
- Multi-path and glare rejection: Glass façades, water, and metallic surfaces can generate misleading returns. Ask how the sensor distinguishes direct returns from reflected path artifacts.
- Weather backscatter suppression: Dust, fog, drizzle, and fine rain create near-field noise. Review filtering behavior, minimum detection persistence, and how the vendor defines usable performance in degraded visibility.
- Temporal consistency: One clean frame is not enough. Check frame-to-frame stability of object contour, point density, and range variance under interference.
- Thermal drift impact: Receiver sensitivity, timing precision, and calibration can shift with temperature. A sensor that resists optical interference but drifts at temperature extremes still fails outdoor readiness.
- Interference mitigation method transparency: Vendors should explain whether protection comes from wavelength filtering, coding strategy, receiver gating, DSP filtering, or sensor fusion assumptions.
A practical evaluation rule is to rate each parameter against three questions: Was it tested under a defined condition? Does it affect object-level perception quality? Can the supplier reproduce the result in your scenario? This keeps the review focused on engineering truth rather than broad claims.
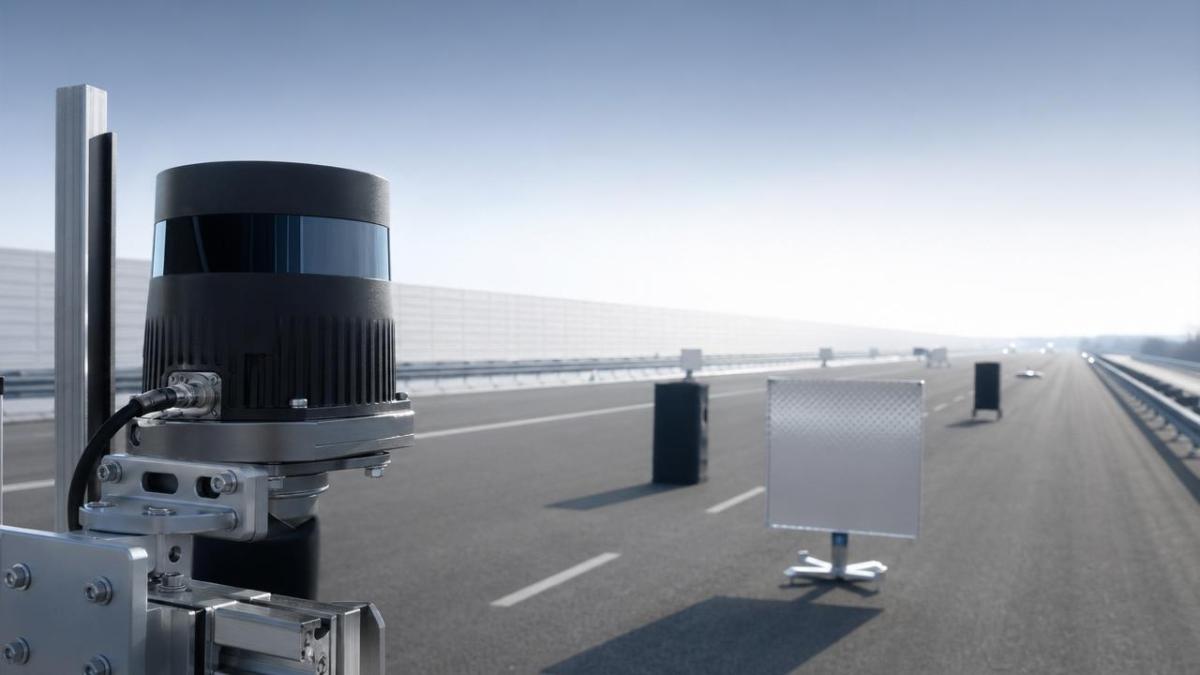
How to interpret parameter claims instead of reading specs at face value
Many solid-state LiDAR anti-interference parameters look impressive until the test setup is examined. Technical evaluators should insist on condition-linked interpretation. For example, “sunlight resistant” is not meaningful unless the vendor states solar intensity, target reflectivity, distance, angle of incidence, and pass criteria. Similarly, “anti-cross-talk design” is incomplete without a test involving multiple simultaneously operating LiDAR units at realistic spacing.
Another common issue is selective reporting. A supplier may quote maximum range on a high-reflectivity target but omit point cloud fragmentation on dark objects under sunlight. In practice, edge cases define operational risk. A forklift, service robot, UAV ground station, or roadside perception node must identify low-contrast obstacles, not just cooperative targets. Therefore, solid-state LiDAR anti-interference parameters should always be paired with target class, reflectivity band, and scene complexity.
It is also important to separate raw optical resilience from algorithmic clean-up. Some vendors rely heavily on downstream filtering to suppress interference artifacts. That can be acceptable in certain stacks, but evaluators need to know the trade-off: aggressive filtering may reduce false points while also reducing small-object sensitivity or increasing latency.
Quick comparison table for technical evaluation teams
Scenario-specific priorities: not every outdoor deployment weights the same parameters
Although the same core checklist applies broadly, technical evaluators should re-rank solid-state LiDAR anti-interference parameters according to deployment context.
For autonomous mobile robots and yard automation
Cross-talk resistance, dust backscatter suppression, and temporal consistency usually deserve top priority. In logistics yards or industrial campuses, multiple vehicles often operate in close proximity, and particulate noise is common. Review not only whether interference exists, but whether it causes unstable braking zones, fluctuating occupancy maps, or degraded safety envelope confidence.
For roadside and smart infrastructure sensing
Glare rejection, wide dynamic reflectivity handling, and thermal stability are often more important than peak range. Roadside systems face long daylight exposure, wet pavement reflections, headlight overlap, and enclosure heating. The question is not only detection, but sustained classification-grade point cloud quality over seasons.
For UAV landing, mapping support, and aerospace-adjacent ground systems
Weight and power still matter, but anti-interference metrics should focus on sunlight immunity, low-contrast surface detection, and vibration-coupled stability. Small landing markers, terrain texture variation, and changing sun angles can expose weak receiver design quickly.
Common blind spots that distort procurement decisions
Several repeat mistakes appear in technical reviews of solid-state LiDAR anti-interference parameters. Eliminating them can save months in qualification cycles.
- Confusing point cloud density with usable data integrity. Dense output is not valuable if a significant portion is unstable, duplicated, or false under interference.
- Accepting indoor or twilight demonstrations as proof of outdoor robustness. Strong solar load changes receiver behavior materially.
- Ignoring target reflectivity bands. A sensor may perform well on white boards and poorly on tires, dark clothing, or matte composites.
- Overlooking enclosure and window contamination effects. Dust, water film, and scratches can amplify apparent interference problems even if the core optics are sound.
- Failing to separate sensor limits from integration limits. Synchronization, mounting angle, and compute pipeline latency can make anti-interference performance appear worse or better than it is.
Execution guide: how to validate anti-interference performance before selection
A useful validation plan should be short, repeatable, and directly tied to procurement risk. Start with three test groups. First, run a controlled sunlight test across at least two reflectivity classes and multiple distances. Second, run a reflective-scene test with glass, metal, and mixed textures to observe ghost returns and contour distortion. Third, run a coexistence test with other active sensors operating simultaneously.
For each test, define pass criteria in operational terms: object detection continuity, range variance, false alarm threshold, frame-to-frame consistency, and impact on downstream tracking. This is more reliable than accepting a single vendor-generated metric. If possible, log raw and filtered output separately. That allows the evaluation team to determine whether the solid-state LiDAR anti-interference parameters are supported by the optical architecture itself or mainly by post-processing.
It is also wise to request traceable evidence: test reports, environmental conditions, firmware version, and any calibration dependencies. In advanced manufacturing and hard-tech sourcing, reproducibility is part of the product specification. A strong supplier should be able to explain tolerance boundaries, not only best-case results.
What to prepare before contacting suppliers or launching a pilot
To make supplier discussions productive, technical evaluators should prepare a concise requirement package. Include deployment environment, expected sunlight exposure, target classes, minimum object size, sensor coexistence density, contamination risk, temperature range, and downstream perception tasks. Without these inputs, comparisons of solid-state LiDAR anti-interference parameters become subjective and procurement cycles slow down.
Also define which outcomes are mission-critical versus acceptable degradation. For example, some use cases can tolerate reduced range in bright conditions if false positives stay low. Others require stable contour extraction above all else. This prioritization helps vendors recommend realistic configurations and prevents overbuying or under-specifying the sensor.
Final decision guidance for technical evaluators
The best purchasing decision will rarely come from the sensor with the highest headline range. It will come from the system with the clearest, test-backed anti-interference behavior under your actual outdoor conditions. When reviewing solid-state LiDAR anti-interference parameters, prioritize sunlight immunity, false return control, cross-talk resistance, reflectivity handling, weather noise suppression, and thermal consistency as a linked set rather than isolated numbers.
If your team is moving toward supplier comparison, pilot validation, or specification drafting, the next step is to align on six questions: which interference modes are most likely in the field, what pass criteria define usable perception, what raw data access is required, how many coexisting sensors will operate nearby, what environmental tolerance window is mandatory, and what evidence the supplier can provide for repeatable performance. Those answers will make solid-state LiDAR anti-interference parameters actionable, comparable, and procurement-ready.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Sep 28, 2026Spindle Runout Measurement in Germany: DIN Standards, Methods, and Acceptance LimitsSpindle runout measurement Germany: explore DIN standards, proven methods, acceptance limits, and audit-ready practices for reliable machining quality.Dr. Marcus Vance
 Sep 27, 2026How to Select Wall-Mount Edge Devices for Space-Constrained Factory NetworksWall mount edge devices for space-constrained factories: evaluate workload, thermal design, power resilience, cable access, and network reliability for smarter deployments.TSV Data Lab
 Sep 26, 2026Machining Tolerance Analysis: How to Set Limits That Meet Function and Cost TargetsMachining tolerance analysis: learn how to set functional limits, control tolerance stacks, reduce inspection risk, and balance precision with production cost.Dr. Marcus Vance
 Sep 25, 2026How to Evaluate an Industrial Infrastructure Data Platform for Multi-Site OperationsIndustrial infrastructure data platform evaluation guide for multi-site operations: compare data quality, edge resilience, interoperability, governance, and scalable proof-of-value criteria.Victor Lin (Chief Software Architect)
 Sep 24, 2026How to Select Machine Vision Optics for Accurate Inspection at Different Working DistancesMachine vision optics selection guide for accurate inspection at every working distance. Compare FOV, pixel scale, DOF, distortion, lighting, and telecentric options.TSV Data Lab
 Sep 23, 2026How to Evaluate a Machine Vision System Integrator for High-Speed Inspection LinesChoose a machine vision system integrator with proven expertise in high-speed inspection, reliable reject timing, robust optics, and measurable acceptance criteria.TSV Data Lab
 Sep 28, 2026When is a SCADA API the right choice for connecting plant systems?SCADA API guide: learn when governed plant data integration improves traceability, security, and scalability—without compromising real-time control.Victor Lin (Chief Software Architect)
 Sep 27, 2026How SCADA data integration improves traceability across production linesSCADA data integration connects production-line data to improve traceability, accelerate quality investigations, and strengthen safety decisions.Victor Lin (Chief Software Architect)
 Sep 26, 2026What to define before starting SCADA integration planningSCADA integration planning starts with clear scope, control boundaries, data models, cybersecurity, and testing. Discover the definitions that reduce risk and costly rework.Victor Lin (Chief Software Architect)
 Sep 25, 2026How a smart factory with Industrial IoT reduces production blind spotsDiscover how a smart factory with Industrial IoT turns real-time machine, quality, and workflow data into actionable insights that reduce production blind spots and delivery risks.Victor Lin (Chief Software Architect)
 Sep 24, 2026When does Industrial IoT make smart manufacturing easier to scale?Smart manufacturing Industrial IoT scales when trusted data, interoperable systems, and secure workflows turn connected assets into measurable gains.TSV Data Lab
 Sep 23, 2026What drives ultra-precision machining cost at 1-micron tolerance?Ultra precision machining cost per part at 1 micron tolerance depends on process, material, metrology, and yield. Learn how to compare quotes confidently.Dr. Marcus Vance
 Sep 22, 2026Drone Engine-T550CC Applications: Build the UAV Power System Around the MissionAn application guide for Drone Engine-T550CC integration, covering payload planning, airframe matching, cooling, fuel, vibration, test procedures, documentation, and service preparation.Elena Rostova (UAV Systems Researcher)
 Sep 22, 2026How to Evaluate Industrial Edge Computing Vendors for Factory DeploymentIndustrial edge computing vendor evaluation guide for factories: compare latency, protocol fit, reliability, security, and lifecycle support before deployment.TSV Data Lab
 Sep 21, 2026Drone Payload Integration: Matching Power, Data, and Center of Gravity for Reliable FlightsDrone payload integration made practical: balance power, data, center of gravity, and endurance to build safer, more reliable mission-ready flights.Elena Rostova (UAV Systems Researcher)
 Sep 20, 2026Autonomous Navigation Pricing: Cost Drivers and Budget Benchmarks for AMR ProjectsAutonomous navigation price explained: compare AMR cost drivers, software, sensors, integration, safety, and lifecycle budgets to build a scalable project plan.Chen Wei (Automation Lead Engineer)























