Robotic Arm for Injection Molding: Key Fit Checks Before Line Integration
Publication Date
author
Before integrating a robotic arm for injection molding into a production line, project leaders must verify far more than reach and cycle time. Tooling compatibility, machine interface protocols, payload stability, safety zoning, and maintenance access all determine whether deployment delivers measurable gains or hidden downtime. This guide outlines the key fit checks that matter most for reliable line integration and long-term manufacturing efficiency.
Why fit checks vary by production scenario
A robotic arm for injection molding is rarely a plug-and-play purchase. For project managers and engineering leads, the real question is not whether the robot can move parts, but whether it fits the exact production context without creating new bottlenecks. A medical molding cell, a high-volume packaging line, and an automotive technical parts line may all use similar robot architectures, yet their integration risks are very different.
This is why scenario-based evaluation matters. In some lines, dry cycle speed is the primary driver. In others, clean handling, traceability, insert placement accuracy, or downstream transfer reliability matter more than headline throughput. A mismatch between application demands and robot configuration can lead to unstable part release, mold interference, operator safety conflicts, or frequent maintenance stops.
At TSV, the engineering-first approach is simple: define the production scene, map the real constraints, and verify mechanical, electrical, software, and maintenance compatibility before installation. For a robotic arm for injection molding, that discipline reduces commissioning risk and shortens the qualification cycle.
Core reason project teams miss the right fit
Many teams compare suppliers by payload, reach, and quoted cycle time only. Those values matter, but they do not explain how the robot behaves with a specific mold opening stroke, end-of-arm tool mass, hot runner layout, part geometry, or machine controller protocol. Integration failures often come from unverified details rather than from obviously wrong machine size.
- Different molding scenarios impose different part removal speeds and orientation limits.
- Downstream equipment may require stricter handoff position repeatability than the molding machine itself.
- Safety zoning and operator access can reduce the usable robot envelope.
- Service clearance and preventive maintenance paths can affect actual uptime more than nominal speed.
Three common application scenarios and what changes in each
To judge whether a robotic arm for injection molding is suitable, project leaders should first classify the line by operating pattern. The following three scenarios cover most real-world integration decisions and reveal why a single specification sheet is not enough.
Each scenario has a different risk profile. High-volume consumer products emphasize pace and repeatability. Technical molding often involves insert handling or part orientation control. Clean or traceable production environments require strict handling discipline and process stability. Selection criteria should follow those realities.
The table below highlights the fit-check differences that matter before line integration begins.
Scenario 1: high-volume molding cells
In fast-cycle production, the robotic arm for injection molding must remove parts quickly without inducing vibration, suction failure, or poor downstream placement. Here, theoretical speed is less useful than stable cycle synchronization with mold opening, cooling rhythm, and conveyor index timing.
Project teams should verify whether the robot’s acceleration profile remains stable under the actual EOAT mass, not under an empty arm test. Even small differences in part adhesion, static charge, or gate vestige can change release behavior at high speed. If handoff consistency is weak, the resulting micro-stoppages can erase expected productivity gains.
Scenario 2: technical parts and insert applications
For engineering components, the robotic arm for injection molding often does more than extraction. It may place inserts, rotate parts, present them to inspection, or transfer them to machining or assembly fixtures. In this setting, payload reserve, wrist rigidity, and motion path accuracy become more important than raw pick speed.
A common mistake is to size the robot only for part weight. The correct method is to include EOAT weight, cabling, vacuum hardware, inserts, dynamic load during acceleration, and the off-center moment created by part geometry. Without that margin, repeatability degrades under production motion.
Scenario 3: clean, validated, or traceable manufacturing
In regulated or cleanliness-sensitive lines, a robotic arm for injection molding must support consistent handling and controlled intervention. The robot may need smoother surfaces, restricted manual touchpoints, easier cleaning access, and a controller that supports event logging or recipe control.
These environments also demand careful service planning. If technicians must enter a restricted zone for routine adjustment, the integration design is already weak. Fit checks should include maintenance routes, sensor replacement access, and how the robot behaves during alarm recovery.
The five engineering checks that decide whether the robot truly fits
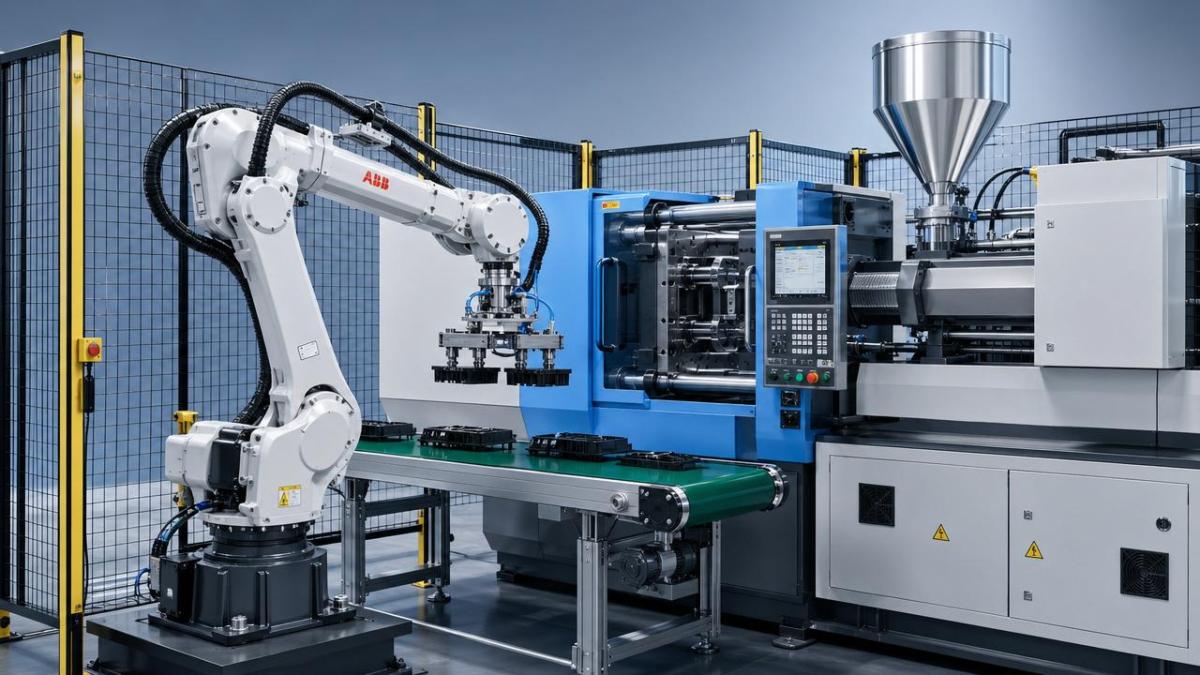
Once the production scenario is clear, project teams should move to the decisive technical checks. These are the areas where a robotic arm for injection molding either integrates smoothly or becomes a long-term source of downtime and engineering rework.
The most effective reviews cover mechanical fit, control compatibility, process timing, safety architecture, and maintainability. If one of these is weak, the project may still pass FAT but fail under continuous production stress.
The following subsections translate those checks into practical evaluation points for line integration.
Mechanical envelope and mold interaction
The first check is not just reach, but usable reach inside the real mold area. Tie bar spacing, mold height, platen access, nozzle-side obstruction, and top-entry or side-entry limitations all affect whether the robotic arm for injection molding can move safely through the required path.
Teams should confirm mold open stroke, take-out depth, extraction angle, and safe clearance under the largest planned tool. A robot that fits one mold may conflict with future mold programs if vertical stroke or arm geometry is too tightly matched to a single setup.
Questions to ask
- Can the arm enter and exit without nearing mold steel at maximum production speed?
- Is there enough reserve for future EOAT changes or larger part families?
- Does the mounting method affect machine access or structural vibration?
EOAT compatibility and payload stability
The end-of-arm tool often determines actual success more than the base robot. Vacuum cups, grippers, sprue cutters, insert nests, part sensors, and quick-change plates all influence the dynamic behavior of a robotic arm for injection molding. A payload that looks acceptable on paper may become unstable when the center of gravity shifts during rotation or acceleration.
EOAT review should include flex, air routing, cable protection, confirmation sensors, and release reliability. In technical lines, rigid and repeatable tooling is essential to prevent flash damage, insert misplacement, or misoriented transfer to secondary stations.
Machine interface and control logic
A robotic arm for injection molding must communicate correctly with the molding machine and with downstream devices. Basic start and stop signals are not enough for complex lines. Teams should verify protocol support, alarm handling, handshake depth, recipe switching logic, and whether event data can be integrated into MES or SCADA layers if needed.
Poor interface planning often creates hidden delays. For example, if the robot waits for redundant confirmations, or if downstream occupancy signals are not prioritized correctly, cycle time suffers even though individual devices are fast. Control reviews should map every state transition, including abnormal recovery.
Safety zoning and operator workflow
Safety is not just compliance paperwork. For a robotic arm for injection molding, real safety design includes guarding layout, interlock logic, manual access points, and how operators perform changeovers, sampling, and clearing. A safe cell that is difficult to access often leads to workarounds, which then create both safety and uptime risk.
Project managers should verify whether doors, fences, light curtains, or area scanners support the actual workflow. The best design protects operators while minimizing unnecessary stops during routine production tasks.
Maintenance access and lifecycle support
A robotic arm for injection molding may look efficient at startup yet become costly if lubrication points, valve islands, vacuum generators, or wear components are difficult to reach. Integration reviews should include preventive maintenance intervals, spare parts availability, troubleshooting access, and expected mean time to repair.
For project owners managing multiple cells, standardized components and clear service routes usually deliver more value than marginal speed gains. Engineering truth shows up in uptime, not in brochure claims.
How requirements differ by business size and project objective
The right robotic arm for injection molding also depends on organizational context. A greenfield facility, a retrofit line, and a multi-plant standardization program do not evaluate fit in the same way. Project leaders should align the technical review with business goals from the start.
Smaller manufacturers often prioritize flexibility and low integration complexity. Larger groups may accept higher upfront engineering effort if the result is scalable architecture, common spare strategy, and unified control standards across regions. Neither approach is wrong, but each leads to different decision criteria.
This is especially important when comparing retrofit automation against new-line deployment.
Retrofit projects
In retrofit scenarios, the robotic arm for injection molding must work around legacy machine layouts, existing guarding, inconsistent signal standards, and limited floor clearance. The practical focus should be integration risk, not idealized performance. Verification should include machine age, controller openness, available I/O, and structural mounting constraints.
Best retrofit priorities
- Confirm machine interface feasibility before final robot selection.
- Measure actual space and service access rather than using only layout drawings.
- Reserve time for debug of alarm logic and recovery sequences.
New line or standardized platform projects
For new lines, a robotic arm for injection molding can be evaluated more strategically. Teams can standardize communication protocols, EOAT interfaces, safety philosophy, and maintenance routines across multiple cells. This often improves long-term efficiency more than selecting the fastest single unit.
In these cases, project leaders should ask whether the chosen robot family supports future mold programs, data capture expectations, and workforce training consistency across sites.
Common misjudgments before line integration
Several errors appear repeatedly when companies buy a robotic arm for injection molding. Most are not caused by bad equipment, but by weak requirement definition. Recognizing these mistakes early helps teams avoid expensive redesign during commissioning.
The first mistake is assuming the quoted cycle time represents real production performance. The second is underestimating EOAT complexity. The third is treating safety and maintenance as afterthoughts rather than integration constraints.
A short pre-integration review can eliminate many of these risks.
- Do not approve the robot based only on nominal payload and arm reach.
- Do not ignore mold family variation and future program expansion.
- Do not separate robot selection from downstream transfer design.
- Do not leave alarm recovery and manual intervention logic undefined.
- Do not skip service access validation during layout review.
Practical action plan for project leaders
If you are evaluating a robotic arm for injection molding, the best next step is to build a fit-check matrix around your actual production scenario. List the current mold range, part family, EOAT concept, machine interface standard, cycle target, safety method, and maintenance expectations. Then test every candidate against those conditions rather than against generic sales claims.
For cross-functional projects, include molding, automation, maintenance, EHS, quality, and downstream process owners in the same review. Integration succeeds faster when all line constraints are visible early. This is especially true in retrofit cells and in applications involving inserts, traceability, or validated handling.
The right robotic arm for injection molding is the one that fits your scenario with measurable stability, safe access, clean handshakes, and maintainable uptime. When project teams evaluate the equipment through that lens, they reduce hidden risk and improve the probability of long-term manufacturing efficiency.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 28, 2026IDC: Global Quadruped Robot Shipments Rise 92.5% in H1 2026 as Volume and Value DivergeGlobal quadruped robot shipments rose 92.5% in H1 2026, according to IDC. Explore what diverging volume and value trends mean for industrial buyers and manufacturers.Chen Wei (Automation Lead Engineer)
 Oct 28, 2026Interpreting Industrial IoT Latency Data for Monitoring and Real-Time ControlInterpret industrial category latency data to assess jitter, deadline misses, and real-time readiness. Learn how to benchmark IIoT systems and choose monitoring and control solutions.TSV Data Lab
 Oct 27, 2026GXO and Agility Robotics Expand Partnership to Accelerate US Humanoid Robot DeploymentGXO and Agility Robotics plan to expand US humanoid robot deployment with Digit 4 in early 2027. Explore warehouse automation plans, service terms and future Digit 5 upgrades.Chen Wei (Automation Lead Engineer)
 Oct 27, 2026Robotic Automation Costs: Budgeting for Equipment, Integration, and MaintenancePlan your robotics automation cost with confidence. Explore equipment, integration, and maintenance expenses, compare quotes, and build a realistic budget for better ROI.Chen Wei (Automation Lead Engineer)
 Oct 26, 2026AMAXiMAL Releases Open-Source TopMod 3D v3 With Claude AIExplore AMAXiMAL’s free, open-source TopMod 3D v3 with Claude AI assistance, topology-based modeling and plywood fabrication tools that connect complex designs to physical builds.Dr. Marcus Vance
 Oct 26, 2026Choosing a SCADA System Integrator Company: PLC Compatibility and Long-Term SupportChoose a scada system integrator company with proven PLC compatibility and reliable long-term support. Discover what to test, compare, and require before investing.Victor Lin (Chief Software Architect)
 Oct 25, 2026Hesai Leads Global ADAS Main Lidar Shipments in Yole’s 2026 ReportHesai led global ADAS main lidar shipments with a 43% share in 2025, according to Yole’s 2026 report. Explore what this ranking reveals about its automotive market position.TSV Data Lab
 Oct 25, 2026Choosing an Aerospace Materials Manufacturer: Quality and Traceability ChecksChoosing an aerospace materials manufacturer? Learn how to verify certifications, test reports, and lot traceability to qualify suppliers confidently and reduce costly sourcing risks.Dr. Marcus Vance
 Oct 24, 2026Guotai Haitong: Global Entry-Level 3D Printer Shipments Rose 39% in Q1 2026Entry-level 3D printer shipments rose 39% in Q1 2026, Guotai Haitong reports. Explore how AI, multicolor printing and print farms are shaping market growth.Dr. Marcus Vance
 Oct 24, 2026Choosing an Industrial Vision Inspection Supplier: Acceptance Tests That MatterChoose an industrial vision inspection supplier with confidence. Discover acceptance tests for defect detection, false rejects, production speed, and reliable part rejection before you buy.TSV Data Lab
 Oct 23, 2026US Navy Raises Gecko Robotics Contract Ceiling to $300M for Robotic Fleet MaintenanceUS Navy raises Gecko Robotics’ contract ceiling to $300M for Pacific Fleet robotic inspections. Explore potential opportunities for maintenance suppliers and key procurement considerations.Chen Wei (Automation Lead Engineer)
 Oct 23, 2026Choosing Industrial Sensing Systems for Global Plants: Protocol CompatibilityCompare industrial sensing systems international buyers can trust. Explore protocol compatibility, reduce integration risks, and select proven configurations for reliable global plant deployments.TSV Data Lab
 Oct 22, 2026KUKA Showcases Physical AI and iiQKA.AI Vision at NVIDIA GTC BerlinExplore KUKA’s Physical AI showcase at NVIDIA GTC Berlin and discover how iiQKA.AI Vision aims to simplify robotic vision integration and improve 2D and 3D scene recognition.TSV Data Lab
 Oct 22, 2026Robotic Machining of Advanced Composites: What Tolerances Are Achievable?Explore advanced materials machining robotics: discover what drives achievable composite tolerances and how to validate accuracy before investing in your next machining system.Dr. Marcus Vance
 Oct 21, 2026China’s Industrial Robot Exports Near RMB 10 Billion in First Nine Months of 2026China’s industrial robot exports neared RMB 10 billion in January–September 2026, with value rising faster than volume. Explore the data and what it could mean for suppliers.Chen Wei (Automation Lead Engineer)
 Oct 21, 2026Low-Latency Industrial Data Processing: Pricing and Key Cost DriversExplore industrial data latency price drivers, from edge hardware to integration and support. Learn how to compare quotes, verify performance, and avoid unnecessary costs.TSV Data Lab
 Oct 20, 2026KUKA Launches iiQKA.AI Vision to Simplify Industrial Image ProcessingKUKA iiQKA.AI Vision simplifies industrial image processing with controller-based 2D and 3D vision. Explore drag-and-drop setup for vision-guided automation.TSV Data Lab