Collaborative Robot Payload 10kg: What It Can Really Handle on the Floor
Publication Date
author
A collaborative robot payload 10kg rating sounds straightforward, but on the shop floor it rarely tells the full story. For operators and line users, real handling capacity depends on reach, gripper weight, acceleration, part geometry, mounting angle, and cycle stability. This article breaks down what a 10kg cobot can truly manage in daily production, helping you judge safe loads, practical use cases, and the limits that matter before deployment.
Why the meaning of a collaborative robot payload 10kg is changing on modern factory floors
The market has shifted from asking whether a cobot can lift a part to asking whether it can lift that part repeatedly, safely, and without slowing the line. That is an important change. A collaborative robot payload 10kg used to sound like a clean specification for light automation. Today, operators are dealing with mixed-model production, shorter batches, faster changeovers, and tighter uptime targets. Under these conditions, rated payload alone is no longer enough for practical judgment.
This shift is driven by how cobots are being deployed. Instead of staying in simple pick-and-place cells, they are now expected to support machine tending, end-of-line packing, fixture loading, pallet sub-tasks, adhesive dispensing, inspection handling, and multi-step handling with tool changes. Each use case changes the real force, inertia, and cycle behavior. As a result, a 10kg rating has become more like a starting reference than a complete answer.
For floor users, the practical question is no longer “Is the payload 10kg?” but “What can this 10kg cobot really handle at my reach, my speed, with my gripper, and over my full shift?” That is where the true operating window appears, and that is also where many deployment mistakes begin.
Key trend signals operators should notice
- Payload ratings are being checked against full end-of-arm tooling weight, not part weight alone.
- Reach and acceleration are increasingly limiting usable load before the rated payload is reached.
- Production teams now care more about stable cycle time than maximum lift number.
- Risk reviews focus more on center of gravity, not just total mass.
- More applications are borderline cases where a 10kg cobot can do the job, but only after tuning speed and tooling.
Why this matters in day-to-day use
A collaborative robot payload 10kg may perform very well in a compact station with short movements and balanced tooling, yet struggle in a wide-reach cell with an offset gripper and frequent starts and stops. The same robot can therefore look strong in one demonstration and weak in another. Understanding that gap helps operators avoid unrealistic expectations during commissioning.
It also explains why engineering-focused evaluation matters. TechStat Vanguard consistently emphasizes that parameters must be read in operating context. On the floor, success depends less on brochure language and more on how payload, reach, inertia, and repeatability interact through a full production cycle.
What is driving the new attention on real handling capacity
Several changes are pushing users to look beyond nominal payload. First, labor pressure has moved cobots into jobs that used to be manual but irregular. These jobs often include unstable part positions, mixed SKUs, or awkward product shapes. A collaborative robot payload 10kg may seem ideal on paper, but irregular geometry can increase wrist stress and reduce safe operating speed.
Second, end-of-arm tooling has become heavier. Vacuum generators, dual grippers, force sensors, camera brackets, compliance units, and cable protection all add mass. Operators sometimes discover too late that a 7kg part is not a 7kg load once the full tool package is included. In many real cells, the usable product weight is far below the rated payload because tooling consumes a large share of capacity.
Third, safety and cycle expectations are rising together. Users want collaborative operation, but they also want throughput close to conventional automation. That creates tension. Higher speed with heavier loads can trigger reduced stability, longer settling time, or stricter safety behavior. The result is that “can lift” and “can produce efficiently” are becoming two very different judgments.
These changes explain why users now need a more practical way to interpret load ratings. The right question is not whether the robot reaches 10kg in a lab condition, but how much stable, repeatable work it can do in the actual production envelope.
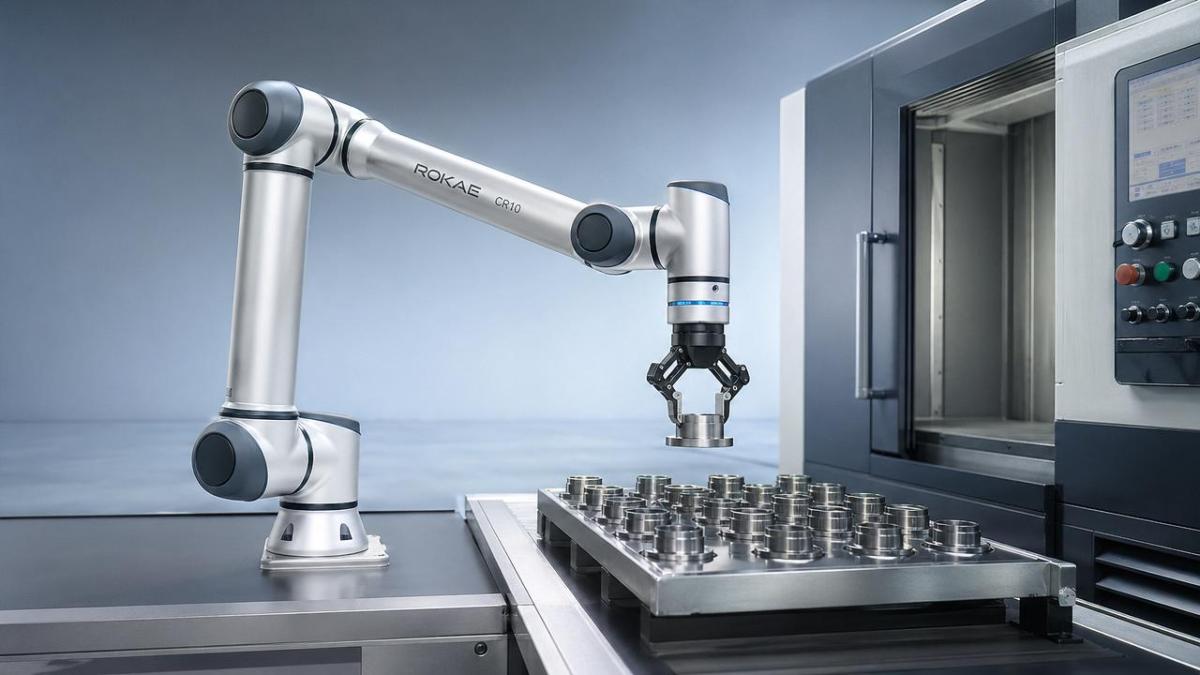
What a 10kg cobot can really handle in common floor applications
In many facilities, a collaborative robot payload 10kg performs best when the real handled product is well below 10kg. That is not a weakness. It is simply how practical automation works. Most successful deployments leave headroom for tooling mass, dynamic loads, positional variation, and future program changes. A good rule for operators is to think in terms of stable working range, not absolute maximum rating.
For short-reach pick-and-place with a light gripper, a 10kg cobot may comfortably handle products in the 6kg to 8kg range. For machine tending with a robust gripper and longer extension, the practical part weight may drop to 4kg to 6kg. For awkward or off-center parts, even lower loads may be the better operating choice if the line needs reliable cycle consistency.
This matters because many operators inherit applications after purchase decisions are already made. If you know the likely practical range, you can quickly identify whether the station needs speed reduction, tooling redesign, or a different robot class before downtime turns into a larger deployment issue.
Typical use cases and realistic payload windows
The hidden limit: not weight, but moment and motion
Operators often focus on kilograms, while the real constraint is frequently the turning effect created by distance from the wrist. A compact 8kg part may be easy for a collaborative robot payload 10kg system to move. A long 5kg component with far-off center of gravity may be harder. The robot feels not only the load, but also how that load is distributed in space.
Motion profile matters too. If the path includes fast starts, sudden stops, vertical lifting, or orientation changes, dynamic forces rise above static load conditions. That is why some cells run fine in test mode but lose smoothness when production speed is increased.
Who is affected most by these payload reality checks
The impact is strongest on operators, technicians, and line leaders because they deal with the practical gap between rated performance and daily output. When a collaborative robot payload 10kg is pushed too close to its limit, the first signs usually appear on the floor: slower motion, reduced precision at the end of reach, unstable gripping, vibration, or repeated need for parameter adjustment.
Maintenance teams are also affected. Higher working loads can increase wear on grippers, vacuum systems, cable routing, and fixtures. Even if the robot itself remains within specification, the surrounding equipment may become the weak point. That is why payload discussions should include the whole cell, not just the arm.
Procurement and engineering teams feel the impact later, especially when a system was selected based on nominal payload alone. If the application grows more complex after installation, the original 10kg decision may leave too little margin for future tooling upgrades or process changes.
Impact by role on the shop floor
- Operators: face slower cycle time or inconsistent placement when load conditions are too aggressive.
- Technicians: spend more time tuning speed, acceleration, and grip logic to recover stability.
- Maintenance staff: see more stress on end effectors and fixture hardware.
- Production supervisors: absorb the output loss if the robot must run conservatively.
- Engineers and buyers: may need redesign or upsizing if the initial payload assumption was too optimistic.
A trend toward wider safety margins
One clear direction in the market is a preference for more payload headroom. Users increasingly accept that selecting a cobot near the exact part weight can be a false economy. Slightly more capacity often improves tuning freedom, cycle consistency, and adaptation to future product changes. For line users, this trend means payload evaluation is becoming less about minimum purchase price and more about long-term operating resilience.
How to judge a collaborative robot payload 10kg before deployment
Before approving a cell, operators and users should translate the 10kg specification into a simple floor checklist. Start with full handled mass: part, gripper, adapter plate, sensor bracket, hose set, and any future add-ons. Then review the farthest reach point, the fastest motion segment, and the least stable gripping orientation. These are usually more revealing than average conditions.
Next, examine whether the process requires gentle movement or hard acceleration. A collaborative robot payload 10kg may be enough for vertical lift and place, but not for a fast side transfer with abrupt deceleration. Floor users should ask to test the exact path, not just a simplified demo path. Real performance is path-dependent.
Finally, watch the end-of-cycle behavior. If the robot needs extra settling time to stop vibration, your practical throughput may be lower than expected. Many payload decisions fail not because the robot cannot carry the load, but because it cannot carry it smoothly enough for the desired takt time.
Pre-deployment evaluation checklist
- Calculate total end-of-arm mass, not product mass alone.
- Check center of gravity and part length, especially for offset grips.
- Review the longest reach and highest speed segment in the actual program.
- Test with production-grade tooling, not temporary lightweight fixtures.
- Observe vibration, overshoot, and settling at real cycle speed.
- Confirm whether mounting angle changes the usable load window.
- Leave capacity margin for future product or tooling changes.
Questions worth asking suppliers or integrators
Ask what payload is achievable at your target reach, with your target acceleration, and with your actual end effector. Ask whether the collaborative robot payload 10kg rating changes under ceiling, wall, or angled mounting. Ask what repeatability looks like near upper payload conditions over extended cycles. These are practical questions that reveal real operating limits faster than general claims.
What to watch next as cobot payload expectations continue to evolve
Looking forward, the most important trend is not simply bigger payload numbers. It is better clarity around usable payload under real production conditions. Users are becoming more data-aware. They want to know how a collaborative robot payload 10kg performs at reach, at speed, and over time. This matches a broader hard-tech shift toward measurable engineering truth rather than generic marketing claims.
Another signal is the growth of application-specific evaluation. Instead of asking whether a 10kg cobot is strong enough in general, teams are asking whether it is strong enough for machine tending, packaging, loading, or inspection transfer with their exact part family. That is a healthier direction because it aligns equipment choice with process reality.
For operators and line users, the practical takeaway is simple: treat payload as a dynamic operating window. A collaborative robot payload 10kg can be highly capable and cost-effective, but only when reach, tooling, inertia, and cycle expectations are judged together. If your team wants to understand whether this trend affects your line, focus on a few core questions: How much of the 10kg is consumed by tooling? Where is the center of gravity at the farthest point? What cycle speed is truly required? And how much margin is needed for stable operation over a full shift?
Those answers will tell you far more than the label alone. In a market moving toward higher automation flexibility, better decisions will come from application-based payload judgment, not headline specifications.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 29, 2026Aerospace Aluminum Alloy Strength: 2024-T3 vs. 7075-T6 ComparedCompare aerospace aluminum alloy strength in 2024-T3 vs. 7075-T6. Explore fatigue, corrosion, and weight trade-offs to choose the right alloy for your design.Dr. Marcus Vance
 Oct 28, 2026IDC: Global Quadruped Robot Shipments Rise 92.5% in H1 2026 as Volume and Value DivergeGlobal quadruped robot shipments rose 92.5% in H1 2026, according to IDC. Explore what diverging volume and value trends mean for industrial buyers and manufacturers.Chen Wei (Automation Lead Engineer)
 Oct 28, 2026Interpreting Industrial IoT Latency Data for Monitoring and Real-Time ControlInterpret industrial category latency data to assess jitter, deadline misses, and real-time readiness. Learn how to benchmark IIoT systems and choose monitoring and control solutions.TSV Data Lab
 Oct 27, 2026GXO and Agility Robotics Expand Partnership to Accelerate US Humanoid Robot DeploymentGXO and Agility Robotics plan to expand US humanoid robot deployment with Digit 4 in early 2027. Explore warehouse automation plans, service terms and future Digit 5 upgrades.Chen Wei (Automation Lead Engineer)
 Oct 27, 2026Robotic Automation Costs: Budgeting for Equipment, Integration, and MaintenancePlan your robotics automation cost with confidence. Explore equipment, integration, and maintenance expenses, compare quotes, and build a realistic budget for better ROI.Chen Wei (Automation Lead Engineer)
 Oct 26, 2026AMAXiMAL Releases Open-Source TopMod 3D v3 With Claude AIExplore AMAXiMAL’s free, open-source TopMod 3D v3 with Claude AI assistance, topology-based modeling and plywood fabrication tools that connect complex designs to physical builds.Dr. Marcus Vance
 Oct 26, 2026Choosing a SCADA System Integrator Company: PLC Compatibility and Long-Term SupportChoose a scada system integrator company with proven PLC compatibility and reliable long-term support. Discover what to test, compare, and require before investing.Victor Lin (Chief Software Architect)
 Oct 25, 2026Hesai Leads Global ADAS Main Lidar Shipments in Yole’s 2026 ReportHesai led global ADAS main lidar shipments with a 43% share in 2025, according to Yole’s 2026 report. Explore what this ranking reveals about its automotive market position.TSV Data Lab
 Oct 25, 2026Choosing an Aerospace Materials Manufacturer: Quality and Traceability ChecksChoosing an aerospace materials manufacturer? Learn how to verify certifications, test reports, and lot traceability to qualify suppliers confidently and reduce costly sourcing risks.Dr. Marcus Vance
 Oct 24, 2026Guotai Haitong: Global Entry-Level 3D Printer Shipments Rose 39% in Q1 2026Entry-level 3D printer shipments rose 39% in Q1 2026, Guotai Haitong reports. Explore how AI, multicolor printing and print farms are shaping market growth.Dr. Marcus Vance
 Oct 24, 2026Choosing an Industrial Vision Inspection Supplier: Acceptance Tests That MatterChoose an industrial vision inspection supplier with confidence. Discover acceptance tests for defect detection, false rejects, production speed, and reliable part rejection before you buy.TSV Data Lab
 Oct 23, 2026US Navy Raises Gecko Robotics Contract Ceiling to $300M for Robotic Fleet MaintenanceUS Navy raises Gecko Robotics’ contract ceiling to $300M for Pacific Fleet robotic inspections. Explore potential opportunities for maintenance suppliers and key procurement considerations.Chen Wei (Automation Lead Engineer)
 Oct 23, 2026Choosing Industrial Sensing Systems for Global Plants: Protocol CompatibilityCompare industrial sensing systems international buyers can trust. Explore protocol compatibility, reduce integration risks, and select proven configurations for reliable global plant deployments.TSV Data Lab
 Oct 22, 2026KUKA Showcases Physical AI and iiQKA.AI Vision at NVIDIA GTC BerlinExplore KUKA’s Physical AI showcase at NVIDIA GTC Berlin and discover how iiQKA.AI Vision aims to simplify robotic vision integration and improve 2D and 3D scene recognition.TSV Data Lab
 Oct 22, 2026Robotic Machining of Advanced Composites: What Tolerances Are Achievable?Explore advanced materials machining robotics: discover what drives achievable composite tolerances and how to validate accuracy before investing in your next machining system.Dr. Marcus Vance
 Oct 21, 2026China’s Industrial Robot Exports Near RMB 10 Billion in First Nine Months of 2026China’s industrial robot exports neared RMB 10 billion in January–September 2026, with value rising faster than volume. Explore the data and what it could mean for suppliers.Chen Wei (Automation Lead Engineer)
 Oct 21, 2026Low-Latency Industrial Data Processing: Pricing and Key Cost DriversExplore industrial data latency price drivers, from edge hardware to integration and support. Learn how to compare quotes, verify performance, and avoid unnecessary costs.TSV Data Lab