Automated guided vehicle price drops can raise total project cost
Publication Date
author
A lower automated guided vehicle price may look attractive at first glance, but in real-world automation projects it can conceal higher lifecycle costs, weaker agv lidar navigation accuracy, faster agv battery degradation rate, and integration risks across cnc automation systems. For buyers comparing agv magnetic tape vs slam comparison data, this analysis explains why engineering metrics—not headline discounts—should guide procurement decisions.
In most industrial automation programs, the visible AGV purchase price represents only one layer of the investment. Engineering teams, operators, procurement managers, and executives usually discover the real cost later: commissioning delays, route instability, battery replacement, software retrofits, and service interruptions that affect line throughput. A unit that is 12% cheaper upfront can easily become 20% to 35% more expensive over a 3- to 5-year operating period.
For data-driven organizations, especially those aligned with TSV’s engineering-first philosophy, the right question is not “Which AGV is cheaper?” but “Which AGV delivers stable navigation, predictable maintenance, and lower total project risk?” That distinction matters in facilities where CNC cells, warehouse staging, and automated material flow must operate within tight takt times and measurable tolerance windows.
Why a Lower AGV Price Often Distorts the Real Investment Picture
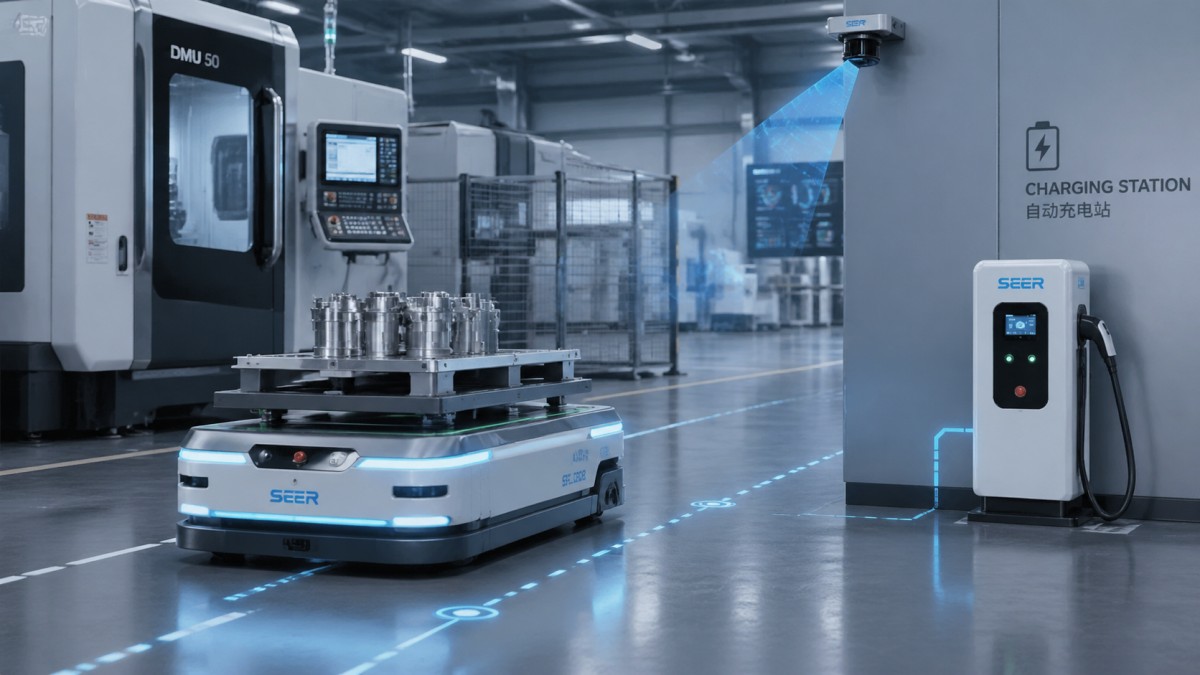
The first procurement error in AGV programs is treating the vehicle as a standalone product rather than a system node inside a larger automation architecture. An AGV does not create value by existing on the shop floor. It creates value only when navigation, charging, fleet control, traffic logic, safety zones, and machine interface protocols all work together over thousands of operating hours.
In practical deployments, a low automated guided vehicle price can be linked to compromises in sensor stack quality, lower-grade battery chemistry, reduced spare parts availability, or limited software openness. These compromises may not be obvious on a quotation sheet, yet they surface quickly when the fleet runs 16 to 24 hours per day and must handle repeated starts, stops, docking, and obstacle negotiation.
For procurement teams, the most important shift is moving from unit cost to lifecycle cost. A project should be evaluated across at least 4 dimensions: acquisition, integration, operation, and recovery from failure. If any one of those dimensions is underestimated, the budget baseline becomes misleading from day one.
The hidden cost categories that usually exceed the discount
Many factories compare AGV quotations line by line, but they do not assign enough weight to recurring cost drivers. A vehicle discounted by a few thousand dollars may require more site mapping hours, more tape maintenance, more frequent battery swaps, or longer operator interventions. These indirect costs accumulate across every shift.
- Commissioning and route tuning: typically 3 to 10 days longer when navigation algorithms are less stable.
- Battery replacement cycle: lower-grade packs may drop below useful capacity in 12 to 18 months instead of 24 to 36 months.
- Downtime cost: even 15 to 30 minutes of blocked flow per shift can disrupt CNC loading priorities.
- Software adaptation: extra middleware or API work can add weeks to deployment.
The table below shows why a lower sticker price can misrepresent the full financial impact of an AGV project.
The key takeaway is straightforward: a lower automated guided vehicle price may reduce CAPEX on paper, but it often shifts cost into OPEX, engineering labor, and production instability. For decision-makers responsible for return on automation investment, that tradeoff is rarely favorable.
Engineering Metrics That Matter More Than the Quoted AGV Price
A robust AGV selection process starts with measurable engineering criteria. In TSV-style benchmarking, the focus should be on repeatable, testable performance rather than broad vendor claims. For most industrial users, 5 metrics deserve immediate scrutiny: navigation accuracy, localization recovery time, battery performance retention, payload stability, and integration readiness.
Among these, agv lidar navigation accuracy is often the most critical for mixed-traffic facilities. If an AGV consistently deviates from its expected path by several centimeters, docking precision can deteriorate, safety buffers may widen unnecessarily, and material handoff efficiency falls. In CNC automation systems, where pallets, carts, or fixtures must align with stations, even a ±10 mm to ±20 mm positional variance can create repeated micro-delays.
Battery behavior is the second major metric. Buyers should not only ask for nominal battery capacity; they should also request expected retention after defined charge cycles, charging window requirements, and operating performance under temperature swings. In many plants, vehicles see frequent partial charging, which can accelerate usable capacity loss if pack quality or battery management is weak.
Minimum technical checkpoints before purchase approval
Instead of relying on brochure language, procurement and engineering teams should request documented thresholds or demonstration data. Even if vendors use different test methods, comparative ranges still provide decision value.
- Path repeatability at standard payload, ideally reviewed over 50 to 100 cycles.
- Localization recovery time after obstacle interference, preferably below 3 to 5 seconds in routine conditions.
- Battery retention trend after 500 to 1,000 charge cycles.
- Docking consistency at transfer points, especially in machine-tending applications.
- API or PLC interface readiness for MES, WMS, or CNC cell controllers.
Why these metrics influence total project cost
Each of these measurements directly affects labor, uptime, and expansion readiness. A fleet with better path stability may reduce manual intervention calls by several times per week. A battery pack that maintains useful performance for 30 months instead of 15 months lowers both replacement spend and maintenance disruption. Open integration support can shorten deployment from 12 weeks to 8 weeks in some projects, depending on site complexity.
This is why engineering metrics should be reviewed alongside cost models. If the AGV will feed CNC machines, support intralogistics routes, or operate in narrow aisles with pedestrians and forklifts, weak technical performance becomes expensive very quickly.
AGV Magnetic Tape vs SLAM Comparison Data: Which Choice Fits Industrial Reality?
One of the most common buying questions is whether to choose magnetic tape guidance or SLAM-based navigation. The answer depends on route stability, plant change frequency, traffic complexity, and long-term expansion plans. A lower-price AGV often uses simpler guidance because it reduces initial hardware and software cost, but that does not automatically make it the lower-cost option over the life of the project.
Magnetic tape systems can work well in highly fixed environments with repetitive point-to-point flows. They are often easier to understand for operators, and initial commissioning can be relatively fast in a simple layout. However, tape can wear, detach, or require updates when the plant changes aisle geometry, machine positions, or safety boundaries.
SLAM navigation is usually more flexible for dynamic factories, especially where routes evolve over 6- to 18-month intervals. It generally supports broader route optimization and can reduce physical floor modifications, but performance depends heavily on sensor quality, software maturity, and environmental conditions such as reflectivity, clutter, or frequent traffic interruptions.
Practical comparison for procurement and operations teams
The following comparison helps buyers frame the agv magnetic tape vs slam comparison in terms of engineering and project economics rather than sales positioning.
The comparison shows that lower entry cost does not guarantee lower total cost. In a facility with only 2 fixed routes and minimal future changes, magnetic tape may remain cost-effective. In a plant expecting 3 layout revisions, traffic growth, or CNC line expansion within 24 months, SLAM may offer a stronger return despite higher initial cost.
Selection guidance by plant profile
- Choose magnetic tape when floor conditions are stable, route logic is simple, and change requests are rare.
- Choose SLAM when multi-zone coordination, temporary obstacles, and future route scaling are expected.
- Request on-site simulation or pilot validation if the plant mixes forklifts, pedestrians, and CNC material transfer.
The strongest procurement decision is therefore context-specific. The right navigation method should match production volatility, not just initial price pressure.
Integration Risk Across CNC Automation Systems and Plant Software
Integration is where many “cheap” AGV projects stop looking cheap. In advanced manufacturing, AGVs rarely operate in isolation. They may need to exchange signals with CNC cells, automated doors, stack lights, conveyors, elevators, WMS software, or MES platforms. If the AGV vendor provides limited protocol support or weak implementation tools, the project timeline can extend by 2 to 6 weeks or more.
CNC automation systems are especially sensitive because machine tools run on schedules, queue logic, and precise handoff timing. A missed arrival can idle a machine. An unstable docking event can require manual correction. A poorly synchronized mission state can confuse upstream material release logic. These are not abstract software issues; they translate directly into production inefficiency.
Procurement teams should therefore include integration readiness as a scored purchasing criterion. Open communication options such as standard industrial protocols, documented APIs, alarm states, and fleet management logs are often more important than an aggressive price discount.
Common integration checkpoints before final vendor selection
A structured review process reduces commissioning surprises. The most practical approach is to define a pre-award interface checklist and require vendors to confirm what is native, what requires customization, and what depends on third-party middleware.
The essential conclusion is that integration quality directly influences ramp-up speed and system stability. If a lower-cost AGV lacks documentation, interface support, or scalable fleet logic, the “savings” can disappear during implementation.
A practical 5-step implementation sequence
- Map the material flow and identify every pickup, drop-off, and queue dependency.
- Validate navigation feasibility with real aisle widths, obstacles, and docking tolerances.
- Define interface responsibilities across AGV, CNC, PLC, and software layers.
- Run a pilot for at least 2 to 4 weeks under shift conditions.
- Approve expansion only after uptime, battery, and intervention data are reviewed.
This staged method protects both operators and management from under-scoped projects and makes supplier comparison more objective.
How Buyers Should Evaluate AGV Suppliers Beyond Price Cuts
For information researchers, operators, buyers, and enterprise decision-makers, the most effective procurement model is a weighted evaluation framework. Price should remain part of the decision, but not the dominant factor. In many industrial cases, a balanced scorecard with 25% cost, 25% technical performance, 25% integration capability, and 25% service support produces stronger long-term outcomes than price-led selection.
Operators care about usability, alarm handling, and recovery from route exceptions. Engineers care about navigation stability, software openness, and maintenance data. Procurement teams care about warranty scope, spare parts lead time, and contract clarity. Executives care about throughput, project timeline, and payback confidence. A complete selection process should address all 4 stakeholder groups at once.
This is also where a data-driven advisory approach becomes valuable. Instead of accepting marketing claims, buyers should request test scripts, demonstration criteria, and maintenance assumptions. That is consistent with TSV’s principle that parameters, tolerances, and measured behavior matter more than broad vendor language.
Recommended AGV procurement scorecard
A structured scorecard helps prevent short-term price pressure from overriding technical reality. The matrix below can be adapted for plants running 1 vehicle or 20 vehicles, and for both fixed-route and flexible navigation programs.
- Technical fit: navigation accuracy, payload match, battery profile, safety behavior.
- Integration fit: CNC handshake, API maturity, fleet software, diagnostics access.
- Operational fit: operator training, maintenance simplicity, spare-part response time.
- Commercial fit: total cost, change-order exposure, warranty, service terms.
Questions that should appear in every RFQ
An RFQ should require more than payload and speed. It should ask for path repeatability, localization recovery, charging strategy, battery retention assumptions, software update policy, spare-part lead time, and interface documentation. Even 8 to 12 carefully framed technical questions can sharply improve decision quality.
If your organization is evaluating suppliers for a new facility or retrofit project, the strongest next step is to build the decision around measurable operating conditions. Define route count, shift hours, floor change frequency, payload range, and integration points before negotiating unit price. To compare AGV options with engineering discipline, obtain a custom evaluation framework, review supplier data against your actual operating profile, and contact TSV for deeper benchmarking, procurement guidance, or a tailored automation assessment.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 24, 2026Guotai Haitong: Global Entry-Level 3D Printer Shipments Rose 39% in Q1 2026Entry-level 3D printer shipments rose 39% in Q1 2026, Guotai Haitong reports. Explore how AI, multicolor printing and print farms are shaping market growth.Dr. Marcus Vance
 Oct 24, 2026Choosing an Industrial Vision Inspection Supplier: Acceptance Tests That MatterChoose an industrial vision inspection supplier with confidence. Discover acceptance tests for defect detection, false rejects, production speed, and reliable part rejection before you buy.TSV Data Lab
 Oct 23, 2026US Navy Raises Gecko Robotics Contract Ceiling to $300M for Robotic Fleet MaintenanceUS Navy raises Gecko Robotics’ contract ceiling to $300M for Pacific Fleet robotic inspections. Explore potential opportunities for maintenance suppliers and key procurement considerations.Chen Wei (Automation Lead Engineer)
 Oct 23, 2026Choosing Industrial Sensing Systems for Global Plants: Protocol CompatibilityCompare industrial sensing systems international buyers can trust. Explore protocol compatibility, reduce integration risks, and select proven configurations for reliable global plant deployments.TSV Data Lab
 Oct 22, 2026KUKA Showcases Physical AI and iiQKA.AI Vision at NVIDIA GTC BerlinExplore KUKA’s Physical AI showcase at NVIDIA GTC Berlin and discover how iiQKA.AI Vision aims to simplify robotic vision integration and improve 2D and 3D scene recognition.TSV Data Lab
 Oct 22, 2026Robotic Machining of Advanced Composites: What Tolerances Are Achievable?Explore advanced materials machining robotics: discover what drives achievable composite tolerances and how to validate accuracy before investing in your next machining system.Dr. Marcus Vance
 Oct 21, 2026China’s Industrial Robot Exports Near RMB 10 Billion in First Nine Months of 2026China’s industrial robot exports neared RMB 10 billion in January–September 2026, with value rising faster than volume. Explore the data and what it could mean for suppliers.Chen Wei (Automation Lead Engineer)
 Oct 21, 2026Low-Latency Industrial Data Processing: Pricing and Key Cost DriversExplore industrial data latency price drivers, from edge hardware to integration and support. Learn how to compare quotes, verify performance, and avoid unnecessary costs.TSV Data Lab
 Oct 20, 2026KUKA Launches iiQKA.AI Vision to Simplify Industrial Image ProcessingKUKA iiQKA.AI Vision simplifies industrial image processing with controller-based 2D and 3D vision. Explore drag-and-drop setup for vision-guided automation.TSV Data Lab
 Oct 20, 2026Smart Industrial Edge Devices: Key Criteria for Legacy PLC IntegrationChoose smart industrial edge devices for legacy PLC integration. Discover key criteria for compatibility, data quality, security, and reliable collection without disrupting control.TSV Data Lab
 Oct 19, 2026Choosing a Radar Sensor by Application: Range, Resolution, and Field of ViewSimplify radar sensor application based product selection. Compare range, resolution, and field of view to avoid blind spots and choose with confidence. Explore the guide.TSV Data Lab
 Oct 18, 2026Comparing Material Options for Procurement: Specs, Costs, and Supply RisksExplore procurement oriented technical content on material options, specs, costs, and supply risks. Compare alternatives to cut hidden expenses and make confident sourcing decisions.Dr. Marcus Vance
 Oct 17, 20265-Axis CNC Positioning Accuracy: How to Interpret ISO 230-2 Test ResultsAssess 5 axis CNC machining positioning accuracy with ISO 230-2. Learn to interpret repeatability, reversal error, and test conditions to compare suppliers and make confident acceptance decisions.Dr. Marcus Vance
 Oct 16, 2026Choosing a Rugged Edge AI Box Supplier: Thermal Tests and Lifecycle SupportChoose a rugged edge AI box supplier with proven thermal performance and reliable lifecycle support. Discover the tests and commitments to verify before you buy.TSV Data Lab
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)
 Oct 24, 2026How Do You Measure a Machine Vision System's False Reject Rate?Measure machine vision false reject rate with the right formula, independent ground truth, and confidence intervals. Learn how to validate performance and reduce costly good-part losses.TSV Data Lab
 Oct 23, 2026How Do You Evaluate Solid-State LiDAR Point Cloud Density?Evaluate solid-state LiDAR point cloud density using valid returns, angular spacing, and real-world coverage. Discover how to compare sensors and choose the right fit for your application.TSV Data Lab