
AMR obstacle avoidance latency becomes visible in mixed traffic
Publication Date
author
In mixed warehouse traffic, AMR obstacle avoidance latency is no longer a hidden spec—it directly affects safety, flow efficiency, and deployment confidence. For engineers, operators, buyers, and decision-makers comparing agv lidar navigation accuracy, agv magnetic tape vs slam comparison, or autonomous mobile robot China options, visible latency reveals the real performance gap between marketing claims and measurable navigation behavior.
Why does obstacle avoidance latency become obvious in mixed traffic?
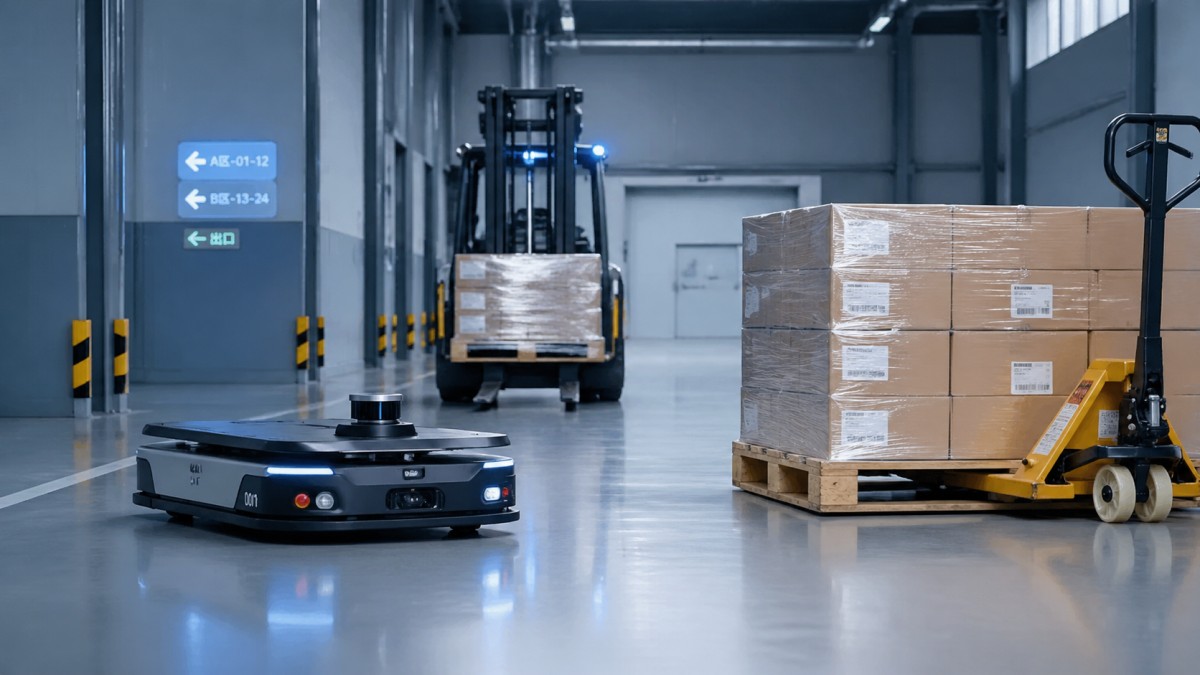
Latency stays partially hidden when an AMR runs on a clean route with predictable geometry. It becomes visible when pedestrians, forklifts, manual carts, pallet jacks, and other AMRs share the same aisle. In that environment, the system must sense, classify, plan, and brake within a very short response window. Even a delay measured in hundreds of milliseconds can translate into extra stopping distance, unstable path correction, or repeated hesitation near intersections.
For operators, the first symptom is rarely a collision. It is usually a pattern: the vehicle slows too late, swings wide around static objects, pauses twice at the same crossing, or creates a queue behind it. For buyers, this is important because brochure claims about smooth autonomy often do not describe behavior under peak traffic. A route that looks acceptable in a demo lane may perform differently during 2-shift or 3-shift operation with dense cross-flow.
For information researchers and enterprise decision-makers, the key question is not whether an AMR can avoid obstacles at all. The real question is how consistently it does so across changing loads, reflective surfaces, narrow turning radii, and temporary obstructions. TechStat Vanguard focuses on these measurable engineering truths because navigation quality is not defined by labels such as “smart” or “advanced.” It is defined by response timing, path stability, and fault tolerance under real warehouse pressure.
In practical evaluation, mixed traffic usually exposes three latency layers within the first 1–2 weeks of pilot operation: sensor perception delay, planning delay, and actuation delay. If one layer is weak, the AMR may still pass a controlled test but fail to maintain stable throughput in a live facility. This is why obstacle avoidance latency has become a procurement issue, not just a controls issue.
What makes latency visible instead of theoretical?
Visibility comes from interaction density. A single AMR on an empty route can hide poor timing through conservative speed settings. In contrast, a mixed-traffic aisle with 5–20 crossing events per hour forces the navigation stack to react continuously. Delayed reaction appears as brake jitter, lane oscillation, missed passing windows, and stop-and-go behavior that human operators quickly notice.
Payload also matters. A loaded unit may require a different braking profile than an unloaded one, especially on polished concrete, ramps, or dusty surfaces. If a vendor presents latency only in ideal low-load conditions, the result may mislead procurement teams. A reliable technical review should separate unloaded testing, nominal payload testing, and near-capacity testing.
- High crossing density reveals whether the navigation controller updates fast enough for continuous replanning.
- Variable loads show whether the motion system preserves braking predictability across different inertia states.
- Mixed obstacles test classification quality, including people, pallets, rack legs, shrink wrap reflections, and moving vehicles.
Which technical indicators actually explain AMR response quality?
Many procurement documents focus on top speed, battery life, and payload, but those figures do not explain how an AMR behaves in mixed traffic. To understand obstacle avoidance performance, buyers should examine a chain of indicators rather than one headline number. That chain includes sensor update rate, localization stability, planning cycle time, braking response, safety zone configuration, and recovery behavior after temporary blockage.
This is also where agv lidar navigation accuracy enters the conversation. Good LiDAR-based navigation is not only about position accuracy in a static map. It also depends on how the system handles transient obstacles, reflective materials, shelf gaps, and dynamic clutter. A platform with tight map repeatability but weak dynamic replanning can still underperform once human and machine traffic mix.
The table below shows practical evaluation dimensions for obstacle avoidance latency. The ranges are not universal pass-fail thresholds; they are reference points for structured comparison during pilot review, factory acceptance planning, and supplier discussion.
A useful lesson from field evaluations is that no single number defines navigation quality. An AMR with acceptable straight-line response may still perform poorly at 90-degree turns or near rack ends. That is why TSV emphasizes parameter relationships. Parameters do not lie, but isolated parameters can still mislead if they are not tested in the exact scenario that matters to your facility.
Key engineering checks before shortlisting a supplier
Before moving to price negotiation, teams should define at least 4 core checks: dynamic obstacle response, narrow-aisle stability, stop-and-resume smoothness, and degraded-condition behavior. Degraded conditions include dim lighting for vision-assisted systems, reflective packaging, partial route obstruction, and temporary wireless delay if fleet coordination is cloud-assisted or edge-dependent.
Recommended shortlist checklist
- Request test evidence for 3 traffic states: low traffic, moderate traffic, and peak crossing conditions.
- Check whether agv lidar navigation accuracy degrades near reflective film, shiny floor patches, or repetitive rack geometry.
- Confirm the recovery process after obstacle removal: immediate continue, map refresh, operator approval, or full reroute.
- Review payload-specific stopping behavior instead of accepting one generic safety claim.
For enterprise decision-makers, these checks shorten supplier qualification cycles. They also reduce the risk of discovering navigation weakness only after integration with WMS, MES, rack systems, and manual material handling routines.
AGV magnetic tape vs SLAM comparison: where does latency risk change?
The phrase agv magnetic tape vs slam comparison appears frequently in early-stage research because route guidance architecture influences both deployment complexity and dynamic behavior. Magnetic tape and similar fixed-guidance approaches can work well in stable, repetitive paths, especially where process variation is low and route changes are infrequent. SLAM-based AMRs offer more route flexibility, but flexibility alone does not guarantee better mixed-traffic performance.
In mixed traffic, the practical trade-off is this: fixed-path systems are often easier to predict but less adaptive when obstructions appear, while SLAM-based systems can reroute more naturally but depend heavily on map quality, sensor fusion, and planning software maturity. Procurement teams should avoid turning this into a binary “old versus new” debate. The real issue is operational fit.
The comparison table below helps separate route method, latency exposure, and use-case suitability. This is particularly helpful when evaluating autonomous mobile robot China suppliers, global AMR integrators, or hybrid facilities that may use both AGV and AMR fleets in different zones.
The takeaway is not that one architecture wins everywhere. A facility with 6–12 fixed transfer points may gain more from route certainty than from advanced rerouting. A site with seasonal layout changes, temporary pallets in aisles, and human-heavy picking zones may benefit more from SLAM. Decision-makers should therefore compare traffic reality, not just vendor vocabulary.
When should buyers question a smooth demo?
A smooth demo deserves scrutiny when it uses low speed, wide aisles, minimal crossing traffic, or unrealistically clean floor space. Buyers should ask whether the demonstration includes 3 common disturbances: moving people, temporary pallet obstruction, and multi-vehicle crossing. If not, the observed latency may understate real deployment behavior.
This is especially important in autonomous mobile robot China sourcing, where supplier diversity is wide. Some manufacturers are strong in hardware cost control, others in fleet orchestration, and others in application engineering. A buyer who only compares list price may miss the larger cost of underperforming navigation after installation.
How should procurement teams evaluate AMR suppliers and deployment risk?
Procurement should treat obstacle avoidance latency as a cross-functional requirement linking engineering, operations, EHS, and finance. A low upfront price may lose value if the AMR requires excessive route restrictions, extra floor markings, manual traffic marshaling, or prolonged tuning. In many warehouses, the hidden cost is not the robot itself; it is the productivity loss from frequent hesitation or operator interventions.
A practical sourcing process often uses 4 stages over 2–8 weeks: requirement definition, controlled pilot, mixed-traffic validation, and commercial closure. During the pilot, teams should document event logs rather than relying only on visual impressions. Log-based review helps compare supplier claims with actual stop frequency, reroute count, false positive avoidance, and recovery time after blockage.
The table below provides a procurement scoring framework that supports information researchers, operators, buyers, and enterprise leaders. It helps convert a vague discussion about “smart avoidance” into a repeatable vendor comparison method.
Procurement teams should also ask for clear documentation on operating envelope limits. These include floor flatness assumptions, aisle width requirements, nominal payload band, charging strategy, and temperature or dust sensitivity if relevant. In data-driven sourcing, a supplier who states limits clearly is often more useful than one who makes broad claims without operational boundaries.
Four implementation checks before final approval
- Run a pilot in at least 2 route types: straight transport lanes and congested crossing zones.
- Verify behavior over 3 operating states: unloaded, typical load, and near-rated load.
- Track intervention frequency during 1 full shift instead of relying on a short demonstration.
- Review whether changes can be solved by software tuning, layout adaptation, or hardware upgrades.
This disciplined process helps companies separate navigation problems from layout problems. It also supports faster commercial decisions because technical objections can be tied to evidence rather than internal debate.
Common misconceptions, FAQ, and what decision-makers should ask next
Mixed-traffic AMR projects often fail at the evaluation stage because teams compare generic autonomy claims instead of measurable behavior. The questions below reflect what engineers, operators, and procurement managers usually need clarified before approval. They also improve search relevance for buyers exploring agv lidar navigation accuracy, agv magnetic tape vs slam comparison, and autonomous mobile robot China sourcing routes.
Does faster always mean better for obstacle avoidance?
No. Higher travel speed can improve throughput only if sensing, planning, and braking remain stable within the site’s actual traffic density. In some facilities, reducing speed by a modest range while improving path confidence delivers better hourly flow because the AMR pauses less often. The right target is balanced performance: safe travel, low hesitation, and acceptable cycle time.
Is LiDAR-based navigation always superior to fixed guidance?
Not always. LiDAR SLAM is usually more flexible, especially where routes change every few months or where temporary obstructions are common. But fixed guidance can remain efficient in stable loops with limited crossing complexity. Buyers should compare not only route technology but also maintenance burden, traffic pattern, aisle discipline, and the cost of future layout changes over 12–36 months.
What is the most common procurement mistake?
The most common mistake is approving a system based on a clean demo and then expecting equivalent performance in a live warehouse. Another frequent error is requesting only top-level specifications without asking how the vendor measures response behavior under clutter, payload variation, and repeated crossings. If latency is not defined in the evaluation process, it will appear later as an operational complaint.
How long should a practical validation take?
A meaningful validation often takes 7–15 days for a focused pilot and longer if integration with doors, elevators, or enterprise systems is included. Very short tests can confirm basic function, but they rarely reveal traffic-driven hesitation patterns. Buyers should include at least several repeated route cycles, multiple shift windows, and representative load conditions before forming a conclusion.
Why choose TSV for AMR benchmarking and supplier evaluation support?
TechStat Vanguard supports hard-tech sourcing with an engineering-first method. We do not reduce AMR evaluation to slogans, and we do not treat navigation claims as self-proving. Our role is to help teams define what must be measured, where marketing language masks technical risk, and which parameters belong in a serious supplier comparison workflow.
If your team is comparing agv lidar navigation accuracy, building an agv magnetic tape vs slam comparison, or screening autonomous mobile robot China suppliers, we can help structure the decision around evidence. That includes parameter confirmation, pilot evaluation criteria, deployment risk mapping, route suitability analysis, and supplier communication points that shorten qualification cycles.
You can contact TSV for support on 6 practical topics: obstacle avoidance parameter review, navigation architecture selection, delivery timeline planning, customization scope definition, compliance and safety documentation review, and quotation comparison logic. For teams under time pressure, this creates a clearer path from early research to shortlist and final procurement approval.
If you need a data-driven benchmark template, a mixed-traffic test checklist, or a structured framework for vendor interviews, reach out with your site conditions, payload range, aisle constraints, and integration needs. Engineering truth starts with measurable questions, and that is where better AMR decisions begin.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 25, 2026Hesai Leads Global ADAS Main Lidar Shipments in Yole’s 2026 ReportHesai led global ADAS main lidar shipments with a 43% share in 2025, according to Yole’s 2026 report. Explore what this ranking reveals about its automotive market position.TSV Data Lab
 Oct 25, 2026Choosing an Aerospace Materials Manufacturer: Quality and Traceability ChecksChoosing an aerospace materials manufacturer? Learn how to verify certifications, test reports, and lot traceability to qualify suppliers confidently and reduce costly sourcing risks.Dr. Marcus Vance
 Oct 24, 2026Guotai Haitong: Global Entry-Level 3D Printer Shipments Rose 39% in Q1 2026Entry-level 3D printer shipments rose 39% in Q1 2026, Guotai Haitong reports. Explore how AI, multicolor printing and print farms are shaping market growth.Dr. Marcus Vance
 Oct 24, 2026Choosing an Industrial Vision Inspection Supplier: Acceptance Tests That MatterChoose an industrial vision inspection supplier with confidence. Discover acceptance tests for defect detection, false rejects, production speed, and reliable part rejection before you buy.TSV Data Lab
 Oct 23, 2026US Navy Raises Gecko Robotics Contract Ceiling to $300M for Robotic Fleet MaintenanceUS Navy raises Gecko Robotics’ contract ceiling to $300M for Pacific Fleet robotic inspections. Explore potential opportunities for maintenance suppliers and key procurement considerations.Chen Wei (Automation Lead Engineer)
 Oct 23, 2026Choosing Industrial Sensing Systems for Global Plants: Protocol CompatibilityCompare industrial sensing systems international buyers can trust. Explore protocol compatibility, reduce integration risks, and select proven configurations for reliable global plant deployments.TSV Data Lab
 Oct 22, 2026KUKA Showcases Physical AI and iiQKA.AI Vision at NVIDIA GTC BerlinExplore KUKA’s Physical AI showcase at NVIDIA GTC Berlin and discover how iiQKA.AI Vision aims to simplify robotic vision integration and improve 2D and 3D scene recognition.TSV Data Lab
 Oct 22, 2026Robotic Machining of Advanced Composites: What Tolerances Are Achievable?Explore advanced materials machining robotics: discover what drives achievable composite tolerances and how to validate accuracy before investing in your next machining system.Dr. Marcus Vance
 Oct 21, 2026China’s Industrial Robot Exports Near RMB 10 Billion in First Nine Months of 2026China’s industrial robot exports neared RMB 10 billion in January–September 2026, with value rising faster than volume. Explore the data and what it could mean for suppliers.Chen Wei (Automation Lead Engineer)
 Oct 21, 2026Low-Latency Industrial Data Processing: Pricing and Key Cost DriversExplore industrial data latency price drivers, from edge hardware to integration and support. Learn how to compare quotes, verify performance, and avoid unnecessary costs.TSV Data Lab
 Oct 20, 2026KUKA Launches iiQKA.AI Vision to Simplify Industrial Image ProcessingKUKA iiQKA.AI Vision simplifies industrial image processing with controller-based 2D and 3D vision. Explore drag-and-drop setup for vision-guided automation.TSV Data Lab
 Oct 20, 2026Smart Industrial Edge Devices: Key Criteria for Legacy PLC IntegrationChoose smart industrial edge devices for legacy PLC integration. Discover key criteria for compatibility, data quality, security, and reliable collection without disrupting control.TSV Data Lab
 Oct 19, 2026Choosing a Radar Sensor by Application: Range, Resolution, and Field of ViewSimplify radar sensor application based product selection. Compare range, resolution, and field of view to avoid blind spots and choose with confidence. Explore the guide.TSV Data Lab
 Oct 18, 2026Comparing Material Options for Procurement: Specs, Costs, and Supply RisksExplore procurement oriented technical content on material options, specs, costs, and supply risks. Compare alternatives to cut hidden expenses and make confident sourcing decisions.Dr. Marcus Vance
 Oct 17, 20265-Axis CNC Positioning Accuracy: How to Interpret ISO 230-2 Test ResultsAssess 5 axis CNC machining positioning accuracy with ISO 230-2. Learn to interpret repeatability, reversal error, and test conditions to compare suppliers and make confident acceptance decisions.Dr. Marcus Vance
 Oct 16, 2026Choosing a Rugged Edge AI Box Supplier: Thermal Tests and Lifecycle SupportChoose a rugged edge AI box supplier with proven thermal performance and reliable lifecycle support. Discover the tests and commitments to verify before you buy.TSV Data Lab
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)























