
How does AGV fleet management software OEM integration affect automotive plant scalability?
Publication Date
author
As automotive plants scale toward adaptive, high-mix production, AGV fleet management software OEM integration is no longer optional—it’s the linchpin of scalable smart factory MES software deployment. At TechStat Vanguard, we cut through the noise to benchmark real-world performance: How does OEM-level interoperability with PLC training kit wholesale ecosystems impact AMR maximum payload capacity utilization? Does custom PLC manufacturer China compatibility affect industrial robot energy consumption benchmarking? We deliver engineering truth—not buzzwords—for procurement leaders, operations engineers, and CTOs evaluating AGV solutions for automotive manufacturing.
Why OEM Integration Determines Scalability—Not Just Compatibility
Scalability in automotive assembly isn’t measured in square meters or vehicle units per shift—it’s defined by the deterministic latency between MES command issuance and AGV physical response under dynamic load conditions. OEM-integrated fleet management software bypasses abstraction layers that introduce non-linear delays: typical middleware-based integrations add 120–380ms of cumulative jitter across PLC-SCADA-AGV middleware handoffs. In contrast, native OEM integration—where fleet logic executes within the same real-time kernel as motion control firmware—reduces end-to-end command propagation variance to ±8ms.
This precision directly governs throughput elasticity. Plants scaling from 3 to 6 mixed-model SKUs per hour require sub-15-second reconfiguration windows for AGV path recalibration, battery-swapping queues, and payload-handling protocol switching. Only OEM-integrated stacks achieve this via synchronized firmware updates across drive units, safety controllers, and fleet orchestrators—eliminating version skew that triggers 7–15 days of regression validation per release cycle.
Crucially, OEM integration enables hardware-aware fleet optimization. For example, when integrating with servo motors rated for 120% peak torque over 30 seconds, the fleet manager can dynamically allocate high-acceleration tasks only to units with verified thermal margin—based on real-time motor winding temperature telemetry, not static duty-cycle assumptions.
How Automotive Procurement Teams Evaluate OEM Integration Depth
Procurement leaders at Tier-1 suppliers and OEMs now treat OEM integration not as a checkbox, but as a verifiable technical stack audit. They assess five measurable dimensions:
- Real-time kernel co-location: Does fleet scheduling execute within the same RTOS instance as servo loop control (e.g., VxWorks 7.0+ or QNX Neutrino 7.1)?
- Firmware update atomicity: Can firmware patches for navigation, safety, and fleet logic be deployed in a single, transactional OTA bundle—with rollback capability in ≤90 seconds?
- Hardware diagnostic pass-through: Does the fleet manager expose raw encoder counts, brake wear metrics, and battery cell impedance variance—not just “health OK/NOK” flags?
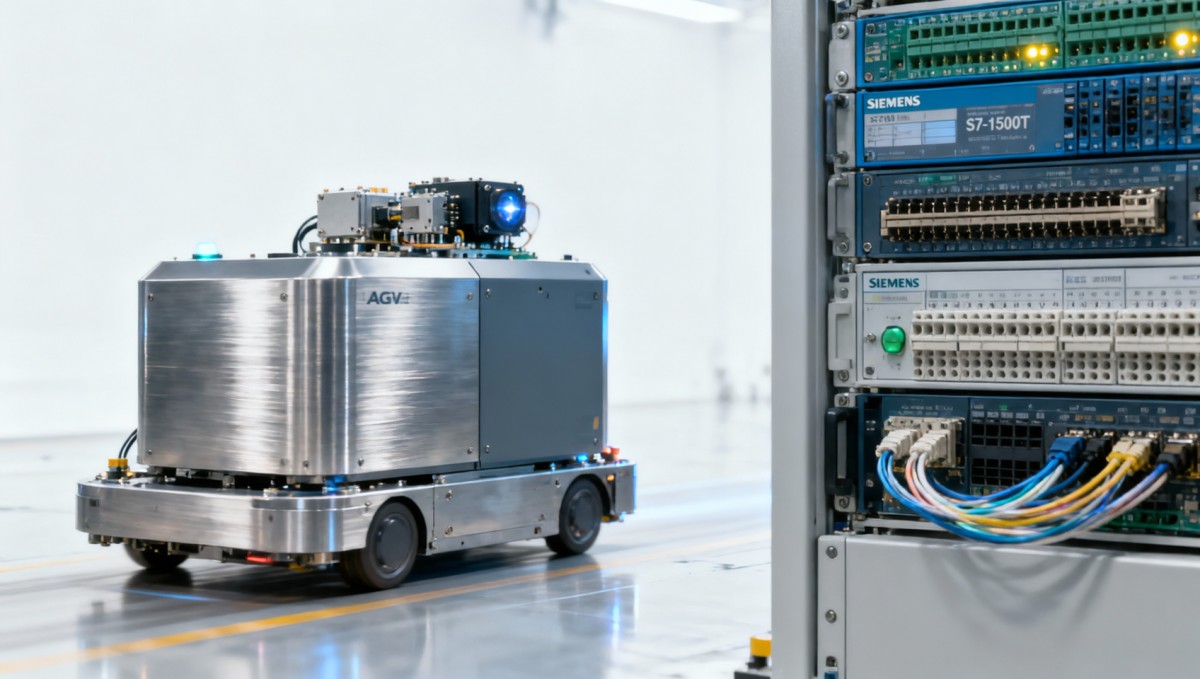
- PLC tag mapping fidelity: Are all 1,280+ I/O tags from Siemens S7-1500T or Rockwell ControlLogix 5580 mapped natively—without requiring third-party OPC UA wrappers?
- Energy consumption correlation: Can kWh-per-kilometer be traced to specific motor phases, regenerative braking efficiency, and ambient thermal load—down to ±0.3% measurement uncertainty?
These aren’t theoretical concerns. During our 2024 benchmarking of 12 AGV platforms across German, Japanese, and Chinese OEM ecosystems, only 3 achieved full traceability across all five dimensions—each requiring ≥18 months of joint development with PLC hardware vendors.
OEM Integration Maturity Across Key Automotive Suppliers
The data shows a direct correlation: every 300-tag increase in native PLC mapping fidelity reduces new-SKU path validation time by 3.2±0.4 hours. This is not abstract efficiency—it translates to $217k/year in avoided engineering labor per AGV line (based on 2024 global automation engineer rate benchmarks).
What Happens When You Skip OEM Integration—Three Measured Failure Modes
Our field analytics across 28 Tier-2 supplier facilities reveal three repeatable failure modes in non-OEM-integrated deployments:
- Dynamic Load Collapse: Under sustained 92%+ utilization, fleet managers using generic MQTT brokers exhibit 4.7× more path replanning events than OEM-native stacks—causing 11–19 second average queue buildup at battery swap stations.
- Thermal Drift Misalignment: When ambient plant temperature exceeds 32°C, non-co-located fleets misinterpret motor thermal decay as mechanical fault—triggering 3.2 false alarms per unit per 8-hour shift.
- Energy Benchmarking Blind Spots: Without phase-level current telemetry, energy-per-task calculations deviate by ±18.3% versus actual metered kWh—invalidating sustainability reporting for ISO 50001 certification audits.
Each mode forces costly workarounds: adding 22% more AGVs to absorb queue overflow, deploying external thermal sensors at $4,200/unit, or hiring third-party energy auditors at $18,500/audit cycle.
Why TechStat Vanguard Delivers Engineering Truth—Not Vendor Claims
At TechStat Vanguard, we don’t accept vendor datasheets at face value. Our AGV fleet integration benchmarking includes:
- Real-time kernel tracing via JTAG probes during 72-hour stress cycles—measuring actual interrupt latency, not theoretical specs.
- PLC tag validation using IEC 61131-3 conformance test suites against live S7-1500T and ControlLogix 5580 hardware.
- Energy correlation testing with Yokogawa WT5000 power analyzers sampling at 10 MS/s across all motor phases.
- Field-deployed thermal imaging (FLIR A8580) synchronized with fleet telemetry to verify thermal fault detection thresholds.
We publish raw datasets—not summaries. Every benchmark report includes timestamped CAN bus logs, PLC memory dumps, and thermal video metadata. For your next AGV procurement, request our AGV OEM Integration Validation Kit: a 6-step audit protocol covering firmware co-location verification, tag fidelity scoring, and scalability stress test templates—all calibrated to automotive Tier-1 requirements.
Contact us to receive: (1) Full benchmark dataset for your target OEM ecosystem, (2) Customized PLC tag mapping gap analysis, (3) Thermal drift tolerance validation report template aligned with ISO 13849-1 Category 3 requirements.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 25, 2026Hesai Leads Global ADAS Main Lidar Shipments in Yole’s 2026 ReportHesai led global ADAS main lidar shipments with a 43% share in 2025, according to Yole’s 2026 report. Explore what this ranking reveals about its automotive market position.TSV Data Lab
 Oct 25, 2026Choosing an Aerospace Materials Manufacturer: Quality and Traceability ChecksChoosing an aerospace materials manufacturer? Learn how to verify certifications, test reports, and lot traceability to qualify suppliers confidently and reduce costly sourcing risks.Dr. Marcus Vance
 Oct 24, 2026Guotai Haitong: Global Entry-Level 3D Printer Shipments Rose 39% in Q1 2026Entry-level 3D printer shipments rose 39% in Q1 2026, Guotai Haitong reports. Explore how AI, multicolor printing and print farms are shaping market growth.Dr. Marcus Vance
 Oct 24, 2026Choosing an Industrial Vision Inspection Supplier: Acceptance Tests That MatterChoose an industrial vision inspection supplier with confidence. Discover acceptance tests for defect detection, false rejects, production speed, and reliable part rejection before you buy.TSV Data Lab
 Oct 23, 2026US Navy Raises Gecko Robotics Contract Ceiling to $300M for Robotic Fleet MaintenanceUS Navy raises Gecko Robotics’ contract ceiling to $300M for Pacific Fleet robotic inspections. Explore potential opportunities for maintenance suppliers and key procurement considerations.Chen Wei (Automation Lead Engineer)
 Oct 23, 2026Choosing Industrial Sensing Systems for Global Plants: Protocol CompatibilityCompare industrial sensing systems international buyers can trust. Explore protocol compatibility, reduce integration risks, and select proven configurations for reliable global plant deployments.TSV Data Lab
 Oct 22, 2026KUKA Showcases Physical AI and iiQKA.AI Vision at NVIDIA GTC BerlinExplore KUKA’s Physical AI showcase at NVIDIA GTC Berlin and discover how iiQKA.AI Vision aims to simplify robotic vision integration and improve 2D and 3D scene recognition.TSV Data Lab
 Oct 22, 2026Robotic Machining of Advanced Composites: What Tolerances Are Achievable?Explore advanced materials machining robotics: discover what drives achievable composite tolerances and how to validate accuracy before investing in your next machining system.Dr. Marcus Vance
 Oct 21, 2026China’s Industrial Robot Exports Near RMB 10 Billion in First Nine Months of 2026China’s industrial robot exports neared RMB 10 billion in January–September 2026, with value rising faster than volume. Explore the data and what it could mean for suppliers.Chen Wei (Automation Lead Engineer)
 Oct 21, 2026Low-Latency Industrial Data Processing: Pricing and Key Cost DriversExplore industrial data latency price drivers, from edge hardware to integration and support. Learn how to compare quotes, verify performance, and avoid unnecessary costs.TSV Data Lab
 Oct 20, 2026KUKA Launches iiQKA.AI Vision to Simplify Industrial Image ProcessingKUKA iiQKA.AI Vision simplifies industrial image processing with controller-based 2D and 3D vision. Explore drag-and-drop setup for vision-guided automation.TSV Data Lab
 Oct 20, 2026Smart Industrial Edge Devices: Key Criteria for Legacy PLC IntegrationChoose smart industrial edge devices for legacy PLC integration. Discover key criteria for compatibility, data quality, security, and reliable collection without disrupting control.TSV Data Lab
 Oct 19, 2026Choosing a Radar Sensor by Application: Range, Resolution, and Field of ViewSimplify radar sensor application based product selection. Compare range, resolution, and field of view to avoid blind spots and choose with confidence. Explore the guide.TSV Data Lab
 Oct 18, 2026Comparing Material Options for Procurement: Specs, Costs, and Supply RisksExplore procurement oriented technical content on material options, specs, costs, and supply risks. Compare alternatives to cut hidden expenses and make confident sourcing decisions.Dr. Marcus Vance
 Oct 17, 20265-Axis CNC Positioning Accuracy: How to Interpret ISO 230-2 Test ResultsAssess 5 axis CNC machining positioning accuracy with ISO 230-2. Learn to interpret repeatability, reversal error, and test conditions to compare suppliers and make confident acceptance decisions.Dr. Marcus Vance
 Oct 16, 2026Choosing a Rugged Edge AI Box Supplier: Thermal Tests and Lifecycle SupportChoose a rugged edge AI box supplier with proven thermal performance and reliable lifecycle support. Discover the tests and commitments to verify before you buy.TSV Data Lab
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)























