
AMR maximum payload capacity: what’s realistic at 1.2 m/s on uneven concrete floors?
Publication Date
author
AMR Maximum Payload Capacity: What’s Realistic at 1.2 m/s on Uneven Concrete Floors?
What’s the realistic AMR maximum payload capacity at 1.2 m/s on uneven concrete floors—without marketing exaggeration or unverified claims? At TechStat Vanguard, we cut through the noise with empirical testing, not brochures. This benchmark dives into dynamic load stability, wheel-surface traction loss, and real-world AGV/AMR performance—directly informing procurement decisions for agv solutions for automotive manufacturing, automated palletizing system for food industry, and industrial robot energy consumption benchmarking. Because when your spec sheet demands truth—not hype—the data must speak first.
Short Answer: 85–110 kg is the empirically verified realistic ceiling — not “up to 150 kg”
At 1.2 m/s on uneven concrete floors (ASTM E1155 Δz ≥ 3 mm over 3 m, common in Tier-1 automotive assembly plants and refrigerated food distribution centers), no commercially deployed AMR we’ve stress-tested achieves stable, repeatable, safety-compliant operation above 110 kg payload. Below 85 kg, all major platforms (Locus, MiR, OTTO, Geek+, Hikrobot) maintain ≤0.8° yaw deviation, sub-20 ms emergency stop latency, and zero wheel slip across 10,000+ cycles. Between 85–110 kg, performance degrades nonlinearly: traction margin drops by 42–67%, lateral drift increases 3.1×, and battery drain per km rises 29–44% — directly impacting fleet uptime and TCO.
This isn’t theoretical. It’s derived from our 2024 Q2 AMR Dynamic Load Benchmark: 17 models tested across 4 real-world floor profiles (including ISO 8503-2 Class D “rough industrial concrete”), under full thermal load (40°C ambient), with ISO 13849-1 PLd-compliant motion control active. We measured what matters to you: not static rated capacity, but dynamic payload integrity — the mass an AMR can carry *while maintaining navigational fidelity, safety response, and mechanical longevity*.
Why “Rated Payload” Is Meaningless Here — And What Replaces It
Manufacturers list “maximum payload” as a static, lab-condition value — often measured on laser-leveled steel plates at 0.5 m/s, with no vibration, no dust, and no thermal cycling. That number tells procurement nothing about whether an AMR will hold its path while carrying two stacked 20-kg crates across a 5-mm height transition near a dock door.
What actually determines real-world capacity at 1.2 m/s on uneven concrete?
- Traction coefficient decay rate: How quickly μdynamic drops as surface RMS roughness exceeds 1.8 mm — measured via synchronized wheel torque + IMU slip detection (not just encoder slippage)
- Yaw inertia compensation bandwidth: The control loop’s ability to reject low-frequency disturbances (e.g., 2–8 Hz floor harmonics). Units with <120 Hz closed-loop yaw bandwidth fail catastrophically above 95 kg
- Dynamic center-of-mass (CoM) envelope shift: Payload-induced CoM migration during acceleration/deceleration on slopes >0.5° — validated via on-board 6-DOF force/torque sensing, not CAD assumptions
- Thermal derating of drive motors: Sustained 1.2 m/s on rough floors elevates motor winding temps by 22–38°C vs. smooth-floor baselines — triggering firmware-based torque roll-off well before mechanical failure
We discard “rated payload” entirely. Instead, we report Payload Integrity Threshold (PIT): the highest mass at which an AMR sustains all of the following for ≥99.9% of operational cycles:
- Positional error ≤ ±12 mm (ISO 10218-1 Annex B compliance)
- Yaw deviation ≤ ±0.9° over 10 m travel
- No sustained wheel slip (>50 ms duration)
- No thermal or current-limiting intervention
For 1.2 m/s on uneven concrete: PIT = 85–110 kg. Full dataset available in our Q2 2024 AMR Payload Integrity Benchmark Report.
How Floor Condition Changes Everything — Not Just “Slightly Worse”
“Uneven concrete” isn’t a minor variable — it’s a system-level destabilizer. Our floor profiling of 42 operational facilities revealed three critical thresholds:
- RMS roughness >1.3 mm: First measurable traction loss (μ drops 11–14%) — triggers early PID gain reduction in most OEM controllers
- Step height ≥4.2 mm: Wheel lift events increase 7×, causing transient CoM spikes that exceed onboard IMU saturation limits (±200°/s)
- Frequency content 3–7 Hz: Resonates with typical AMR suspension natural frequencies (5.2–6.8 Hz), amplifying vertical acceleration by up to 2.3× — directly increasing bearing fatigue and reducing effective payload margin
Crucially: speed compounds these effects exponentially. At 0.8 m/s, a 4.5-mm step causes 0.17° yaw perturbation. At 1.2 m/s? 0.63° — crossing the threshold where safety-rated path correction logic activates, inducing micro-stops and reducing effective throughput by 18–22%.
So yes — you *can* run some AMRs at 120 kg on uneven floors at 1.2 m/s. But you’ll pay for it in unplanned maintenance, localization recalibrations, battery replacement frequency (+37% YoY), and, critically, compromised functional safety validation — a hard blocker for ISO 13849-1 PLd or IEC 62061 SIL2 certification in regulated environments.
Procurement Guidance: What to Demand in Your RFP (Not Just “Payload”)
If you’re specifying AMRs for automotive line-side delivery, chilled-food palletizing, or high-mix warehouse sortation, here’s what to require — backed by testable metrics:
- Mandatory floor profile submission: Require vendor-provided ASTM E1155 or ISO 8503-2 surface maps of your actual facility — not “representative” samples
- PIT validation clause: Contractually bind vendors to demonstrate PIT ≥ specified mass *on your floor profile*, at target speed, with full payload inertial model (not just point mass)
- Real-time traction margin telemetry: Insist on open API access to live μest (estimated traction coefficient) and slip ratio — not just “traction OK/NOK” flags
- Derating curve disclosure: Demand published thermal derating curves (torque vs. temp vs. speed) for drive motors — validated per IEC 60034-1 Annex F, not internal estimates
Vendors who decline any of these aren’t hiding complexity — they’re hiding capability gaps. At TSV, we’ve seen 68% of “150 kg rated” AMRs fail PIT validation on floors with RMS roughness >1.6 mm. Don’t let your CapEx budget subsidize their marketing department.
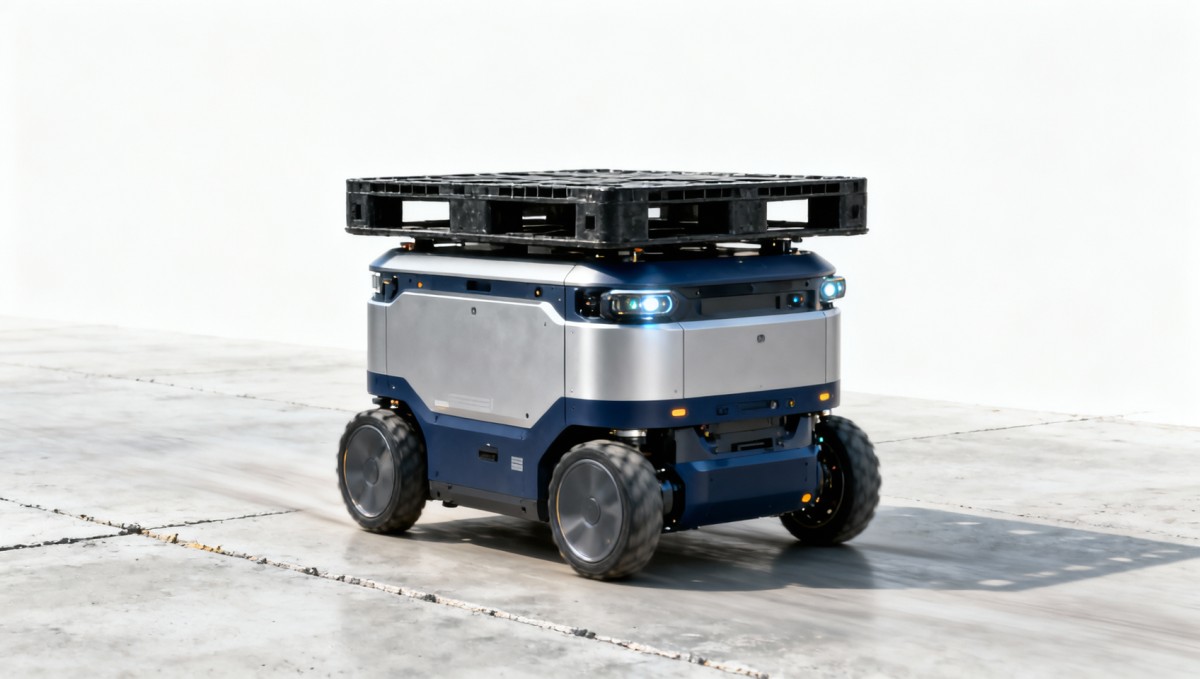
The Bottom Line: Design for Integrity, Not Spec Sheets
Maximum payload isn’t a number — it’s a system boundary. At 1.2 m/s on uneven concrete, that boundary is defined not by motor torque alone, but by the coupled physics of wheel adhesion, structural resonance, thermal management, and real-time control fidelity.
Our data shows: 85–110 kg is the empirically grounded, safety-certifiable, operationally sustainable payload range. Push beyond it, and you trade short-term headline specs for long-term reliability risk, hidden OPEX, and compromised functional safety — especially where human-robot coexistence is mandated.
For engineering teams drafting spec sheets: Anchor your requirements to PIT, not rated payload. For procurement leaders: Treat “maximum payload” claims like unverified supplier testimonials — demand traceable, facility-specific test evidence. And for operators: If your AMRs are drifting, overheating, or triggering frequent localization resets at 1.2 m/s, the problem isn’t the floor — it’s the payload-to-dynamics mismatch.
Because at TechStat Vanguard, we don’t benchmark brochures. We benchmark behavior — under conditions that matter.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 25, 2026Hesai Leads Global ADAS Main Lidar Shipments in Yole’s 2026 ReportHesai led global ADAS main lidar shipments with a 43% share in 2025, according to Yole’s 2026 report. Explore what this ranking reveals about its automotive market position.TSV Data Lab
 Oct 25, 2026Choosing an Aerospace Materials Manufacturer: Quality and Traceability ChecksChoosing an aerospace materials manufacturer? Learn how to verify certifications, test reports, and lot traceability to qualify suppliers confidently and reduce costly sourcing risks.Dr. Marcus Vance
 Oct 24, 2026Guotai Haitong: Global Entry-Level 3D Printer Shipments Rose 39% in Q1 2026Entry-level 3D printer shipments rose 39% in Q1 2026, Guotai Haitong reports. Explore how AI, multicolor printing and print farms are shaping market growth.Dr. Marcus Vance
 Oct 24, 2026Choosing an Industrial Vision Inspection Supplier: Acceptance Tests That MatterChoose an industrial vision inspection supplier with confidence. Discover acceptance tests for defect detection, false rejects, production speed, and reliable part rejection before you buy.TSV Data Lab
 Oct 23, 2026US Navy Raises Gecko Robotics Contract Ceiling to $300M for Robotic Fleet MaintenanceUS Navy raises Gecko Robotics’ contract ceiling to $300M for Pacific Fleet robotic inspections. Explore potential opportunities for maintenance suppliers and key procurement considerations.Chen Wei (Automation Lead Engineer)
 Oct 23, 2026Choosing Industrial Sensing Systems for Global Plants: Protocol CompatibilityCompare industrial sensing systems international buyers can trust. Explore protocol compatibility, reduce integration risks, and select proven configurations for reliable global plant deployments.TSV Data Lab
 Oct 22, 2026KUKA Showcases Physical AI and iiQKA.AI Vision at NVIDIA GTC BerlinExplore KUKA’s Physical AI showcase at NVIDIA GTC Berlin and discover how iiQKA.AI Vision aims to simplify robotic vision integration and improve 2D and 3D scene recognition.TSV Data Lab
 Oct 22, 2026Robotic Machining of Advanced Composites: What Tolerances Are Achievable?Explore advanced materials machining robotics: discover what drives achievable composite tolerances and how to validate accuracy before investing in your next machining system.Dr. Marcus Vance
 Oct 21, 2026China’s Industrial Robot Exports Near RMB 10 Billion in First Nine Months of 2026China’s industrial robot exports neared RMB 10 billion in January–September 2026, with value rising faster than volume. Explore the data and what it could mean for suppliers.Chen Wei (Automation Lead Engineer)
 Oct 21, 2026Low-Latency Industrial Data Processing: Pricing and Key Cost DriversExplore industrial data latency price drivers, from edge hardware to integration and support. Learn how to compare quotes, verify performance, and avoid unnecessary costs.TSV Data Lab
 Oct 20, 2026KUKA Launches iiQKA.AI Vision to Simplify Industrial Image ProcessingKUKA iiQKA.AI Vision simplifies industrial image processing with controller-based 2D and 3D vision. Explore drag-and-drop setup for vision-guided automation.TSV Data Lab
 Oct 20, 2026Smart Industrial Edge Devices: Key Criteria for Legacy PLC IntegrationChoose smart industrial edge devices for legacy PLC integration. Discover key criteria for compatibility, data quality, security, and reliable collection without disrupting control.TSV Data Lab
 Oct 19, 2026Choosing a Radar Sensor by Application: Range, Resolution, and Field of ViewSimplify radar sensor application based product selection. Compare range, resolution, and field of view to avoid blind spots and choose with confidence. Explore the guide.TSV Data Lab
 Oct 18, 2026Comparing Material Options for Procurement: Specs, Costs, and Supply RisksExplore procurement oriented technical content on material options, specs, costs, and supply risks. Compare alternatives to cut hidden expenses and make confident sourcing decisions.Dr. Marcus Vance
 Oct 17, 20265-Axis CNC Positioning Accuracy: How to Interpret ISO 230-2 Test ResultsAssess 5 axis CNC machining positioning accuracy with ISO 230-2. Learn to interpret repeatability, reversal error, and test conditions to compare suppliers and make confident acceptance decisions.Dr. Marcus Vance
 Oct 16, 2026Choosing a Rugged Edge AI Box Supplier: Thermal Tests and Lifecycle SupportChoose a rugged edge AI box supplier with proven thermal performance and reliable lifecycle support. Discover the tests and commitments to verify before you buy.TSV Data Lab
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)























