
Custom Machining for Robotics Joints Starts With Tolerance Stack Up
Publication Date
author
In custom machining for robotics joints, performance begins long before assembly—with tolerance stack up, material behavior, and process control. For teams evaluating collaborative robots and industrial robots, even minor deviations can affect backlash, repeatability, and service life. This article examines how precision-driven machining decisions turn engineering data into reliable joint performance and smarter sourcing.
Why tolerance stack up is the real starting point for robotics joint machining
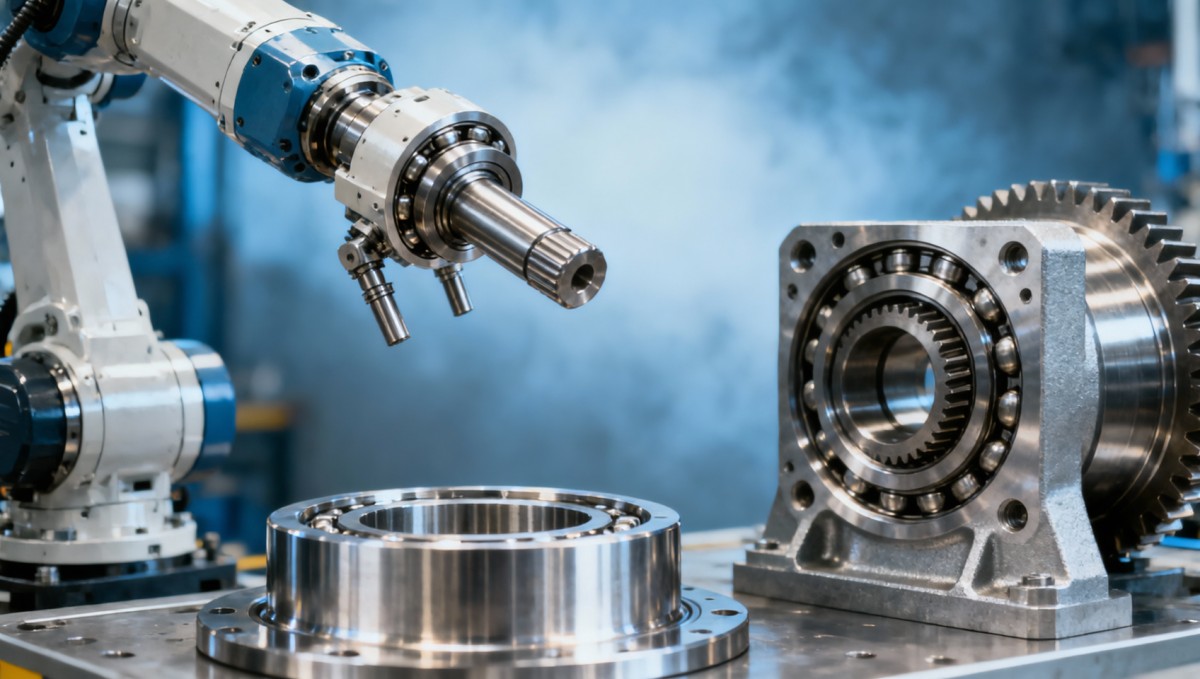
A robotics joint is not defined by one shaft, one bearing seat, or one housing dimension in isolation. Its real behavior comes from the cumulative effect of every machined feature across the assembly chain. That is why tolerance stack up matters from the first drawing review, especially in joints used in cobots, articulated robot arms, rotary modules, and servo-driven end-axis systems.
For information researchers and procurement teams, the risk is clear: a supplier may quote tight tolerances on one critical diameter, yet leave alignment, coaxiality, perpendicularity, or fit relationships underdefined. In practice, a joint can pass incoming inspection on individual parts and still underperform after assembly. Common symptoms include excess backlash, heat rise, vibration, seal wear, and unstable repeatability over 6–12 months of operation.
In robot joint machining, tolerance stack up typically spans 3 layers. The first is part-level tolerance, such as bore size, shaft fit, and flatness. The second is assembly-level relationship, such as concentricity between motor interface and bearing pocket. The third is dynamic operating behavior, where thermal growth, load reversal, and lubrication condition influence the final running state.
TechStat Vanguard approaches this topic from an engineering benchmark perspective rather than a marketing one. Parameters do not lie; the joint either maintains motion accuracy under load cycles, or it does not. For buyers, that means asking not only “What tolerance can you machine?” but also “How does your machining process control the accumulated error across the full joint architecture?”
What stack up usually affects in a robotic joint
- Backlash behavior in gear-driven or harmonic drive interfaces, especially when multiple fit surfaces are machined in separate setups.
- Repeatability drift during continuous duty, where microns of offset can influence end-effector path stability over thousands of cycles.
- Bearing preload consistency, which depends on shoulder position, spacer dimensions, and axial face accuracy.
- Seal life and lubrication retention, often affected by surface finish ranges such as Ra 0.4–1.6 μm on rotating contact surfaces.
Why this matters in sourcing decisions
A low quoted unit price can become expensive if the supplier lacks stack-up discipline. Rework, delayed commissioning, shortened maintenance intervals, and unstable field performance often cost more than the original machining premium. In B2B robotics procurement, the more integrated the joint function, the more important it is to assess machining capability as a system-level competency rather than a piece-part service.
Which machining parameters most directly influence joint accuracy and service life?
Not every dimension in a print has equal influence on robotics joint performance. Engineers, operators, and buyers should separate cosmetic tolerances from function-critical controls. In most custom machining for robotics joints, 5 groups of parameters carry the highest decision weight: dimensional tolerance, geometric tolerance, surface finish, material condition, and process repeatability across batches.
For example, a bearing pocket may require a size tolerance in the micron range, but if coaxiality between two pockets is poorly managed, the assembly can still create uneven load distribution. Likewise, a shaft with acceptable diameter tolerance may still introduce premature wear if roundness, runout, or surface hardness after heat treatment is inconsistent. This is why evaluating only one number from a quotation sheet is not enough.
The table below summarizes common parameter categories that directly affect custom machining for robotics joints. These are not universal values for every design, but they reflect the kind of engineering data that should be reviewed before supplier approval, pilot builds, or volume release.
For operators, these parameters translate into practical outcomes: smoother motion, more stable torque transmission, and fewer corrective interventions. For enterprise decision-makers, they provide a common language to align R&D, quality, and procurement. A supplier who can explain how these parameters interact is usually more valuable than one who only promises “high precision” without process evidence.
Typical process windows worth reviewing
In many robotics joint projects, prototype machining may take 7–15 working days depending on complexity, material availability, and post-processing. Pilot validation can add another 2–4 weeks if heat treatment, grinding, coating, and assembly checks are included. These are ordinary industrial ranges, not guarantees, but they help teams plan around real process timing instead of optimistic quoting language.
Dimensional targets may range from general machining tolerances on noncritical features to much tighter control on bearing fits and mating surfaces. Surface finish windows also vary by function; sealing surfaces, for instance, often need more refined finish than external mounting faces. The key point is to prioritize the parameters that influence motion accuracy and durability, then ask how the supplier validates them at each operation step.
A practical 4-point parameter review
- Identify the 3–5 function-critical dimensions tied to torque transfer, bearing location, or encoder alignment.
- Map which features are machined in one setup and which require reclamping, because setup count often drives stack-up risk.
- Review heat-treatment sequence before final finishing to avoid post-process distortion surprises.
- Require inspection evidence for first article, in-process checkpoints, and final critical characteristics.
How should buyers compare suppliers for custom machining of robotics joints?
Supplier comparison in robotics machining should go beyond machine list and unit price. A 5-axis CNC center, CMM access, or grinding capability is useful, but the real selection question is whether the supplier can control the full tolerance chain from raw material to validated assembly interfaces. Procurement teams often see similar quotations from several vendors, yet the quality risk profile behind those numbers can differ sharply.
A robust procurement review usually covers at least 6 checkpoints: print review capability, process route design, fixture strategy, inspection method, traceability discipline, and change-control response. This matters especially when a robotics joint includes hardened parts, thin-wall sections, precision bores, or multiple datums that interact under assembly load. A vendor that quotes quickly but asks few technical questions may not be reducing risk.
The following comparison table can help sourcing teams separate a basic machining vendor from a partner suitable for custom machining in robotics joints, where tolerance stack up and long-term performance are procurement-critical, not optional extras.
This comparison is especially useful for teams sourcing internationally, where supplier qualification cycles may already extend 3–8 weeks. Better early screening reduces trial-and-error cost. It also aligns with TSV’s data-driven view of the hard-tech supply chain: a good supplier should be able to discuss measured capability, not just sales language.
Procurement questions worth asking before RFQ approval
- Which 3 features in this joint carry the highest stack-up risk, and how will they be machined relative to the main datum?
- How many setups are required, and which features are finished after heat treatment or grinding?
- What inspection plan is used for first article, pilot lot, and serial production release?
- What is the typical lead time range for prototypes, repeat batches, and rework if a dimensional drift is found?
Cost versus risk: what decision-makers should balance
The cheapest option can work for low-load brackets or noncritical covers, but robotics joint machining rarely behaves like a commodity purchase. If the part influences rotational accuracy, bearing alignment, or reducer interface, a modest increase in machining and inspection cost can reduce field failures, maintenance interruptions, and qualification delays. Cost should be evaluated across the entire service window, not only the purchase order line item.
What process controls, standards, and validation steps reduce hidden failure risk?
Custom machining for robotics joints becomes more predictable when process control is built around critical-to-function features. In real manufacturing, hidden failure risk often comes from distortion after heat treatment, unstable fixturing, datum transfer errors, or insufficient verification between roughing and finishing. These are controllable issues, but only if the process route is engineered with the final joint behavior in mind.
For buyers working across advanced manufacturing sectors, it is also useful to look at quality discipline through the lens of recognized systems. While not every robotics machining supplier will operate under the same certification scope, familiarity with structured quality management, inspection records, calibration control, and traceability practices is a strong signal. In higher-criticality sectors, standards such as ISO 9001, AS9100, or ISO 13485 often shape machining documentation expectations even when the end application differs.
A practical validation path usually has 4 stages: drawing clarification, prototype verification, pilot process locking, and production monitoring. Each stage should have explicit exit criteria. For example, prototypes may confirm fit and assembly logic, but pilot builds should verify repeatability across multiple pieces, not just one successful sample. This distinction matters because tolerance stack up often appears only when batch variation enters the picture.
The checklist below reflects a disciplined approach that helps engineers, operators, and procurement managers evaluate whether a machining source can support robotics joint reliability over time rather than only at first assembly.
A 6-item validation checklist for robotics joint machining
- Confirm datum strategy on the drawing and ensure inspection datums match machining datums wherever possible.
- Review material condition, heat-treatment route, and expected distortion control before final machining.
- Request first article inspection on function-critical dimensions and geometric relationships, not only general dimensions.
- Validate surface finish requirements on bearing, seal, and sliding interfaces with the appropriate metrology method.
- Check batch repeatability through pilot samples rather than a single golden part.
- Define nonconformance response time, containment steps, and revision-control procedure before serial release.
Common misconceptions that create avoidable risk
“Tighter tolerance everywhere is always better”
This can increase cost and lead time without improving joint performance. Good engineering allocates tighter tolerance only to features that affect stack up, preload, or motion accuracy. Overconstraining noncritical surfaces can add machining steps and inspection burden while creating little functional value.
“If one prototype assembled correctly, the process is stable”
Not necessarily. One-piece success may hide batch instability. Pilot runs over several pieces and multiple setups are more meaningful for procurement decisions, especially when production is expected to scale from small-lot validation to recurring release.
“Inspection at the end is enough”
End-of-line inspection catches some issues, but in-process verification is often what prevents scrap and schedule loss. For complex robotics joint machining, intermediate control after roughing, heat treatment, or semi-finishing can protect the final quality window.
FAQ: what do engineering teams and buyers ask most about robotics joint machining?
How do I know whether tolerance stack up is a serious issue in my joint design?
It becomes serious when several precision interfaces interact in one motion chain. If your joint includes two or more bearing locations, a reducer interface, a motor mount, encoder alignment, or preload-sensitive spacers, stack up should be reviewed early. A simple rule is to examine every feature that influences rotation center, axial position, or torque transfer and then map how errors accumulate across 3–5 connected dimensions.
What lead time is typical for custom machining for robotics joints?
For many projects, prototypes may run 7–15 working days if material and tooling are available. More complex parts involving heat treatment, grinding, or special inspection can extend to 2–4 weeks. Serial production timing depends on lot size, fixture maturity, and inspection frequency. The important point is to distinguish between quoted machining time and the total engineering cycle needed for validated release.
What should procurement prioritize when comparing quotations?
Prioritize technical clarity over headline price. Review critical tolerance interpretation, setup count, post-treatment finishing sequence, inspection coverage, and traceability. If two quotations are close, the supplier that identifies stack-up risk, documents control points, and explains corrective action usually offers the lower total risk for robotics joint sourcing.
Are aerospace or medical machining standards relevant to robotics parts?
They may be relevant as a benchmark for process discipline rather than as a direct requirement. Practices associated with AS9100 or ISO 13485 environments—such as stricter documentation, traceability, and process control—can be useful reference points when sourcing high-precision robotics joint components. The key is not to assume a label alone guarantees suitability; the underlying execution still needs review.
Why work with a data-driven technical partner when qualifying machining sources?
In hard-tech supply chains, information noise often hides the real engineering differences between suppliers. That is especially true in custom machining for robotics joints, where terms like “precision” or “high quality” mean little without measurable context. TechStat Vanguard was built to cut through that noise by focusing on technical benchmarking, performance logic, and traceable engineering evaluation rather than promotional claims.
For information researchers, TSV helps convert scattered supplier language into structured decision criteria. For users and operators, it clarifies which machining choices actually influence motion smoothness, maintenance burden, and service life. For procurement managers and enterprise leaders, it shortens supplier qualification by organizing what matters most: tolerance range interpretation, process capability signals, validation checkpoints, and sourcing risk visibility.
If your team is reviewing a robotics joint project, the most valuable next step is often not a generic quote request, but a focused technical discussion. That discussion should cover at least 5 areas: critical dimensions, stack-up path, material and heat-treatment sequence, inspection method, and expected delivery window for prototype and pilot stages. Clear inputs lead to better supplier comparisons and fewer late-stage surprises.
You can contact TSV to discuss parameter confirmation, supplier screening logic, machining process evaluation, prototype versus pilot expectations, documentation depth, certification-related concerns, sample support strategy, and quotation communication structure. If you need a more reliable basis for custom machining decisions in robotics joints, start with the data that governs performance—not the adjectives that decorate a sales page.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026How tight can micro machining aerospace tolerances be in production?Micro machining aerospace tolerances can reach low-micron levels in production. Learn what controls repeatability, inspection confidence, and flight-critical quality.Dr. Marcus Vance
 Oct 13, 2026How to keep an industrial robotic integration project on scheduleIndustrial robotic integration project management: keep automation on schedule with proven controls for interfaces, suppliers, FAT, commissioning, and change risk.Victor Lin (Chief Software Architect)























