
Can a Cobot Handle Medical Device Assembly Without Slowing Validation?
Publication Date
author
Can a cobot for medical device assembly accelerate output without derailing validation? For engineers, buyers, and plant leaders evaluating smart factory automation solutions, the real question is not hype but evidence: cycle stability, traceability, risk control, and compliance. This article examines how cobots fit regulated assembly environments, where validation bottlenecks arise, and what data-driven implementation paths protect both throughput and approval timelines.
In regulated production, a collaborative robot is rarely rejected because it cannot move parts accurately enough. It is rejected because the surrounding process cannot prove repeatability, control software revisions, or document changes in a way that supports IQ, OQ, and PQ. For medical device assembly, the core issue is not whether cobots are advanced, but whether the automation architecture can withstand validation scrutiny while delivering stable cycle time improvement.
That distinction matters to multiple stakeholders. Operators care about ergonomic relief, simpler changeovers, and safe human-machine interaction. Procurement teams compare total cost of ownership across 3-year to 7-year horizons. Engineering leaders focus on traceability, downtime risk, and clean integration with MES, vision systems, torque tools, and electronic batch records. Executives want a shorter path from capital approval to qualified output.
From a data-first manufacturing perspective, the right question becomes more precise: under what assembly conditions can a cobot increase throughput by 10% to 30% without extending validation cycles by 8 to 16 weeks? The answer depends on process criticality, software complexity, fixture design, and the discipline of change control.
Where Cobots Fit Best in Medical Device Assembly
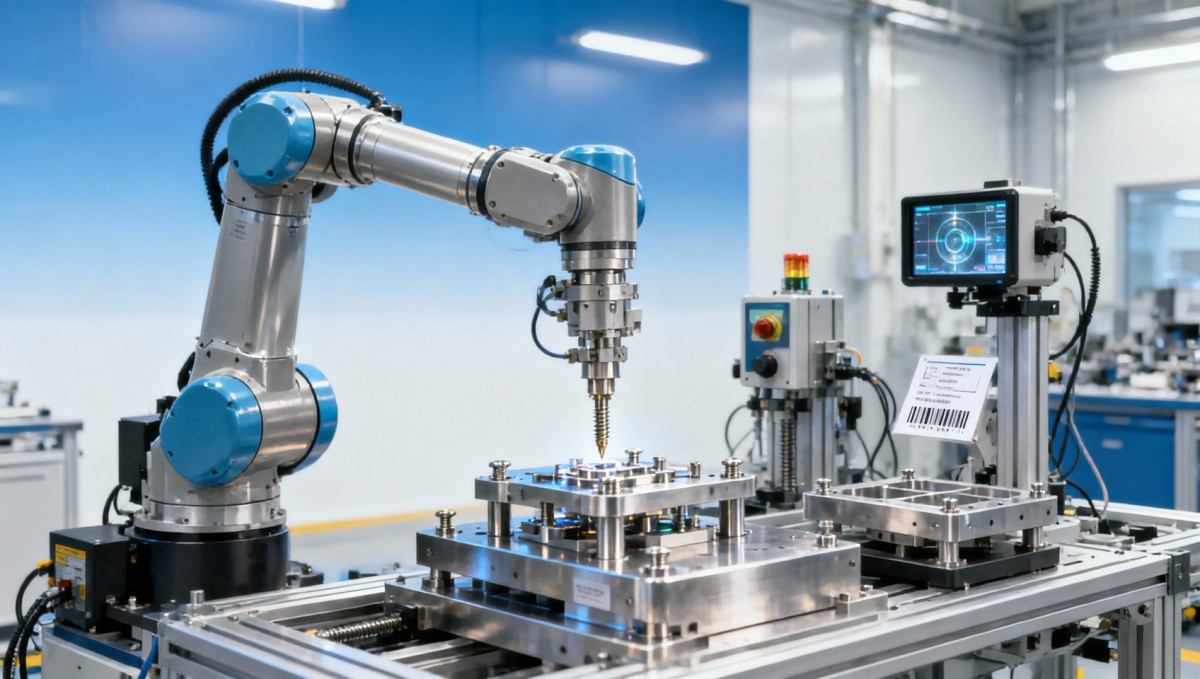
Cobots are most effective in medical device assembly when the task is repetitive, force-limited, and highly structured. Typical fit areas include pick-and-place, tray loading, screwdriving with torque verification, adhesive dispensing with monitored bead paths, label application, light press-fit steps, and inspection handoff to vision stations. These activities often run in cycle windows of 8 to 45 seconds, where small repeatability gains compound across a shift.
They are less ideal when the process depends on complex manual dexterity, irregular soft materials, or frequent undocumented product variation. In those cases, a cobot may still help, but the validation burden increases because the team must qualify not only motion paths but also edge conditions, exception handling, and operator intervention rules. The more branches the process contains, the more test cases must be executed during OQ.
A practical rule is to start with tasks that have 4 traits: stable part presentation, measurable pass/fail criteria, a limited SKU family, and clear error-proofing requirements. If the assembly line already has digital torque tools, barcode traceability, and standardized fixtures, cobot integration usually proceeds faster than in lines where work instructions remain paper-based and station-level data collection is inconsistent.
Best-fit task categories
- Component handling where positional tolerance is commonly within ±0.1 mm to ±0.5 mm and the path is fixed.
- Guided fastening where torque, angle, and completion signals can be logged for every serial number.
- Inspection support where the cobot feeds parts to vision or leak-test equipment at a consistent orientation.
- Packaging-adjacent handling for sterile barrier preparation, provided environmental and contamination controls are fully assessed.
The table below outlines where cobots tend to accelerate implementation and where they can trigger extra validation work. This is especially useful for buyers comparing automation candidates before issuing a URS or supplier RFQ.
The key takeaway is simple: cobots add value fastest when process logic is narrow, acceptance criteria are digital, and exception states are intentionally limited. In medical device assembly, that usually means beginning with one validated station, not a full-line transformation.
Why Validation Slows Automation Projects
Validation delays rarely come from robot hardware alone. They usually emerge from software layering, undocumented interfaces, and late design changes. A cobot cell may include the robot controller, safety PLC, HMI, vision camera, torque driver, barcode scanner, historian, and MES connector. Each added interface can multiply testing paths, alarm states, and cybersecurity review requirements. What looked like a 6-week integration can become a 12-week qualification effort if interfaces are finalized too late.
Another common bottleneck is excessive customization. Teams often request custom dashboards, unique user roles, nonstandard recipes, or special data exports before the first line even reaches FAT. Every custom feature may appear small, but together they expand software verification, document revision control, and operator training matrices. In regulated assembly, simplicity is often faster than sophistication.
Validation-sensitive failure points
The highest-risk points are typically found in five areas: recipe selection, data integrity, safety logic, rework handling, and change control. If a station allows manual overrides without clear logging, the team can struggle to prove traceability during deviation review. If rejected parts can re-enter the flow without unique event history, serial-level accountability breaks down.
What often adds 2 to 6 extra weeks
- Late lock-in of URS and FAT acceptance criteria after programming already started.
- Unclear ownership between machine builder, validation team, IT, and quality engineering.
- Frequent mechanical changes to fixtures, feeders, or guarding after OQ protocols are drafted.
- Missing audit trail expectations for parameter edits, user access, and alarm acknowledgments.
- Insufficient worst-case testing across different operators, shifts, and lot conditions.
For decision-makers, the implication is important: the cobot itself does not slow validation. Poorly controlled system design does. A well-bounded station with documented revision history, fixed user permissions, and clear electronic records can move through IQ, OQ, and PQ on a normal timetable. A loosely scoped “smart” cell can derail the schedule even if the robot performs perfectly.
Teams should also differentiate between process validation and equipment qualification. If the assembly characteristic is critical to product function, the burden may extend beyond machine repeatability into process capability, environmental monitoring, and downstream verification. In such cases, the project plan should reserve enough time for 3 phases: engineering run-off, formal qualification, and post-launch monitoring.
A Data-Driven Implementation Path That Protects Throughput and Compliance
The safest path is phased deployment. Instead of replacing an entire operator station with a high-logic automation cell, manufacturers can begin with one bounded task and define measurable success before scaling. A strong pilot uses baseline data from at least 2 to 4 weeks of manual production, including cycle time spread, first-pass yield, operator touches, ergonomic strain points, and deviation frequency. That baseline becomes the reference for validation and ROI reviews.
A practical implementation model has five stages: feasibility study, user requirements, design freeze, qualification execution, and controlled ramp-up. During feasibility, the team should confirm part presentation stability, contamination controls, and error-proofing needs. During the URS stage, every critical function should map to a testable requirement. If it cannot be tested, it should not remain ambiguous in the design package.
Recommended project structure
- Set a cycle time target such as reducing average station time from 28 seconds to 22 seconds while holding reject rate below the current baseline.
- Limit initial SKU coverage to 1 to 3 variants rather than full-family deployment.
- Freeze software functions before FAT, with a documented change request path for all later edits.
- Define electronic traceability fields early, including serial number, torque result, recipe ID, user action, and alarm history.
The table below shows a structured comparison between low-risk and high-risk cobot implementation styles. It can serve as a planning checklist for engineering, procurement, and quality teams working from the same capital project brief.
The strongest programs also include a short monitored ramp, often 1 to 3 production lots, before full release. This period is useful for confirming alarm frequency, operator recovery steps, and maintenance response time. It provides evidence that the station can sustain output, not just pass scripted tests.
For organizations aligned with TSV’s data-first philosophy, the discipline is straightforward: measure the baseline, reduce uncontrolled complexity, and validate only what has been intentionally designed. Throughput gains follow when repeatability and documentation are engineered together.
How Buyers and Plant Leaders Should Evaluate a Cobot Cell
Procurement decisions in medical device assembly should not focus only on robot payload, reach, or quoted cycle speed. Those specifications matter, but they do not determine whether the line will qualify smoothly. Buyers should score suppliers across at least 4 dimensions: validation readiness, integration transparency, service response, and lifecycle maintainability. A lower machine price can become more expensive if FAT documents, software backups, and spare part strategy are weak.
For operators and production managers, recovery behavior is equally important. A cobot cell that stops safely but requires engineering intervention for every minor exception will erode OEE. Ask how the station handles empty nest detection, failed torque confirmation, barcode read errors, and manual re-entry after stoppage. The desired answer is not “it rarely happens,” but a documented recovery flow that trained staff can execute in under 2 to 5 minutes.
Key procurement questions
- What documents are included for IQ, OQ support, software backup, and alarm matrix review?
- How are parameter changes version-controlled, and who can edit recipes or setpoints?
- What spare parts are recommended for the first 12 months, and what are standard lead times?
- Can the supplier support FAT and SAT with traceability testing across all connected devices?
- What is the expected MTBF range for the station-level subsystem, not only the robot arm?
The table below summarizes a practical evaluation framework for sourcing teams and technical stakeholders. It is intentionally operational rather than promotional, because sourcing errors in regulated manufacturing usually come from incomplete technical due diligence.
When comparing proposals, insist on seeing the station as a validated system, not only as hardware. The robot arm may be the visible component, but the qualification burden lives in the software states, connected tools, and controlled data path. That is where the real sourcing risk sits.
Common Questions from Engineers, Operators, and Decision-Makers
How much throughput gain is realistic without increasing validation risk?
In many bounded assembly tasks, a 10% to 25% throughput improvement is a more credible planning range than aggressive headline claims. The gain usually comes from reduced motion waste, more stable handling, and fewer fatigue-related inconsistencies. If the project requires extensive vision logic, many recipes, or complex human intervention rules, the output gain may still be achievable, but the validation timeline will likely expand unless scope is contained.
How long does a typical cobot implementation take in a regulated environment?
For a well-scoped station, feasibility to SAT often fits within roughly 10 to 18 weeks, followed by qualification and monitored ramp depending on internal quality procedures. The largest schedule swings usually come from document approval cycles, software changes after FAT, and interface delays with plant systems. A narrow pilot usually moves faster than a line-wide rollout by a wide margin.
What are the biggest mistakes companies make?
Three mistakes repeat often. First, automating an unstable process instead of fixing the process first. Second, over-customizing software before proving the core workflow. Third, treating validation as a final checkpoint rather than a design input. When those errors combine, the team spends more time rewriting documents and retesting than producing qualified units.
Are cobots suitable for all medical device manufacturers?
Not universally. They are usually strongest for manufacturers with medium to high repetition, stable fixtures, and a clear need for digital traceability or ergonomic improvement. Very low-volume, high-mix environments may still benefit, but only if changeover control is disciplined and validation planning accounts for recipe complexity. In some cases, semi-automation is a better first step than a fully integrated cobot cell.
A cobot can support medical device assembly without slowing validation, but only when the project is engineered around evidence rather than excitement. The winning formula is a bounded process, early traceability design, limited customization, and strict change control from URS through ramp-up. For engineers, that means fewer unknowns during qualification. For operators, it means clearer recovery and safer repetitive work. For procurement and leadership teams, it means a capital project that can improve output while staying defensible under audit and release review.
If your team is assessing a cobot for medical device assembly and needs a clearer decision framework, now is the time to compare the process data, qualification scope, and supplier documentation model before purchase. Contact us to discuss a tailored evaluation path, review technical selection criteria, or explore a validation-conscious automation roadmap built around measurable manufacturing truth.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026How tight can micro machining aerospace tolerances be in production?Micro machining aerospace tolerances can reach low-micron levels in production. Learn what controls repeatability, inspection confidence, and flight-critical quality.Dr. Marcus Vance























