
A Cobot Palletizing Layout Fails Faster Than Most Teams Expect
Publication Date
author
A cobot palletizing layout often fails earlier than teams expect—not because the robot itself is incapable, but because the surrounding system was never engineered as a system. In real projects, underperformance usually starts before commissioning: carton flow is unbalanced, safety zones reduce usable cycle time, gripper assumptions do not match SKU variation, and upstream/downstream data is disconnected from ERP or WMS logic. For buyers, operators, procurement teams, and manufacturing leaders, the key lesson is simple: a collaborative robot palletizing cell is only as reliable as its layout logic, safety design, and integration architecture. If those foundations are weak, throughput losses, nuisance stops, and ROI erosion appear fast.
Why does a cobot palletizing layout fail so quickly in practice?
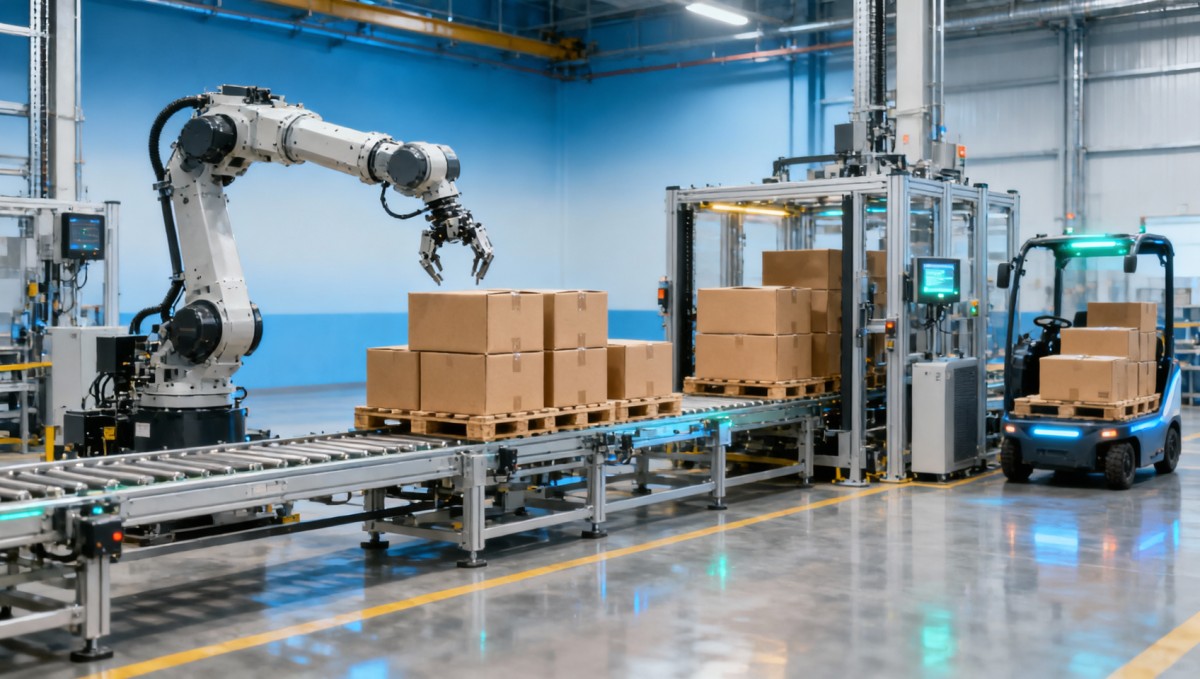
The most common misconception is that palletizing is a “simple end-of-line task.” On paper, the cell may look straightforward: product infeed, cobot, gripper, pallet station, safety scanner, and maybe an AGV pickup point. In operation, however, palletizing cells sit at the convergence of motion control, material flow, human access, packaging variability, and plant data systems.
That is why failure often happens faster than expected. Not always as a catastrophic shutdown, but as a gradual loss of performance:
- Cycle time misses begin during mixed-SKU or unstable infeed conditions.
- Operator interventions rise because cases arrive skewed, damaged, or inconsistently spaced.
- Safety slowdowns reduce real throughput below quoted vendor numbers.
- Servo drive response time and motion tuning prove inadequate for the actual pick-and-place pattern.
- AGV integration with ERP WMS creates pallet release delays, causing the robot to wait for downstream availability.
- Pallet pattern logic is too rigid to handle packaging changes without engineering support.
In other words, most teams do not buy a bad cobot. They deploy a layout that looked acceptable in concept but was not validated against production reality.
What are the earliest warning signs before launch?
Many project teams wait for FAT or SAT to discover system weakness, but layout failure usually leaves clues much earlier. These signs matter to all four target reader groups—researchers, operators, procurement specialists, and executives—because they indicate whether the investment is fundamentally sound.
1. Throughput estimates are based on robot speed, not line reality.
If the proposal highlights maximum cobot reach, payload, or picks per minute but does not model conveyor accumulation, product presentation, pallet exchange time, and operator access interruptions, the estimate is incomplete.
2. Safety is treated as a compliance item, not a cycle-time variable.
The cobot iso/ts 15066 safety standard is essential, but compliance alone does not guarantee productivity. A collaborative application may still require scanners, reduced speed zones, restricted access logic, or separation from manual touchpoints. If safety planning happens after the layout is frozen, speed losses arrive late and expensively.
3. Product variability is underestimated.
Case dimensions, center of gravity, surface friction, packaging compression strength, and label position all affect grip stability and stacking quality. A cell designed around ideal cartons can deteriorate quickly when real packaging variation appears.
4. Data interfaces are undefined.
If the project team cannot clearly explain how order data, SKU recipe selection, pallet IDs, warehouse release signals, and exception states move between PLC, robot controller, MES, ERP, and WMS, then the layout is not operationally ready.
5. Manual recovery scenarios are vague.
Operators will eventually face jams, dropped cases, pallet skew, sensor faults, and missing pallet conditions. If reset and recovery logic is unclear, downtime will be high even when the robot is technically healthy.
Which design mistakes destroy performance the fastest?
Some design errors have an outsized effect on uptime and return on investment. These are the areas that deserve the most attention during concept review and supplier evaluation.
1. Poor line balance between infeed and palletizing cell
A palletizing cell fails when upstream case supply is inconsistent or downstream pallet evacuation is slower than robot output. This mismatch creates starvation and blocking. Teams sometimes focus heavily on cobot selection while ignoring conveyor buffering, lane merging, accumulation length, and pallet handoff timing.
What matters is not nominal robot cycle time alone, but system cycle time under variation. A layout should be reviewed for:
- Peak and average carton arrival rates
- Buffer capacity during upstream surges
- Pallet changeover time
- Mixed-SKU sequencing rules
- Downtime impact when one subsystem pauses
2. Incorrect assumptions about collaborative operation
Many teams choose a cobot because they expect easier deployment, smaller footprint, and safer human interaction. Those advantages are real, but they are often oversimplified. In palletizing, reach, stack height, payload at extension, and safe speed under human proximity can become limiting factors. If the line requires high throughput, a collaborative robot may only succeed if the layout minimizes unnecessary travel and human entry frequency.
The key question is not “Can a cobot do palletizing?” It is “Can this cobot, in this layout, under this safety concept, meet sustained throughput?”
3. Underestimating servo drive response time and motion settling
Quoted cycle performance can degrade if servo response, acceleration profiles, or end-of-arm-tool dynamics are not matched to real carton handling. Fast moves that look fine in simulation can create oscillation, mis-picks, or unstable placement when carton stiffness and gripper compliance vary.
For engineering teams, this is where data matters more than marketing language. Ask for:
- Loaded versus unloaded motion profiles
- Placement accuracy at maximum stack height
- Repeatability under continuous operation, not just isolated test cycles
- Servo tuning assumptions for your actual packaging type
- Recovery behavior after emergency stop or interrupted motion
4. Weak AGV integration with ERP WMS logic
A modern palletizing cell often depends on automated pallet transport. This creates a software and logistics dependency that many teams underestimate. If AGV dispatching, pallet destination confirmation, finished pallet call logic, and inventory system synchronization are delayed or inconsistent, the cobot waits idle.
This is one of the clearest examples of a layout failing because of architecture, not hardware. The robot may perform perfectly, yet total equipment effectiveness remains poor because pallet removal or empty pallet delivery is not synchronized with production demand.
5. Layouts that make operators the hidden bottleneck
Even highly automated cells can become labor-dependent if manual pallet loading, slip-sheet insertion, label verification, rework handling, or jam recovery is awkward. A bad layout forces unnecessary walking, awkward reaches, delayed reset actions, and safety zone intrusions that repeatedly slow the robot.
If operators must frequently enter the collaborative workspace, the productivity advantage of automation drops quickly.
How should buyers and decision-makers evaluate a cobot palletizing proposal?
For procurement teams and executives, the right evaluation framework is not just capex comparison. A lower initial price can hide substantial operational cost if the layout is fragile. A stronger purchasing decision comes from asking harder technical and operational questions.
Focus on these evaluation dimensions
- Real throughput: What is the sustained cases-per-minute rate under expected SKU mix, shift duration, and operator interaction?
- Safety-performance tradeoff: How does the cobot iso/ts 15066 safety standard implementation affect speed, access, and fault recovery?
- Integration maturity: Is there a documented interface map covering robot controller, PLC, scanner, AGV, ERP, and WMS?
- Changeover flexibility: How easily can new pallet patterns, carton sizes, or pallet types be introduced?
- Maintenance burden: What components create the most downtime risk—gripper wear parts, sensors, conveyors, servo drives, software dependencies?
- Scalability: Can the layout support future line speed increases, more SKUs, or additional pallet destinations?
Decision-makers should also distinguish between a good demo and a robust deployment. A polished proof-of-concept may show ideal picks under controlled conditions, but a production-ready solution must demonstrate resilience under packaging variation, shift turnover, network interruptions, and logistics delays.
What do operators and plant teams need for reliable day-to-day use?
For operators and line users, a successful cell is not defined by brochure specifications. It is defined by whether the system is predictable, recoverable, and easy to run during a normal shift.
The most useful design and handover priorities are:
- Clear HMI logic: Operators should immediately understand alarm states, pallet status, recipe selection, and restart conditions.
- Simple recovery procedures: Jam clearing, dropped-box handling, and pallet reset steps should be standardized and safe.
- Stable product presentation: Conveyor guides, spacing controls, and sensing should present cartons consistently to the gripper.
- Accessible maintenance points: Sensors, vacuum lines, wear parts, and gripper components should be easy to inspect and replace.
- Training tied to exceptions: Most downtime comes from edge cases, not normal operation. Training should prioritize abnormal conditions.
When teams skip these basics, operators become forced compensators for weak engineering. That is usually the moment confidence in the project starts to collapse.
How to design a cobot palletizing layout that scales instead of stalling
The best layouts are built backward from production reality rather than forward from robot capability. That means validating constraints before finalizing the cell.
A practical design sequence
- Map the full material flow. Include infeed variability, accumulation logic, pallet exchange, AGV timing, and warehouse handoff.
- Define the true throughput target. Use sustained shift-level output, not isolated peak speed.
- Model safety with operations, not separately. Consider access frequency, scanner zones, manual interventions, and safe-speed effects early.
- Test packaging reality. Validate grip and stack performance on real cartons, including damaged and tolerance-edge samples.
- Audit data architecture. Clarify all signals, IDs, fault states, recipe sources, and system ownership across controls and enterprise software.
- Design for recovery. The faster the cell can be safely reset after a disturbance, the better its real productivity.
- Plan for future SKUs and logistics changes. A rigid layout may pass launch, then fail six months later when the business changes.
For advanced manufacturing organizations, this is where a data-driven mindset creates value. The most effective teams benchmark assumptions using measurable variables: actual case distribution, actual servo response under load, actual stop frequency, actual AGV latency, and actual operator intervention rates. That is far more useful than relying on generalized automation claims.
Final judgment: when is a cobot palletizing layout actually a good fit?
A cobot palletizing layout is a strong fit when throughput requirements are realistic, SKU variation is understood, safety is designed into the process early, and software integration is treated as part of the machine—not an afterthought. It is a weak fit when teams expect the robot alone to solve unstable line conditions, unclear warehouse logic, or poor packaging control.
The central takeaway is this: most palletizing failures are not sudden technical surprises. They are predictable system-design failures that reveal themselves quickly once real production starts. If your team evaluates line balance, cobot iso/ts 15066 safety standard implications, servo drive response time, and agv integration with erp wms before procurement is locked, you dramatically reduce commissioning risk and improve long-term ROI.
In end-of-line automation, layout quality decides success faster than most teams expect. The companies that get it right do not buy the most exciting pitch. They buy the most coherent system.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 16, 2026Choosing a Rugged Edge AI Box Supplier: Thermal Tests and Lifecycle SupportChoose a rugged edge AI box supplier with proven thermal performance and reliable lifecycle support. Discover the tests and commitments to verify before you buy.TSV Data Lab
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)
 Oct 15, 2026How Should You Compare TechStat Vanguard 5-Axis CNC Tolerances?TechStat Vanguard 5-axis CNC tolerance comparison: learn how to verify part accuracy, assess inspection evidence, and choose suppliers that reliably meet your drawing requirements.Dr. Marcus Vance
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab























