When does an AGV traffic control algorithm fail
Publication Date
author
An AGV traffic control algorithm does not fail only when vehicles stop moving—it fails when routing logic can no longer maintain safe, predictable, and efficient flow under real operating pressure. For operators, understanding when an agv traffic control algorithm breaks down is essential to preventing congestion, deadlocks, unexpected delays, and safety risks in automated facilities.
In modern factories, warehouses, aerospace assembly zones, and mixed-material transport environments, flow reliability matters as much as hardware reliability. A weak agv traffic control algorithm can erase the value of accurate sensors, stable drives, and well-designed layouts. Failure often appears gradually through rising queue time, route oscillation, mission conflicts, and unstable recovery behavior.
For data-driven engineering teams, the key issue is not whether control logic works during demos. The real issue is whether it keeps performing during peak demand, map changes, battery constraints, and unexpected path blockage. That is the point where algorithm quality becomes measurable.
Operational Definition of AGV Traffic Control Algorithm Failure
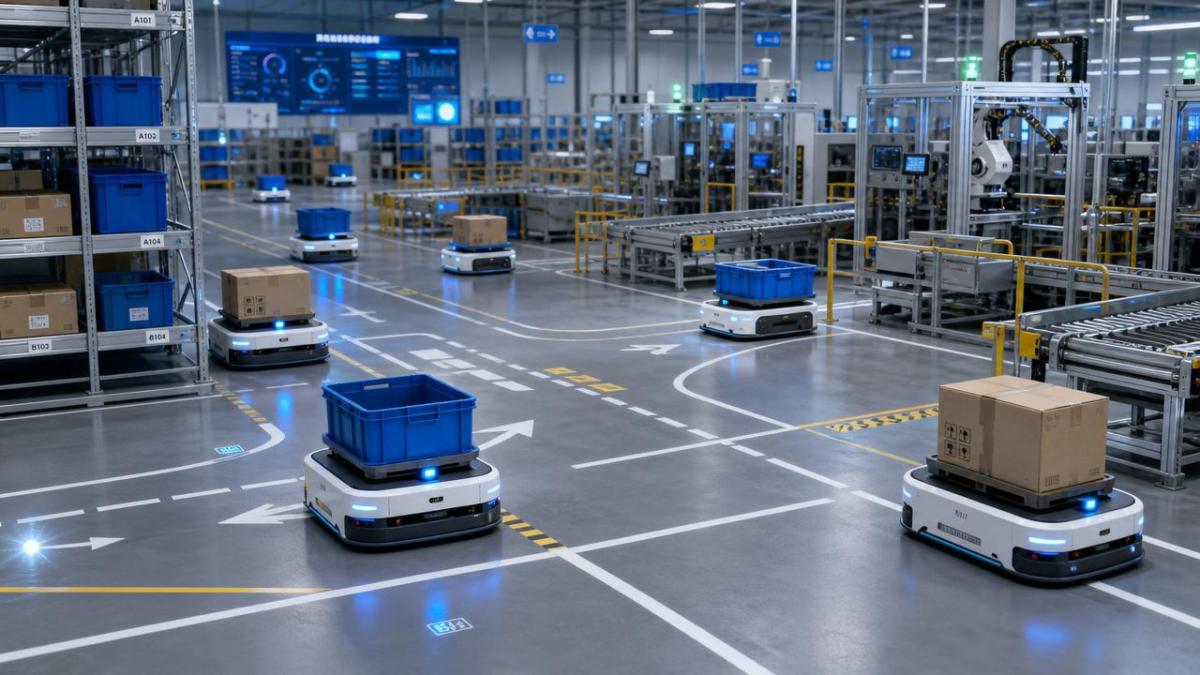
An agv traffic control algorithm is the rule set that allocates routes, resolves conflicts, manages right-of-way, and restores flow after disruption. It may be centralized, distributed, or hybrid. Failure means those rules stop meeting system objectives under actual load.
The most useful engineering definition includes three dimensions: safety, stability, and throughput. If one dimension collapses, the algorithm has already failed, even if vehicles still complete tasks.
- Safety failure: conflict resolution becomes unreliable or near-collision frequency rises.
- Stability failure: small disturbances create disproportionate queue growth or route oscillation.
- Efficiency failure: mission completion time exceeds acceptable limits despite available physical capacity.
This framing is important because many facilities judge success only by uptime. A system may remain online while the agv traffic control algorithm silently degrades planning quality, energy use, and scheduling reliability.
Industry Conditions That Expose Failure Earlier
Across the broader industrial sector, AGV and AMR fleets now operate in denser and more variable settings. Production lines reconfigure faster. Warehouse slotting changes more often. Multi-vendor automation stacks introduce timing mismatch. These conditions expose weaknesses that static route logic cannot absorb.
Several industry signals usually appear before an agv traffic control algorithm visibly breaks.
These signals matter in general manufacturing because material flow now supports shorter lot sizes, traceable part movement, and tighter takt discipline. Traffic control is no longer a background feature. It directly affects delivery confidence and line continuity.
Core Failure Modes in an AGV Traffic Control Algorithm
Most agv traffic control algorithm failures fall into a few recurring patterns. Each one can be measured with route logs, reservation states, and mission history.
Deadlock and Circular Waiting
Deadlock occurs when vehicles hold route segments while waiting for one another. Circular waiting appears in loops, narrow aisles, and shared transfer nodes. If the algorithm does not detect unsafe reservation dependency, the system freezes despite healthy hardware.
Starvation Under Priority Rules
Some fleets prioritize urgent missions or loaded vehicles. That can improve local performance while starving low-priority jobs. A failing agv traffic control algorithm often shows excellent average numbers but poor tail performance on delayed tasks.
Route Oscillation and Replanning Instability
When congestion appears, the system may keep rerouting vehicles between similar paths. Excessive replanning increases uncertainty and travel distance. If routes change faster than the environment changes, control logic is amplifying noise instead of solving it.
Poor Scalability Beyond Test Fleet Size
An agv traffic control algorithm may perform well with ten vehicles and fail with thirty. Computation time, communication overhead, and reservation conflicts rise nonlinearly. This is one of the most common deployment gaps between pilot and full operation.
Mismatch Between Traffic Logic and Physical Reality
Algorithms can fail when digital assumptions ignore acceleration limits, stopping distance, sensor delay, or floor conditions. In practice, path feasibility is not enough. The timing model must match actual vehicle behavior within safe margins.
Why Failure Matters to Business Performance
The value of an agv traffic control algorithm is not abstract. It affects measurable plant outcomes. Throughput, labor intervention, energy consumption, and WIP movement all depend on traffic quality.
- Higher mission latency can starve machines or overfill buffers.
- Frequent manual resets reduce automation confidence.
- Unstable routing increases battery use and charging congestion.
- Safety margin erosion raises compliance and incident exposure.
For a data-centered organization, these effects should be tied to benchmark indicators. Typical indicators include intersection dwell time, route completion variance, blocked-node frequency, mission aging, and recovery time after obstruction. If those metrics trend upward together, the agv traffic control algorithm is nearing its operating boundary.
Typical Scenarios Where the Algorithm Breaks First
Not every layout stresses control logic in the same way. Certain operating scenarios reveal weakness much earlier than others.
These scenarios are common across comprehensive industrial operations, not only e-commerce warehouses. Aerospace tooling transfer, electronics staging, and heavy component movement all create similar stress patterns.
Practical Evaluation Methods Before Full Failure Appears
The best way to manage an agv traffic control algorithm is to detect decline before stoppage. That requires structured testing under realistic disturbances.
- Run peak-load simulation with dynamic task injection, not fixed route replay.
- Measure 95th percentile travel time, not only average travel time.
- Introduce temporary blockages and record recovery path quality.
- Test mixed battery states to expose charging-related congestion.
- Compare reservation plan against actual motion timestamps.
A robust agv traffic control algorithm should degrade gracefully. Throughput may drop under stress, but collapse should not be abrupt. Graceful degradation is often the clearest sign of mature control logic.
Implementation Notes and Risk Controls
Several engineering practices reduce the risk of algorithm failure in live operations.
- Separate mission priority from intersection priority where possible.
- Limit uncontrolled replanning frequency with hysteresis thresholds.
- Reserve escape nodes for deadlock recovery in constrained layouts.
- Use digital twins calibrated by real telemetry, not ideal motion models.
- Track long-tail delay events because averages hide real failure onset.
It is also useful to audit whether the agv traffic control algorithm depends too heavily on perfect communication. Short data delay, packet loss, or localization jitter should not immediately destabilize traffic decisions.
Next-Step Framework for Engineering Review
A practical review should begin with route conflict logs, congestion heat maps, and mission completion distribution. Then compare the algorithm’s assumptions with measured fleet behavior. The question is simple: under what exact operating threshold does the agv traffic control algorithm stop producing safe and efficient flow?
For organizations building evidence-based automation standards, this threshold should be documented like any other engineering parameter. Deadlock frequency, recoverability, queue saturation point, and timing variance should become benchmark values, not anecdotal observations.
That approach aligns with TSV’s data-first view of automation performance. Marketing language cannot explain traffic resilience. Measured failure boundaries can. If the agv traffic control algorithm is central to material flow, then its limits must be tested, quantified, and reviewed before they become operational losses.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 10, 2026When does the cost of industrial robots pay back in high-volume production?Cost of industrial robots: discover how high-volume manufacturers calculate payback through uptime, cycle time, labor, quality, and integration before investing.Chen Wei (Automation Lead Engineer)
 Oct 09, 2026What does a manufacturing robot really cost beyond the purchase price?Manufacturing robot cost goes far beyond the purchase price. Explore integration, tooling, safety, uptime, and total ownership factors for smarter automation investments.Chen Wei (Automation Lead Engineer)
 Oct 08, 2026AGV vs. AMR: Which Is Better for Frequently Changing Routes?Which is better for changing routes? Compare AGVs and AMRs for flexible navigation, docking precision, traffic control, and faster facility reconfiguration.Chen Wei (Automation Lead Engineer)
 Oct 07, 2026How Much Does an Automated Guided Vehicle Cost in 2026?How much does an automated guided vehicle cost in 2026? Explore AGV price ranges, hidden deployment costs, and smart buying factors for stronger ROI.Chen Wei (Automation Lead Engineer)
 Oct 06, 2026Are Collaborative Robots Safe Enough to Operate Without Fencing?Are collaborative robots safe enough to work without fencing? Explore risk assessment, safeguarding options, and practical guidance for safer, productive cobot cells.Chen Wei (Automation Lead Engineer)