
Warehouse AMR Projects Stall When Traffic Rules Come Too Late
Publication Date
author
Warehouse AMR projects rarely fail on hardware alone. They stall when traffic logic, right-of-way, and exception handling are defined after deployment—especially in amr for warehouse logistics programs tied to agv integration with erp wms and broader smart factory automation solutions. For researchers, operators, buyers, and executives, the real question is not just speed or payload, but whether rules, data, and floor behavior align before scale turns friction into costly downtime.
In most facilities, the first 2 to 5 robots look promising. Travel time is short, aisle conflicts seem manageable, and dashboards suggest steady throughput. The real stress starts when fleets scale to 20, 50, or 100+ mobile units sharing crossings, pick faces, charging points, manual forklifts, and pedestrian traffic. At that point, missing traffic governance becomes a systems problem, not a vehicle problem.
For B2B buyers and technical teams, this changes how AMR evaluation should be done. Navigation accuracy, payload, and battery life still matter, but they are only part of the deployment equation. Rule engines, queue priorities, ERP/WMS data timing, exception recovery, and floor-level operating discipline often determine whether automation scales or stalls.
From the TechStat Vanguard perspective, the most reliable warehouse automation decisions come from engineering truth rather than marketing claims. Parameters such as intersection latency, stop frequency per hour, reroute success rate, and mission recovery time are more decision-useful than broad labels like “intelligent,” “flexible,” or “industry-leading.”
Why warehouse AMR projects slow down after pilot success
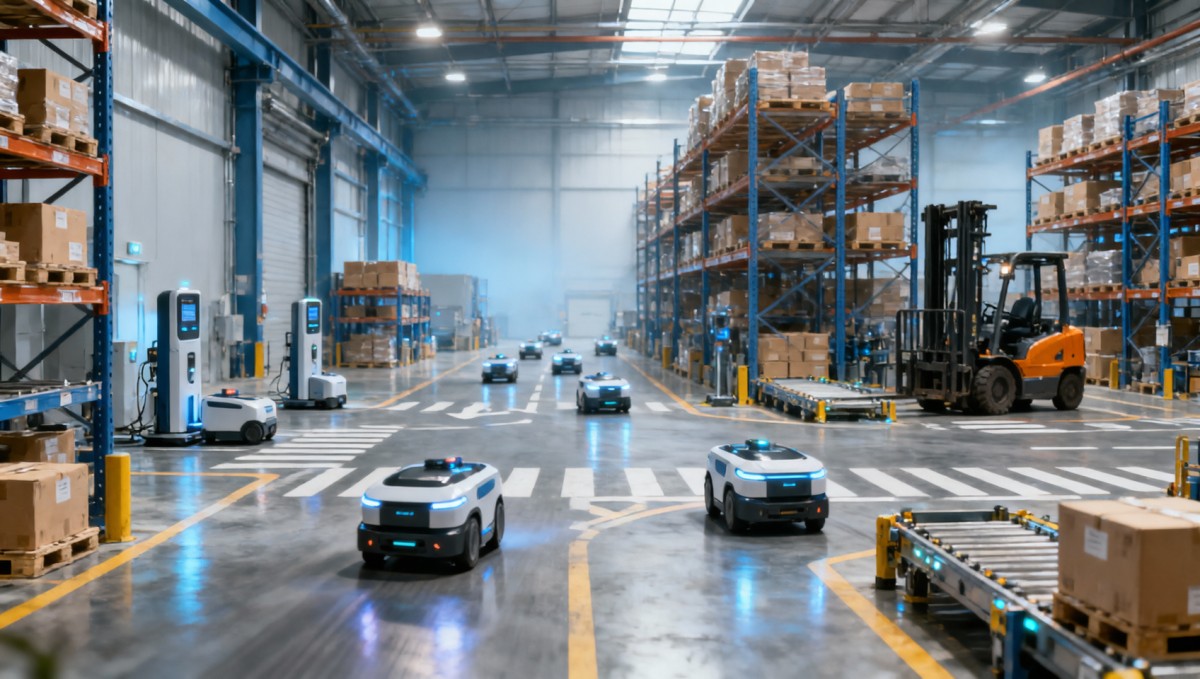
A pilot often runs in a simplified operating window: one shift, limited SKU complexity, low human traffic, and controlled routes. Under those conditions, an AMR for warehouse logistics can achieve acceptable mission completion rates. But when deployment expands across 2 or 3 shifts, mixed order profiles, replenishment peaks, and dock congestion, hidden traffic assumptions begin to break.
The most common issue is that traffic rules are treated as software settings rather than operating policy. If right-of-way is unclear at a 4-way crossing, robots may hesitate for 3 to 12 seconds each event. Multiply that by 80 crossings per hour across a fleet, and the site loses meaningful productive time without any single “failure” appearing severe enough to trigger root-cause action.
Another problem is late-stage integration. When AGV integration with ERP WMS is incomplete, mission priority can be outdated by 5 to 30 seconds. In high-velocity fulfillment, that lag is enough to send mobile robots toward a lane that has already been blocked by manual replenishment or pallet transfer. The result is not just delay; it is cascading re-queue behavior.
Operators also experience a gap between digital logic and floor reality. A route that looks efficient in simulation may intersect with battery swap zones, temporary staging pallets, or shift-change pedestrian spikes. In practice, warehouse AMR traffic must be designed around actual floor behaviors measured over days or weeks, not idealized maps captured once during commissioning.
The difference between navigation and traffic governance
Navigation answers, “Can a robot reach the destination?” Traffic governance answers, “How should 30 robots, 12 operators, 4 forklifts, and 2 urgent replenishment tasks share the same space without throughput collapse?” Sites that confuse these two layers often buy capable robots but underinvest in rules, orchestration, and exception design.
- Navigation concerns localization, path planning, obstacle detection, and docking repeatability, often in the range of ±10 mm to ±50 mm depending on application.
- Traffic governance concerns priority logic, no-go windows, lane reservation, congestion release, and safe fallback when a route becomes unavailable for 30 seconds or more.
- System performance depends on both layers. A robot can localize perfectly and still create severe queueing if mission priorities and crossing rules are weak.
Early warning signals that a pilot will not scale cleanly
Teams should watch for small but repeated signs: more than 5% of missions requiring manual intervention, charging congestion during peak hour, recurring deadlock zones, or travel time variance exceeding 20% for the same route. These are typically traffic-rule symptoms rather than proof of poor hardware quality.
The table below highlights where many warehouse automation projects underestimate operational complexity during expansion.
The core takeaway is simple: warehouse AMR success is rarely determined at the robot spec sheet alone. It is determined by whether fleet logic, facility constraints, and enterprise data flows are engineered together before volume rises.
The traffic rules that should be defined before go-live
A robust AMR deployment requires explicit operating rules, not informal habits. At minimum, teams should define crossing priority, overtaking rules, charger access priority, pedestrian yielding behavior, blocked-lane timeout thresholds, and manual override authority. If these are postponed until after launch, every exception becomes a live production experiment.
In many smart factory automation solutions, the highest-risk areas are not long travel corridors but shared micro-zones. These include inbound staging, pick module entrances, packing merge points, and charging clusters. Even a 10-meter area can create 25% of all fleet delays if multiple task types converge there with no reservation logic.
Right-of-way should also be role-based, not just route-based. For example, a robot carrying line-side replenishment to a production-critical zone may need higher priority than a robot returning empty totes. Without mission tiering, the system treats unequal tasks as equal, which can produce elegant software behavior but poor business outcomes.
Exception handling must be time-bound. If a path obstruction lasts 15 seconds, the vehicle may wait. If it lasts 60 seconds, the fleet manager may reroute. If it lasts 3 minutes, a supervisor alert and task reassignment may be required. Defining these thresholds early helps avoid operator confusion and inconsistent interventions.
Five rule categories that reduce downtime
- Intersection logic: define who stops, who proceeds, and how long a robot can occupy a crossing before forced release.
- Lane ownership: mark one-way, two-way, and temporary no-entry lanes, especially where aisle width is below 2.5 meters.
- Mission priority: rank urgent, standard, empty-return, and charging tasks using 3 to 5 service levels.
- Human interaction: specify warning distance, reduced-speed zones, and manual handoff points around workstations.
- Recovery behavior: define actions for lost localization, blocked docks, failed pickup, and communications interruption.
Practical thresholds worth validating during FAT or SAT
Buyers should request measurable acceptance criteria. Typical examples include intersection dwell time under 8 seconds at nominal load, successful reroute execution within 10 seconds for common obstructions, docking repeatability suitable to the transfer interface, and mission recovery without operator intervention for at least a defined set of routine exceptions.
The following table provides a practical structure for pre-go-live traffic rule validation in warehouse AMR programs.
These checks do not make the project slower; they make scaling more predictable. In procurement terms, they also create a much clearer basis for comparing suppliers beyond headline speed and payload claims.
Why ERP, WMS, and fleet orchestration determine real throughput
A warehouse AMR fleet does not operate in isolation. It acts on job creation, inventory status, pick confirmations, replenishment triggers, and priority updates coming from WMS, ERP, MES, or local execution layers. If those data streams are delayed, duplicated, or missing context, robots can be perfectly available yet still perform the wrong work at the wrong time.
This is why AGV integration with ERP WMS should be treated as a throughput design task rather than an IT afterthought. If order release batches every 10 minutes but floor replenishment needs responses within 2 to 3 minutes, the automation layer is already starting from stale demand. That mismatch often shows up as congestion, idle return trips, or urgent manual interventions.
Data granularity matters as well. A simple transport order may not be enough for dynamic decision-making. The fleet manager may also need source readiness, dock availability, queue status, and task criticality. Without that context, an AMR system can optimize path length while harming labor synchronization or production continuity.
For enterprise decision-makers, the practical question is not whether a vendor “supports integration,” but how the system behaves under imperfect data. Can it reject contradictory orders, retry safely, fall back to a staging rule, or flag a supervisor within 30 to 90 seconds? Mature automation programs ask these questions early.
Data points that should flow into fleet logic
- Task priority codes tied to business urgency, such as line-stop prevention versus routine empty container return.
- Destination readiness status, including whether a dock, station, or transfer point can accept delivery in the next 30 to 120 seconds.
- Inventory or tote state, so the robot is not dispatched to collect a load that has not been released or confirmed.
- Exception tags, such as blocked aisle, station maintenance, or temporary safety restriction.
Integration questions procurement teams should ask
Buyers should request workflow maps, not just interface lists. Ask whether the system supports event-driven updates, queue-level visibility, audit logs for task changes, and defined fallback logic during network interruptions. Also ask what happens when WMS status and floor sensor status disagree. That scenario is common in live facilities and reveals the maturity of the orchestration approach.
A useful procurement comparison is shown below.
The better the orchestration layer, the less likely the operation will blame the robots for failures caused by stale tasks, poor sequencing, or weak exception policy. That distinction is essential in any data-driven review of smart factory automation solutions.
Selection criteria for buyers, operators, and executives
A sound supplier evaluation framework should balance vehicle capability, software governance, integration depth, and service readiness. In practice, many projects overweight travel speed and payload but underweight traffic diagnostics, commissioning method, and post-go-live optimization support. That imbalance often raises lifecycle cost even when initial capital pricing looks attractive.
For operators, ease of exception recovery matters. A system that needs 8 to 10 clicks for a simple task restart will create avoidable friction on the floor. For procurement teams, spare parts lead times, software support windows, and role-based training quality can be just as material as the robot spec. For executives, the key metrics are throughput stability, labor coordination, and scalability across multiple zones or sites.
It also helps to distinguish between a warehouse that needs localized transport automation and one pursuing broader digital factory alignment. If the long-term plan includes line-side delivery, edge data collection, machine state feedback, or cross-site operational benchmarking, the AMR platform should fit that architecture from the start.
From a risk perspective, the cheapest proposal is often the one that transfers engineering work back to the buyer. If route policy, traffic logic, and exception matrices must be defined mostly by the customer after purchase, the “low-price” package can become costly in commissioning delays and internal coordination hours.
A practical 6-point evaluation checklist
- Fleet behavior under congestion: ask for evidence from dense traffic scenarios, not only open-lane demos.
- Integration scope: confirm how ERP, WMS, PLC, MES, and local sensors exchange status and priority data.
- Exception matrix: review at least 10 to 15 common failure modes and corresponding response logic.
- Acceptance metrics: define dwell time, reroute time, mission completion rate, and manual intervention thresholds.
- Service model: clarify remote support window, on-site response time, and software update governance.
- Scalability path: confirm whether the same control logic can expand from one zone to multiple workflows without redesign.
Who should be involved before purchase approval
Successful approval cycles usually involve 4 groups early: operations, automation engineering, IT or application integration, and finance or procurement. In many stalled projects, one of these groups joins too late. The result is a technically valid pilot that lacks budget clarity, data readiness, or floor-level process ownership for scale-up.
The most resilient buying decisions are those built on measurable operating assumptions: route density, average missions per hour, peak task overlap, recharge windows, and acceptable recovery time. Once those numbers are defined, supplier claims become easier to test and compare.
Implementation roadmap: from rule design to stable multi-robot operations
A disciplined rollout should begin before hardware arrives. The first step is traffic mapping, where teams identify crossings, merge points, manual traffic zones, charger locations, and constrained aisles. The second step is rule modeling, where priority logic and exception thresholds are assigned to those locations. Only after these foundations are defined should workflow integration and acceptance testing be finalized.
For most sites, a phased deployment over 6 to 12 weeks is more reliable than a one-step launch. Week 1 to 2 may focus on map validation and route segmentation. Week 3 to 5 may test mission creation, charging policy, and obstruction logic. Week 6 onward may introduce denser traffic, more task classes, and mixed-shift operation. This sequence reduces the risk of discovering rule conflicts during live business peaks.
KPIs should be operational, not cosmetic. Common examples include completed missions per hour, average route delay, stop count per mission, queue time at bottleneck nodes, and percentage of tasks requiring manual recovery. A dashboard that only reports fleet online status provides limited management value.
Continuous tuning is also normal. Even well-designed warehouse AMR programs often need 2 to 4 adjustment cycles after go-live as real order mix, human behavior, and peak-hour traffic reveal new patterns. The objective is not perfect day-one configuration, but a system architecture that supports evidence-based refinement without major redesign.
Recommended rollout sequence
- Measure current-state traffic and task volume by zone for at least 5 to 10 operating days.
- Define right-of-way, queue rules, charger logic, and exception thresholds before software finalization.
- Validate ERP/WMS and fleet interface behavior under late, duplicate, and blocked-task scenarios.
- Run site acceptance tests with congested conditions, not only nominal conditions.
- Train operators and supervisors on 3 levels: normal use, exception handling, and escalation governance.
- Review KPI trends weekly during the first 30 to 60 days and tune based on observed bottlenecks.
FAQ: common buyer and operator questions
How many AMRs can a site add before traffic logic must be redesigned? There is no universal number, but many sites feel the first strong governance pressure when fleets move from single digits to 15 to 30 units in shared lanes. The trigger is usually route density and intersection count, not fleet size alone.
What acceptance test is often missing? Congestion simulation. Many FAT or SAT programs validate travel and docking, but not simultaneous obstruction, charger demand, urgent task insertion, and manual traffic overlap within the same hour.
How long should post-go-live tuning last? For moderate complexity, 2 to 6 weeks of active tuning is common. Multi-zone or mixed-workflow sites may need longer, especially when ERP/WMS logic is also being adjusted.
What should executives ask for in reviews? Ask for delay reason breakdown, not just utilization. A fleet showing 85% utilization may still hide excessive queue loss, poor task sequencing, or frequent operator resets.
Warehouse AMR projects become durable when traffic governance, enterprise data flow, and floor behavior are designed as one system. For researchers, operators, buyers, and executives, the goal is not simply to deploy mobile robots, but to build a predictable transport layer that supports real operational scale.
TechStat Vanguard advocates a data-first approach: define measurable rules, test exceptions under realistic load, and compare suppliers on recoverability as much as raw capability. If you are evaluating AMR for warehouse logistics, reviewing AGV integration with ERP WMS, or planning broader smart factory automation solutions, now is the right time to structure the project around engineering truth rather than late-stage improvisation.
To discuss a more rigorous evaluation framework, request a tailored assessment model, compare integration paths, or review traffic-rule design priorities for your facility, contact us to get a customized solution and deeper technical guidance.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)
 Oct 15, 2026How Should You Compare TechStat Vanguard 5-Axis CNC Tolerances?TechStat Vanguard 5-axis CNC tolerance comparison: learn how to verify part accuracy, assess inspection evidence, and choose suppliers that reliably meet your drawing requirements.Dr. Marcus Vance
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)























