
AGV Solutions for Automotive Manufacturing Face a Charging Bottleneck
Publication Date
author
As automakers accelerate smart factory automation solutions, many discover that AGV solutions for automotive manufacturing face a critical charging bottleneck that undermines throughput, uptime, and ROI. From AGV integration with ERP WMS to AGV positioning accuracy millimeter requirements and automated guided vehicle for heavy load deployment, the real challenge is no longer navigation alone—it is sustaining continuous, data-driven operations at scale.
For most manufacturers, the key question is not whether AGVs can move parts accurately. It is whether the fleet can stay available across multi-shift production without charging delays creating hidden losses in body shop, battery pack assembly, stamping logistics, and final assembly. In practice, charging strategy has become a system-level constraint that affects fleet sizing, line continuity, software orchestration, labor intervention, and capital planning. If charging is designed late, even a technically capable AGV project can underperform.
Why the charging bottleneck is now the real constraint in automotive AGV deployments
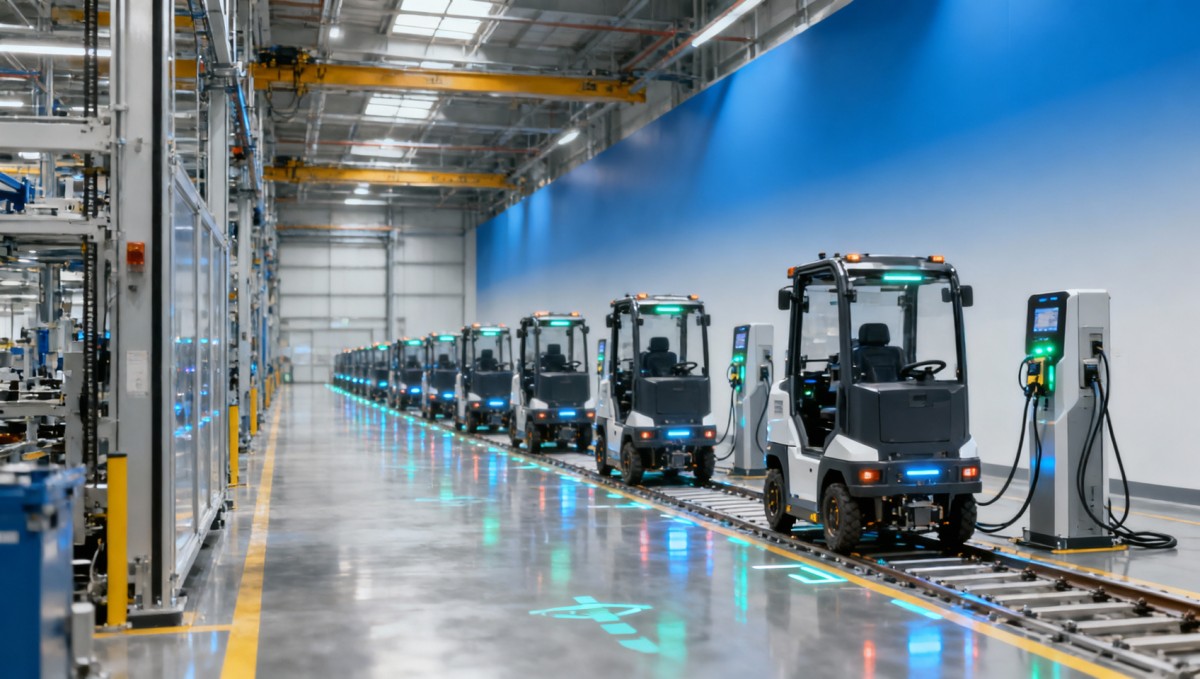
Automotive plants push AGVs harder than many other environments. Duty cycles are longer, payloads are heavier, routes are more repetitive, and uptime expectations are stricter. In these conditions, the charging model directly shapes operational performance.
The bottleneck usually appears when companies scale from pilot success to plant-wide deployment. A small fleet can often tolerate manual charging windows or loosely scheduled opportunity charging. But once the fleet supports just-in-time material flow, body-in-white transfer, heavy load transport, or battery module movement, charging stops being a background utility and becomes a production dependency.
Common symptoms include:
- Vehicles queueing for chargers during peak shifts
- Unexpected traffic congestion around charging stations
- Dispatch software prioritizing battery status over material urgency
- Extra AGV purchases made only to offset unavailable charge time
- Manual intervention increasing because low-battery vehicles miss tasks
- Reduced ROI despite acceptable navigation performance
For decision-makers, the takeaway is simple: the charging bottleneck is rarely just an energy issue. It is a throughput issue, a controls issue, and often a layout issue.
What automotive operators and buyers are actually trying to evaluate
Readers researching this topic usually want practical answers to four questions.
First, how serious is the risk?
Very serious if the AGV fleet supports takt-sensitive production. In automotive manufacturing, even short availability losses can ripple into line starvation, work-in-process imbalance, and missed output targets.
Second, what causes the bottleneck?
Usually not one factor, but the interaction of several: battery chemistry limits, insufficient charger count, poor charger placement, weak dispatch logic, mismatch between route energy demand and charge windows, and underestimation of peak traffic behavior.
Third, can software solve it alone?
Not entirely. Fleet management software, ERP/WMS orchestration, and predictive energy scheduling help a lot, but software cannot fully compensate for physically poor charger topology or unrealistic fleet sizing assumptions.
Fourth, how should a plant judge whether a supplier’s solution is robust?
By asking for operational data, not generic claims. Buyers should request battery cycle performance under actual payload, charging time under realistic state-of-charge windows, fleet availability under peak task density, and recovery behavior after schedule disruption.
Where the charging bottleneck comes from in real automotive production
In theory, AGVs run, recharge, and resume work. In reality, automotive plants introduce conditions that magnify every weakness in that loop.
Heavy-load transport increases energy volatility. An automated guided vehicle for heavy load applications consumes energy differently depending on acceleration profile, floor condition, route slope, pallet weight variance, and stop frequency. This means charging demand is not evenly distributed across the fleet.
Millimeter-level positioning raises power and workflow demands. When AGV positioning accuracy millimeter targets must be maintained for docking, robotic handoff, or high-value subassembly transfer, vehicles may perform more frequent corrections, slower approach logic, or precision sensing routines. These may seem small individually, but across a large fleet they affect cycle time and energy patterns.
Multi-system integration exposes scheduling conflicts. AGV integration with ERP WMS creates operational intelligence, but it also reveals how tightly the fleet is tied to production timing. If material release timing, route prioritization, and charging windows are not coordinated, vehicles can be technically connected yet operationally inefficient.
Peak-hour behavior overwhelms static charging design. Plants often model average utilization, while real production experiences bursts. Shift changes, replenishment spikes, upstream delays, and rework loops create temporary surges in both transport demand and charging demand.
Why many AGV projects look good in pilots but struggle at scale
Pilots are often conducted in simplified conditions: fewer routes, lower congestion, better supervision, and softer uptime expectations. Under these conditions, charging friction stays hidden.
Scale changes everything:
- More vehicles compete for fewer practical charging windows
- Traffic management becomes more complex around shared intersections and charging zones
- Battery degradation begins to affect fleet consistency, not just individual units
- Software optimization must balance task urgency, charge urgency, and route occupancy simultaneously
- Small assumptions in simulation turn into large productivity losses in full production
That is why procurement teams should be cautious about accepting pilot KPIs as proof of plant-wide readiness. The better question is whether the supplier can demonstrate stable fleet availability under scaled, variable, and disrupted operating conditions.
How to evaluate AGV charging strategy before investing further
For researchers, operators, and enterprise buyers, the most useful evaluation framework is not brand-first. It is scenario-first.
Start with these assessment points:
- Fleet duty profile: What is the real hourly mission count by route, payload class, and shift?
- Energy consumption map: Which routes drain batteries fastest under normal and peak loads?
- Charging philosophy: Is the system based on scheduled charging, opportunity charging, battery swap, or hybrid logic?
- Charger topology: Are chargers located where vehicles can access them without disrupting traffic or adding deadhead distance?
- Battery lifecycle behavior: How does performance change after repeated fast-charge cycles and thermal stress?
- Software coordination: Can fleet control dynamically optimize tasks and charge timing based on production priority?
- Failure recovery: What happens if a charger fails, a zone is blocked, or a batch of vehicles enters low-battery state simultaneously?
If a supplier cannot answer these questions with quantified evidence, the charging bottleneck risk remains high.
What solutions actually reduce the bottleneck
There is no universal fix, but the most effective approaches usually combine hardware, software, and workflow redesign.
Opportunity charging in the right process windows. This works best when routes naturally include short dwell times and the fleet software can distribute charging events intelligently. Poorly implemented opportunity charging, however, can simply move congestion from transport lanes to charger lanes.
Better charger placement, not just more chargers. Adding chargers sounds easy, but charger count alone does not solve layout inefficiency. Placement should minimize queueing, dead travel, and conflict with production traffic.
Segmented fleet logic. Not all AGVs should share the same charging rules. Heavy-load units, takt-critical units, and flexible replenishment units often need different dispatch and charge priorities.
Battery and thermal management visibility. Real-time monitoring of battery health, temperature, and charge acceptance helps avoid hidden degradation that reduces availability over time.
Digital twin or simulation-based validation. Before rollout, plants should model route density, charge demand peaks, charger failure scenarios, and production variation. This is far more reliable than planning from average utilization spreadsheets.
What procurement teams and plant leaders should ask suppliers
For enterprise decision-makers, the goal is to separate marketing language from engineering truth. Ask suppliers for evidence that matches your production reality.
- What fleet availability can you guarantee under our shift pattern and payload mix?
- What is the average and worst-case charger queue time in comparable automotive sites?
- How does battery degradation affect mission capacity after 12, 24, and 36 months?
- How is AGV integration with ERP WMS used to prevent charging from conflicting with material priority?
- What happens when charger capacity is temporarily reduced?
- Can the system maintain AGV positioning accuracy millimeter requirements when battery state changes?
- For automated guided vehicle for heavy load use cases, what are the validated runtime figures at full payload?
These questions help buyers compare solutions on operational resilience, not brochure claims.
The practical bottom line for automotive manufacturers
AGV solutions for automotive manufacturing do not fail only because of navigation, localization, or software integration gaps. Increasingly, they underperform because charging architecture was treated as a secondary utility rather than a core production design variable.
The strongest AGV deployments are built around a clear understanding of energy demand, charger topology, fleet behavior, and line-critical task priority. When charging is engineered into the system from the start, manufacturers can improve uptime, reduce unnecessary fleet oversizing, and protect automation ROI. When it is ignored, the plant often pays twice: once for the AGV investment, and again for the lost throughput it was supposed to prevent.
For teams evaluating or expanding AGV programs, the right decision is not just choosing vehicles with good specs. It is choosing an operational model where charging, dispatching, and production flow work as one system.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)
 Oct 15, 2026How Should You Compare TechStat Vanguard 5-Axis CNC Tolerances?TechStat Vanguard 5-axis CNC tolerance comparison: learn how to verify part accuracy, assess inspection evidence, and choose suppliers that reliably meet your drawing requirements.Dr. Marcus Vance
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)























