What makes a digital twin useful on an assembly line
Publication Date
author
For enterprise decision-makers, the real value of a digital twin for automotive assembly line operations lies in measurable control—not hype. When every second of downtime, tolerance drift, and process imbalance affects cost and output, a useful digital twin turns live production data into actionable engineering insight. It helps teams validate performance, reduce risk, and make faster, evidence-based decisions across complex manufacturing environments.
When does a digital twin for automotive assembly line work become truly useful?
A digital twin is useful only when it reflects real production constraints, not an idealized animation of the line.
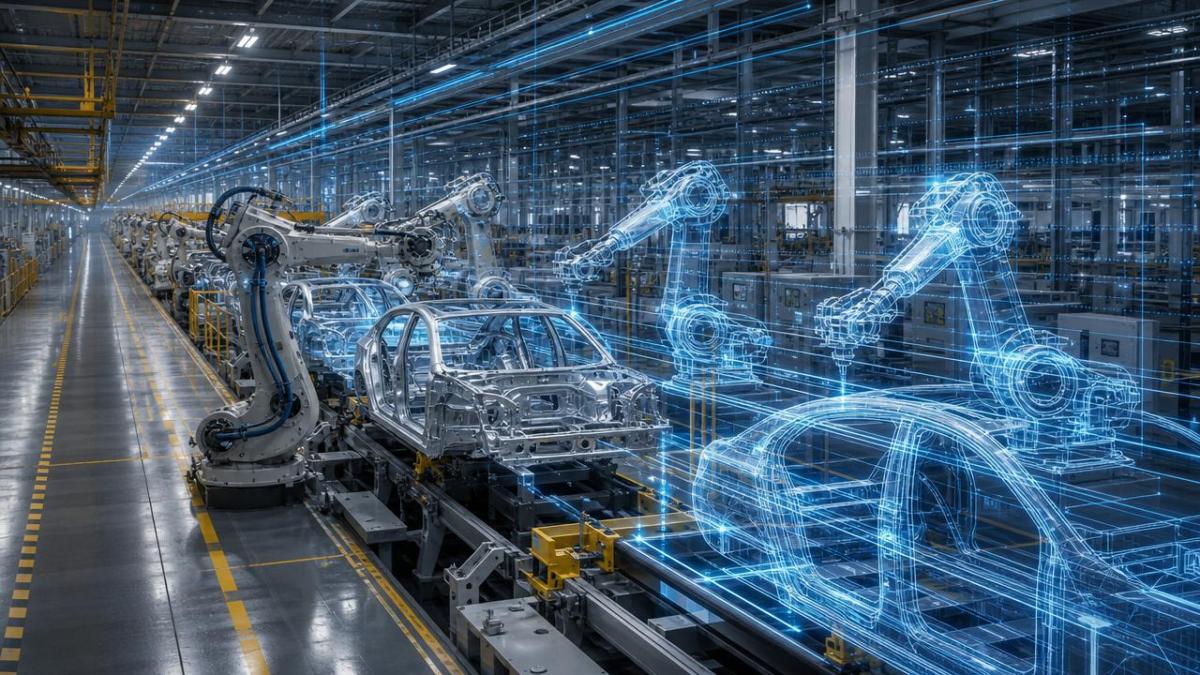
On an assembly line, usefulness starts with synchronization between physical equipment, process logic, and operational data.
That means cycle times, torque values, robot paths, station buffers, and defect signals must stay connected to the twin.
If the model cannot explain why throughput fell, why queues formed, or why rework increased, it is not useful.
In a data-driven environment, engineering truth matters more than visual complexity. Parameters must support decisions.
This is especially important in mixed-model production, where one line may process multiple variants with different takt requirements.
A practical digital twin for automotive assembly line optimization should answer three questions quickly.
- Where is current performance deviating from plan?
- What upstream factor is creating the deviation?
- What change delivers the lowest-risk improvement?
Why scenario judgment matters on an assembly line
Not every assembly environment needs the same twin architecture, update frequency, or simulation depth.
A body shop, battery pack line, trim line, and final inspection cell have different bottlenecks and data priorities.
Using one generic model across all scenarios usually creates cost without decision value.
A useful digital twin for automotive assembly line planning must match the decision layer it supports.
For some lines, the twin should focus on real-time condition monitoring and downtime prediction.
For others, the twin should validate layout changes, staffing balance, buffer sizing, or product variant sequencing.
This scenario-based approach aligns with TSV’s engineering-first view: data should reduce uncertainty, not decorate dashboards.
Which assembly line scenarios benefit most from a digital twin?
High-variation model assembly
Mixed-model assembly creates unstable takt patterns, changing parts demand, and uneven operator workload.
Here, a digital twin for automotive assembly line control helps test sequence rules before disruptions reach the floor.
The key judgment point is whether the twin can simulate variant-driven station overload with real routing logic.
Robot-intensive fastening and joining stations
In robotic stations, small path drift or timing overlap can reduce output and increase quality risk.
A useful twin tracks path execution, torque traces, cycle stability, and collision margins.
The judgment point is whether the model links robot behavior to quality outcomes, not just motion replay.
Battery and e-mobility assembly processes
Battery pack assembly adds thermal sensitivity, traceability requirements, and strict process windows.
A digital twin for automotive assembly line deployment is valuable when it maps process tolerances to defect risks.
Useful models should connect dispensing, welding, sealing, and inspection data into one process view.
Ramp-up and line reconfiguration projects
During launch phases, assumptions fail quickly because actual throughput rarely matches nominal design values.
A digital twin for automotive assembly line ramp-up helps validate bottlenecks before capital changes become expensive.
The judgment point is how fast the twin can absorb new floor data and update constraints.
How needs differ across assembly line scenarios
Different scenarios require different inputs, outputs, and success metrics.
This is why the best digital twin for automotive assembly line results does not begin with software selection.
It begins with a precise decision problem, a measurable operational baseline, and trusted source data.
What should be included in a useful digital twin model?
A useful model does not need every variable. It needs the right variables with stable update logic.
For most assembly lines, the following elements create practical value.
- Station-level cycle time and queue data
- Equipment state signals and downtime codes
- Quality checkpoints linked to process steps
- Material flow and buffer occupancy
- Variant routing and work content differences
- Changeover time and maintenance events
Without this structure, a digital twin for automotive assembly line use may look complete but remain operationally weak.
The strongest models also include confidence rules, showing which calculations are estimated and which are measured.
How to choose the right scenario-fit approach
A scenario-fit approach reduces deployment waste and improves adoption.
- Define the line decision that currently lacks evidence.
- Identify the minimum data needed to answer that decision.
- Map constraints at station, line, and plant levels.
- Select update frequency based on process volatility.
- Test the twin against one repeatable production problem.
- Measure whether actions from the twin improve output or quality.
This method supports a more rigorous digital twin for automotive assembly line strategy.
It also reflects TSV’s benchmark mindset: the model must prove value through engineering outcomes.
What are the most common misjudgments?
The first mistake is treating visualization as value.
A 3D model does not guarantee a useful digital twin for automotive assembly line improvement.
The second mistake is ignoring data quality. Poor timestamp alignment breaks causality across stations.
The third mistake is modeling too much too early. Broad scope often delays the first usable result.
The fourth mistake is separating process engineers from model logic. Operational expertise must shape assumptions.
The fifth mistake is measuring success only by implementation completion, not by throughput, scrap, or downtime reduction.
What should the next step look like?
Start with one line problem that has visible cost and repeatable occurrence.
Examples include unstable cycle balance, recurring robot stoppage, or variant-driven congestion.
Then define the minimum viable digital twin for automotive assembly line validation around that problem.
Use measured signals, clear baselines, and short feedback loops.
If the twin consistently explains deviations and improves decisions, expand its scope with discipline.
In advanced manufacturing, useful systems are not judged by claims. They are judged by tolerance control, traceable insight, and verified improvement.
That is what makes a digital twin for automotive assembly line operations genuinely useful on an assembly line.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 10, 2026When does the cost of industrial robots pay back in high-volume production?Cost of industrial robots: discover how high-volume manufacturers calculate payback through uptime, cycle time, labor, quality, and integration before investing.Chen Wei (Automation Lead Engineer)
 Oct 09, 2026What does a manufacturing robot really cost beyond the purchase price?Manufacturing robot cost goes far beyond the purchase price. Explore integration, tooling, safety, uptime, and total ownership factors for smarter automation investments.Chen Wei (Automation Lead Engineer)
 Oct 08, 2026AGV vs. AMR: Which Is Better for Frequently Changing Routes?Which is better for changing routes? Compare AGVs and AMRs for flexible navigation, docking precision, traffic control, and faster facility reconfiguration.Chen Wei (Automation Lead Engineer)
 Oct 07, 2026How Much Does an Automated Guided Vehicle Cost in 2026?How much does an automated guided vehicle cost in 2026? Explore AGV price ranges, hidden deployment costs, and smart buying factors for stronger ROI.Chen Wei (Automation Lead Engineer)
 Oct 06, 2026Are Collaborative Robots Safe Enough to Operate Without Fencing?Are collaborative robots safe enough to work without fencing? Explore risk assessment, safeguarding options, and practical guidance for safer, productive cobot cells.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026What Causes Machine Vision Systems to Miss Small Defects?What causes machine vision systems to miss small defects? Discover how lighting, optics, motion, and AI thresholds affect detection—and prevent costly escapes.TSV Data Lab