
Why vision inspection software misses defects in mixed lighting
Publication Date
author
Mixed lighting is one of the fastest ways to expose the limits of vision based quality inspection software. Reflections, shadow shifts, spectral imbalance, and unstable contrast can cause vision inspection software to miss critical defects that operators, engineers, buyers, and decision-makers cannot afford to overlook. This article explains the root causes, the hidden performance gaps, and what to verify before selecting or optimizing an inspection system.
Why mixed lighting breaks defect detection more often than teams expect
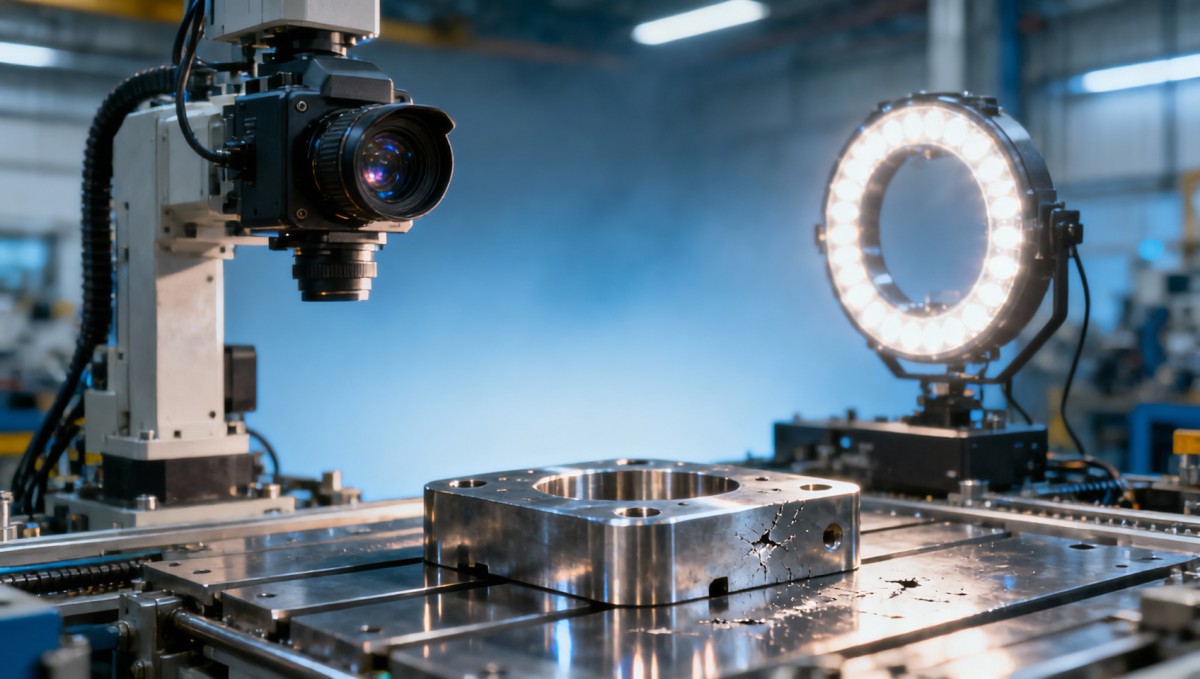
In controlled demos, vision inspection software often performs well because the image source is stable. On a real production floor, lighting rarely stays stable for an entire 8–12 hour shift. Ambient daylight changes, overhead LEDs age, machine enclosures reflect light differently after maintenance, and product surfaces vary between lots. Mixed lighting turns a repeatable imaging task into a moving target, and that is where missed defects begin.
The problem is not only brightness. Mixed lighting changes the spectral content reaching the camera sensor. A scratch that is visible under one wavelength may nearly disappear under another. A stain that stands out under diffuse white light may blend into the background under a warmer source. When software thresholds, segmentation rules, or neural models are trained in one lighting condition and deployed in another, inspection reliability drops without an obvious alarm.
This matters across industries. In electronics, solder bridges, hairline cracks, and contamination can be hidden by reflections. In precision machining, burrs and edge chips may be masked by glare on metallic parts. In packaging and medical production, print contrast, seal integrity cues, and particulate visibility can change within a narrow angle range of 5°–15°. The software does not “ignore” defects by choice; it receives inconsistent visual evidence.
For information researchers and procurement teams, this is a key evaluation issue. A supplier may claim high detection accuracy, but if the benchmark was built under a single light source, the result does not represent real deployment risk. TSV’s engineering-first view is simple: parameters do not lie. If illumination stability, sensor response, and tolerance windows are not quantified, the vision inspection software claim is incomplete.
- Mixed lighting introduces three core failure paths: unstable contrast, false edges caused by glare, and defect invisibility caused by spectral mismatch.
- The risk increases when parts have glossy, translucent, curved, or highly textured surfaces, especially when line speed changes across small-batch and mid-volume production.
- The hidden cost is not only escapes. It also includes false rejects, reinspection labor, delayed supplier qualification, and longer process validation cycles.
What actually causes vision inspection software to miss defects under mixed lighting?
Most missed-defect events under mixed lighting come from the interaction of optics, illumination, part geometry, and algorithm design. Teams often focus on the software layer first, but the root cause is frequently upstream. If the camera receives a poor image, even advanced vision inspection software can only work within a narrow confidence band. That is why robust inspection starts with imaging physics, not just model tuning.
Contrast instability is the first failure mode
Rule-based systems depend on consistent grayscale or color separation between a defect and the background. Mixed lighting changes this separation across time and position. A defect that shows a grayscale difference of 20–30 levels in one station may shrink to fewer than 8–10 levels at another angle or time of day. Once that margin collapses, thresholds fail and segmentation becomes erratic.
This is especially common in lines with a combination of ring lights, overhead factory lighting, and incidental sunlight. Operators may not notice the shift because the human eye adapts quickly, but the machine vision system measures the scene as a different input distribution. The result is unstable pass/fail logic, even when the part itself has not changed.
Reflections create false features and hide real defects
Specular reflection is a major reason vision inspection software misses scratches, pits, dents, and edge defects on metal, coated plastic, polished glass, and carbon fiber surfaces. Bright hotspots saturate pixels, flatten local detail, and generate edges that do not belong to the part. In a production cell, a reflection can move with only a small shift in fixture position, lens angle, or lamp intensity.
If a defect occupies only a few pixels, saturation can erase it completely. If a model was trained on images with controlled reflection but deployed under mixed lighting, it may overfit to background shine rather than true defect morphology. This is why line teams often report a confusing pattern: the system catches obvious defects but misses subtle ones in random bursts.
Spectral mismatch changes what the sensor can see
Not all light sources are equivalent, even when they appear equally bright to operators. Different LEDs, fluorescent fixtures, and natural light produce different spectral distributions. Certain inks, adhesives, residues, and polymer finishes respond strongly to specific wavelength bands. If the camera, lens coating, and illumination are not matched, the defect signature may weaken or shift unpredictably.
For buyers comparing systems, this means a simple lux value is not enough. You need to ask whether the supplier validated the application under white, red, blue, infrared, or multispectral conditions; whether the exposure range was fixed; and whether the defect library covered lot-to-lot material variation across at least 3 production states.
Motion and exposure amplify lighting variability
At higher conveyor speeds or shorter takt times, exposure settings become more sensitive. If mixed lighting forces a compromise between motion blur and image brightness, small defects can disappear. In practical terms, a line running at 20–60 parts per minute may tolerate one imaging setup, while a line at 120 parts per minute may require strobe synchronization, shielding, and tighter trigger timing.
This is where engineering benchmarking matters. TSV’s perspective is that software should never be evaluated in isolation. Inspection reliability must be mapped against sensor type, lens selection, light geometry, enclosure design, part presentation, and acceptable defect size range. Without that framework, accuracy claims are marketing language, not decision-grade data.
Which technical parameters should buyers and engineers verify before trusting the result?
When teams evaluate vision inspection software for mixed lighting, they should move beyond a single “detection rate” number. A more reliable assessment uses a parameter matrix that links imaging conditions to defect classes. This helps procurement teams compare vendors on measurable engineering evidence instead of polished demos.
The table below summarizes practical verification items that matter during pre-purchase trials, factory acceptance, or line optimization. These are not exotic laboratory metrics. They are the operational questions that determine whether the system will remain stable after 2–4 weeks of normal production variation.
A reliable inspection project usually defines at least 5 key checks before sign-off: target defect size, allowable false reject range, lighting variance tolerance, cycle time per part, and revalidation method after process changes. If a vendor cannot explain these points clearly, the burden of risk will move back to the factory.
Three practical parameter groups to request in every evaluation
First, request image acquisition parameters: sensor type, pixel size, lens focal length, exposure window, trigger method, and recommended working distance. Second, request illumination parameters: source type, geometry, diffuser design, shielding assumptions, and maintenance interval. Third, request algorithm parameters: defect classes supported, retraining triggers, acceptable confidence threshold range, and fallback rules for uncertain images.
For enterprise decision-makers, these details shorten supplier qualification. For operators, they reduce troubleshooting ambiguity. For procurement teams, they make quotations comparable. Without parameter transparency, two proposals may look similar in price but differ sharply in deployment risk and long-term support cost.
How should you compare inspection approaches in mixed-light environments?
There is no single best inspection architecture for every line. The right choice depends on defect type, part material, throughput, and process stability. In mixed lighting, the wrong architecture often creates a false sense of security because it works during setup but degrades during routine production. A structured comparison helps prevent that mistake.
The table below compares common inspection approaches used in industrial quality control where mixed lighting is a known risk. The goal is not to recommend one method universally, but to show where each method becomes fragile or resilient.
The engineering lesson is straightforward: software selection and lighting strategy cannot be separated. If your environment includes open stations, reflective components, or more than one active light source, a lower-cost 2D system may still succeed, but only with controlled shielding, fixed angles, and disciplined maintenance. If those controls are unrealistic, the apparent savings may vanish through escapes and manual rechecks.
A practical decision path for procurement and technical teams
- Define the top 3 defect classes by risk, not by convenience. A visible stain and a safety-critical crack should not carry the same validation priority.
- Map the real lighting environment over at least 2 production periods, such as day shift and night shift, or enclosure open and closed maintenance states.
- Run sample validation with mixed good and bad parts across small-batch and normal throughput conditions, not only static bench tests.
- Compare revalidation effort. A cheaper system that requires frequent retuning can cost more over 6–12 months.
This decision path aligns with TSV’s broader hard-tech philosophy. Strip away adjectives and compare the inspection stack by measurable tolerances, validation evidence, and long-term operating discipline.
What should operators, buyers, and decision-makers check before deployment or purchase?
A strong purchasing decision for vision inspection software in mixed lighting should include operational checks, not just commercial terms. Many projects fail after installation because the procurement scope excluded enclosure design, operator access effects, cleaning frequency, or dataset refresh rules. The software is then blamed for a system-level gap that should have been defined upfront.
Operator checklist for daily stability
Operators need a clear routine that takes 5–10 minutes per shift, not a vague instruction to “watch the images.” A practical checklist includes lens cleanliness, light source status, fixture repeatability, reference sample review, and confirmation that no new reflective objects were introduced in the station. These checks reduce drift before it becomes a quality event.
If the station operates across multiple product variants, operators should also know which variant changes require recipe confirmation. In mixed lighting, even a packaging film change or surface finish update can alter image behavior enough to affect defect detection. Fast escalation rules are essential when reject patterns change suddenly.
Procurement checklist for supplier comparison
Buyers should ask 6 core questions: What lighting conditions were used during validation? What is the target defect size range? How many part states were tested? What requalification steps are required after a material or fixture change? What support is included during the first 30–90 days? What image data will be retained for troubleshooting and acceptance review?
These questions transform a sales discussion into an engineering discussion. They also help compare quotations with different hidden assumptions. One supplier may price only software and camera hardware, while another includes lighting redesign, shielding, commissioning, and line-side retraining support.
Decision-maker checklist for risk and total cost
Enterprise leaders should evaluate total cost over the full operating window, often 12–24 months, rather than judging only the initial purchase. Key cost drivers include false rejects, operator intervention time, retraining frequency, spare lighting modules, engineering support, and downtime during recipe changes. Mixed lighting increases all of these if the initial design is under-specified.
A disciplined project usually defines 4 implementation stages: application review, sample imaging study, line trial, and acceptance benchmark. That structure reduces surprises and shortens the path from concept to qualified production use.
- Do not approve a system based only on showroom images or static bench samples.
- Do not separate lighting hardware responsibility from software accountability without a written interface definition.
- Do not assume AI eliminates the need for controlled imaging; it reduces some sensitivity but does not cancel physics.
FAQ: common questions about vision inspection software in mixed lighting
Can better software alone solve missed defects in mixed lighting?
Not usually. Better vision inspection software can improve tolerance to variation, but it cannot recover image information that was never captured. If reflections saturate the sensor or contrast collapses below a usable range, software has limited room to respond. In most factories, the durable fix combines lighting control, optics review, and algorithm adjustment.
A practical rule is to treat imaging and analysis as one system. If you only change the software, you may gain short-term improvement but still leave the line vulnerable during shift changes, material changes, or seasonal daylight variation.
Which environments are most likely to create mixed-light inspection failures?
Open stations near windows, cells with transparent safety panels, lines with multiple retrofitted lamps, and stations inspecting glossy or curved parts are common problem environments. Facilities that run different products on the same line also see higher risk because each material finish interacts differently with the available light sources.
If your station includes more than one active illumination path and no light shielding, assume there is a qualification risk until proven otherwise. That is true for electronics, machining, aerospace components, packaging, plastics, and general industrial assembly.
How long does a proper validation process usually take?
For a defined application with available samples, an initial imaging and feasibility review may take 7–15 days. A more complete line-side validation with multiple lots, multiple defect types, and mixed-light stress testing often extends to 2–4 weeks. Complex applications with fixture redesign or multispectral evaluation can take longer.
Rushing this step increases risk. If the supplier cannot explain the validation phases, acceptance criteria, and retest trigger conditions, the deployment schedule may look fast on paper but expensive in operation.
What is the biggest procurement mistake in this category?
The most common mistake is buying based on a headline detection claim without verifying the test conditions. Accuracy without context is not a decision metric. Buyers need to know the defect library, lighting states, sample count logic, acceptable false reject range, and who owns revalidation after a line change.
A second common mistake is under-budgeting for the imaging environment. Spending on software while neglecting enclosures, light control, and sample engineering often leads to preventable misses later.
Why work with a data-driven technical partner before you commit?
In hard-tech sourcing, the gap between a convincing demo and a stable production result can be costly. TechStat Vanguard approaches that gap as an engineering benchmarking problem, not a branding problem. For mixed-light inspection projects, that means focusing on tolerance windows, defect visibility conditions, imaging dependencies, and supplier-side validation logic before a purchasing decision is locked in.
This approach is especially useful for information researchers building a longlist, operators dealing with unstable line behavior, procurement teams comparing competing offers, and decision-makers responsible for qualification speed. Instead of relying on generic claims, you can assess whether the proposed vision inspection software stack matches your defect types, throughput range, and environmental constraints.
If you are reviewing an existing system or preparing a new sourcing project, the most valuable discussions usually start with specific questions: Which defect classes are currently missed? Under what lighting states do escapes occur? What part materials create reflection problems? What cycle time and acceptance thresholds are required? These details drive the right architecture far more than product slogans do.
Contact TSV to discuss parameter confirmation, inspection architecture comparison, sample-based feasibility review, supplier evaluation criteria, expected validation cycle, and deployment risk checkpoints. If needed, the conversation can also cover lighting strategy, retraining triggers, support scope, quotation comparison, and what to include in a defensible spec sheet before purchase.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026How tight can micro machining aerospace tolerances be in production?Micro machining aerospace tolerances can reach low-micron levels in production. Learn what controls repeatability, inspection confidence, and flight-critical quality.Dr. Marcus Vance
 Oct 13, 2026How to keep an industrial robotic integration project on scheduleIndustrial robotic integration project management: keep automation on schedule with proven controls for interfaces, suppliers, FAT, commissioning, and change risk.Victor Lin (Chief Software Architect)























