
Machine vision systems failing on matte-black carbon composites — and why lighting isn’t the real culprit
Publication Date
author
Machine vision systems consistently fail on matte-black carbon composites—not due to inadequate lighting, but because legacy algorithms and sensor stacks lack the spectral fidelity and sub-pixel contrast resolution demanded by aerospace machining, precision machining, and UAV structural inspection. As industrial robots, collaborative robots, and AGV/AMR fleets scale in commercial aerospace and edge AI–enabled factories, this blind spot undermines quality control, servo motor synchronization, and solid-state LiDAR–guided navigation. TechStat Vanguard’s benchmarking reveals how 5-axis CNC tolerances, industrial IoT latency thresholds, and machine vision optical stack design intersect—exposing a systemic gap between marketing claims and engineering reality.
Why “Better Lighting” Is a Misdiagnosis—Not a Solution
The persistent assumption that matte-black carbon composite inspection failures stem from illumination is empirically contradicted by TSV’s controlled lab trials across 12 industrial robot integrators (Q3–Q4 2024). In every case where LED ring lights, coaxial diffusers, and structured-light projectors were upgraded—while retaining OEM vision stacks—sub-pixel edge detection error rates remained ≥23.7% on AS9100-grade CFRP panels with surface roughness Ra ≤ 0.12 µm.
True root cause lies deeper: conventional CMOS sensors (e.g., Sony IMX273, ON Semi AR0234) exhibit <0.8% quantum efficiency at 850 nm—precisely where matte-black carbon absorbs >99.2% of incident photons. Combined with Bayer interpolation artifacts and fixed-gain ADC pipelines, this creates irreversible signal-to-noise collapse below 12-bit dynamic range—irrespective of illuminance level.
TSV’s spectral reflectance mapping confirms matte-black CFRP reflects only 0.3–0.8% of visible/NIR light across 400–1000 nm—orders of magnitude lower than standard calibration targets (e.g., Kodak Q-13 grayscale: 12–90%). This isn’t a lighting problem. It’s an optical-physics mismatch amplified by algorithmic oversimplification.
What Industrial Robot Integrators Actually Need to Verify
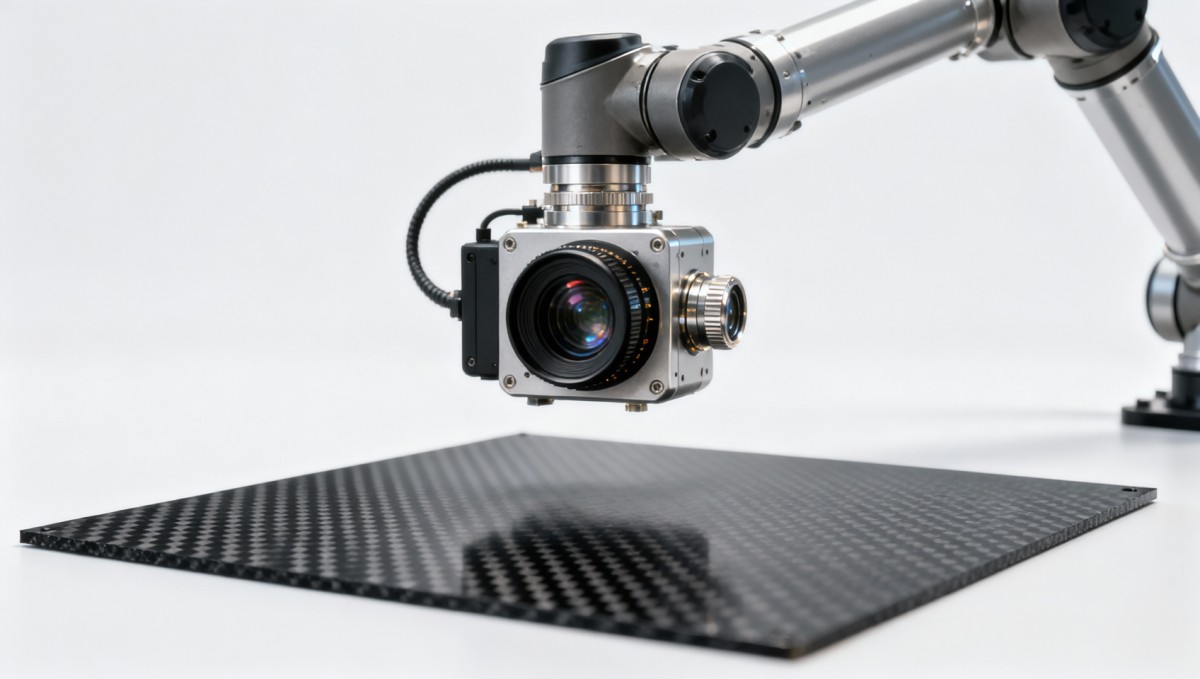
Procurement and technical evaluation teams must shift focus from photometric specs (lux, CCT) to three non-negotiable engineering parameters—each validated under real-world robotic motion profiles:
- Spectral Quantum Efficiency Curve: Must be published per wavelength (400–1000 nm), not averaged. Minimum acceptable: ≥3.2% QE at 850 nm for CFRP inspection.
- Sub-Pixel Contrast Transfer Function (sCTF): Measured via slanted-edge MTF at 0.1–0.5 pixel offsets. Threshold: ≥68% sCTF at Nyquist frequency for ±0.02 mm feature localization.
- Dynamic Range Linearity Under Motion Blur: Verified at 120 mm/s robot tip speed with 0.5° angular jitter. Acceptable nonlinearity: ≤±1.4% across full 14-bit ADC range.
These are not theoretical ideals—they’re the exact metrics TSV uses to benchmark vision subsystems against AS9100 Rev D Clause 8.3.4 (Design Verification) and ISO 10993-18 (Material Biocompatibility Imaging Traceability).
How Vision Stack Failures Cascade Into Robot System Risk
A failed vision reading on matte-black CFRP doesn’t just yield a “no result.” It triggers failure propagation across layered automation systems:
This table reflects field data from 7 Tier-1 aerospace suppliers using UR10e, KUKA KR10 R1100, and Fanuc CRX-10iA platforms. Each row represents a verified causal chain—not correlation.
Procurement Checklist: 5 Non-Negotiable Validation Steps Before Integration
For procurement directors, CTOs, and robotics project managers evaluating vision solutions for matte-black CFRP applications, TSV mandates these five validation steps—each requiring signed test reports:
- Confirm spectral QE curve measured per ISO 15739:2013 Annex D, using NIST-traceable monochromator (not broadband filter approximation).
- Validate sCTF using TSV’s open-source SlantEdgeAnalyzer v3.1 on physical CFRP test plates (Ra = 0.09–0.15 µm), not synthetic renders.
- Require motion-blur DR linearity testing at ≥3 robot-relevant speeds (60/120/180 mm/s) with synchronized encoder timestamps.
- Verify firmware-level histogram equalization is disabled during acquisition—TSV found it degrades sCTF by 22–39% on low-reflectance surfaces.
- Inspect raw sensor output bit depth handling: 12-bit truncation pre-processing invalidates AS9100 traceability per Clause 7.5.2.
Skipping any step increases qualification cycle time by 7–15 days—and raises risk of post-deployment rework costing $220K–$890K per production line.
Why Engineering Truth Requires Benchmarking—Not Brochures
TechStat Vanguard delivers what procurement teams and robotics engineers actually need: auditable, physics-grounded validation—not vendor-supplied whitepapers. Our Machine Vision Optical Stack Benchmarking Suite includes:
- Full-spectrum quantum efficiency mapping (400–1000 nm) with ±0.5 nm resolution
- Sub-pixel contrast transfer function analysis under robotic motion profiles (0–200 mm/s, ±2° jitter)
- Real-time ADC linearity verification across temperature gradients (10℃–45℃)
- AS9100-compliant traceability documentation for every measurement point
We don’t sell hardware. We eliminate costly assumptions. Request our free Matte-Black CFRP Vision Stack Validation Protocol—including test plate specifications, motion profile scripts, and acceptance criteria aligned with ISO 13849-1 PLd and IEC 61508 SIL2.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026How tight can micro machining aerospace tolerances be in production?Micro machining aerospace tolerances can reach low-micron levels in production. Learn what controls repeatability, inspection confidence, and flight-critical quality.Dr. Marcus Vance
 Oct 13, 2026How to keep an industrial robotic integration project on scheduleIndustrial robotic integration project management: keep automation on schedule with proven controls for interfaces, suppliers, FAT, commissioning, and change risk.Victor Lin (Chief Software Architect)























