How to reduce false rejects in machine vision factory inspection
Publication Date
author
A false reject occurs when a conforming part is classified as defective. In a machine vision inspection factory, that error is not merely a nuisance: it creates unnecessary manual review, disrupts line balance, can trigger avoidable holds, and gradually weakens confidence in the inspection system. The dangerous response is to lower the decision threshold until the reject rate looks acceptable. That may reduce nuisance rejects while allowing real defects to pass.
The correct objective is not the lowest possible reject rate. It is a stable and explainable decision boundary that separates acceptable product variation from conditions that genuinely violate the specification. Achieving that boundary requires treating false rejects as a system problem involving the part, presentation, imaging chain, reference data, and inspection logic—not as a single software parameter.
Measure the error before tuning the system
Many inspection stations report only a total reject rate. That number is insufficient. A rejected part should be traced through disposition: confirmed defect, confirmed good part, inconclusive because of handling damage, or unable to verify. Without this feedback, the system may be tuned against assumptions rather than evidence.
A useful starting point is a reject review record that links each event to the image, time, camera or station ID, product variant, lot, fixture position, operator disposition, and stated reject reason. The goal is to identify repeatable patterns. False rejects often cluster around one cavity, one shift, a particular surface finish, a specific batch of packaging, a camera position, or a lighting condition that changes after cleaning or maintenance.
Separate the inspection result from the business disposition. A vision system may correctly identify an unusual visual condition even if the part is later accepted through an approved concession. That is not necessarily a false reject. Conversely, a part that passes functional testing after being rejected for a cosmetic criterion may still reveal that the visual specification or the vision rule is poorly aligned with the actual acceptance standard.
The review process should preserve the original image and the inspection settings used at the time of the decision. Reprocessing an image after settings have changed can be useful for diagnosis, but it must not overwrite the historical evidence. Traceability matters when a recurring nuisance reject becomes a customer complaint, a quality escape investigation, or a safety-related production stop.
Start with the acceptance criterion, not the algorithm
False rejects frequently originate before the camera captures an image. The system is asked to detect “scratches,” “contamination,” “missing material,” or “incorrect assembly” without a measurable definition of what makes the condition rejectable. Human inspectors may apply experience and context; an automated system cannot reliably infer an unwritten rule.
A usable vision criterion should answer practical questions:
- What feature is being assessed: length, width, area, contrast, position, count, completeness, color, or surface continuity?
- What is the allowable range or minimum detectable defect size?
- Where on the part does the rule apply, and which regions are excluded?
- Does orientation, material grain, texture, gloss, print registration, or natural variation affect appearance?
- Which conditions require automatic rejection, which require review, and which are acceptable?
For example, a rule such as “reject visible scratches” is too subjective for reliable automation. A more operational requirement may define a protected zone, a minimum scratch length and contrast relative to its local background, and exclusions for known texture or machining marks. The exact values must come from product requirements and risk assessment, not from what is easiest for the camera to detect.
Where product safety, function, seal integrity, identification, or regulatory marking is involved, acceptance criteria need particular discipline. A false reject is costly, but an overly relaxed rule for a critical feature can create a far larger exposure. The decision logic should reflect defect severity rather than applying the same tolerance philosophy to every visual anomaly.
Lighting is often the real root cause
When a station rejects apparently good parts inconsistently, lighting deserves scrutiny before software thresholds are changed. Machine vision does not inspect a part directly; it inspects reflected, transmitted, or emitted light. A minor change in illumination angle can make a harmless texture appear as a defect or cause a true defect to disappear.
Highly reflective metal, clear film, curved plastic, wet surfaces, textured coatings, and printed materials all create different optical challenges. A bright-field setup may exaggerate glare on a glossy label. Low-angle dark-field lighting may make acceptable surface texture look like scratching. Backlighting can be excellent for measuring a silhouette but cannot reveal many surface defects. Coaxial lighting can improve uniformity on flat reflective surfaces but may be unsuitable for deep features or irregular geometry.
Uniformity matters as much as brightness. If illumination falls off across the field of view, a global grayscale threshold can reject parts at the darker edges while accepting identical parts near the center. The same effect can appear when LEDs age, lenses become contaminated, protective windows haze, or ambient light reaches the inspection zone.
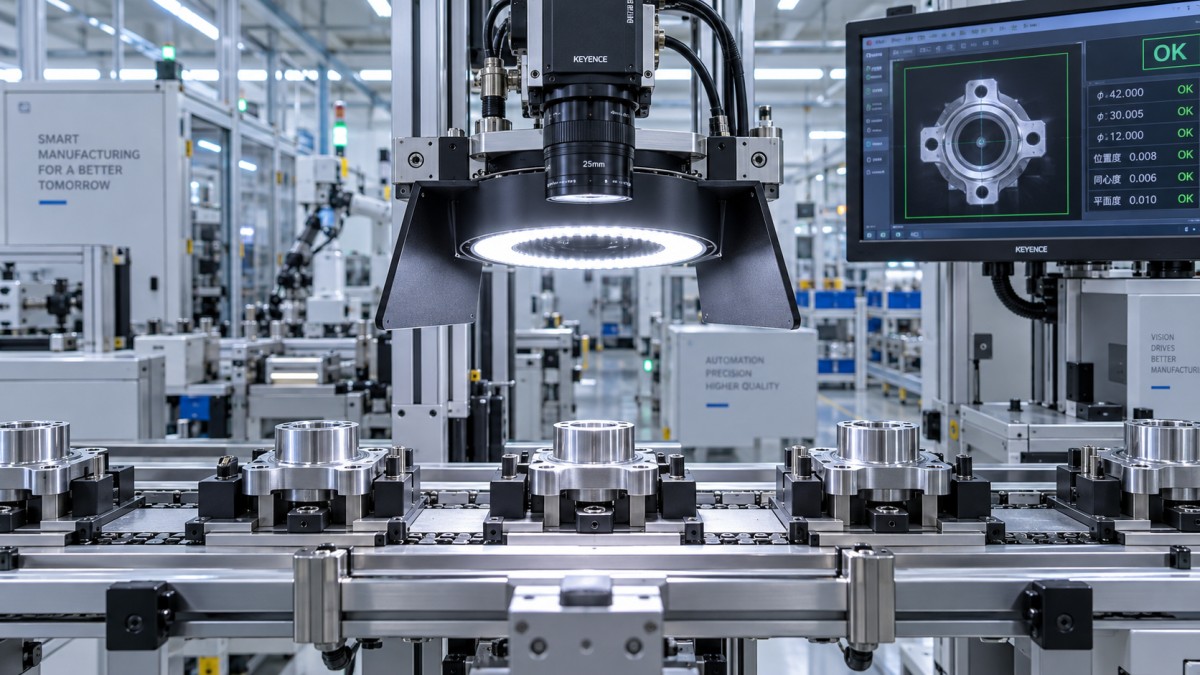
Before changing a threshold, capture images of the same known-good part at different locations in the fixture and at the beginning and end of a production run. Compare background intensity, contrast, reflections, and feature measurements. If the image changes substantially while the part does not, the imaging environment—not part quality—is driving instability.
Lighting control should include mechanical shielding from ambient light, stable power supplies, fixed mounting, cleaning intervals, and checks after lamp, lens, or fixture changes. For demanding surface inspections, a single image may not be enough. Combining lighting geometries or capturing images from more than one angle can distinguish a real surface discontinuity from a reflection. That increases system complexity, but it may be more defensible than forcing one lighting setup to handle incompatible defect mechanisms.
Control part presentation and fixture variation
A vision application can be accurate in a controlled validation image set yet reject good product when parts arrive rotated, shifted, tilted, vibrating, or inconsistently seated. The software may be capable of locating the part, but broad position correction has limits. A feature seen at an angle changes its apparent shape, focus, and contrast; it is not simply translated within the image.
Fixture wear is a common source of gradual drift. Locating pins, nests, clamps, belts, guides, and part stops can change the part’s pose without generating an obvious mechanical alarm. Vibration from nearby equipment may also introduce motion blur, especially where short cycle times force fast exposure.
Inspect the production process around the camera. Ask whether the part is fully seated at image capture, whether the conveyor speed is constant, whether a pneumatic clamp settles before triggering, and whether protective films, oil, dust, or handling marks are present only at certain stages. A reject pattern tied to an assembly sequence may indicate that inspection occurs too early, before a component is fully positioned, rather than that the part itself is nonconforming.
Use reference features that are stable and functionally relevant for alignment. Alignment to an inconsistent printed mark, a reflective edge, or a deformable gasket can cause a correctly manufactured part to be evaluated in the wrong region. The inspection region of interest should follow the actual feature being judged, while still maintaining controls that detect gross part misplacement.
Match optics and image resolution to the tolerance
Software cannot recover detail that the optical system never resolved. If a defect criterion is close to, or smaller than, the pixel scale, small variations in focus, edge interpolation, and contrast can push good parts across the acceptance threshold. The result is an inspection that appears precise because it produces a number, but the number is not repeatable enough for the tolerance being enforced.
The practical question is not simply how many megapixels the camera has. It is how many pixels represent the smallest defect or dimensional change that must be judged, across the actual field of view. Lens distortion, depth of field, working distance, object height variation, and focus stability all affect the usable measurement.
For dimensional inspection, calibrate the image-to-object relationship using an appropriate artifact and verify performance across the inspection area, not only at its center. For presence/absence or surface appearance tasks, verify that focus and contrast remain adequate at the expected extremes of part height and position. A shallow depth of field may produce attractive images at nominal placement but unstable results when normal manufacturing variation occurs.
Do not use aggressive image sharpening, contrast enhancement, or noise filtering as a substitute for optical adequacy. Such processing can improve visual appearance while amplifying texture, suppressing weak defects, or creating inconsistent feature boundaries. Any preprocessing step should be tested against both confirmed-good parts and confirmed-defective parts.
Build a reference data set that includes normal variation
A vision model trained or configured from a handful of ideal samples will often treat routine manufacturing variation as abnormal. Good-part data must represent the approved production range: different material lots, finishes, print density, tooling conditions, orientations, and reasonable environmental conditions. It should also include borderline yet acceptable parts when the specification permits them.
For rule-based inspection, this data set supports threshold selection and exposes where a single global rule is inadequate. For AI-based classification or anomaly detection, it is fundamental. An anomaly model trained only on pristine samples may reject harmless differences in texture, color, or reflectance. A classifier trained with uncertain labels can learn the inconsistency of the disposition process rather than the true quality rule.
Data governance is especially important when “good” labels are created from an operator override. An override may mean the part met the requirement, but it may also mean production pressure influenced the decision. Confirmed labels should be tied to an approved disposition method, such as dimensional verification, functional testing, controlled visual review, or documented engineering judgment.
Keep distinct sets for development, validation, and ongoing monitoring. Reusing the same images to tune and to claim performance gives an overly optimistic result. The system should also be challenged with known defect samples where available, including defects near the reject boundary. False reject reduction is acceptable only if sensitivity to critical defects remains protected.
Use decision bands when the process allows them
A binary pass/fail threshold forces every borderline image into an immediate production decision. Where cycle time and control plans permit, a three-way result can be safer: pass, reject, and review. The review band should be narrow and based on uncertainty near the acceptance boundary, not used as a dumping ground for poor image quality.
Examples include a measurement close to tolerance, a feature partially obscured by a transient reflection, or a classifier score near its calibrated decision limit. Manual review should use a defined work instruction and, for critical characteristics, a second verification method where practical. If the review queue becomes large, that is evidence that the inspection capability or process variation needs correction—not a reason to normalize extensive manual sorting.
Threshold changes must be controlled changes. Record the reason, affected product variants, before-and-after samples, validation results, approval, and rollback path. Unrecorded “small adjustments” create a serious traceability gap, particularly when the same station supports multiple part numbers or critical inspections.
Distinguish algorithm error from process drift
A rising false reject rate can mean the vision system has drifted, but it can also be the earliest visible signal that the upstream process has changed. If a camera begins flagging more seal wrinkles, solder appearance variation, label skew, fill-level variation, or missing components, do not assume the inspection is too sensitive. Compare the images with process data, tooling status, material lots, maintenance activity, and operator interventions.
Trend reject reasons separately. A stable total reject rate can hide a meaningful shift if one defect category rises while another falls. Conversely, a sudden increase in generic “inspection failed” events may indicate communication faults, trigger timing errors, image acquisition failures, or poor part presentation rather than a quality change.
Monitor image-quality indicators alongside quality results: exposure level, focus metric, alignment score, background uniformity, camera temperature where relevant, and failed image acquisition count. These measures create an early warning layer. They help maintenance teams act before optical degradation turns into a flood of false rejects or, worse, reduced defect detection.
Validate changes against both sides of the risk
A reduction in false rejects should be validated as a trade-off study, not celebrated as an isolated improvement. The relevant question is: after the change, how does the station perform on verified good parts and on verified defects, especially defects that affect safety, function, traceability, or customer requirements?
Validation should reflect the real operating envelope: normal shift duration, expected part positioning range, production speed, material variation, and lighting condition. A short demonstration with hand-presented samples is not equivalent to production performance. When the system governs disposition automatically, the validation record should show that the revised method meets the approved control requirements for that feature.
The most durable way to reduce false rejects is to make the visual signal more stable, the acceptance rule more explicit, and the feedback loop more disciplined. A machine vision inspection factory performs reliably when a rejected image can be explained in physical and quality terms: what was observed, why it violated the requirement, and why normal variation was not mistaken for a defect. That standard protects throughput without turning inspection into a blind compromise on quality.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 18, 2026Comparing Material Options for Procurement: Specs, Costs, and Supply RisksExplore procurement oriented technical content on material options, specs, costs, and supply risks. Compare alternatives to cut hidden expenses and make confident sourcing decisions.Dr. Marcus Vance
 Oct 17, 20265-Axis CNC Positioning Accuracy: How to Interpret ISO 230-2 Test ResultsAssess 5 axis CNC machining positioning accuracy with ISO 230-2. Learn to interpret repeatability, reversal error, and test conditions to compare suppliers and make confident acceptance decisions.Dr. Marcus Vance
 Oct 16, 2026Choosing a Rugged Edge AI Box Supplier: Thermal Tests and Lifecycle SupportChoose a rugged edge AI box supplier with proven thermal performance and reliable lifecycle support. Discover the tests and commitments to verify before you buy.TSV Data Lab
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)
 Oct 18, 2026What Should an AS9100 Machining Supplier Checklist Include?Build an AS9100 machining supplier checklist that verifies capability, traceability, inspection, and outsourced processes. Discover what to check before approving your next aerospace supplier.Dr. Marcus Vance
 Oct 17, 2026How Should You Interpret Industrial Robot Repeatability Specs?Decode industrial robot repeatability specifications, understand ISO 9283 test conditions, and avoid costly selection mistakes. Learn how to verify performance for your process.Chen Wei (Automation Lead Engineer)
 Oct 16, 2026How Can You Fairly Compare MTBF Across Industrial Servo Motors?Make a fair industrial servo motor MTBF comparison with matched operating profiles, failure criteria, and confidence bounds. Discover how to assess reliability beyond advertised numbers.Chen Wei (Automation Lead Engineer)
 Oct 15, 2026How Should You Compare TechStat Vanguard 5-Axis CNC Tolerances?TechStat Vanguard 5-axis CNC tolerance comparison: learn how to verify part accuracy, assess inspection evidence, and choose suppliers that reliably meet your drawing requirements.Dr. Marcus Vance
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab