Solid-state LiDAR vs radar for mobile robots?
Publication Date
author
For AGV AMR teams evaluating perception stacks, the choice between solid-state LiDAR and radar is not about hype—it is about measurable performance in clutter, speed, and cost. This guide compares detection fidelity, interference tolerance, edge processing demands, and deployment fit for mobile robots, helping engineers, operators, buyers, and decision-makers choose the right sensor strategy with data-first clarity.
In mobile robotics, perception errors rarely stay isolated at the sensor level. A missed pallet edge, a false positive near reflective wrap, or poor target separation in a mixed human-machine aisle can affect navigation stability, throughput, and safety procedures within seconds. For procurement and engineering teams, the real question is not which sensor sounds more advanced, but which sensing architecture performs predictably under the site’s operating envelope.
TechStat Vanguard approaches this comparison from an engineering benchmark perspective. That means focusing on detection range bands, angular resolution, velocity estimation, environmental tolerance, compute load, and life-cycle cost rather than promotional language. In many deployments, the answer is not LiDAR or radar alone, but a deliberate sensor strategy matched to robot speed, aisle width, obstacle profile, and failure tolerance.
How Solid-State LiDAR and Radar Differ at the Physics Level
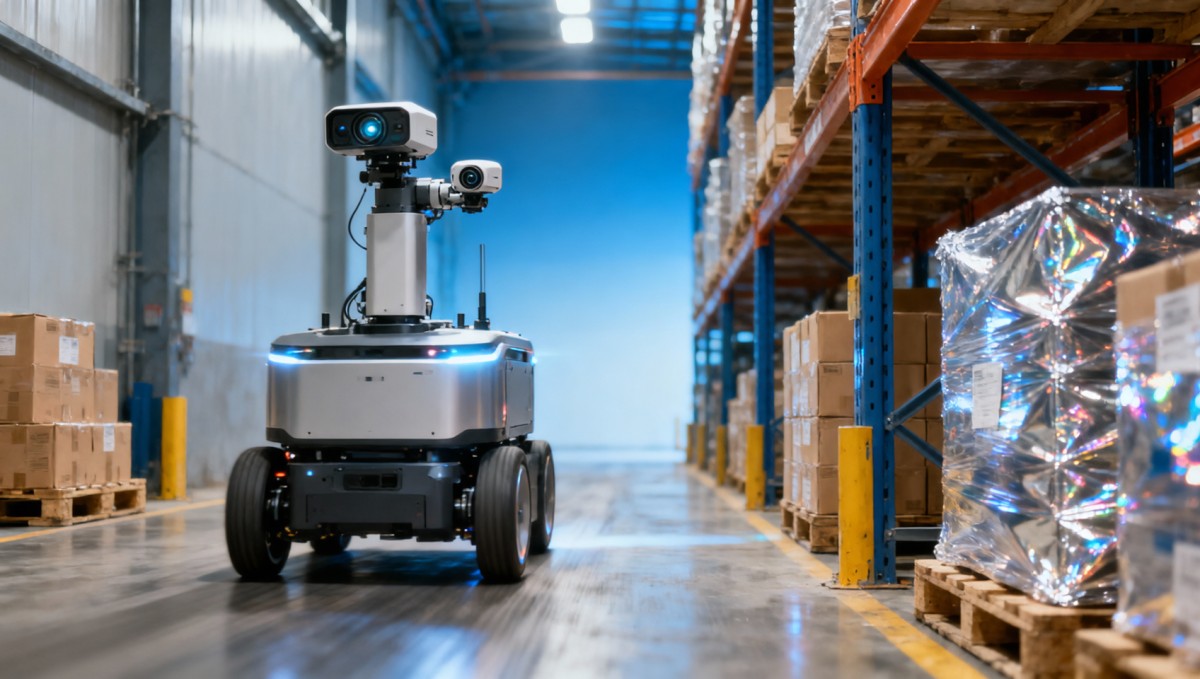
Solid-state LiDAR measures distance by emitting laser light and calculating time-of-flight or phase shift from reflected signals. Radar uses radio waves, usually in millimeter-wave bands such as 60 GHz, 77 GHz, or 79 GHz, to detect range, relative velocity, and target presence. For mobile robots, this difference matters because optical sensing and RF sensing fail in different ways and excel under different constraints.
In practical AGV and AMR operation, solid-state LiDAR usually provides finer spatial detail. It can often resolve pallet forks, rack uprights, low obstacles, or edge boundaries with greater geometric precision, especially at short-to-mid ranges such as 0.1 m to 30 m. Radar, by contrast, often delivers stronger robustness in dust, fog, rain, and certain low-visibility conditions, though with lower shape fidelity for object contouring.
This is why engineers should separate three metrics that are too often blended together: detection, classification, and localization. Radar may reliably detect that something is present and moving at 12 m ahead, but LiDAR may be better at telling the navigation stack whether that object is a narrow pole, a person-shaped cluster, or a pallet corner intruding 120 mm into the lane.
A second distinction is velocity handling. Radar directly measures Doppler shift, making relative speed estimation a native strength. LiDAR can infer motion across frames, but this usually depends more on scan rate, point cloud registration, and tracking algorithms. In robots moving at 1.5 m/s to 3.0 m/s in mixed environments, this difference can influence emergency stop distance and prediction quality around crossing forklifts or fast-moving carts.
Core sensing priorities for mobile robots
- Obstacle contour detail for path planning in narrow aisles, often below 2.5 m lane width.
- Reliable presence detection in dust, spray, smoke, or outdoor yard transitions.
- Velocity awareness for moving hazards, especially above 2 m/s closing speed.
- Stable output under vibration, temperature swings, and reflective industrial surfaces.
Why this matters to buyers and operators
A buyer may compare sensor price per unit, but operators live with the consequences of nuisance stops, blind zones, and cleaning intervals. A sensor that reduces false alarms by even 10% to 20% can materially improve fleet utilization in a 20-robot site. Likewise, a sensor that requires lens cleaning every 2 to 3 shifts instead of once per week may raise labor overhead and reduce confidence in unattended operation.
Performance Comparison in Warehouses, Factories, and Outdoor Transfer Routes
The table below compares the most decision-critical attributes for mobile robot perception. Values are expressed as typical engineering tendencies rather than vendor-specific guarantees, because exact performance depends on antenna design, optical architecture, mounting height, software filtering, and target material. Teams should treat these as selection cues for validation testing, not as universal specifications.
The key takeaway is not that one sensor dominates all tasks. LiDAR generally supports richer mapping and more precise local path planning, while radar offers stronger persistence under environmental interference. In facilities with both indoor aisles and outdoor transfer segments, the sensor stack should be validated against at least 4 conditions: clean ambient light, reflective packaging, airborne dust, and moving metallic traffic.
Typical deployment scenarios
In high-bay warehouses, robots often navigate close to shrink wrap, rack legs, and pallet overhang. Here, solid-state LiDAR has a clear advantage when precise obstacle boundary extraction is needed for lane-centering and docking. A resolution gap of a few centimeters can be operationally meaningful when dock alignment tolerance is within ±20 mm to ±50 mm.
In dusty factories, foundries, cement-adjacent production, or semi-outdoor yards, radar can become a stability anchor. Even if LiDAR remains the primary planner input, radar may improve hazard persistence when airborne particles or spray create intermittent optical noise. This can reduce sudden confidence collapse in the perception stack during shift changes or washdown periods.
For faster AMRs serving cross-dock or outdoor campus logistics, radar’s velocity sensitivity becomes more valuable. If the robot must predict moving forklifts entering from side lanes, radar can help detect relative motion earlier. That said, radar alone may struggle to classify irregular static clutter with the precision needed for low-clearance maneuvers.
A practical rule of thumb
- If your primary failure mode is missed geometry, start with LiDAR.
- If your primary failure mode is degraded visibility, add radar early.
- If your robots exceed 2 m/s or cross mixed traffic, evaluate radar-assisted motion tracking.
- If your site has both indoor precision and outdoor variability, plan for sensor fusion rather than single-sensor standardization.
Interference, False Positives, and Edge Processing Demands
One of the most underestimated procurement risks is assuming that published range or field-of-view values predict real-world reliability. In practice, mobile robot teams lose time not on maximum range, but on corner cases: reflective floors, glass partitions, black rubber loads, hanging film, multi-path reflections, and simultaneous operation of many robots in the same RF or optical environment.
Solid-state LiDAR can be sensitive to contamination on the optical window, strong sunlight in some mounting geometries, and difficult materials that absorb or scatter light. Radar can be affected by multi-path behavior, metallic clutter, and ghost targets if signal processing is not well tuned. For buyers, this means acceptance testing should include nuisance-object scenarios, not only clean-lane demonstrations.
Compute load is another dividing line. Dense LiDAR point clouds may require higher bandwidth, stronger edge processors, and tighter synchronization with localization and planning modules. Radar can reduce raw data volume in some designs, but extracting usable semantic information may still require advanced filtering, object tracking, and sensor fusion logic. Lower data rate does not automatically mean easier system integration.
For many fleets, the real cost sits downstream in software validation. A team may save on hardware upfront but spend 8 to 16 extra weeks tuning false alarms, path planner thresholds, or dynamic obstacle behavior. This is especially common when a single sensor is pushed to handle mapping, safety support, and motion prediction without a layered architecture.
Common interference checks before purchase approval
- Test on black, reflective, transparent, and mesh-like materials at 1 m, 5 m, and 10 m.
- Run at least 3 lighting states: normal indoor light, direct glare exposure, and low-light transitions.
- Measure false positive rate in mixed traffic for a full shift, not just a 10-minute demo.
- Check performance after lens or radome contamination typical of 24 to 72 hours of operation.
Integration questions CTOs should ask
Ask vendors how many processing stages sit between raw sensor output and navigation-grade objects. Clarify whether the robot controller receives points, clusters, tracked objects, or occupancy maps. Also verify latency budget across the full chain. In mobile robots, a perception-to-actuation delay of 80 ms versus 180 ms can materially change stop margin at speeds above 2.5 m/s.
Selection Framework by Use Case, Budget, and Risk Tolerance
The right sensor strategy depends less on headline technology and more on the operating mission. A low-speed tugger AMR in a clean electronics plant has different needs from a pallet-moving AGV in a food processing facility with condensation and washdown cycles. Selection should therefore map to speed class, obstacle complexity, environment severity, and acceptable downtime.
The table below gives a decision-oriented framework that procurement teams can use during specification drafting. It is designed to support cross-functional review among engineering, operations, and sourcing teams, especially when standardizing a fleet across more than one site.
For most enterprise buyers, the strongest long-term position is to write performance-based specifications rather than technology-only requirements. Instead of requesting “radar-equipped AMRs” or “LiDAR-only AGVs,” specify detection thresholds, update rates, contamination tolerance, and stop-performance behavior under defined site conditions. This reduces vendor ambiguity during RFQ comparison.
Four procurement dimensions to score
First, score sensing performance by scenario, not by brochure metrics. Include static low obstacles, moving metal vehicles, transparent barriers, and wrapped pallets. Second, score integration burden: middleware support, API maturity, time synchronization, and diagnostics visibility. Third, score maintainability, including cleaning interval, recalibration needs, and spare part availability within 2 to 6 weeks.
Fourth, score total cost of ownership over 24 to 36 months. That should include compute upgrades, validation labor, unplanned service visits, and lost productivity from nuisance stops. In many deployments, software and operations costs exceed the initial sensor price difference, especially once fleet size reaches 15 to 50 units.
Typical implementation workflow
- Define 5 to 8 site-critical scenarios and pass-fail thresholds.
- Shortlist 2 to 3 candidate sensor stacks, not single devices only.
- Run pilot testing for at least 2 weeks across day and night shifts.
- Compare intervention rate, false alarm rate, and compute utilization.
- Lock specification only after maintenance and operator feedback are included.
FAQ for Engineers, Buyers, and Fleet Decision-Makers
Is solid-state LiDAR more accurate than radar for mobile robots?
For geometric detail, usually yes. Solid-state LiDAR is commonly better at mapping obstacle boundaries, rack edges, and pallet geometry at short and medium range. But accuracy should be separated into spatial accuracy, velocity accuracy, and reliability under interference. Radar may be less detailed spatially yet more dependable in fog, dust, or spray, which can make it operationally more useful in harsh conditions.
Can radar replace LiDAR in AGV or AMR navigation?
In some simple environments, partial replacement is possible, but full replacement is uncommon where tight navigation precision is required. If docking tolerance is within a few centimeters or the robot navigates around irregular clutter, LiDAR usually remains the stronger primary sensor. Radar is more often used as a complementary layer for robustness and motion awareness.
When does sensor fusion become worth the extra cost?
Sensor fusion becomes easier to justify when the site combines at least 2 of the following: narrow aisles, mixed human-forklift traffic, outdoor transitions, frequent airborne contamination, or robot speeds above 2 m/s. In these cases, the cost of a single avoidable collision, repeated emergency stops, or delayed deployment often outweighs the added hardware and software expense.
What should procurement teams request in a vendor trial?
Request a structured test matrix, not a generic demo. Include at least 6 metrics: detection of low obstacles, performance near reflective wrap, moving target handling, contamination tolerance, perception latency, and operator intervention frequency. Require data logs over multiple shifts and ask whether the reported output is raw, filtered, or fused. This prevents favorable one-off demonstrations from masking integration risk.
What a Data-First Decision Looks Like
For most mobile robot programs, the most effective comparison is not solid-state LiDAR versus radar in the abstract. It is LiDAR-only, radar-only, and fused architectures tested against the actual failure modes of your facility. The decision should be tied to speed envelope, object diversity, environment severity, and acceptable recovery time when perception confidence drops.
If your operation depends on precise contouring in structured indoor spaces, solid-state LiDAR is often the foundation. If your environment includes visibility degradation, moving industrial traffic, or semi-outdoor exposure, radar can add meaningful resilience. If the business impact of downtime is high, a layered perception stack often delivers the best operational margin.
TechStat Vanguard supports engineering-led sourcing by translating sensor claims into measurable evaluation criteria. If you are drafting an RFQ, benchmarking AMR perception stacks, or standardizing sensor requirements across multiple sites, a parameter-first review will reduce trial-and-error cost and shorten supplier qualification cycles.
To move from comparison to specification, map your top 5 operating risks, define pass-fail thresholds, and validate under live conditions. For tailored guidance on mobile robot sensor selection, integration priorities, or procurement criteria, contact us to discuss a custom evaluation framework or explore more hard-tech decision support solutions.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 18, 2026Comparing Material Options for Procurement: Specs, Costs, and Supply RisksExplore procurement oriented technical content on material options, specs, costs, and supply risks. Compare alternatives to cut hidden expenses and make confident sourcing decisions.Dr. Marcus Vance
 Oct 17, 20265-Axis CNC Positioning Accuracy: How to Interpret ISO 230-2 Test ResultsAssess 5 axis CNC machining positioning accuracy with ISO 230-2. Learn to interpret repeatability, reversal error, and test conditions to compare suppliers and make confident acceptance decisions.Dr. Marcus Vance
 Oct 16, 2026Choosing a Rugged Edge AI Box Supplier: Thermal Tests and Lifecycle SupportChoose a rugged edge AI box supplier with proven thermal performance and reliable lifecycle support. Discover the tests and commitments to verify before you buy.TSV Data Lab
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)
 Oct 17, 2026How Should You Interpret Industrial Robot Repeatability Specs?Decode industrial robot repeatability specifications, understand ISO 9283 test conditions, and avoid costly selection mistakes. Learn how to verify performance for your process.Chen Wei (Automation Lead Engineer)
 Oct 16, 2026How Can You Fairly Compare MTBF Across Industrial Servo Motors?Make a fair industrial servo motor MTBF comparison with matched operating profiles, failure criteria, and confidence bounds. Discover how to assess reliability beyond advertised numbers.Chen Wei (Automation Lead Engineer)
 Oct 15, 2026How Should You Compare TechStat Vanguard 5-Axis CNC Tolerances?TechStat Vanguard 5-axis CNC tolerance comparison: learn how to verify part accuracy, assess inspection evidence, and choose suppliers that reliably meet your drawing requirements.Dr. Marcus Vance
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)