What does an EtherCAT cycle time benchmark really prove?
Publication Date
author
An ethercat cycle time benchmark can reveal far more than a headline speed figure—but only if the test conditions, topology, jitter behavior, and payload realism are fully disclosed. In industrial automation, motion control, machine vision, robotics, and edge-connected equipment, the real value of an ethercat cycle time benchmark is not raw speed alone. It is proof of deterministic timing under repeatable, engineering-grade conditions.
That distinction matters across the broader industrial landscape. A published benchmark may look impressive, yet still say little about usable control performance. If sync drift, frame loss, CPU loading, cable length, distributed clocks, and actual I/O payload are hidden, the benchmark becomes a marketing number rather than an engineering reference.
Why an EtherCAT Cycle Time Benchmark Needs a Checklist
An ethercat cycle time benchmark is often treated as a simple race: the shorter the cycle, the better the network. That interpretation is incomplete. EtherCAT performance depends on controller architecture, slave count, update model, packet content, synchronization quality, and software stack efficiency.
A checklist prevents false conclusions. It forces technical evaluation toward measured determinism, bounded jitter, and system stability. It also makes benchmark comparisons fair across vendors, devices, and test labs.
Core Checklist: What an EtherCAT Cycle Time Benchmark Should Prove
Use the following points to judge whether an ethercat cycle time benchmark has engineering value or only headline appeal.
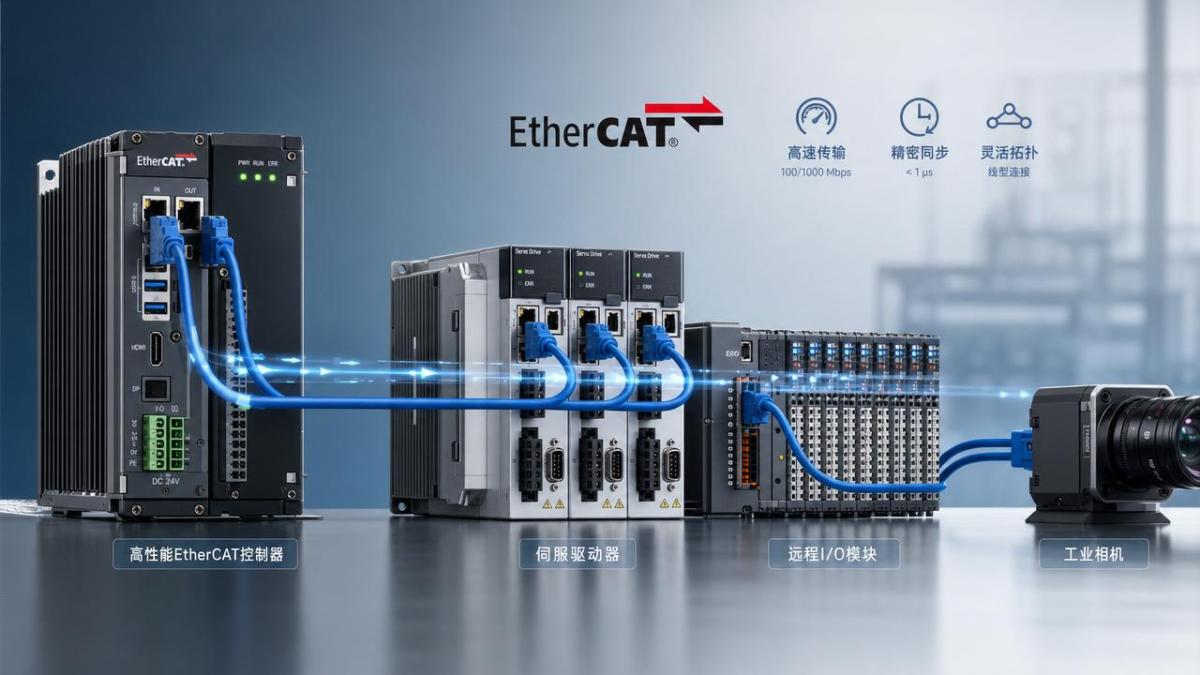
- Define the topology clearly, including line, ring, branch segments, slave count, cable length, and whether remote I/O, servo drives, and gateways were active during the test.
- State the payload size per cycle, not just the loop interval, because a light telegram at 125 microseconds proves less than a full data image at the same rate.
- Measure jitter distribution, not only average cycle time, since deterministic control depends on worst-case timing behavior and not on a favorable mean value.
- Report controller load, core allocation, operating system, and task priority, because benchmark results can collapse when CPU contention or non-real-time scheduling appears.
- Verify distributed clock synchronization accuracy, because an ethercat cycle time benchmark without clock alignment data cannot prove coordinated multi-axis motion quality.
- Include error behavior under stress, such as frame retries, lost packets, late frames, and recovery times, because stable operation matters more than isolated best-case bursts.
- Compare cold-start and sustained-run performance, since thermal changes, memory pressure, and background diagnostics can affect long-duration deterministic timing.
- Separate network capability from application latency, because a fast bus does not guarantee fast PLC logic, interpolation, sensor processing, or actuator response.
- Document instrumentation methods, time sources, and sample windows, because benchmark credibility depends on traceable measurement rather than software screenshots alone.
- Test with realistic mixed devices, because an ethercat cycle time benchmark using homogeneous nodes may not represent machine tools, packaging lines, or robotic cells.
What the Benchmark Can Actually Prove
Deterministic transport quality
A strong ethercat cycle time benchmark can prove that cyclic data transport remains predictable at a defined load. This is useful when evaluating synchronized drives, fast discrete I/O, or closed-loop control layers that depend on bounded timing.
It can also prove whether the network architecture scales. If jitter remains tight as more slaves are added, the benchmark supports claims of deployment readiness in larger systems.
Controller and stack efficiency
An ethercat cycle time benchmark may also reveal how efficiently the master stack, NIC path, and real-time scheduler are implemented. Strong results under heavy payloads suggest careful software design, interrupt handling, and memory discipline.
That matters beyond automation. Any edge-connected industrial platform using high-rate sensing, vision triggers, or precision actuator timing benefits from efficient deterministic communications.
Usable synchronization for motion systems
If distributed clocks are measured properly, the benchmark can prove synchronization fitness for multi-axis motion. That is far more meaningful than a bare microsecond figure without phase alignment evidence.
What the Benchmark Does Not Automatically Prove
Even a good ethercat cycle time benchmark has limits. It does not automatically prove application-level productivity, machine throughput, servo tuning quality, or end-product precision.
For example, a packaging line may run well at a modest network cycle if mechanics are stable and logic is optimized. A UAV test rig or semiconductor motion stage may require tighter synchronization, but still fail if sensors, algorithms, or actuators add delay elsewhere.
It also does not prove cybersecurity robustness, maintainability, or interoperability under every vendor combination. Those require separate validation.
Scenario Notes Across Industrial Applications
Robotics and coordinated motion
In robotics, an ethercat cycle time benchmark is valuable when it shows stable timing with multiple servo drives, feedback devices, and safety-related messaging present. Tight jitter windows matter more than record-low single-cycle claims.
The practical question is whether path accuracy and axis coordination remain consistent during acceleration, deceleration, and concurrent sensor traffic.
Machine vision and inspection
For vision-linked systems, the benchmark should be read alongside trigger timing, camera interface latency, and edge compute load. A fast EtherCAT loop helps only when image acquisition and processing stay equally deterministic.
Process equipment and distributed I/O
In broader industrial equipment, including test stands, packaging systems, and specialty machinery, the ethercat cycle time benchmark is often more about stability over long runs than minimum cycle bragging rights.
A slightly slower but repeatable network can outperform an unstable faster configuration once uptime, troubleshooting effort, and parameter drift are considered.
Commonly Missed Risks in EtherCAT Cycle Time Benchmark Claims
Ignore unloaded tests at your own risk. A benchmark with trivial payload may hide the real limits of application traffic and cyclic diagnostics.
Watch for short sample windows. A ten-second run may miss sporadic timing spikes that appear only after thermal equilibrium or background service activity.
Question single-number reporting. Minimum cycle time without 99.9th percentile jitter, max deviation, or fault counts is not enough for engineering decisions.
Check whether the benchmark used production-like devices. Lab-friendly slaves may not reflect mixed-vendor behavior in actual machine networks.
Do not confuse bus timing with total control latency. Sensor conversion, PLC scan, interpolation, and actuator response can dominate overall performance.
Practical Execution Advice
- Build a benchmark matrix that varies slave count, payload size, cycle target, and controller load rather than publishing one best-case result.
- Capture jitter histograms, fault events, and synchronization drift over extended runs, ideally under thermal and application stress.
- Correlate the ethercat cycle time benchmark with machine-level outcomes such as axis following error, trigger accuracy, or rejected-part rate.
- Use traceable measurement tools and disclose test scripts, software versions, and topology diagrams for repeatability.
Conclusion and Next Action
A credible ethercat cycle time benchmark proves deterministic communication performance under stated conditions. It can validate timing discipline, synchronization quality, and scaling behavior. It cannot, by itself, prove superior machine productivity or universal system fitness.
The next step is simple: request the full benchmark context. Ask for topology, payload, jitter, distributed clock data, sustained-run results, and application correlation. When those details are visible, an ethercat cycle time benchmark becomes a useful engineering instrument rather than a headline claim.
That approach aligns with data-first technical evaluation: parameters over slogans, evidence over promotion, and deployable truth over impressive but isolated numbers.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 10, 2026When does the cost of industrial robots pay back in high-volume production?Cost of industrial robots: discover how high-volume manufacturers calculate payback through uptime, cycle time, labor, quality, and integration before investing.Chen Wei (Automation Lead Engineer)
 Oct 09, 2026What does a manufacturing robot really cost beyond the purchase price?Manufacturing robot cost goes far beyond the purchase price. Explore integration, tooling, safety, uptime, and total ownership factors for smarter automation investments.Chen Wei (Automation Lead Engineer)
 Oct 08, 2026AGV vs. AMR: Which Is Better for Frequently Changing Routes?Which is better for changing routes? Compare AGVs and AMRs for flexible navigation, docking precision, traffic control, and faster facility reconfiguration.Chen Wei (Automation Lead Engineer)
 Oct 07, 2026How Much Does an Automated Guided Vehicle Cost in 2026?How much does an automated guided vehicle cost in 2026? Explore AGV price ranges, hidden deployment costs, and smart buying factors for stronger ROI.Chen Wei (Automation Lead Engineer)
 Oct 06, 2026Are Collaborative Robots Safe Enough to Operate Without Fencing?Are collaborative robots safe enough to work without fencing? Explore risk assessment, safeguarding options, and practical guidance for safer, productive cobot cells.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026What Causes Machine Vision Systems to Miss Small Defects?What causes machine vision systems to miss small defects? Discover how lighting, optics, motion, and AI thresholds affect detection—and prevent costly escapes.TSV Data Lab