
What Makes a Good Cobot Palletizing Layout in Tight Spaces?
Publication Date
author
In tight facilities, a strong cobot palletizing layout is not just about fitting equipment into less floor space—it is about protecting throughput, safety, and ROI. This guide explains how cobot palletizing layout decisions connect with smart factory automation solutions, from AGV traffic flow and operator access to servo drive response time, helping engineers, buyers, and plant leaders build compact systems that perform reliably under real production constraints.
Why layout matters more than robot reach in tight palletizing cells
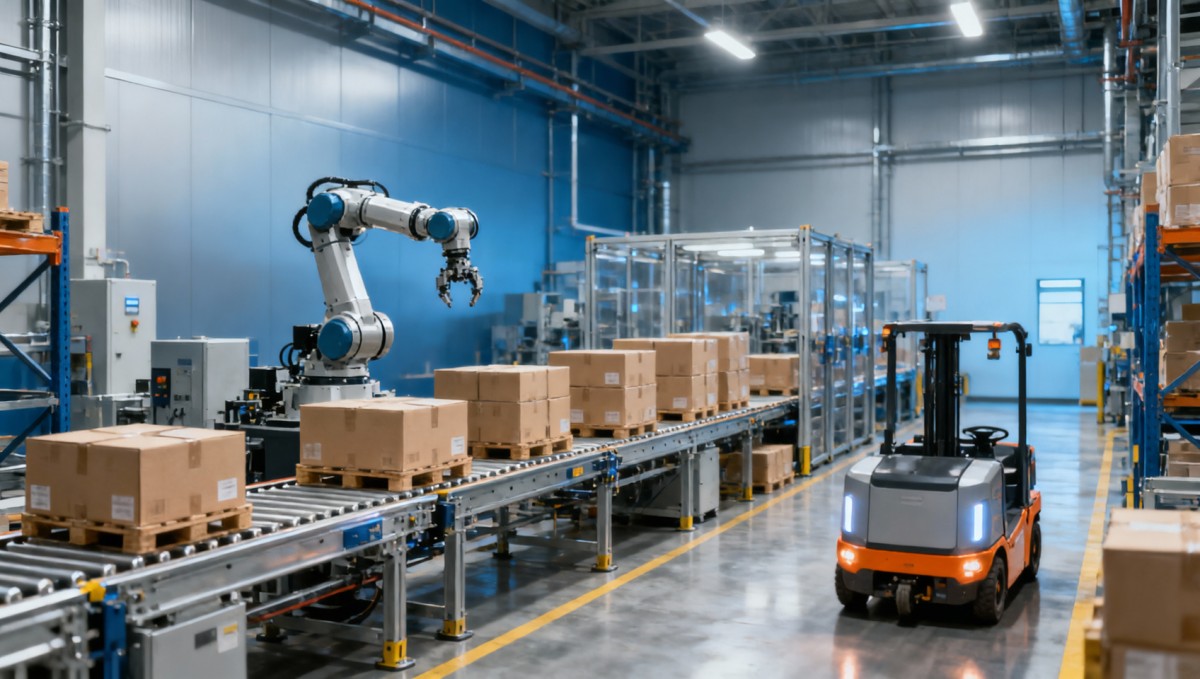
A good cobot palletizing layout in tight spaces is a system design question, not only a robot selection question. Many facilities begin with arm reach, payload, and stack height, then discover the cell cannot support safe replenishment, operator movement, or forklift clearance. In compact production areas, layout quality determines whether the cobot palletizing system can maintain cycle stability across 2–3 shifts, handle upstream interruptions, and avoid repeated micro-stoppages.
For information researchers and procurement teams, the practical issue is simple: a cobot palletizer that fits on paper may still fail on the floor. A tight-space layout must balance at least 5 variables at the same time—robot footprint, infeed orientation, pallet position, human access, and material transport. If one of these variables is ignored, the result is often reduced pallet quality, unsafe intervention, or unusable spare floor area.
Operators usually notice the problem first. They need enough clearance to load consumables, reset alarms, and inspect cartons without stepping into awkward positions. In many compact lines, a difference of 600–900 mm in access aisle planning can decide whether routine work takes seconds or causes repeated delays. That is why a strong cobot palletizing layout should be reviewed as an operational workflow, not just as an equipment drawing.
At TSV, we approach compact automation with a parameter-first mindset. Instead of vague claims about “space-saving efficiency,” decision-makers should ask exact questions: What is the true operating envelope? How much buffer is needed for carton accumulation? What is the AGV turning requirement? What reset zones remain accessible during live production? In hard-tech environments, parameters do not lie, and layout tolerances directly affect uptime.
- A compact palletizing cell usually performs better when robot motion, pallet exchange, and infeed transfer are mapped as one process rather than three separate purchases.
- Aisle and service access should be reviewed for normal operation, cleaning, preventive maintenance, and emergency stop access.
- The best layout in a tight space is rarely the smallest footprint; it is the smallest footprint that still preserves safe movement and stable throughput.
What defines a good cobot palletizing layout in limited floor space?
A good cobot palletizing layout in limited floor space should allow predictable flow from product infeed to full-pallet discharge without forcing unnecessary turns, manual crossings, or dead zones. In most compact cells, layout performance is shaped by 4 core conditions: product presentation, pallet access, safety zoning, and replenishment logic. When these are aligned, the cell remains easier to operate even during SKU changes or uneven upstream supply.
For example, a single-line infeed with side pallet discharge may save area, but it can also create congestion if AGV or pallet jack traffic intersects operator inspection paths. By contrast, an L-shaped or diagonal presentation sometimes uses similar floor space while improving visibility and reducing handoff conflicts. This is why plant leaders should evaluate not just square meters, but how each square meter behaves during live production over 8–12 hour shifts.
Servo response and gripper stability also matter in tight layouts. When a cobot must work close to guarding, posts, or conveyor edges, motion smoothness becomes more important than simple nominal speed. Poorly tuned acceleration profiles can introduce carton sway, placement inconsistency, or longer settling time. In compact palletizing, stable trajectory and repeatable placement often bring more value than chasing peak speed specifications.
The following table summarizes common layout evaluation dimensions used by engineers and buyers during a compact cell review. These are not fixed universal values, but they provide a realistic decision framework for comparing proposals.
The key takeaway is that a good cobot palletizing layout is measured by interaction quality. If operators can work cleanly, pallets can change without production blockage, and the robot can place consistently inside a constrained envelope, the layout is doing its job. If the cell looks compact but requires repeated workarounds, the design is too tight in the wrong places.
Four signs the layout is structurally sound
First, the infeed path is direct and does not require product reorientation unless the SKU mix truly demands it. Second, operators can access common service points within 1–2 steps instead of walking around the entire cell. Third, pallet removal and replenishment can happen with limited disruption. Fourth, the cobot path avoids excessive deceleration caused by nearby obstructions.
What experienced buyers usually ask
Procurement teams often make better decisions when they request a flow-based review instead of a single machine quote. Ask suppliers to explain the exact pallet exchange sequence, expected cycle window, access zones, and how the layout behaves during sensor faults, carton skew, or temporary conveyor stoppage. These questions reveal whether the proposal is engineered for production or only for presentation.
Which layout patterns work best for AGV, manual handling, and mixed traffic?
Traffic integration is one of the most underestimated parts of a compact cobot palletizing layout. A cell that looks efficient in isolation may fail when AGVs, pallet jacks, and people share the same corridor. In mixed-traffic environments, layout planning should begin with path conflict reduction. The best palletizing arrangement is often the one that removes crossings rather than the one that minimizes equipment spacing by a few hundred millimeters.
When AGVs are used, entry and exit geometry matters as much as robot placement. AGV systems usually need reliable docking logic, predictable stop positions, and enough turning room to avoid repeated correction maneuvers. In narrow production aisles, even a small alignment error can slow the pallet exchange cycle. Facilities that run high mix or frequent pallet turnover should map AGV movement in 3 stages: approach, load transfer, and departure.
Manual handling environments follow different rules. A pallet jack operator needs visibility, handle swing space, and a clear exit line. If the pallet zone is too deep inside the cell, every exchange becomes slower and less safe. That is why many compact operations prefer edge-access pallet positions, even if this requires a slightly more complex robot motion path. The layout should reduce human strain before it tries to reduce every robot degree of travel.
The comparison below helps teams evaluate layout patterns based on traffic mode, operator behavior, and future automation expansion.
For buyers, the most important point is that layout should match traffic discipline. If the plant is moving toward AGV/AMR integration within 12–24 months, the palletizing cell should be designed with future docking and communication zones in mind. Retrofitting a compact cell later is usually more expensive than preserving a small amount of strategic space during the first installation.
A practical traffic review checklist
- Map every movement path: operator walk path, pallet input, full pallet removal, maintenance access, and emergency stop access.
- Check whether any two paths intersect during normal operation, not only during startup or shutdown.
- Review the worst case, such as blocked pallet removal, sensor fault reset, or upstream carton accumulation.
- Assess whether the same layout can support future AGV introduction without moving guarding, conveyor supports, or control cabinets.
What technical parameters should buyers and engineers verify before approval?
When evaluating a cobot palletizing layout, technical verification should go beyond payload and reach. Compact cells are more sensitive to placement repeatability, gripper behavior, line speed variation, and control response. Engineers should review at least 6 categories before approval: product dimensions, load stability, pallet pattern logic, cycle expectation, safety interface, and maintenance access. These parameters shape whether the layout remains robust under real factory conditions.
For carton or bag palletizing, product size variation has a direct effect on path planning. A system handling narrow dimensional tolerance behaves differently from one processing mixed packages with uneven rigidity. If the line is expected to palletize small and large SKUs in one cell, the layout should allow enough buffer and gripper clearance to avoid repeated recipe adjustments. Tight layouts punish poor SKU planning faster than larger cells do.
Control architecture also affects compact palletizing performance. Servo drives, vision support, and conveyor synchronization do not need to be over-specified, but they do need to be matched. In a constrained cell, delayed handoff signals or slow deceleration tuning may create more instability than raw mechanical limitations. This is especially true where products arrive irregularly or when the line uses sensor-based orientation correction before pick-up.
The following table provides a practical approval framework for technical and procurement teams reviewing a compact cobot palletizing proposal.
A strong proposal should answer these points with drawings, sequence logic, and realistic operating assumptions. If the supplier can only provide nominal robot specifications but cannot explain pallet exchange timing, product accumulation logic, or access behavior, the layout review is incomplete. TSV’s engineering view is clear: procurement quality improves when purchasing documents include measurable layout criteria instead of only equipment names.
Standards and compliance points worth checking
Exact local requirements depend on country, machine architecture, and risk assessment, but buyers should still verify whether the design aligns with common machinery safety practice, documented risk assessment, electrical integration discipline, and operator access logic. In regulated or export-oriented facilities, asking for the intended compliance path early can shorten approval time by several days or even a few weeks during final acceptance.
Common approval questions
Ask whether the supplier has defined the handover boundaries for controls, how recipe changes are managed, what alarms require manual entry, and which maintenance tasks must be done weekly, monthly, or quarterly. These questions protect both users and decision-makers from hidden operating costs that do not appear in a basic quotation.
How should procurement teams compare layout options, costs, and implementation risk?
Procurement teams often receive multiple offers that seem similar because all claim compact design, collaborative safety, and flexible palletizing. The real difference usually appears in implementation detail. A useful comparison should separate capital cost from layout risk, throughput resilience, and future expansion potential. In many plants, the lowest purchase price becomes the highest ownership burden when the compact cell later needs guard relocation, conveyor changes, or additional pallet handling hardware.
A practical procurement method is to compare options across 3 layers. First, compare equipment scope: cobot, gripper, conveyor, pallet handling, controls, and safety components. Second, compare site adaptation: footprint fit, utility needs, floor anchoring, and integration with existing line logic. Third, compare operating realism: recipe count, average intervention frequency, pallet exchange mode, and operator training demand. This layered review is far more reliable than comparing only one total price line.
Typical implementation timelines for compact palletizing cells vary with complexity, but many projects move through 4 stages: requirement clarification, layout and interface confirmation, manufacturing and FAT, then on-site installation and SAT. If standard modules are used, the process may move faster. If the project requires custom infeed handling, mixed pallet patterns, or AGV interface preparation, planning and validation usually take longer. Tight spaces add verification work because clashes are less forgiving.
Buyers should also price the cost of operational friction. A layout that saves a small amount upfront but causes repeated manual intervention every shift can create hidden labor and downtime costs across 12 months. In compact automation, design errors are expensive because physical correction often means moving multiple linked components rather than adjusting one isolated machine.
A procurement checklist for compact cobot palletizing projects
- Request a dimensioned layout drawing that includes access paths, service points, guarding lines, and pallet transfer zones.
- Ask for the assumed throughput window, such as average and peak production conditions, not only a single nominal cycle figure.
- Confirm whether the proposal includes operator training, recipe setup support, and documentation for troubleshooting and preventive maintenance.
- Check if expansion paths are preserved for future vision modules, extra pallet positions, or AGV/AMR handoff.
- Clarify which site works are excluded, such as electrical drops, compressed air preparation, floor reinforcement, or conveyor modification.
For enterprise decision-makers, this comparison method helps reduce trial-and-error cost and supplier qualification time. That aligns with TSV’s broader mission in robotics and automation: remove marketing noise, focus on verifiable parameters, and make hard-tech sourcing decisions easier to defend internally.
FAQ: what do teams still get wrong about compact cobot palletizing layouts?
Is the smallest footprint always the best cobot palletizing layout?
No. The best layout is the one that protects flow, access, and safety inside the available space. A very small footprint may increase congestion, reduce maintenance access, and force more production stops. In many projects, adding a modest service zone or pallet exchange buffer improves overall output more than shrinking the cell by another few hundred millimeters.
Can one compact cobot palletizer handle multiple SKUs efficiently?
Often yes, but only if the layout and gripper strategy are designed for SKU variation. Teams should verify size range, product rigidity, pattern rules, and recipe switching logic. If the line handles highly variable products, the layout should include enough infeed control and access for adjustment. Otherwise, flexibility exists in theory but not in daily use.
What should operators pay attention to during early use?
Operators should focus on 4 early indicators: how easy it is to clear minor faults, whether pallet exchange causes waiting time, whether products arrive consistently at pick position, and whether alarm resets require awkward access. These signals reveal layout weaknesses faster than long-term statistics and help plants correct issues during the first weeks of operation.
How long does layout validation usually take before purchase approval?
For straightforward projects, initial layout and interface review may be completed within several days. More complex compact palletizing cells with custom conveyors, mixed traffic, or automation handshakes can take 2–4 weeks to review properly because drawings, risk assessment inputs, and line interface details need more coordination. Rushed approval often creates costlier corrections later.
Why work with a data-driven technical review partner before finalizing the layout?
For many teams, the hardest part of buying a cobot palletizing layout is not finding suppliers. It is separating polished claims from engineering reality. That is where a data-driven review perspective becomes valuable. TSV focuses on robotics and automation with the belief that tolerances, repeatability, and process logic matter more than broad adjectives. In compact palletizing, that mindset helps buyers avoid expensive layout mistakes hidden behind generic sales language.
If your facility is comparing tight-space palletizing options, the most useful discussion is usually not “Which robot is best?” but “Which layout can sustain our real product mix, traffic pattern, and uptime target?” We can help structure that review around measurable factors such as access logic, conveyor buffering, pallet exchange sequence, AGV compatibility, and technical documentation completeness.
Contact us when you need support with parameter confirmation, compact cobot palletizing layout comparison, supplier proposal review, expected delivery window discussion, or custom automation scenario planning. We can also help frame the right questions for certification path review, interface clarification, sample handling assumptions, and quotation evaluation so your internal engineering and procurement teams can make faster, more defensible decisions.
A tight space does not need to force a weak palletizing result. With the right layout logic, realistic technical checks, and disciplined supplier evaluation, a compact cobot palletizing cell can deliver stable output, safer operation, and clearer ROI. That is the standard TSV stands for: engineering truth through data.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026How tight can micro machining aerospace tolerances be in production?Micro machining aerospace tolerances can reach low-micron levels in production. Learn what controls repeatability, inspection confidence, and flight-critical quality.Dr. Marcus Vance























