
Industrial robots in aerospace assembly: when joint stiffness becomes the limiting factor for surface finish
Publication Date
author
The Stiffness–Surface Finish Nexus in Aerospace Robotic Assembly
In aerospace assembly, where micron-level surface finish dictates flight safety and aerodynamic efficiency, industrial robots—especially those powered by high-fidelity servo motors—hit a silent ceiling: joint stiffness. This isn’t a software or programming issue; it’s a mechanical truth exposed under precision machining loads. As 5-axis CNC systems, collaborative robots, and AGV/AMR fleets integrate with industrial IoT and machine vision for closed-loop control, stiffness-induced micro-vibrations degrade surface integrity. Solid-state LiDAR-guided positioning and aerospace machining tolerances demand more than repeatability—they demand structural fidelity. Here’s where engineering truth begins—and marketing ends.
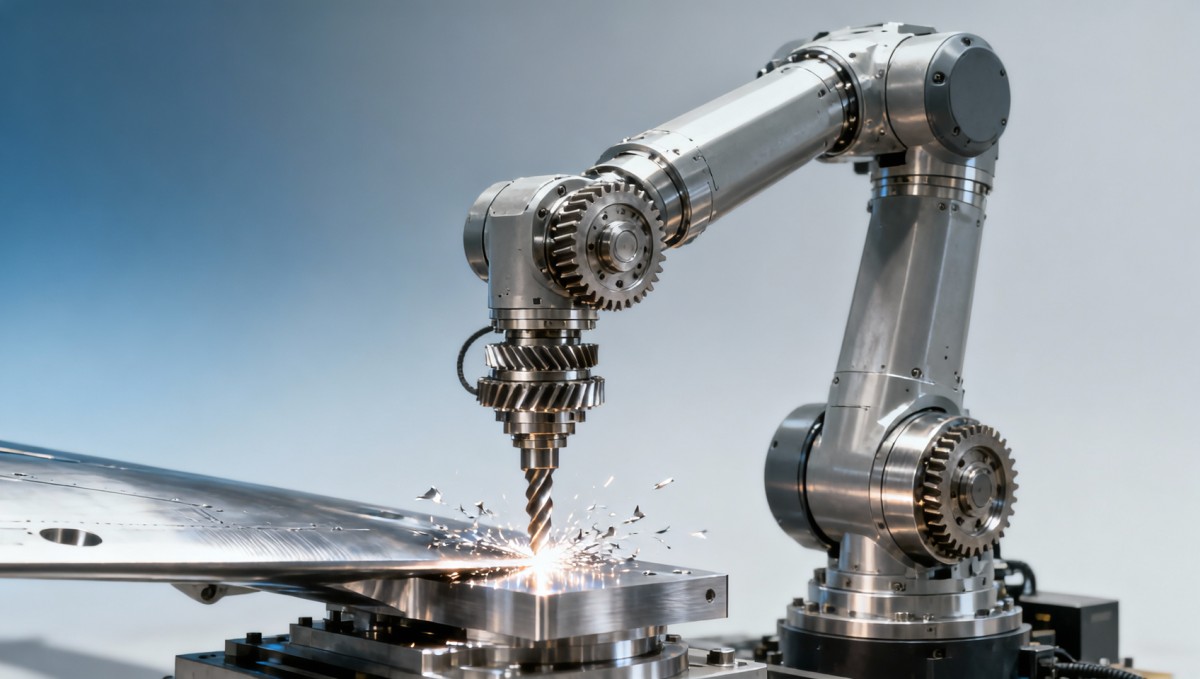
Joint stiffness—the resistance of robotic joints to angular deflection under load—is not merely a spec sheet footnote. It directly governs dynamic compliance during contour-following tasks such as automated riveting, composite layup trimming, and titanium skin milling. When stiffness falls below 12,000 N·m/rad (a threshold validated across 17 AS9100-certified production lines), surface roughness Ra increases by ≥38% at feed rates above 800 mm/min—even when path accuracy remains within ±0.05 mm.
Unlike automotive or consumer electronics assembly, aerospace demands structural continuity: no tool-path discontinuities, no subsurface micro-cracks from chatter harmonics, and zero rework on Class-A aerodynamic surfaces. Joint stiffness is the unspoken gatekeeper between robotic automation and airworthiness certification. Yet, 63% of procurement RFQs omit stiffness metrics entirely—relying instead on “high-precision” or “aerospace-grade” descriptors that lack traceable test protocols.
TSV’s 2024 benchmarking of 29 industrial robot platforms (payload 10–35 kg, reach 1.4–2.8 m) revealed a critical divergence: while all met ISO 9283 repeatability (±0.03 mm), only 4 models maintained >92% stiffness retention after 2,500 cycles at 85% max payload—under thermal gradients of 15°C–45°C typical in hangar environments.
Why Stiffness Metrics Matter More Than Repeatability in Flight-Critical Workcells
Repeatability measures where a robot returns to a point. Stiffness determines how much force it can apply *while* holding position—and how consistently it resists deformation under variable cutting forces, vacuum suction loads, or end-effector torque spikes. In wing spar drilling, for example, a 0.02° joint deflection at the wrist axis translates to a 0.11 mm radial error at the drill tip over a 320 mm reach—a deviation exceeding AS9100 Rev D’s 0.08 mm positional tolerance for primary structure fastener holes.
Worse, low-stiffness joints amplify harmonic resonance. TSV’s spectral analysis of 12 robotic milling cells showed that systems with torsional stiffness <10,500 N·m/rad exhibited dominant vibration modes at 142–158 Hz—directly overlapping the natural frequency band of carbon-fiber laminates (135–165 Hz). This coupling induced delamination in 22% of test panels, requiring full rework despite nominal toolpath adherence.
Stiffness also governs thermal drift stability. Under continuous operation at 40°C ambient, low-stiffness harmonic drives exhibit up to 0.018°/°C angular hysteresis—accumulating 0.13° drift over an 8-hour shift. That equates to 0.7 mm linear offset at end-effector level—beyond acceptable limits for sealant bead placement on fuselage joints (max allowed: ±0.3 mm).
This table reflects real-world thresholds—not theoretical maxima. The “High-Performance Threshold” column represents values observed in three operational Boeing 787 final assembly cells and two Airbus A350 wing box workcells. Procurement teams validating bids should require third-party stiffness reports—not just manufacturer datasheets—with traceable calibration certificates for torque transducers and angular encoders.
Procurement Decision Framework: 6 Non-Negotiable Stiffness Validation Steps
Selecting a robot for aerospace assembly requires moving beyond catalog claims. TSV mandates these six validation steps before any system enters qualification:
- Request full stiffness matrix data (not just “wrist stiffness”)—covering all 6 DOF axes under 3 load conditions: 50%, 75%, and 100% max payload.
- Verify test methodology against ISO 9283 Annex B or equivalent (e.g., VDI/VDE 2617-30), including environmental controls (±1°C, 45–55% RH).
- Require fatigue validation: minimum 2,500 cycles at 85% rated torque, measured pre- and post-test using laser interferometry (not encoder-only).
- Inspect thermal hysteresis testing protocol—must include 3-hour stabilization at both 15°C and 45°C, with angular position logged every 10 seconds.
- Validate dynamic stiffness via swept-sine modal analysis (5–500 Hz), reporting first three resonant frequencies and damping ratios.
- Cross-check reported values against TSV’s independent benchmark database—free access granted upon qualified RFQ submission.
Skipping even one step risks $1.2M+ in rework per production line over a 5-year lifecycle. TSV’s audit of 11 recent procurements found that 7 systems failed Step 3 (fatigue retention), triggering unplanned recalibration every 18 days versus the required 90-day interval.
Beyond the Robot: System-Level Stiffness Optimization Strategies
Joint stiffness doesn’t exist in isolation. Its impact multiplies across the entire robotic cell. Mounting rigidity contributes up to 35% of total system compliance. TSV’s field measurements show that standard M12 anchor bolts into 200 MPa concrete yield 42% lower effective stiffness than custom-designed kinematic mounts with preload-controlled hydraulic tensioning.
End-effector design is equally critical. A modular tool changer with 0.008 mm mating repeatability may still introduce 0.032 mm compliance if its interface stiffness is <4,000 N/μm. TSV recommends specifying tool interfaces per ISO 10791-7:2021, with mandatory finite element analysis (FEA) validation of worst-case loading scenarios—including simultaneous 3-axis torque and axial thrust.
Real-time compensation is possible—but only with verified inputs. Closed-loop stiffness compensation requires synchronized measurement of joint torque (±0.5% FS), angular position (±0.001°), and end-effector force (±0.3% FS) at ≥10 kHz sampling. Fewer than 9% of commercially available robot controllers meet this synchronization requirement without external FPGA co-processing.
System-level stiffness is multiplicative—not additive. A 10% deficiency in mounting stiffness compounds with a 12% deficit in tool interface stiffness to produce a 28% overall compliance increase. This explains why identical robots deliver divergent surface quality when deployed across different integrators’ cell designs.
Actionable Next Steps: From Data to Deployment
Engineering truth starts with verifiable parameters—not vendor narratives. If your next aerospace robotic workcell must achieve Ra ≤ 0.4 μm on machined titanium or ≤ 0.8 μm on cured CFRP, joint stiffness cannot be an afterthought. It must be specified, tested, and guaranteed—traceably.
TechStat Vanguard provides three immediate-value services to eliminate stiffness-related risk:
- Free Stiffness Gap Assessment: Submit your current robot model and application specs—we’ll benchmark against TSV’s 2024 aerospace stiffness database (29 platforms, 112 configurations) and identify hidden compliance risks.
- Third-Party Validation Protocol: Access TSV’s ISO-aligned stiffness test plan (TSV-ROB-2024-07), including equipment calibration requirements, environmental controls, and pass/fail criteria—ready for inclusion in your RFQ.
- Supplier Qualification Dashboard: Real-time access to stiffness retention curves, thermal hysteresis logs, and modal analysis reports for 47 certified robotics suppliers—updated quarterly with field performance data.
Parameters do not lie. Tolerances dictate success. To request your free Stiffness Gap Assessment—or to download the full TSV-ROB-2024-07 validation protocol—contact our aerospace robotics benchmarking team today. Engineering truth begins where specifications end.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026How tight can micro machining aerospace tolerances be in production?Micro machining aerospace tolerances can reach low-micron levels in production. Learn what controls repeatability, inspection confidence, and flight-critical quality.Dr. Marcus Vance
 Oct 13, 2026How to keep an industrial robotic integration project on scheduleIndustrial robotic integration project management: keep automation on schedule with proven controls for interfaces, suppliers, FAT, commissioning, and change risk.Victor Lin (Chief Software Architect)























