
How to Choose AMR Fleet Management Software in 2026
Publication Date
author
In 2026, choosing the right amr fleet management software is no longer just an IT decision—it directly affects uptime, routing accuracy, labor efficiency, and ROI. For teams comparing automation systems alongside agv charging station setup, robotic bin picking 3d vision, and servo motor for cnc router upgrades, this guide explains how to evaluate platforms with engineering rigor, data transparency, and procurement-ready criteria.
Why AMR fleet management software now sits at the center of automation decisions
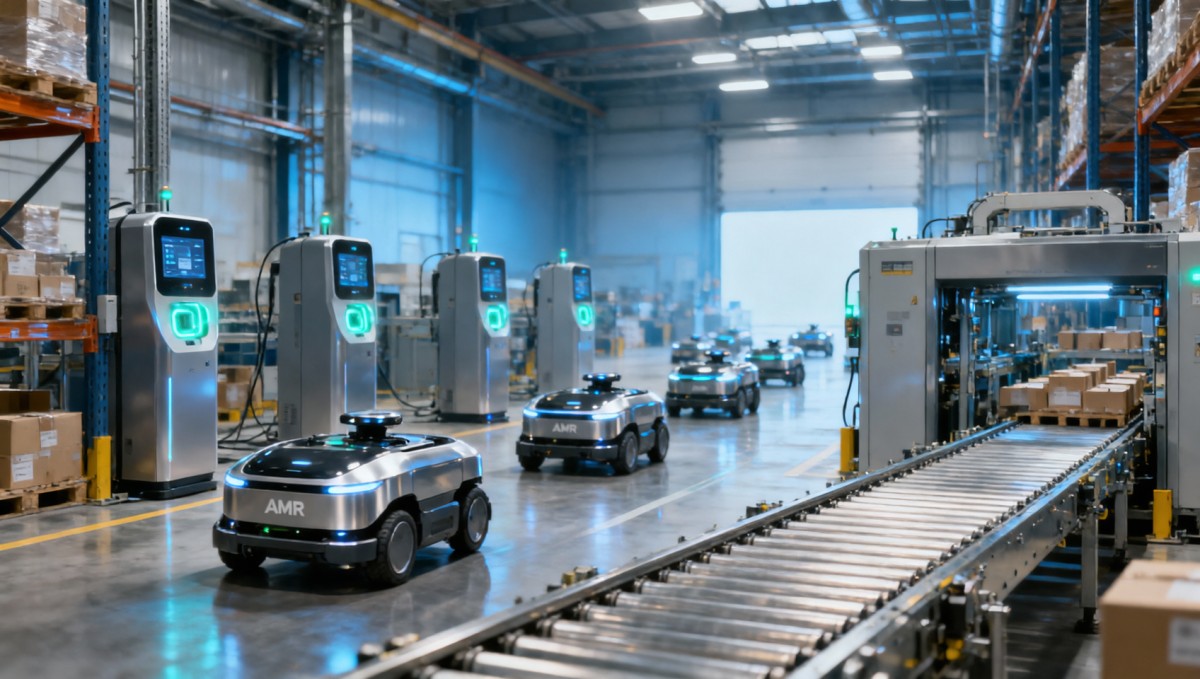
For many factories, warehouses, and mixed-use industrial campuses, AMR fleet management software has become the real control layer behind mobile automation. The robots may carry parts, pallets, totes, or inspection payloads, but the fleet platform decides task allocation, traffic priority, congestion recovery, battery strategy, and integration with upstream systems. In practical terms, weak software can turn capable hardware into an underperforming investment within 3–6 months of deployment.
This matters across the broader hard-tech supply chain because AMR operations no longer exist in isolation. A facility evaluating robotic bin picking 3d vision may also need mobile robots to feed workstations. A site planning agv charging station expansion may discover that charger utilization depends more on fleet scheduling logic than charger count. A CNC workshop upgrading a servo motor for cnc router lines may still lose throughput if material transport between cells remains poorly coordinated.
TechStat Vanguard approaches this topic from an engineering benchmarking mindset. The key question is not whether a vendor claims intelligence, autonomy, or scalability. The useful question is narrower and more measurable: how does the software perform under variable load, mixed traffic, intermittent Wi-Fi, changing missions, and real maintenance constraints over 2–4 shifts per day?
Buyers, operators, and executives usually care about different outcomes. Operators want stable dispatching, simple alarms, and fast exception handling. Procurement teams need clean requirement mapping, support scope, and lifecycle cost visibility. Decision-makers care about utilization, deployment risk, and payback logic. Good amr fleet management software should satisfy all three groups without hiding behind vague dashboards.
What the software is expected to manage in 2026
Modern platforms are expected to orchestrate more than robot movement. In a typical deployment, they should cover task queue management, dynamic rerouting, traffic control, battery-aware scheduling, role-based user access, event logs, and APIs for WMS, MES, ERP, or line-side PLC coordination. Sites with 5–20 robots have different needs from sites running 50–200 mobile units across multiple zones, but both need control transparency.
- Dispatching logic that can assign jobs by priority, distance, battery state, payload, and robot capability rather than first-come, first-served.
- Traffic rules that prevent aisle deadlock, charger queues, and repeated route conflicts during shift peaks or material surges.
- Operational visibility that lets teams review idle time, mission completion time, alarm frequency, and failure patterns on a daily or weekly basis.
- Integration readiness for adjacent systems such as agv charging station controls, conveyor handoff points, machine tending cells, and robotic bin picking 3d vision stations.
When these elements are missing or poorly designed, the symptoms often appear as labor workarounds rather than software failures. Teams add manual dispatching, isolate robots by zone, overbuild charging points, or keep more standby labor on each shift. Those hidden compensations distort ROI and make the automation project look less effective than the hardware specification originally suggested.
How to evaluate AMR fleet management software with engineering rigor
The most reliable way to compare amr fleet management software is to break evaluation into measurable layers. Start with navigation orchestration, then move to system integration, operational visibility, resilience, and supplier support. This avoids a common mistake: buying software based on demo graphics instead of actual scheduling logic, exception handling, and maintainability over a 12–36 month operating horizon.
A practical procurement review should define 5 core dimensions before any vendor shortlisting: mission complexity, facility layout variability, required uptime window, integration depth, and support response expectations. For example, a clean warehouse with repeated point-to-point moves differs sharply from a mixed factory where mobile robots interact with forklifts, manual carts, elevators, and production cells. The software requirements are not the same, even if both projects use AMRs.
TSV recommends documenting acceptance criteria in parameter language wherever possible. Instead of asking whether the platform is scalable, define expected concurrent robot count, average missions per hour, charger occupancy thresholds, and recovery behavior after communication loss. Instead of asking whether dashboards are powerful, ask which logs can be exported, at what interval, and whether event timestamps align across robot, charger, and upstream system records.
The table below can be used as a first-pass procurement framework for cross-functional teams. It translates software claims into operational checks that engineering, operations, and sourcing teams can review together during the RFQ stage.
A structured table like this prevents teams from overvaluing polished interfaces. In many real projects, the deciding factor is not how the software looks during a demo, but how it reacts when 3 robots request the same handoff point, one charger is down, and a priority order must still leave the line on time.
The 4 technical layers that deserve the closest review
1. Scheduling logic
Look for rule depth, not just mission assignment. The platform should understand task urgency, travel time, current position, battery state, robot type, and path congestion. In facilities with 10–30 active robots, inefficient dispatching may remain hidden. In facilities above that range, poor logic usually creates visible queueing and idle machine time.
2. System resilience
Ask how the fleet software responds to Wi-Fi dropouts, map changes, blocked routes, or upstream system delays. Resilience is not a marketing term. It should be visible in fallback modes, local buffering, reattempt rules, and event traceability. If a mission fails, the operator should know why in seconds, not after a support ticket chain.
3. Integration discipline
The software should integrate cleanly with line-side automation, machine vision inspection, warehouse execution, and charging infrastructure. For example, if robotic bin picking 3d vision releases totes irregularly, the fleet manager must absorb those fluctuations without causing downstream starvation or overstock at the cell.
4. Data transparency
Engineering teams should be able to export logs, compare mission cycle times, review alarm recurrence, and identify route bottlenecks over daily, weekly, and monthly windows. If a supplier cannot show how data is stored, tagged, and retrieved, future optimization becomes slow and expensive.
Which software capabilities matter most for operators, procurement teams, and executives?
Different stakeholders usually ask different questions about amr fleet management software, and strong projects translate those needs into one aligned checklist. Operators need stable execution and clear interfaces. Procurement teams need contractual clarity, integration boundaries, and support expectations. Executives need confidence that the platform will scale from pilot to plant-wide rollout without unpredictable redesign costs.
In 2026, user experience should be measured as operational clarity rather than visual simplicity alone. A clean dashboard matters, but what matters more is whether an operator can distinguish blocked path events from battery alerts, charger queue issues, or handoff failures within 1–2 screens. Confusing alarm structures increase downtime because teams waste time diagnosing the wrong layer.
Procurement teams should also separate standard functionality from engineering effort. Many platforms advertise broad connectivity, but the real cost sits in customization, middleware, site commissioning, and post-go-live changes. A low entry quote may become expensive if every MES tag, charger handshake, or map revision requires billable engineering hours.
Executives should focus on scale economics and governance. Can one system manage a single area now and 3–5 zones later? Can permissions, audit trails, and reporting support multiple departments? Can the supplier support version control, cybersecurity updates, and phased expansion over 12–24 months? If not, the software may solve only today’s bottleneck.
Role-based decision checklist
- For operators: confirm alarm readability, route override controls, task reassignment steps, user permissions, and average training time, which in many facilities should be manageable within 1–3 days for core functions.
- For procurement: confirm license scope, integration inclusions, support hours, spare device policy, software update policy, and responsibilities during commissioning and acceptance testing.
- For engineering: confirm API documentation, event timestamp structure, map update workflow, simulation support, and charger logic compatibility with agv charging station design.
- For executives: confirm scale path, total cost range over 3 years, expected deployment phases, and decision points for adding robots, zones, or integrated workcells.
One recurring TSV observation is that many underperforming deployments fail at the handoff between departments. Operations signs off on usability, procurement pushes for price, and engineering discovers late integration gaps. The result is not a bad robot, but a weak decision process. A shared scorecard prevents this drift.
AMR fleet software comparison: what to score before you shortlist vendors
Shortlisting works best when vendors are compared against the same use case, the same traffic conditions, and the same expansion assumptions. Teams should not compare one platform in a light-duty warehouse scenario and another in a heavy mixed-flow factory scenario. Keep mission volume, payload logic, facility constraints, and integration scope consistent so the comparison reveals software differences rather than demo framing.
A robust scorecard should balance function, risk, and operating cost. Function includes dispatching, charging, maps, logs, and APIs. Risk includes deployment complexity, supplier dependency, and recovery behavior. Operating cost includes licenses, updates, onsite support, and engineering changes. This is especially important when AMR projects are being assessed together with conveyor cells, robotic bin picking 3d vision stations, or machine tending upgrades.
The following comparison matrix is designed for practical procurement workshops. It does not assume any one vendor model. Instead, it helps teams convert technical observations into a purchasing decision that survives finance review and plant operations scrutiny.
This matrix helps expose hidden lifecycle risk. Two software options may both complete a demo mission, yet only one may remain efficient when mission volume doubles, chargers are shared, and adjacent automation cells produce irregular demand patterns. That distinction directly affects uptime, labor backup needs, and expansion cost.
Common comparison mistakes
The first mistake is comparing interface style instead of control depth. The second is ignoring charger logic until late in the project, even though agv charging station utilization often becomes a limiting factor after go-live. The third is assuming integration is trivial because an API exists. APIs still need data discipline, ownership, timeout behavior, and version control.
Another mistake is evaluating only steady-state performance. Real facilities face blocked aisles, task surges, mixed manual traffic, and schedule changes. Ask vendors to explain behavior during edge cases across at least 4 scenarios: congestion, communication loss, charger unavailability, and urgent task insertion. That reveals much more than a polished standard demo.
Implementation, compliance, and lifecycle cost: what many buyers overlook
Buying amr fleet management software is only one part of the decision. Successful deployment depends on mapping, workflow design, safety coordination, IT alignment, charger planning, acceptance testing, and support coverage. A typical implementation may move through 4 stages: requirement definition, simulation and integration planning, onsite commissioning, and production stabilization. Depending on site complexity, that cycle may take 6–16 weeks.
Compliance and governance also matter. While the exact requirements depend on region and facility type, buyers should review cybersecurity practices, user access controls, audit logs, software update procedures, and safety interaction with plant traffic management. If the AMR system interacts with machines, doors, lifts, or conveyors, interface validation becomes part of commissioning discipline, not an optional add-on.
Lifecycle cost deserves the same attention as purchase price. Costs can include software licenses, integration engineering, onsite setup, training, updates, network improvements, map revisions, and support renewals. Some facilities also incur indirect costs from change freezes, production interruptions during commissioning, or temporary labor overlap during ramp-up. These are manageable when planned early, but expensive when discovered late.
TSV’s broader hard-tech view is useful here because AMR software rarely stands alone. It interacts with edge devices, sensors, charging systems, machine vision, and manufacturing controls. A fleet platform that looks affordable in isolation may become a poor choice if it creates recurring engineering dependence whenever the plant expands or adjacent automation changes.
A realistic implementation checklist
- Define operating boundaries: robot count, shifts, traffic zones, handoff stations, payload rules, and charger locations.
- Validate integration points: WMS, MES, PLCs, elevator or door controls, and vision-guided workcells.
- Set acceptance metrics: mission completion rate, average mission time, alarm response workflow, and recovery behavior after faults.
- Train teams by role: operators, maintenance, IT, and production supervisors should not receive the same training depth.
- Plan post-go-live review windows at 2 weeks, 30 days, and 90 days to capture bottlenecks before they become permanent workarounds.
FAQ for buyers comparing AMR fleet software in 2026
How many robots justify a dedicated fleet management platform?
Even smaller deployments can benefit if workflows are variable or integration is complex. In simple layouts, 3–5 robots may run acceptably with limited control features. Once sites add multiple zones, charging contention, or integration with production and warehouse systems, dedicated amr fleet management software becomes much more valuable.
What should buyers ask about charger coordination?
Ask whether the software supports opportunity charging, queue management, charger prioritization, and workload-aware battery thresholds. This is especially important when agv charging station infrastructure is shared or when shifts create demand spikes. Charger logic can directly affect robot availability and task delays.
Can one platform support mixed automation workflows?
Often yes, but only if integration depth is verified early. Sites combining mobile robots with robotic bin picking 3d vision, conveyor handoff, or machine tending should confirm event timing, task triggers, and failure recovery logic. The challenge is usually not connectivity alone, but orchestration under variable demand.
How long does deployment usually take?
A straightforward installation may move quickly, while a complex multi-system rollout often needs 6–16 weeks including testing and stabilization. The schedule depends on layout mapping, interface count, IT readiness, charger setup, and acceptance criteria. Asking for a phased timeline is more useful than asking for one headline date.
Why work with a data-driven technical partner before you finalize the shortlist
Choosing amr fleet management software in 2026 requires more than collecting brochures and watching demos. It requires a disciplined review of parameters, operating constraints, integration boundaries, and lifecycle trade-offs. That is exactly where TechStat Vanguard adds value. Our perspective is built around engineering truth, not promotional language, so procurement and technical teams can make decisions based on measurable fit rather than market noise.
For information researchers, we can help translate vendor claims into comparable technical criteria. For operators and maintenance teams, we can help identify which functions matter most for alarms, dispatching, charger coordination, and exception recovery. For sourcing teams and executives, we can support requirement framing around scale, support scope, rollout phases, and total decision risk.
If your project also touches agv charging station planning, robotic bin picking 3d vision integration, edge AI sensing, or servo motor for cnc router modernization, the selection logic should be connected rather than isolated. Mobile automation performance depends on the wider system. Reviewing these interfaces early reduces rework, shortens supplier qualification cycles, and improves commissioning confidence.
Contact TechStat Vanguard to discuss parameter confirmation, software selection criteria, integration checkpoints, delivery planning, compliance considerations, test acceptance structure, or quotation comparison. If you are building a shortlist now, we can help turn your AMR project into a procurement-ready technical brief with clearer requirements, fewer assumptions, and stronger decision discipline.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026How tight can micro machining aerospace tolerances be in production?Micro machining aerospace tolerances can reach low-micron levels in production. Learn what controls repeatability, inspection confidence, and flight-critical quality.Dr. Marcus Vance























